
mlech26l/ncps
mlech26l/ncps has 2,363 GitHub stars and 377 forks. GitHot measured 0 stars in 24 hours, +3 in 7 days, and +5 in 15 days. Last checked 2026-11-21 16:42 UTC. Last push 2024-08-14.
측정된 스타 증가
- in 24h
- 0
- in 7 days
- +3
- in 15 days
- +5
- in 1 month
- 기록 수집 중
서로 겹치는 기간의 순증가량이며 일별 합계가 아닙니다. 측정값이 없으면 비워 둡니다. 스타는 관심도를 나타내며 품질을 보장하지 않습니다.
소개
PyTorch와 TensorFlow로 구현한 NCP, LTC, CfC 와이어드 신경 모델
머신러닝README.md
Original
Neural Circuit Policies (for PyTorch and TensorFlow)




📜 Papers
Neural Circuit Policies Enabling Auditable Autonomy (Open Access).
Closed-form continuous-time neural networks (Open Access)
Neural Circuit Policies (NCPs) are designed sparse recurrent neural networks loosely inspired by the nervous system of the organism C. elegans. The goal of this package is to making working with NCPs in PyTorch and keras as easy as possible.
import torch
from ncps.torch import CfC

rnn = CfC(20,50) # (input, hidden units)
x = torch.randn(2, 3, 20) # (batch, time, features)
h0 = torch.zeros(2,50) # (batch, units)
output, hn = rnn(x,h0)
Installation
pip install ncps
🔖 Colab Notebooks
We have created a few Google Colab notebooks for an interactive introduction to the package
- Google Colab (Pytorch) Basic usage
- Google Colab (Tensorflow): Basic usage
- Google Colab (Tensorflow): Processing irregularly sampled time-series
- Google Colab (Tensorflow) Stacking NCPs with other layers
End-to-end Examples
Usage: Models and Wirings
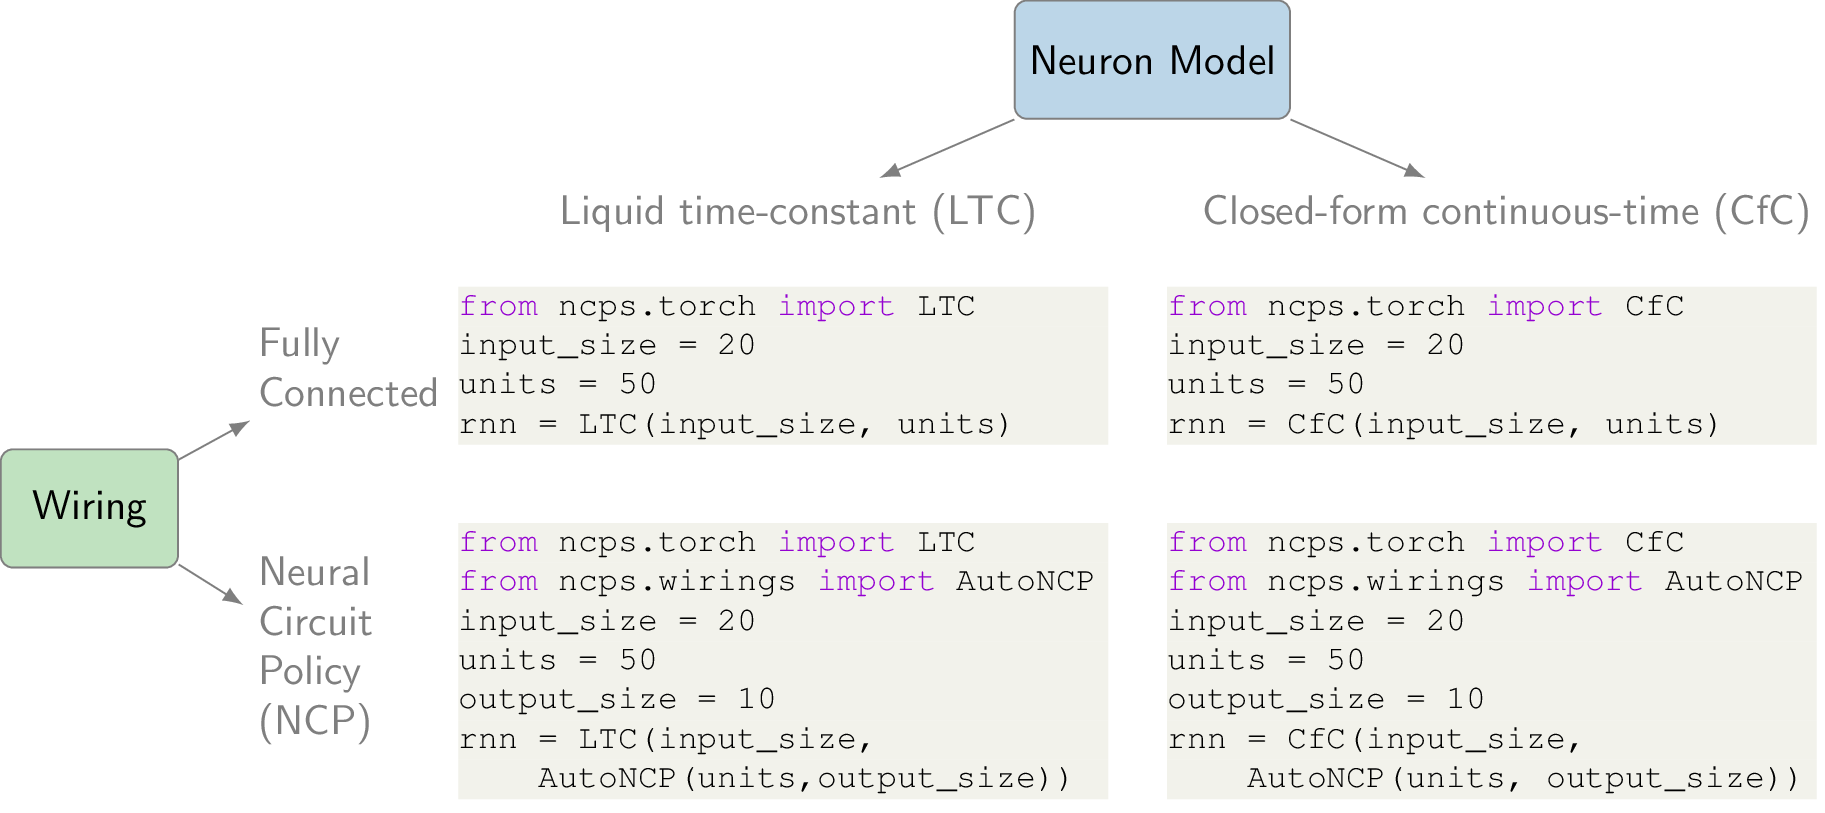
The package provides two models, the liquid time-constant (LTC) and the closed-form continuous-time (CfC) models.
Both models are available as tf.keras.layers.Layer or torch.nn.Module RNN layers.
from ncps.torch import CfC, LTC

input_size = 20
units = 28 # 28 neurons
rnn = CfC(input_size, units)
rnn = LTC(input_size, units)
The RNNs defined above consider fully-connected layers, i.e., as in LSTM, GRUs, and other RNNs. The distinctiveness of NCPs is their structured wiring diagram. To combine the LTC or CfC model with a
from ncps.torch import CfC, LTC
from ncps.wirings import AutoNCP

wiring = AutoNCP(28, 4) # 28 neurons, 4 outputs
input_size = 20
rnn = CfC(input_size, wiring)
rnn = LTC(input_size, wiring)
Tensorflow
The Tensorflow bindings are available via the ncps.tf module.
from ncps.tf import CfC, LTC
from ncps.wirings import AutoNCP

units = 28
wiring = AutoNCP(28, 4) # 28 neurons, 4 outputs
input_size = 20
rnn1 = LTC(units) # fully-connected LTC
rnn2 = CfC(units) # fully-connected CfC
rnn3 = LTC(wiring) # NCP wired LTC
rnn4 = CfC(wiring) # NCP wired CfC
We can then combine the NCP cell with arbitrary tf.keras.layers, for instance to build a powerful image sequence classifier:
from ncps.wirings import AutoNCP
from ncps.tf import LTC
import tensorflow as tf
height, width, channels = (78, 200, 3)

ncp = LTC(AutoNCP(32, output_size=8), return_sequences=True)

model = tf.keras.models.Sequential(
    [
        tf.keras.layers.InputLayer(input_shape=(None, height, width, channels)),
        tf.keras.layers.TimeDistributed(
            tf.keras.layers.Conv2D(32, (5, 5), activation="relu")
        ),
        tf.keras.layers.TimeDistributed(tf.keras.layers.MaxPool2D()),
        tf.keras.layers.TimeDistributed(
            tf.keras.layers.Conv2D(64, (5, 5), activation="relu")
        ),
        tf.keras.layers.TimeDistributed(tf.keras.layers.MaxPool2D()),
        tf.keras.layers.TimeDistributed(tf.keras.layers.Flatten()),
        tf.keras.layers.TimeDistributed(tf.keras.layers.Dense(32, activation="relu")),
        ncp,
        tf.keras.layers.TimeDistributed(tf.keras.layers.Activation("softmax")),
    ]
)
model.compile(
    optimizer=tf.keras.optimizers.Adam(0.01),
    loss='sparse_categorical_crossentropy',
)
@article{lechner2020neural,
  title={Neural circuit policies enabling auditable autonomy},
  author={Lechner, Mathias and Hasani, Ramin and Amini, Alexander and Henzinger, Thomas A and Rus, Daniela and Grosu, Radu},
  journal={Nature Machine Intelligence},
  volume={2},
  number={10},
  pages={642--652},
  year={2020},
  publisher={Nature Publishing Group}
}
관련 프로젝트 살펴보기
불러오는 중…