프로젝트 GitHub에서 보기
iwatake2222/self-driving-ish_computer_vision_system
iwatake2222/self-driving-ish_computer_vision_system has 408 GitHub stars and 87 forks. GitHot measured -1 stars in 24 hours. Last checked 2026-11-20 02:39 UTC. Last push 2022-02-12.
측정된 스타 증가
- in 24h
- -1
- in 7 days
- 기록 수집 중
- in 15 days
- 기록 수집 중
- in 1 month
- 기록 수집 중
서로 겹치는 기간의 순증가량이며 일별 합계가 아닙니다. 측정값이 없으면 비워 둡니다. 스타는 관심도를 나타내며 품질을 보장하지 않습니다.
소개
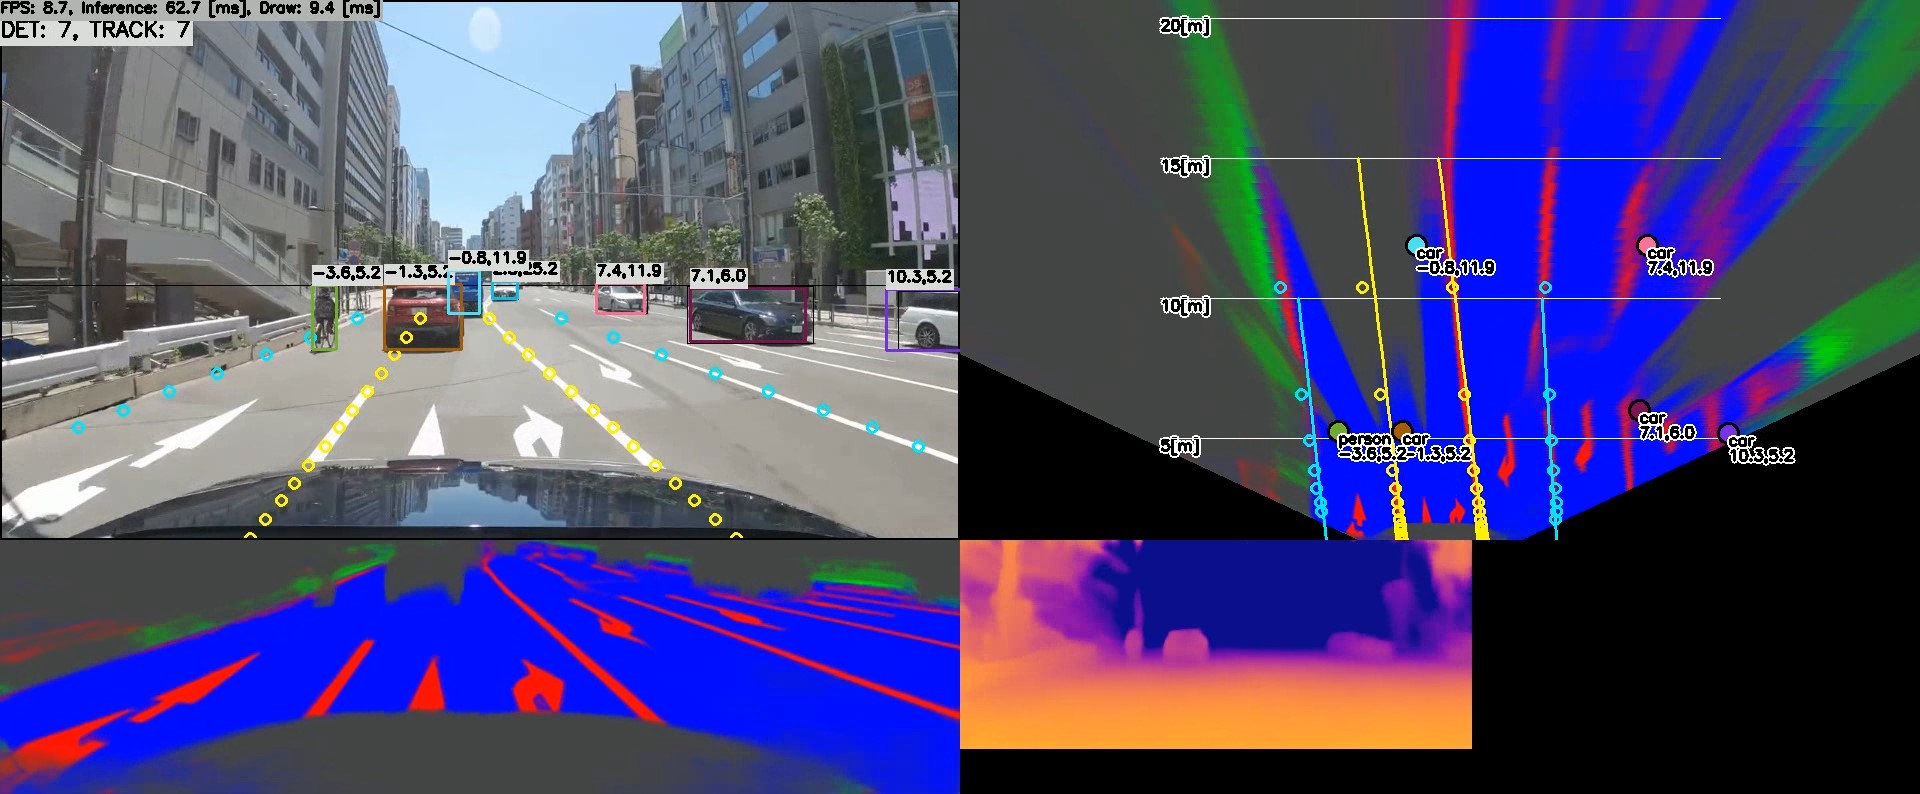
This project generates images you've probably seen in autonomous driving demo. Object Detection, Lane Detection, Road Segmentation, Depth Estimation using TensorRT
머신러닝README.md
OriginalSelf-Driving-ish Computer Vision System
- This project generates images you've probably seen in autonomous driving demo
- Detection
- Object Detection and Tracking
- Lane Detection and Curve Fitting
- Road Segmentation
- Depth Estimation
- Transform using Projective Geometry and Pinhole Camera Model
- Normal View -> Top View
- Distance Calculation (image plane -> ground plane in world coordinate system)
Result
- YoutTube: https://youtu.be/GB4p_fjQZNE
Tested Environment
Computer
- Windows 10 (x64) + Visual Studio 2019
- Intel Core i7-6700 @ 3.4GHz + NVIDIA GeForce GTX 1070
- Jetson Xavier NX. JetPack 4.6
- You will get error if using JetPack 4.5 or before because of TensorRT error
Deep Learning Inference Framework
- TensorFlow Lite with XNNPACK delegate
- CPU
- Note: Running with CPU is very slow
- TensorRT
- GPU
Usage
./main [input]
 - input:
    - use the default image file set in source code (main.cpp): blank
        - ./main
     - use video file: *.mp4, *.avi, *.webm
        - ./main test.mp4
     - use image file: *.jpg, *.png, *.bmp
        - ./main test.jpg
    - use camera: number (e.g. 0, 1, 2, ...)
        - ./main 0
    - use camera via gstreamer on Jetson: jetson
        - ./main jetson
- Mouse Drag: Change top view angle
- Keyboard (asdwzx) : Change top view position
How to build a project
0. Requirements
- OpenCV 4.x
- CMake
- TensorRT 8.0.x
- If you get build error related to TensorRT, modify cmake settings for it in
inference_helper/inference_helper/CMakeLists.txt
- If you get build error related to TensorRT, modify cmake settings for it in
1. Download source code and pre-built libraries
- Download source code
- If you use Windows, you can use Git Bash
git clone https://github.com/iwatake2222/self-driving-ish_computer_vision_system.git cd self-driving-ish_computer_vision_system git submodule update --init sh inference_helper/third_party/download_prebuilt_libraries.sh - Download models
sh ./download_resource.sh
2-a. Build in Windows (Visual Studio)
- Configure and Generate a new project using cmake-gui for Visual Studio 2019 64-bit
Where is the source code: path-to-cloned-folderWhere to build the binaries: path-to-build (any)
- Open
main.sln - Set
mainproject as a startup project, then build and run! - Note:
- You may need to modify cmake setting for TensorRT for your environment
2-b. Build in Linux (Jetson Xavier NX)
mkdir build && cd build
# cmake .. -DENABLE_TENSORRT=off
cmake .. -DENABLE_TENSORRT=on
make
./main
Note
cmake options
cmake .. -DENABLE_TENSORRT=off  # Use TensorFlow Lite (default)
cmake .. -DENABLE_TENSORRT=on   # Use TensorRT

cmake .. -DENABLE_SEGMENTATION=on    # Enable Road Segmentation function (default)
cmake .. -DENABLE_SEGMENTATION=off   # Disable Road Segmentation function

cmake .. -DENABLE_DEPTH=on    # Enable Depth Estimation function (default)
cmake .. -DENABLE_DEPTH=off   # Disable Depth Estimation function
Misc
- It will take very long time when you execute the app for the first time, due to model conversion
- I took 80 minutes with RTX 3060ti
- I took 10 - 20 minutes with GTX 1070
Software Design
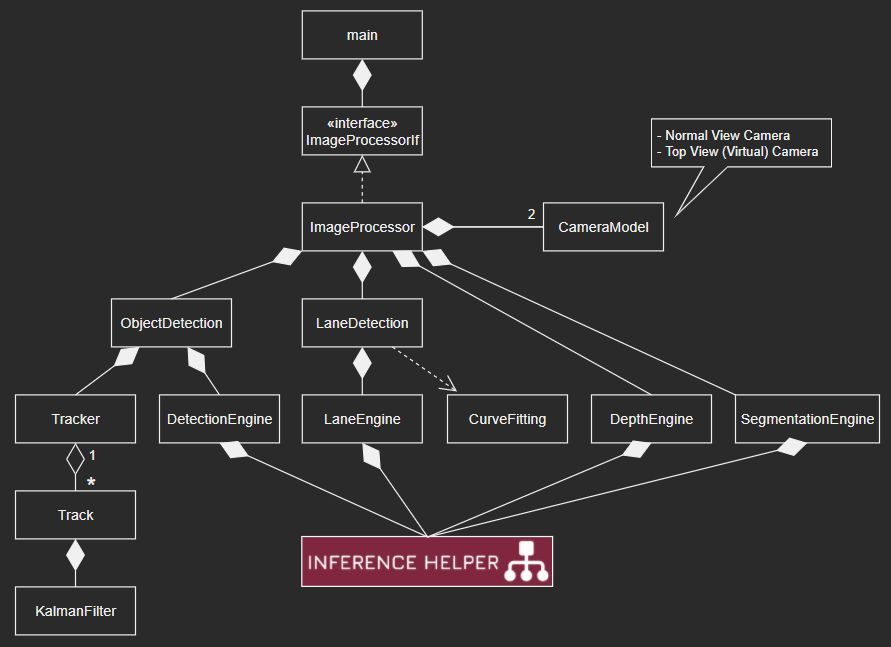
Class Diagram
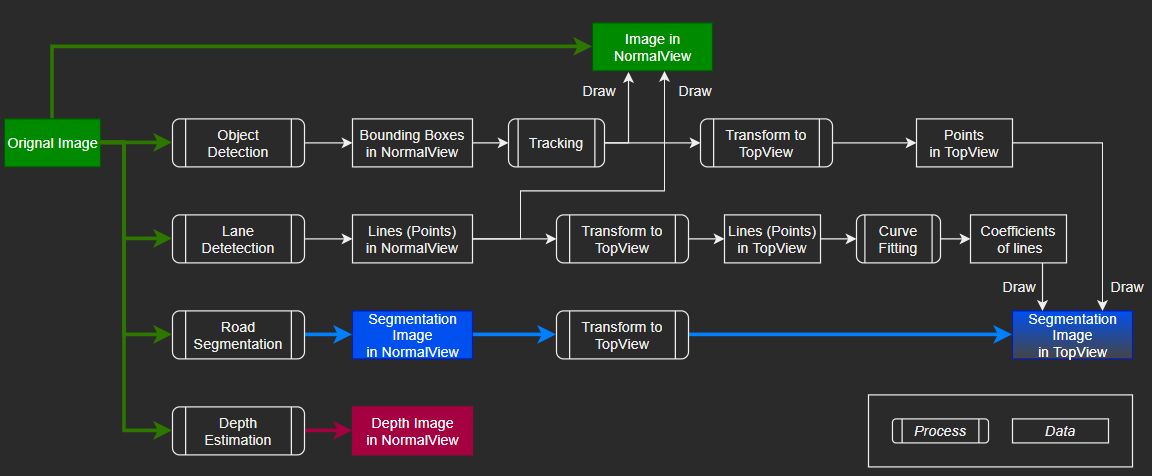
Data Flow Diagram
Model Information
Details
- Object Detection
- Lane Detection
- Ultra-Fast-Lane-Detection, 288x800
- https://github.com/PINTO0309/PINTO_model_zoo/blob/main/140_Ultra-Fast-Lane-Detection/download_culane.sh
- Road Segmentation
- road-segmentation-adas-0001, 512x896
- https://github.com/PINTO0309/PINTO_model_zoo/blob/main/136_road-segmentation-adas-0001/download.sh
- Depth Estimation
- LapDepth, 192x320
- https://github.com/PINTO0309/PINTO_model_zoo/blob/main/148_LapDepth/download_ldrn_kitti_resnext101.sh
- LapDepth, 256x512
- 00_doc/pytorch_pkl_2_onnx_LapDepth.ipynb
Performance
| Model | Jetson Xavier NX | GTX 1070 |
|---|---|---|
| == Inference time == | ||
| Object Detection | 10.6 ms | 6.4 ms |
| Lane Detection | 9.6 ms | 4.9 ms |
| Road Segmentation | 29.1 ms | 13.5 ms |
| Depth Estimation | 55.2 ms | 37.8 ms |
| == FPS == | ||
| Total (All functions) | 6.8 fps | 10.9 fps |
| Total (w/o Segmentation, Depth) | 24.4 fps | 33.3 fps |
- Input
- Jetson Xavier NX: Camera
- GTX 1070: mp4 video
- With TensorRT FP16
- "Total" includes image read, pre/post process, other image process, result image drawing, etc.
License
- Copyright 2021 iwatake2222
- Licensed under the Apache License, Version 2.0
Acknowledgements
I utilized the following OSS in this project. I appreciate your great works, thank you very much.
Code, Library
- TensorFlow
- https://github.com/tensorflow/tensorflow
- Copyright 2019 The TensorFlow Authors
- Licensed under the Apache License, Version 2.0
- Generated pre-built library
- TensorRT
- https://github.com/nvidia/TensorRT
- Copyright 2020 NVIDIA Corporation
- Licensed under the Apache License, Version 2.0
- Copied source code
- cvui
- https://github.com/Dovyski/cvui
- Copyright (c) 2016 Fernando Bevilacqua
- Licensed under the MIT License (MIT)
- Copied source code
Model
- PINTO_model_zoo
- https://github.com/PINTO0309/PINTO_model_zoo
- Copyright (c) 2019 Katsuya Hyodo
- Licensed under the MIT License (MIT)
- Copied converted model files
- YOLOX
- https://github.com/Megvii-BaseDetection/YOLOX
- Copyright (c) Megvii, Inc. and its affiliates. All Rights Reserved
- Licensed under the Apache License, Version 2.0
- Ultra-Fast-Lane-Detection
- https://github.com/cfzd/Ultra-Fast-Lane-Detection
- Copyright (c) 2020 cfzd
- Licensed under the MIT License (MIT)
- road-segmentation-adas-0001
- https://github.com/openvinotoolkit/open_model_zoo/tree/master/models/intel/road-segmentation-adas-0001
- Copyright (c) 2021 Intel Corporation
- Licensed under the Apache License, Version 2.0
- LapDepth-release
- https://github.com/tjqansthd/LapDepth-release
- Licensed under the GNU General Public License v3.0
Image Files
- OpenCV
- https://github.com/opencv/opencv
- Licensed under the Apache License, Version 2.0
- YoutTube
- https://www.youtube.com/watch?v=tTuUjnISt9s
- Licensed under the Creative Commons license
- Copyright Dashcam Roadshow 2020