
fangchangma/self-supervised-depth-completion
fangchangma/self-supervised-depth-completion has 654 GitHub stars and 134 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-14 01:21 UTC. Last push 2021-04-24.
측정된 스타 증가
- in 24h
- 0
- in 7 days
- 기록 수집 중
- in 15 days
- 기록 수집 중
- in 1 month
- 기록 수집 중
서로 겹치는 기간의 순증가량이며 일별 합계가 아닙니다. 측정값이 없으면 비워 둡니다. 스타는 관심도를 나타내며 품질을 보장하지 않습니다.
소개
ICRA 2019 "Self-supervised Sparse-to-Dense: Self-supervised Depth Completion from LiDAR and Monocular Camera"
머신러닝README.md
Originalself-supervised-depth-completion
This repo is the PyTorch implementation of our ICRA'19 paper on "Self-supervised Sparse-to-Dense: Self-supervised Depth Completion from LiDAR and Monocular Camera", developed by Fangchang Ma, Guilherme Venturelli Cavalheiro, and Sertac Karaman at MIT. A video demonstration is available on YouTube.
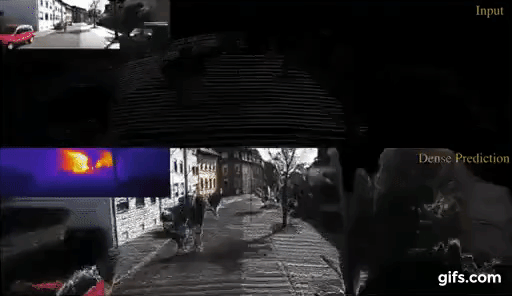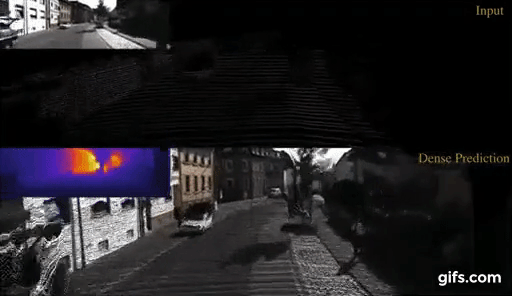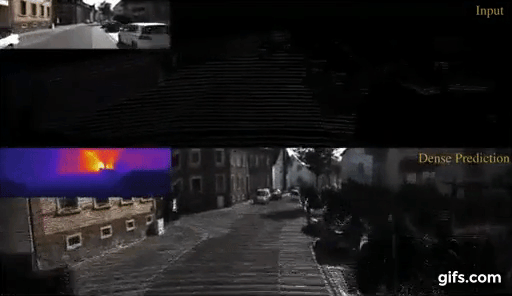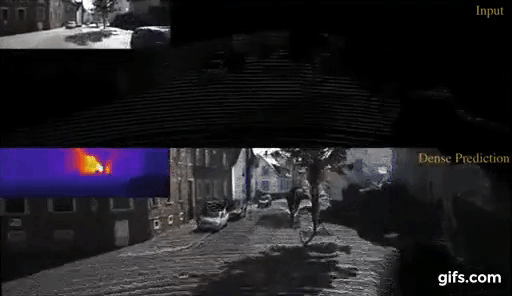
Our network is trained with the KITTI dataset alone, without pretraining on Cityscapes or other similar driving dataset (either synthetic or real). The use of additional data is likely to further improve the accuracy.
Please create a new issue for code-related questions.
Contents
Dependency
This code was tested with Python 3 and PyTorch 1.0 on Ubuntu 16.04.
pip install numpy matplotlib Pillow
pip install torch torchvision # pytorch

# for self-supervised training requires opencv, along with the contrib modules
pip install opencv-contrib-python==3.4.2.16
Data
- Download the KITTI Depth Dataset from their website. Use the following scripts to extract corresponding RGB images from the raw dataset.
./download/rgb_train_downloader.sh
./download/rgb_val_downloader.sh
The downloaded rgb files will be stored in the ../data/data_rgb folder. The overall code, data, and results directory is structured as follows (updated on Oct 1, 2019)
.
├── self-supervised-depth-completion
├── data
|   ├── data_depth_annotated
|   |   ├── train
|   |   ├── val
|   ├── data_depth_velodyne
|   |   ├── train
|   |   ├── val
|   ├── depth_selection
|   |   ├── test_depth_completion_anonymous
|   |   ├── test_depth_prediction_anonymous
|   |   ├── val_selection_cropped
|   └── data_rgb
|   |   ├── train
|   |   ├── val
├── results
Trained Models
Download our trained models at http://datasets.lids.mit.edu/self-supervised-depth-completion to a folder of your choice.
- supervised training (i.e., models trained with semi-dense lidar ground truth): http://datasets.lids.mit.edu/self-supervised-depth-completion/supervised/
- self-supervised (i.e., photometric loss + sparse depth loss + smoothness loss): http://datasets.lids.mit.edu/self-supervised-depth-completion/self-supervised/
Commands
A complete list of training options is available with
python main.py -h
For instance,
# train with the KITTI semi-dense annotations, rgbd input, and batch size 1
python main.py --train-mode dense -b 1 --input rgbd

# train with the self-supervised framework, not using ground truth
python main.py --train-mode sparse+photo

# resume previous training
python main.py --resume [checkpoint-path]

# test the trained model on the val_selection_cropped data
python main.py --evaluate [checkpoint-path] --val select
Citation
If you use our code or method in your work, please cite the following:
@article{ma2018self,
	title={Self-supervised Sparse-to-Dense: Self-supervised Depth Completion from LiDAR and Monocular Camera},
	author={Ma, Fangchang and Cavalheiro, Guilherme Venturelli and Karaman, Sertac},
	booktitle={ICRA},
	year={2019}
}
@article{Ma2017SparseToDense,
	title={Sparse-to-Dense: Depth Prediction from Sparse Depth Samples and a Single Image},
	author={Ma, Fangchang and Karaman, Sertac},
	booktitle={ICRA},
	year={2018}
}
관련 프로젝트 살펴보기
tensorflow/tensorflow
모두를 위한 오픈소스 머신러닝 프레임워크
201,591 스타huggingface/transformers
🤗 Transformers: 텍스트, 비전, 오디오, 멀티모달 분야의 최첨단 머신러닝 모델을 위한 모델 정의 프레임워크로, 추론과 학습을 모두 지원합니다.
168,951 스타AUTOMATIC1111/stable-diffusion-webui
Stable Diffusion 웹 UI
165,306 스타Comfy-Org/ComfyUI
그래프와 노드로 구성된 인터페이스를 갖춘, 가장 강력하고 모듈성이 뛰어난 확산 모델 GUI, API, 백엔드입니다. 세계에서 가장 빠른 로컬 추론 엔진입니다.
146,694 스타