
NVIDIA/warp
NVIDIA/warp has 7,304 GitHub stars and 692 forks. GitHot measured +3 stars in 24 hours and +32 in 7 days. Last checked 2026-11-12 14:09 UTC. Last push 2026-11-07.
시뮬레이션, 로보틱스, 머신러닝을 GPU로 가속하는 Python 프레임워크입니다.
측정된 스타 증가
- in 24h
- +3
- in 7 days
- +32
- in 15 days
- 업데이트 지연
- in 1 month
- 업데이트 지연
서로 겹치는 기간의 순증가량이며 일별 합계가 아닙니다. 측정값이 없으면 비워 둡니다. 스타는 관심도를 나타내며 품질을 보장하지 않습니다.
README.md
Original



NVIDIA Warp
Warp is a Python framework for GPU-accelerated simulation, robotics, and machine learning. Warp takes regular Python functions and JIT compiles them to efficient kernel code that can run on the CPU or GPU.
Warp comes with a rich set of primitives for physics simulation, robotics, geometry processing, and more. Warp kernels are differentiable and can be used as part of machine-learning pipelines with frameworks such as PyTorch, JAX and Paddle.
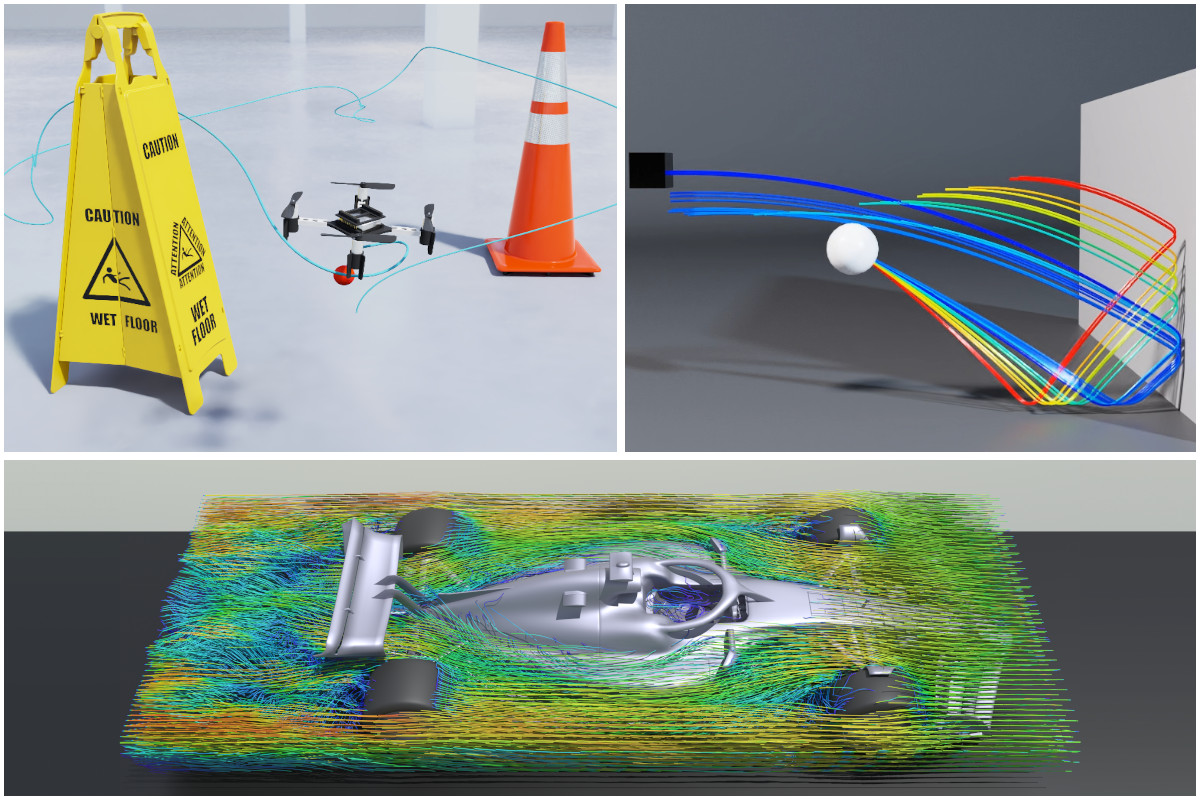
A selection of physical simulations computed with Warp
Quick Start
Simulate one million particles under gravitational attraction, in 20 lines:
import warp as wp
import numpy as np

num_particles = 1_000_000
dt = 0.01


@wp.kernel
def gravity_step(pos: wp.array[wp.vec3], vel: wp.array[wp.vec3]):
    i = wp.tid()
    position = pos[i]
    dist_sq = wp.length_sq(position) + 0.01  # softened distance
    acc = -1000.0 / dist_sq * wp.normalize(position)  # gravitational pull toward origin
    vel[i] = vel[i] + acc * dt
    pos[i] = pos[i] + vel[i] * dt


rng = np.random.default_rng(42)
positions = wp.array(rng.normal(size=(num_particles, 3)), dtype=wp.vec3)
velocities = wp.array(rng.normal(size=(num_particles, 3)), dtype=wp.vec3)

for _ in range(100):
    wp.launch(gravity_step, dim=num_particles, inputs=[positions, velocities])

print(positions.numpy())
Installing
Warp requires Python 3.11 or newer. We publish warp-lang wheels on PyPI for Windows (x86-64 and experimental Arm64), Linux (x86-64 and AArch64), and macOS (Apple Silicon). The Windows and Linux wheels support CPU execution and CUDA acceleration. The macOS wheels support CPU execution but not Metal acceleration.
PyPI and nightly wheels for Linux and Windows use CUDA Toolkit 13.4. They require an NVIDIA R580-series or newer driver and a Turing (sm_75) or newer GPU for CUDA acceleration. For CUDA 12 environments, download a +cu12 wheel from GitHub Releases or build Warp from source with CUDA 12.
Starting with Warp 1.19.0, PyPI releases and release candidates include experimental Windows on Arm wheels.
Install with pip install warp-lang from an Arm64 Python environment; see the
Windows on Arm installation notes.
The easiest way to install Warp is from PyPI:
pip install warp-lang
You can also use pip install warp-lang[examples] to install additional dependencies for running examples and USD-related features.
For nightly builds, conda, CUDA 12 compatibility wheels, building from source, and CUDA driver requirements, see the Installation Guide.
Tutorial Notebooks
The NVIDIA Accelerated Computing Hub also hosts Warp tutorial notebooks that can be opened in Colab:
| Notebook | Colab Link |
|---|---|
| 01. Introduction to NVIDIA Warp |  |
| 02. Ising Model | |
| 03. 2D Navier-Stokes Solver | |
| 04. Differentiable Simulations in Warp | |
Running Examples
The warp/examples directory contains examples covering physics simulation, geometry processing, optimization, and tile-based GPU programming. Before running examples, install the optional example dependencies using:
pip install warp-lang[examples]
On Linux aarch64 systems (e.g., NVIDIA DGX Spark), the [examples] extra automatically installs
usd-exchange instead of usd-core as a drop-in replacement,
since usd-core wheels are not available for that platform.
Examples can be run from the command-line as follows:
python -m warp.examples.<example_subdir>.<example>
Most examples can be run on either the CPU or a CUDA-capable device, but a handful require a CUDA-capable device. These are marked at the top of the example script. Some examples generate USD files containing time-sampled animations in the current working directory. These can be viewed in Pixar's UsdView, Blender, or any USD-compatible viewer.
To browse the example source code, you can open the directory where the files are located like this:
python -m warp.examples.browse
warp/examples/core
 |
 |
 |
 |
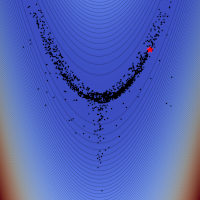
| dem | fluid | graph capture | mesh |
 |
 |
 |
 |
| nvdb | raycast | raymarch | sample mesh |
 |
 |
 |
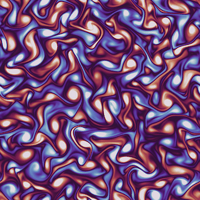 |
| sph | torch | wave | 2-D incompressible turbulence in a periodic box |
 |
|||
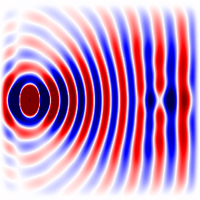
| 3-D FDTD Luneburg lens single GPU · multi GPU |
warp/examples/geometry
 |
 |
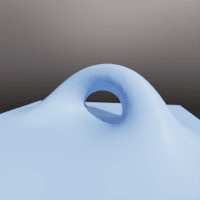
| isosurface | sparse marching cubes |
warp/examples/fem
 |
 |
 |
 |
| diffusion 3d | mixed elasticity | apic fluid | streamlines |
 |
 |
 |
 |
| distortion energy | taylor green | kelvin helmholtz | magnetostatics |
 |
 |
 |
 |
| adaptive grid | nonconforming contact | darcy level-set optimization | elastic shape optimization |
 |
|||
| cantilever topology optimization |
warp/examples/optim
 |
 |
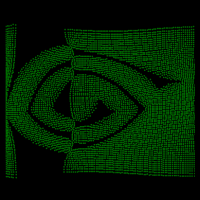 |
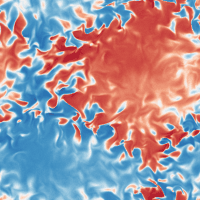 |
| diffray | fluid checkpoint basic · custom backward |
particle repulsion | navier-stokes perturbation |
warp/examples/tile
 |
 |
 |
|
| mlp | nbody | mcgp |
Learn More
Please see the following resources for additional background on Warp:
- Product Page
- How to Use NVIDIA Warp to Build GPU-Accelerated Computational Physics Simulations (GTC 2026 tutorial)
- SIGGRAPH 2024 Course Slides
- GTC 2024 Presentation
- GTC 2022 Presentation
- GTC 2021 Presentation
- SIGGRAPH Asia 2021 Differentiable Simulation Course
Support
See the FAQ for common questions.
Problems, questions, and feature requests can be opened on GitHub Issues.
For inquiries not suited for GitHub Issues, please email [email protected].
Contributing
Contributions and pull requests from the community are welcome. Please see the Contribution Guide for more information on contributing to the development of Warp.
License
Warp is provided under the Apache License, Version 2.0. Please see LICENSE.md for full license text.
This project will download and install additional third-party open source software projects. Review the license terms of these open source projects before use.
Building from Source
When building Warp from source using the build_lib.py script, the build process automatically
downloads NVIDIA libmathdx. Pre-built Warp
packages (e.g., from PyPI) already include libmathdx statically linked into the library binaries.
In both cases, libmathdx is governed by the
NVIDIA Software License Agreement.
NOTICE AND DISCLAIMER: This software automatically retrieves, accesses or interacts with external materials. Those retrieved materials are not distributed with this software and are governed solely by separate terms, conditions and licenses. You are solely responsible for finding, reviewing and complying with all applicable terms, conditions, and licenses, and for verifying the security, integrity and suitability of any retrieved materials for your specific use case. This software is provided "AS IS", without warranty of any kind. The author makes no representations or warranties regarding any retrieved materials, and assumes no liability for any losses, damages, liabilities or legal consequences from your use or inability to use this software or any retrieved materials. Use this software and the retrieved materials at your own risk.
Publications & Citation
Research Using Warp
Our PUBLICATIONS.md file lists academic and research publications that leverage the capabilities of Warp. We encourage you to add your own published work using Warp to this list.
Citing Warp
If you use Warp in your research, please use the "Cite this repository" button on the GitHub repository page or refer to the CITATION.cff file for citation information.
관련 프로젝트 살펴보기
tensorflow/tensorflow
모두를 위한 오픈소스 머신러닝 프레임워크
201,584 스타huggingface/transformers
🤗 Transformers: 텍스트, 비전, 오디오, 멀티모달 분야의 최첨단 머신러닝 모델을 위한 모델 정의 프레임워크로, 추론과 학습을 모두 지원합니다.
168,917 스타AUTOMATIC1111/stable-diffusion-webui
Stable Diffusion 웹 UI
165,300 스타Comfy-Org/ComfyUI
그래프와 노드로 구성된 인터페이스를 갖춘, 가장 강력하고 모듈성이 뛰어난 확산 모델 GUI, API, 백엔드입니다. 세계에서 가장 빠른 로컬 추론 엔진입니다.
146,472 스타