
KumarRobotics/CoverageControl
KumarRobotics/CoverageControl has 28 GitHub stars and 6 forks. Star changes are not measured yet. Last checked 2026-11-14 08:38 UTC. Last push 2026-09-14.
측정된 스타 증가
- in 24h
- 기록 수집 중
- in 7 days
- 기록 수집 중
- in 15 days
- 기록 수집 중
- in 1 month
- 기록 수집 중
서로 겹치는 기간의 순증가량이며 일별 합계가 아닙니다. 측정값이 없으면 비워 둡니다. 스타는 관심도를 나타내며 품질을 보장하지 않습니다.
소개
Environment for coverage control and learning using GNN
머신러닝README.md
OriginalSee full documentation at https://KumarRobotics.github.io/CoverageControl/
Introduction
Coverage control is the problem of navigating a robot swarm to collaboratively monitor features or a phenomenon of interest not known a priori.
The library provides a simulation environment, algorithms, and GNN-based architectures for the coverage control problem.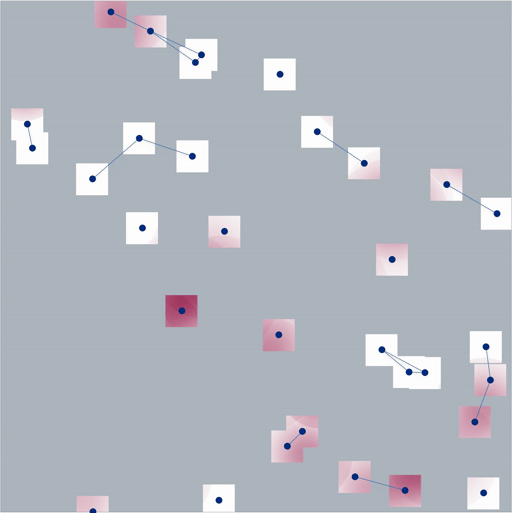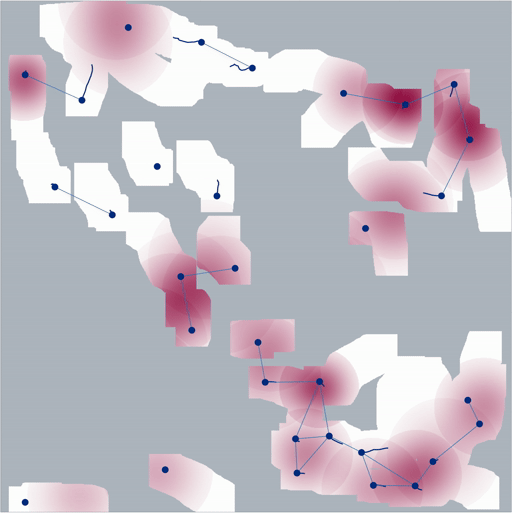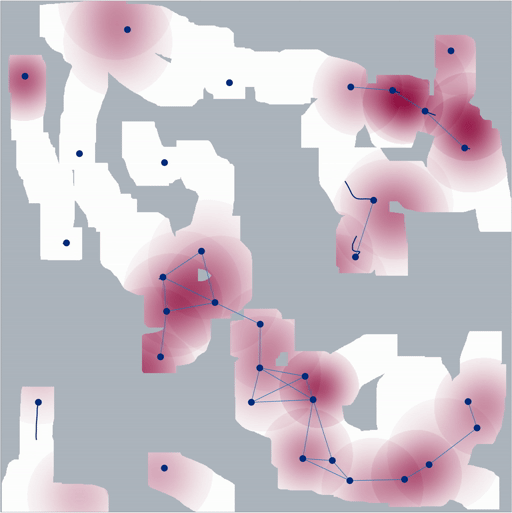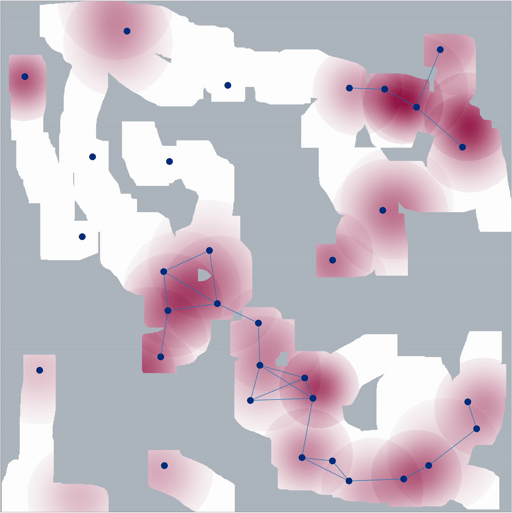
Key features:
- The core library is written in
C++andCUDAto handle large-scale simulations - There are
pythonbindings that interface with the core library - Several Centroidal Voronoi Tessellation (CVT)-based algorithms (aka Lloyd's algorithms)
- Learnable Perception-Action-Communication (LPAC) architecture for the coverage control problem is implemented in
PyTorchandPyTorch Geometric
Getting Started
The library is available as a pip package. To install the package, run the following command:
pip install coverage_control
See Installation for more details on installation.
See Quick Start guide for a quick introduction to the library.
Citation
@article{agarwal2024lpac,
      title         =   {LPAC: Learnable Perception-Action-Communication Loops with
                            Applications to Coverage Control},
      author        =   {Saurav Agarwal and Ramya Muthukrishnan and
                            Walker Gosrich and Vijay Kumar and Alejandro Ribeiro},
      year          =   {2024},
      eprint        =   {2401.04855},
      archivePrefix =   {arXiv},
      primaryClass  =   {cs.RO}
}
LPAC: Learnable Perception-Action-Communication Loops with Applications to Coverage Control.
Saurav Agarwal, Ramya Muthukrishnan, Walker Gosrich, Vijay Kumar, and Alejandro Ribeiro.
arXiv preprint arXiv:2401.04855 (2024).
Acknowledgements
- PyTorch
- PyTorch Geometric
- Eigen
- pybind11
- CGAL
- JSON for Modern C++
- CUDA Samples
- gnuplot-iostream
- hungarian-algorithm-cpp
- toml++
Support and Funding
The work was performed at the GRASP Laboratory and the Alelab, University of Pennsylvania, USA.
This work was supported in part by grants ARL DCIST CRA W911NF-17-2-0181 and ONR N00014-20-1-2822.
Contributors
- Saurav Agarwal
- Ramya Muthukrishnan
License
The library is licensed under the GPL-3.0 License. The documentation is not under the GPL-3.0 License and is licensed under the CC BY-NC-SA 4.0 License.
관련 프로젝트 살펴보기
tensorflow/tensorflow
모두를 위한 오픈소스 머신러닝 프레임워크
201,591 스타huggingface/transformers
🤗 Transformers: 텍스트, 비전, 오디오, 멀티모달 분야의 최첨단 머신러닝 모델을 위한 모델 정의 프레임워크로, 추론과 학습을 모두 지원합니다.
168,958 스타AUTOMATIC1111/stable-diffusion-webui
Stable Diffusion 웹 UI
165,311 스타Comfy-Org/ComfyUI
그래프와 노드로 구성된 인터페이스를 갖춘, 가장 강력하고 모듈성이 뛰어난 확산 모델 GUI, API, 백엔드입니다. 세계에서 가장 빠른 로컬 추론 엔진입니다.
146,746 스타