
slideshow-video-maker
TyphoonFlame
400Sterne
Slideshow Video Maker 2026 pre-configured environment for seamless local workstation deployment, integrating advanced video editing, screen...
Verbessere deinen Arbeitsablauf mit Editoren, Terminals, CLI- und Git-Werkzeugen.
TyphoonFlame
Slideshow Video Maker 2026 pre-configured environment for seamless local workstation deployment, integrating advanced video editing, screen...

typicms
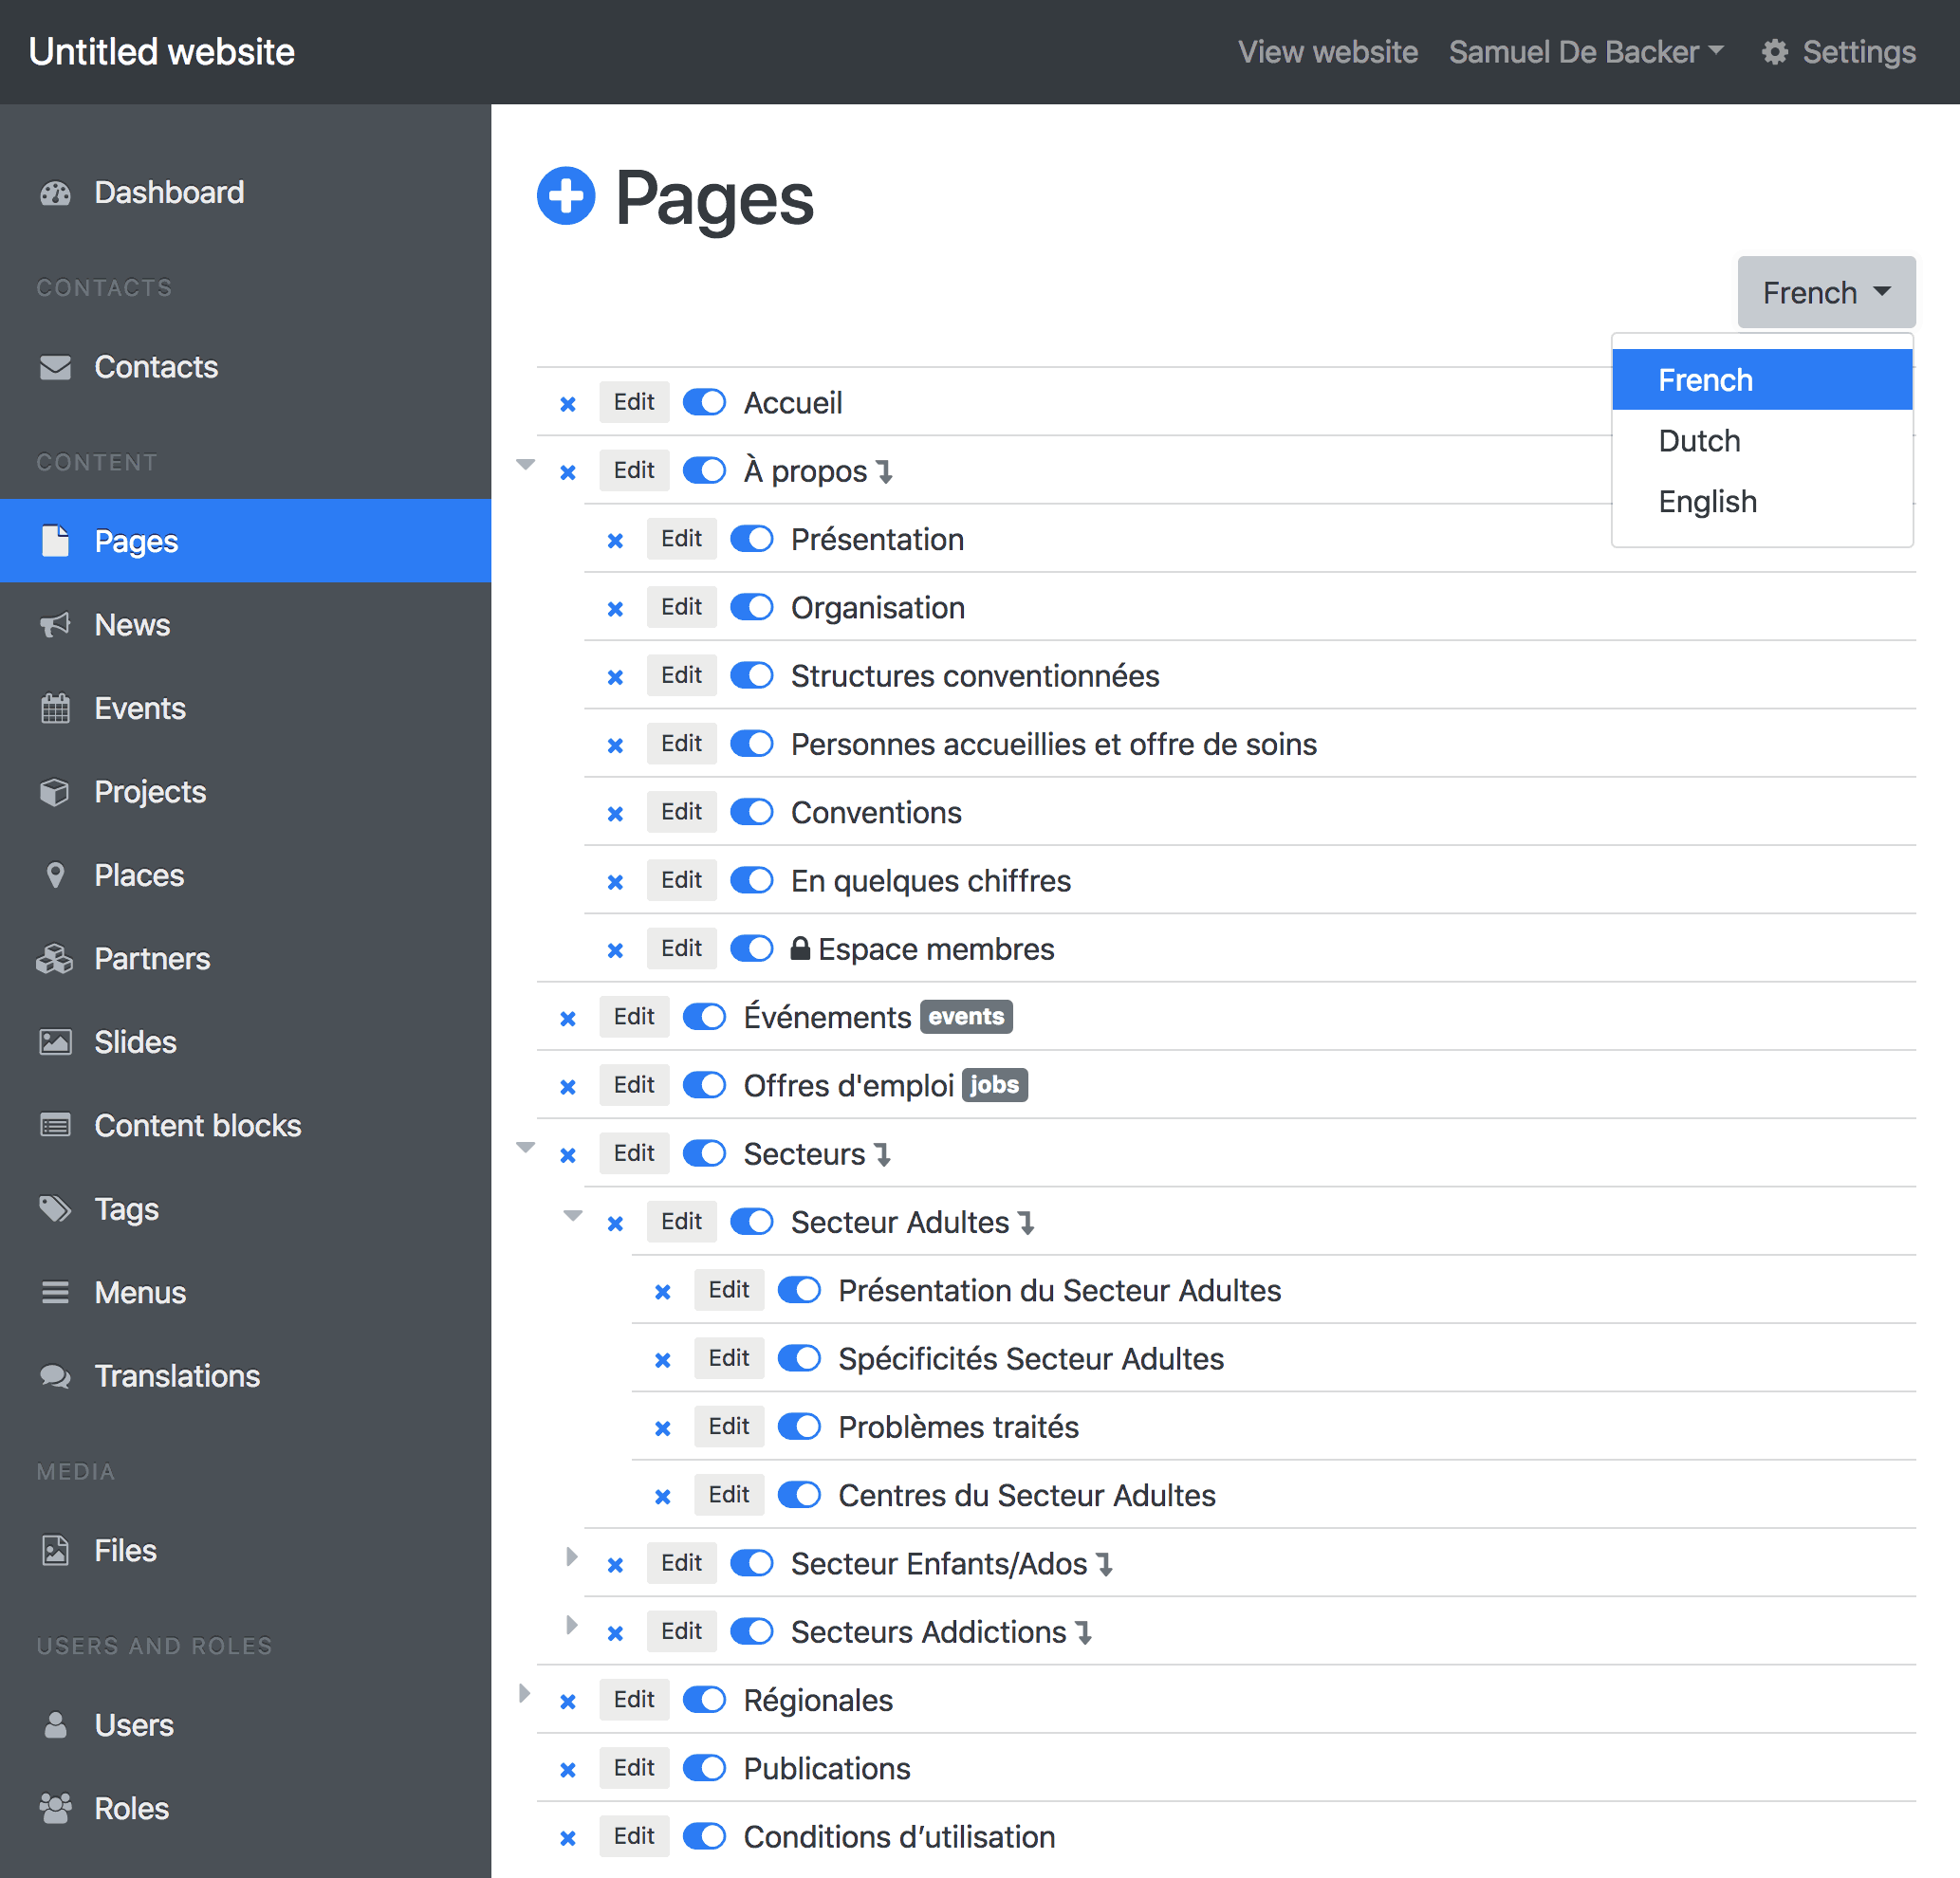
A modular multilingual CMS built with Laravel, enabling developers to manage structured content like pages, news, events, and more.

Tyrrrz
Class-first framework for building command-line interfaces

Tyru5
Floating scratch shell for herdr — a tmux-floax style toggleable popup, one per workspace, with persistent sessions

udacity
Starter project code for students taking Udacity ud120

udibr

Automatically generate headlines to short articles

UEC-InabaLab
ロールプレイで収集した日本語のカウンセリング対話データセット

UKPLab

Powerful unsupervised domain adaptation method for dense retrieval. Requires only unlabeled corpus and yields massive improvement: "GPL: Generative Pseudo Labeling for Unsupervised Domain Adaptation of Dense Retrieval" https://arxiv.org/abs/2112.07577

ultimatepp

U++ is a C++ cross-platform rapid application development framework focused on programmer's productivity. It includes a set of libraries (GUI, SQL, Network etc.), and integrated development environment (TheIDE).

ultralytics
CocoaPods specification for the Ultralytics pod, distributing the Ultralytics.xcframework client for computer vision models hosted on the Ultralytics Platform.
ultralytics
Docker container, inference pipeline, and submission tooling for deploying trained YOLOv3 object detection models in the xView satellite imagery challenge.

umap-project
uMap lets you create maps with OpenStreetMap layers in a minute and embed them in your site.

umodoc
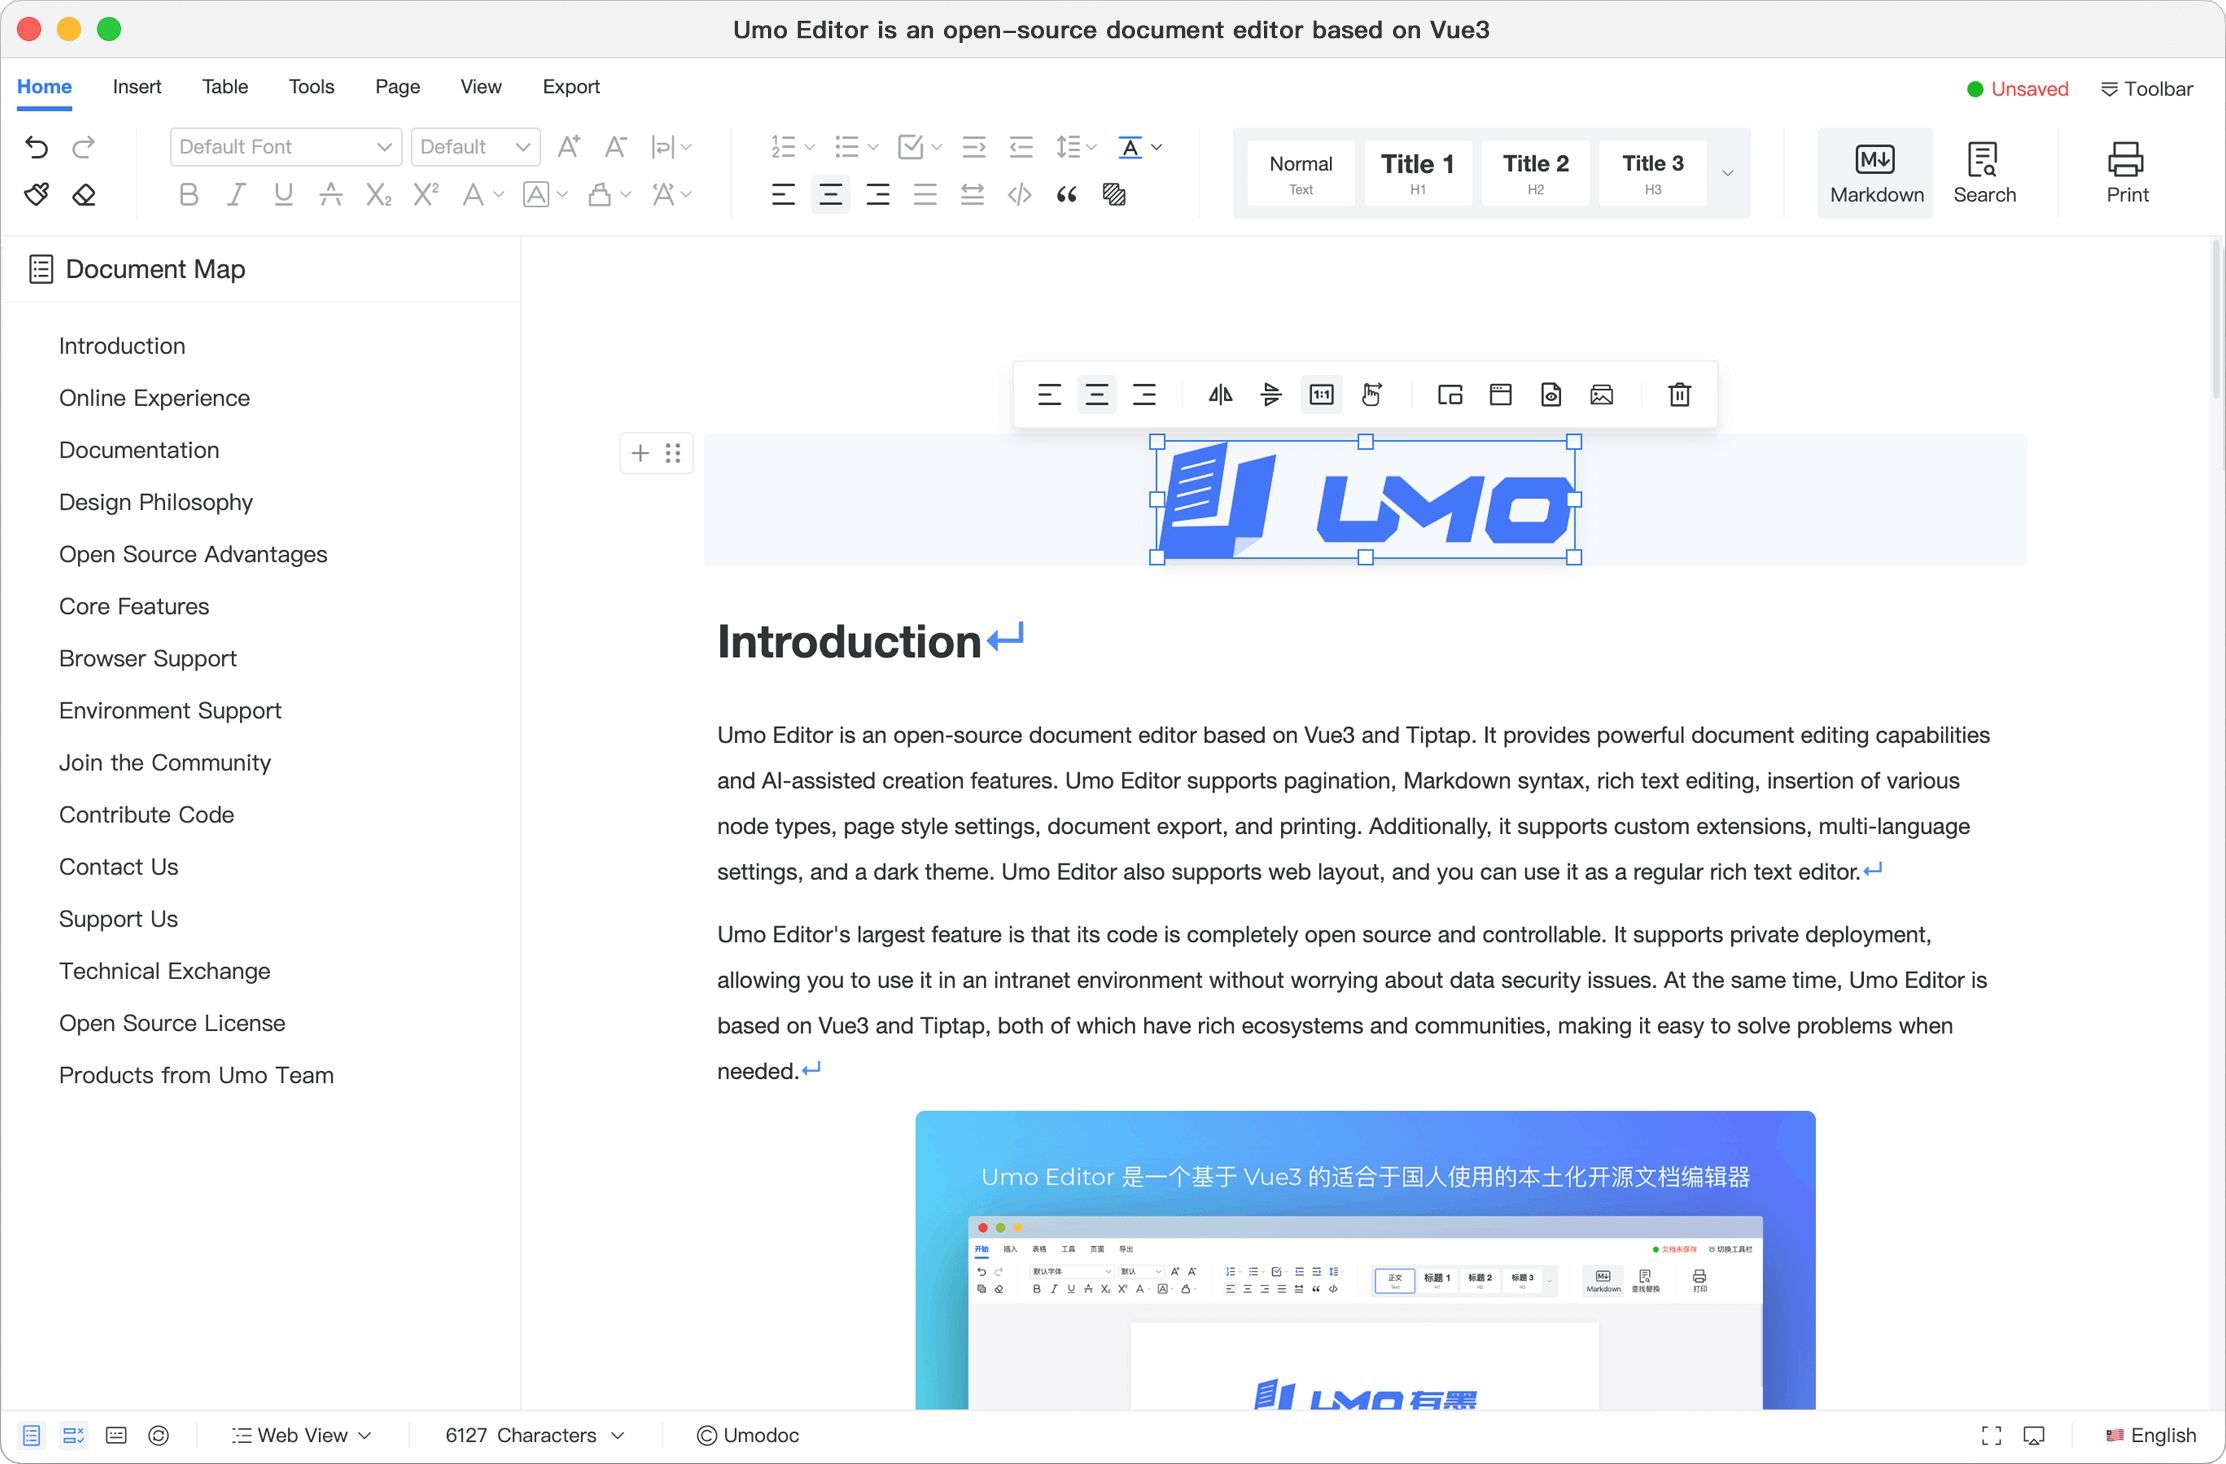
Umo Editor is an open-source document editor based on Vue3 and Tiptap3, providing an online editing experience similar to Microsoft Word.

umputun
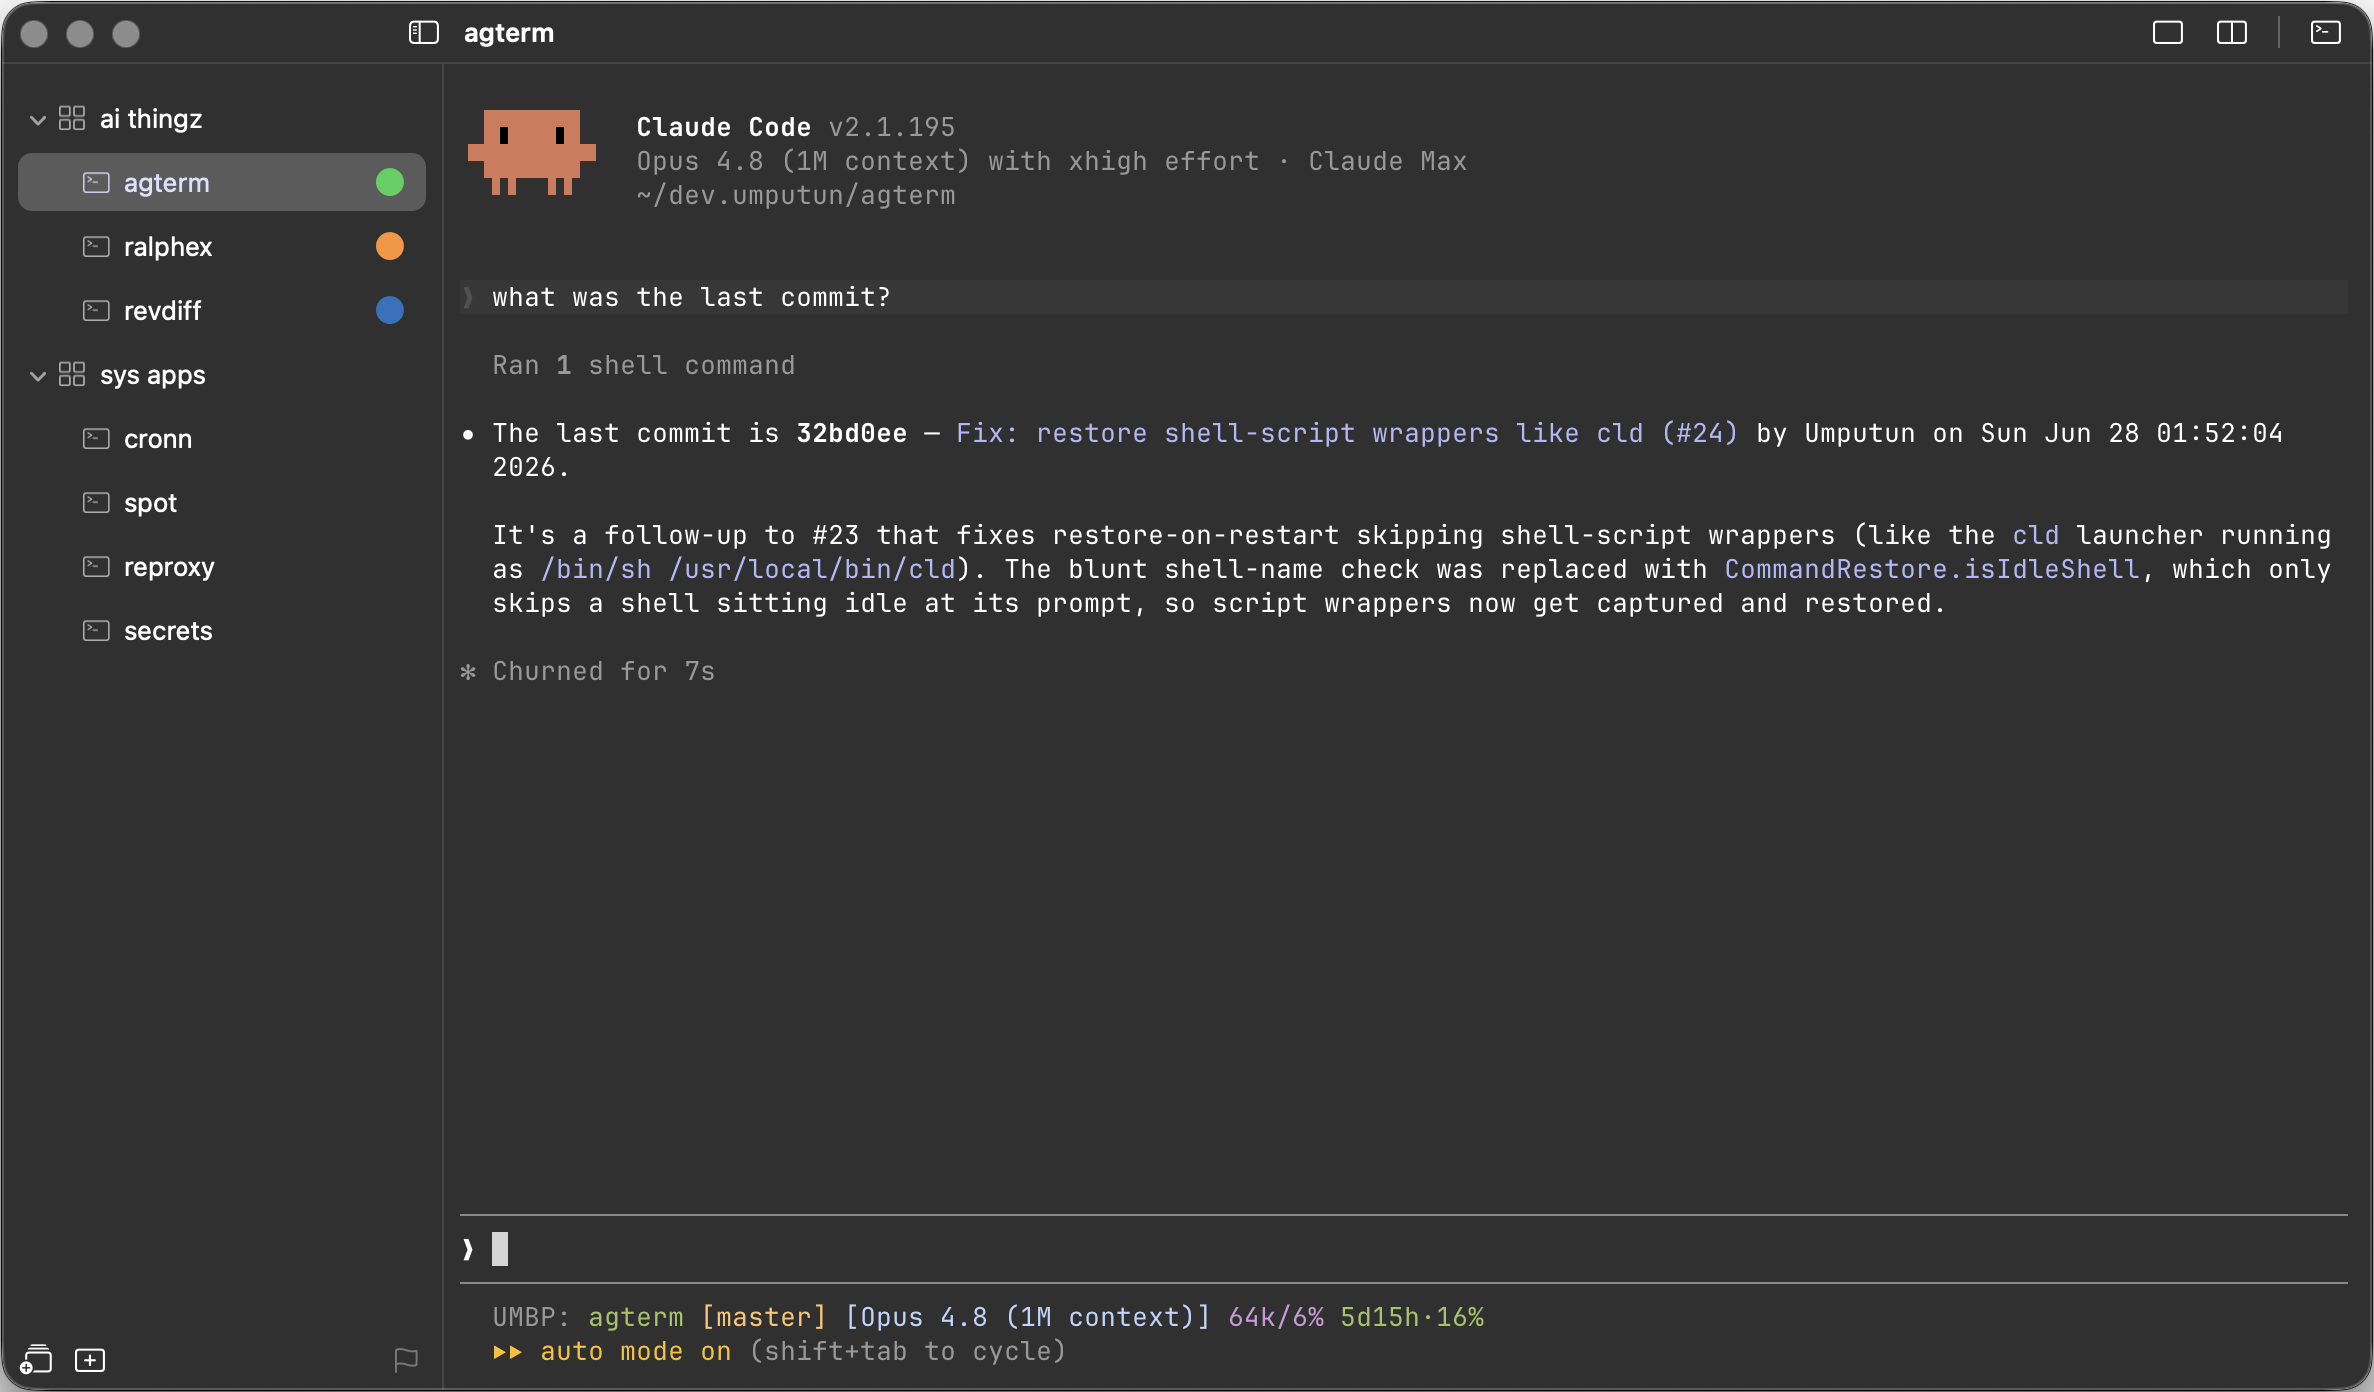
A genuinely good terminal

un33k
Returns unicode slugs

unchainedshop
High-Performance Headless Node.js ESM E-Commerce Framework

und3fined

Read Medium content without limit!

undergroundwires
☁️ Azure summary in bullet points

undertheseanlp

Repository to track the progress in Vietnamese Natural Language Processing, including the datasets and the current state-of-the-art for the most common Vietnamese NLP tasks.

undont

unified diff viewing experience in Neovim; local diffs, merge conflicts, GitHub PR review

unhappychoice
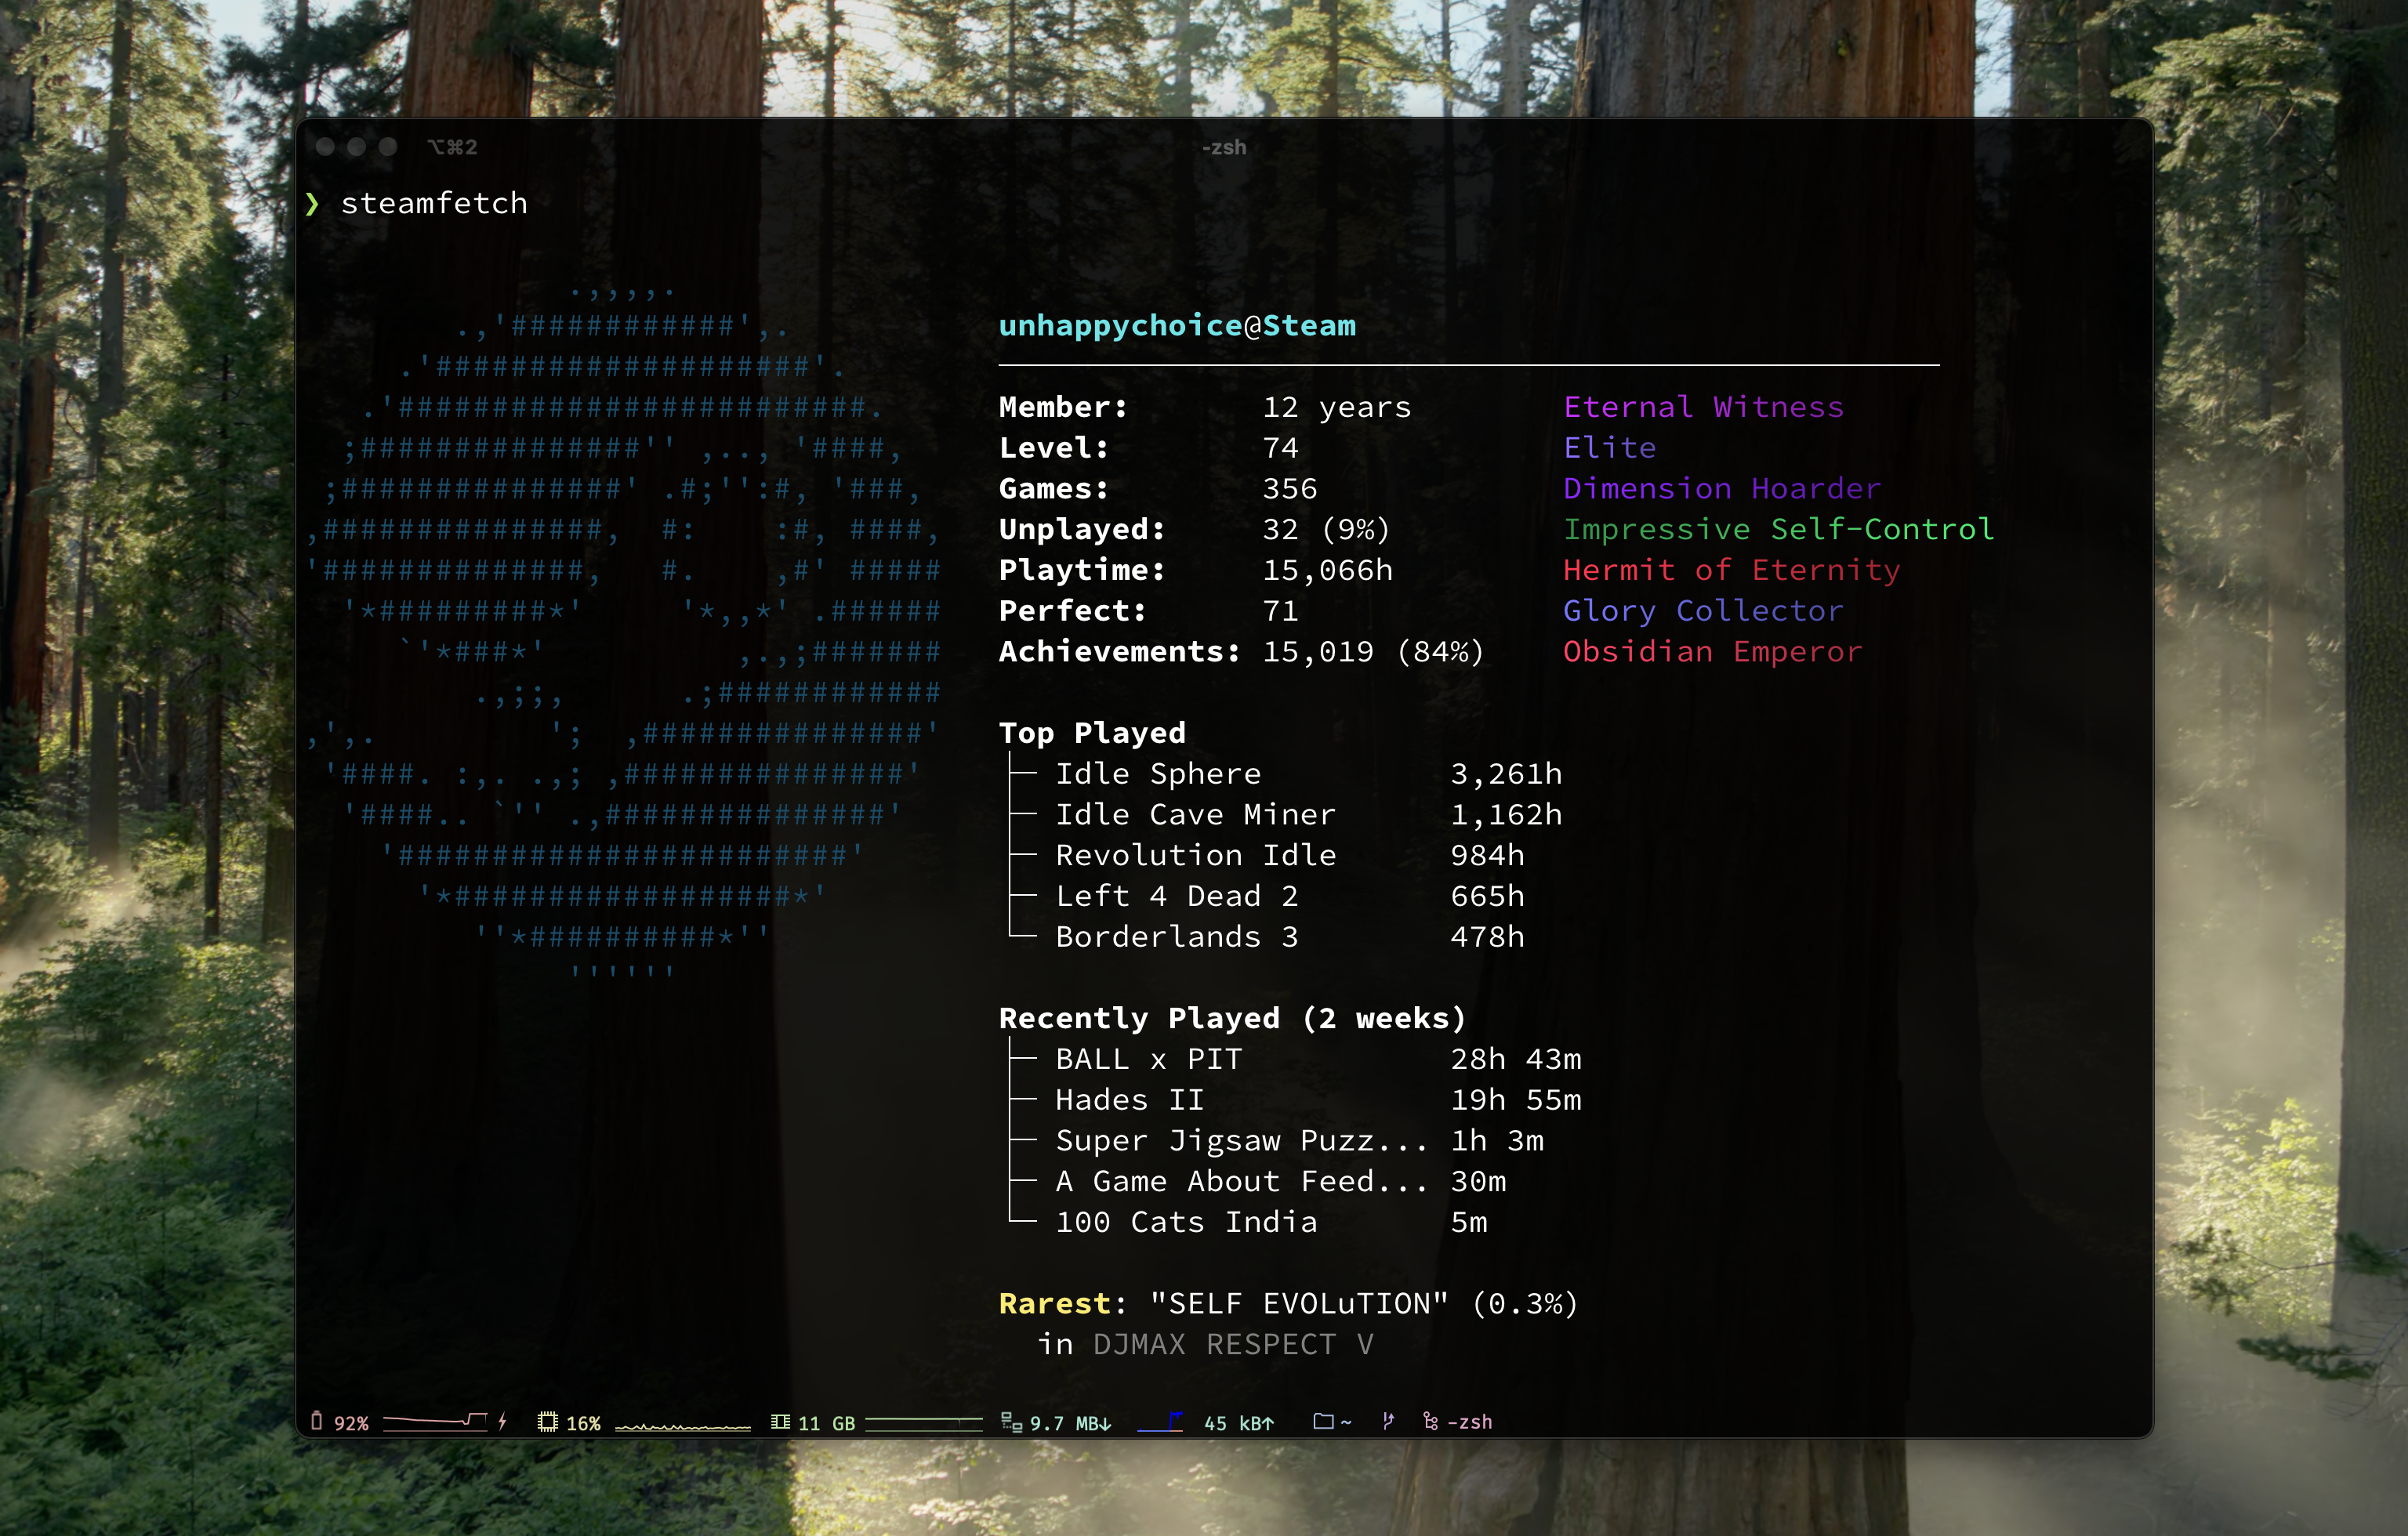
neofetch for Steam - Display your Steam stats in terminal
unhappychoice
:desktop_computer: Show high resolution images on your terminal !

unikraft

Build and use highly customized and ultra-lightweight unikernel VMs.

unitreerobotics
Here are the ROS simulation packages for Unitree robots, You can load robots and joint controllers in Gazebo, so you can perform low-level control (control the torque, position and angular velocity) of the robot joints. Please be aware that the Gazebo simulation cannot do high-level control, namely walking. Aside from these simulation functions, you can also control your real robots in ROS with the unitree_ros_to_real packages. For real robots, you can do high-level and low-level control using our ROS packages.