
yrlu/quadrotor
yrlu/quadrotor has 1,131 GitHub stars and 301 forks. GitHot measured -1 stars in 24 hours and -1 in 7 days. Last checked 2026-11-12 06:29 UTC. Last push 2024-05-05.
Quadrotor control, path planning and trajectory optimization
实测星标增长
- 24小时
- -1
- 7天
- -1
- 15天
- 正在收集历史
- 1个月
- 正在收集历史
各周期内的星标净变化,周期相互重叠,并非每日新增。缺失的测量保持空白。星标代表关注度,不代表软件质量。
README.md
原文Quadrotor Control, Path Planning and Trajectory Optimization

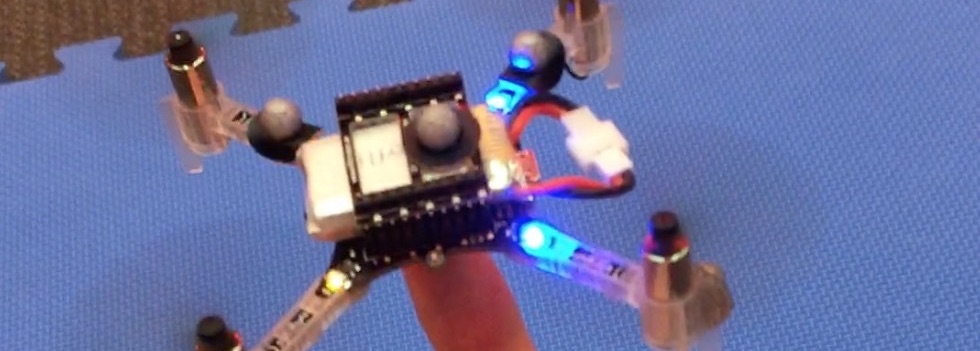
(Click the image above to watch real quadrotor demonstrations)
Following MEAM 620 Advanced Robotics course at University of Pennsylvania.
🚫 For Penn students: Please DO NOT spoil the learning experience by using this repository as a shortcut for your assignments. Most importantly, DO NOT violate the honor code!
Repository Contents
This repository contains MATLAB code for:
- Quadrotor PD controllers
- Path planning algorithms (Dijkstra, A*)
- Trajectory optimization algorithms (Minimum Snap/Acceleration Trajectory)
If you use this software in your publications, please cite it using the following BibTeX entry:
@misc{lu2017quadrotor,
  author = {Lu, Yiren and Cai, Myles and Ling, Wudao and Zhou, Xuanyu},
  doi = {10.5281/zenodo.6796215},
  month = {7},
  title = {{Quadrotor control, path planning and trajectory optimization}},
  url = {https://github.com/yrlu/quadrotor},
  year = {2017}
}
PD Controller
- Run code: change trajectories in file
control/runsim.mand run. - See quadrotor_dynamics.pdf for dynamic modeling of the quadrotor.
- See
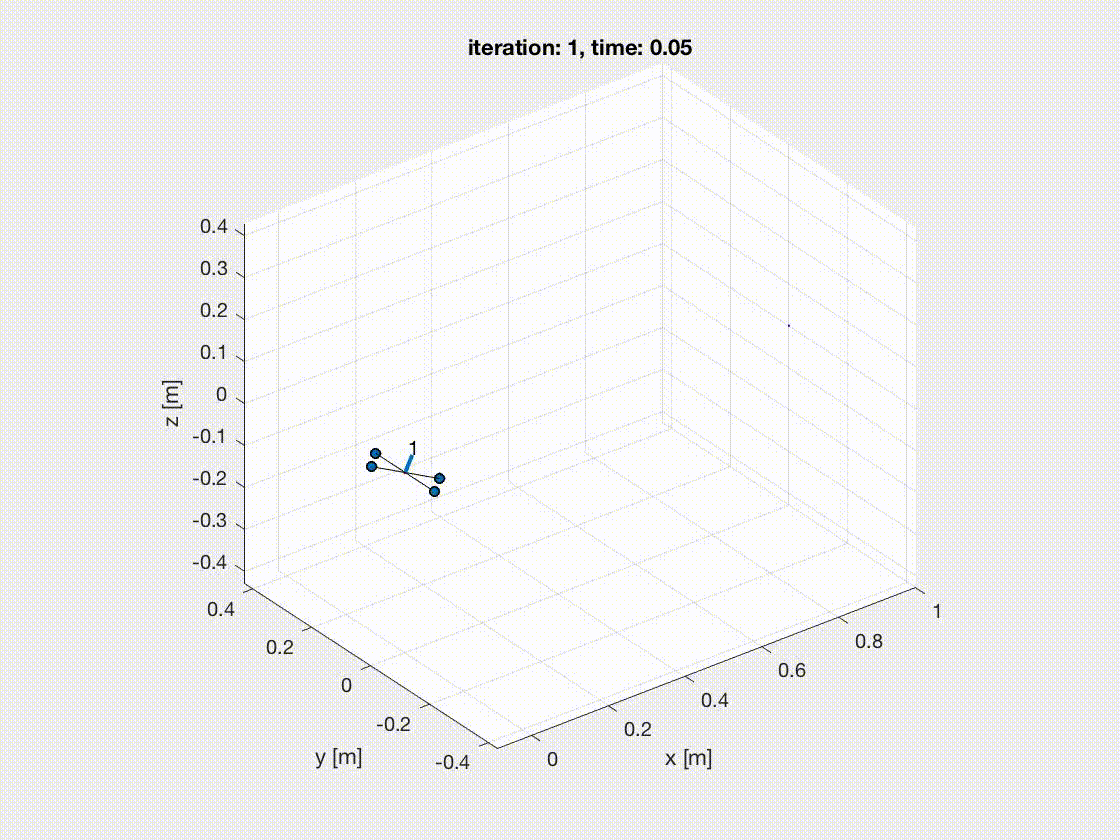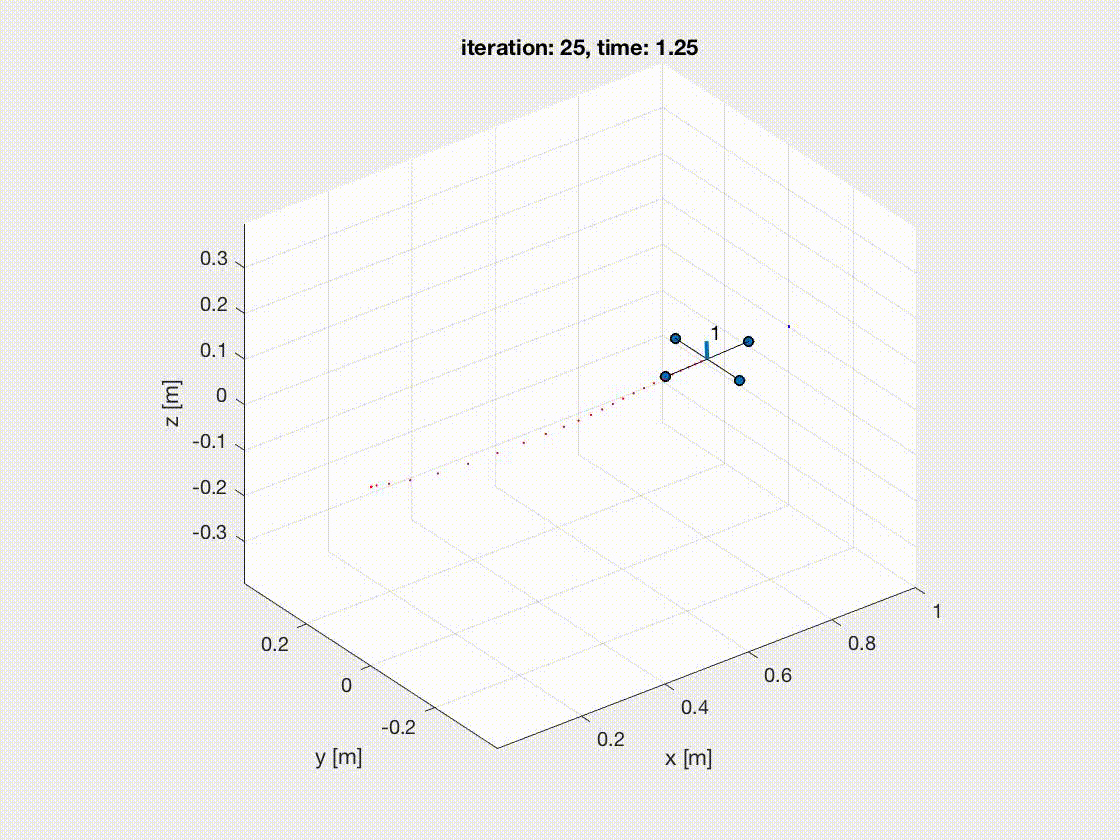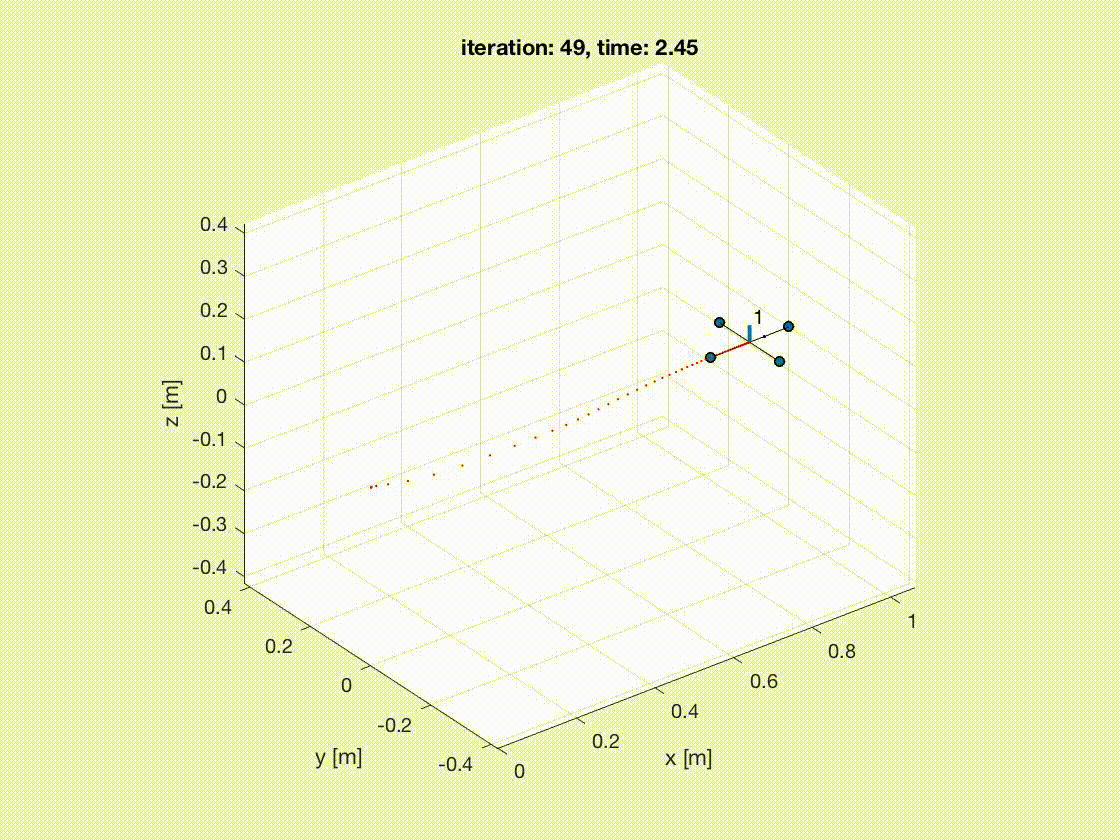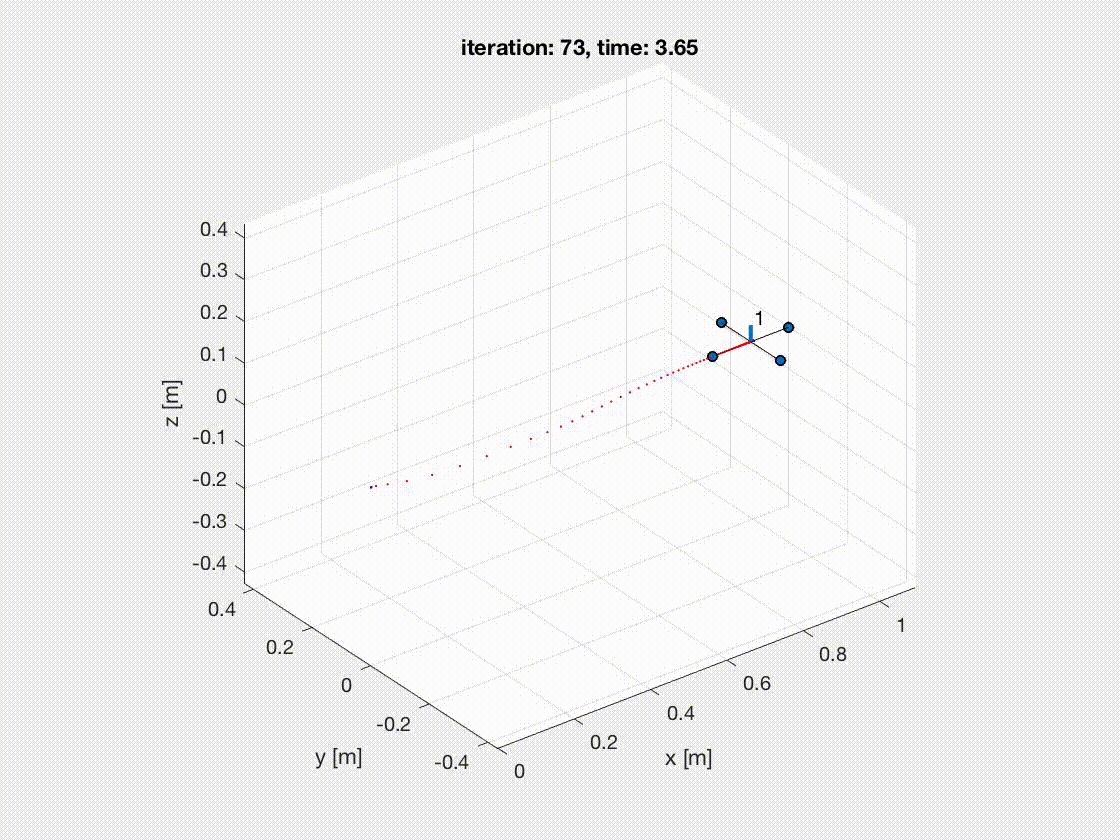
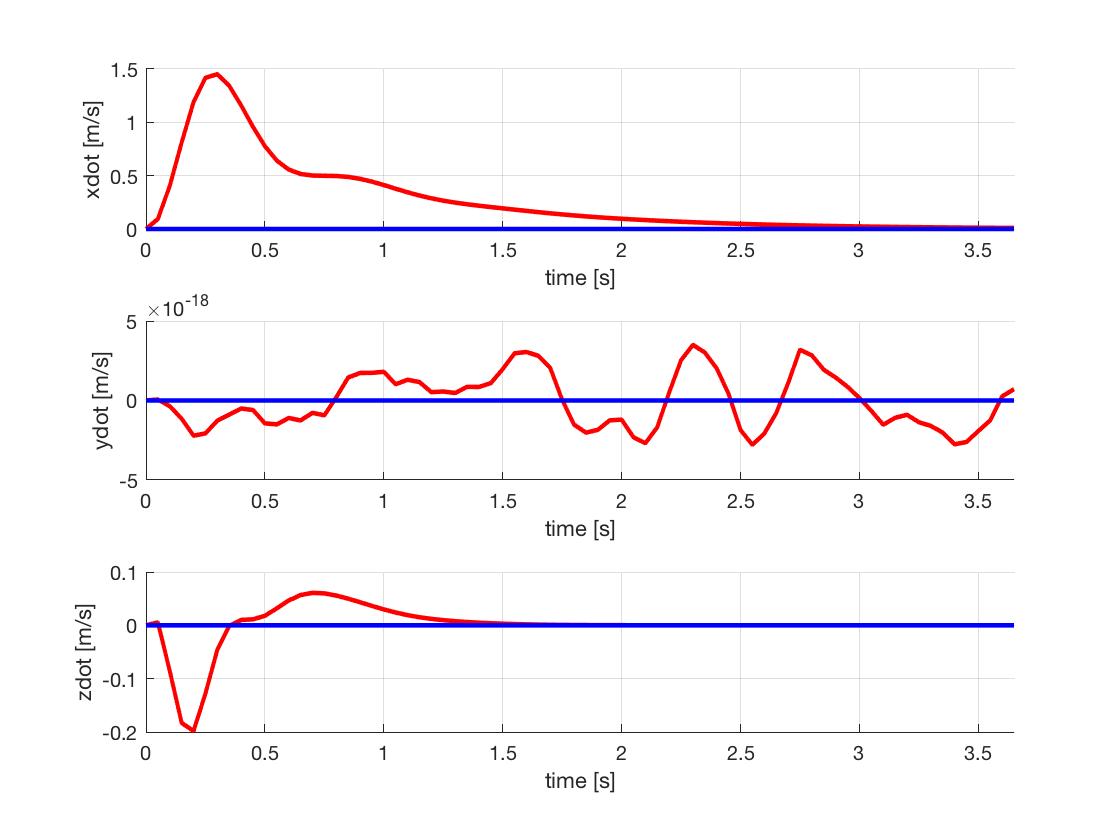
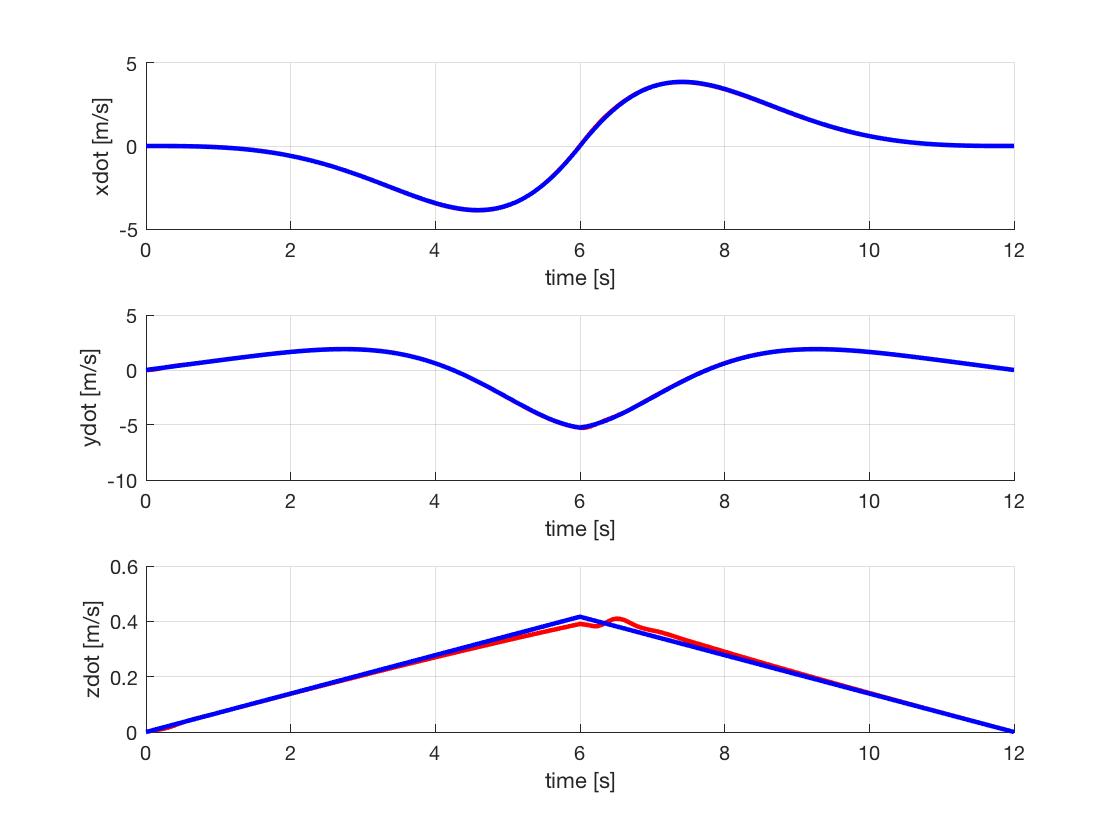
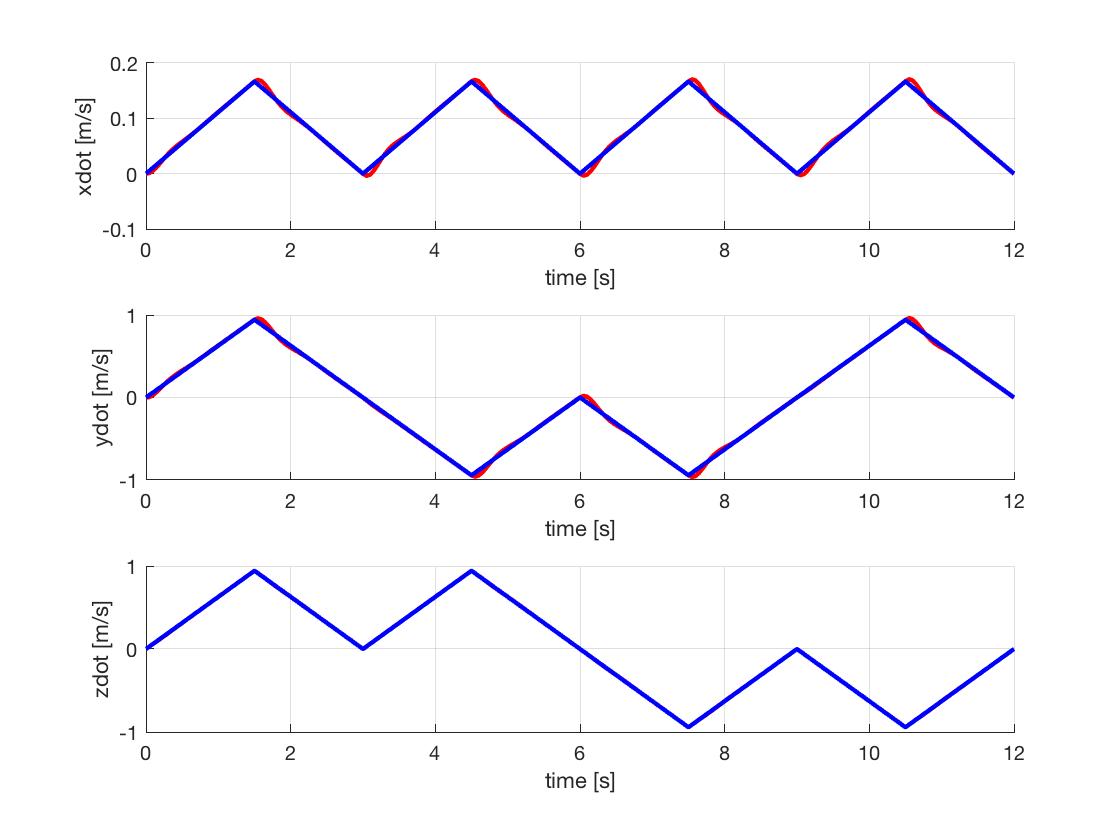
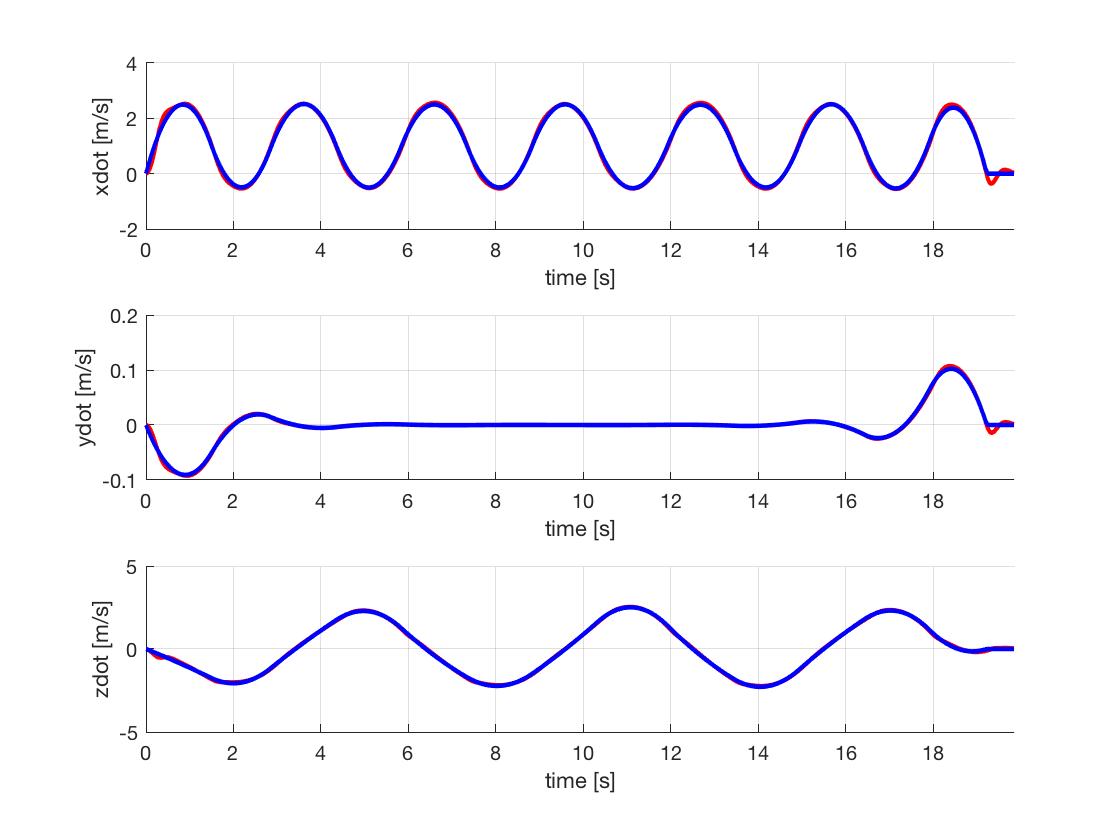
control/controller.mfor implementation of the PD controller. - Visualization below. Desired (blue) vs Actual (red)
Trajectory 1: Step

Trajectory 2: Circle


Trajectory 2: Diamond


Path Planning and Trajectory Optimization
- Run code:
traj_planning/runsim.mand run path 1 or path 3. - See project_report.pdf for more details about trajectory generation
- See
traj_planning/path_planning/dijkstra.mfor implementation of path finding algorithms (dijstra, A*). - See
traj_planning/traj_opt7.mfor implementations of minimium snap trajectory. - See
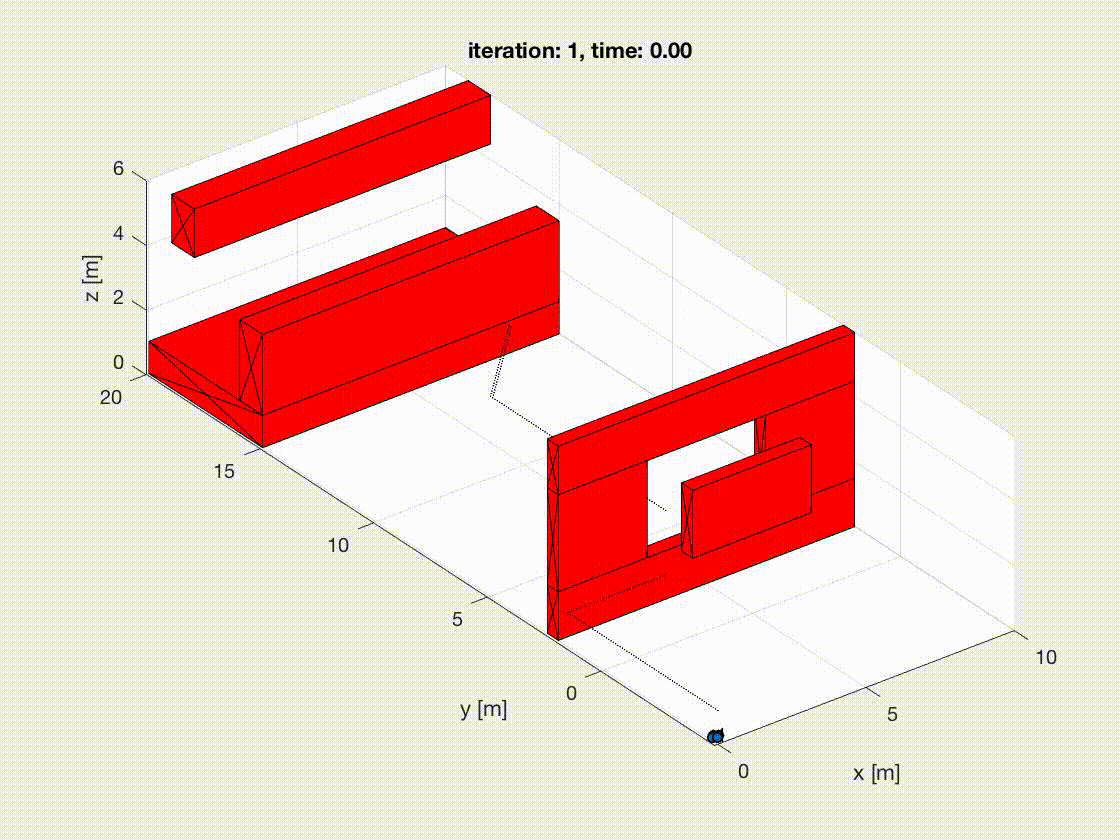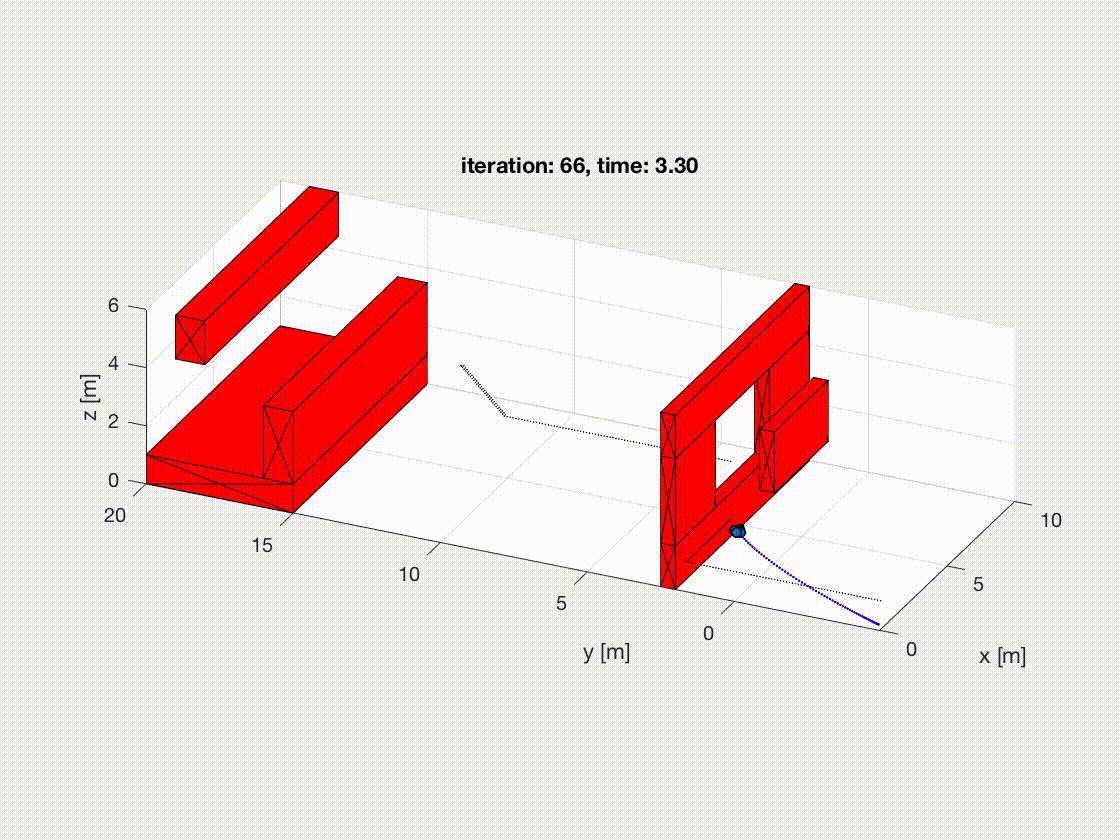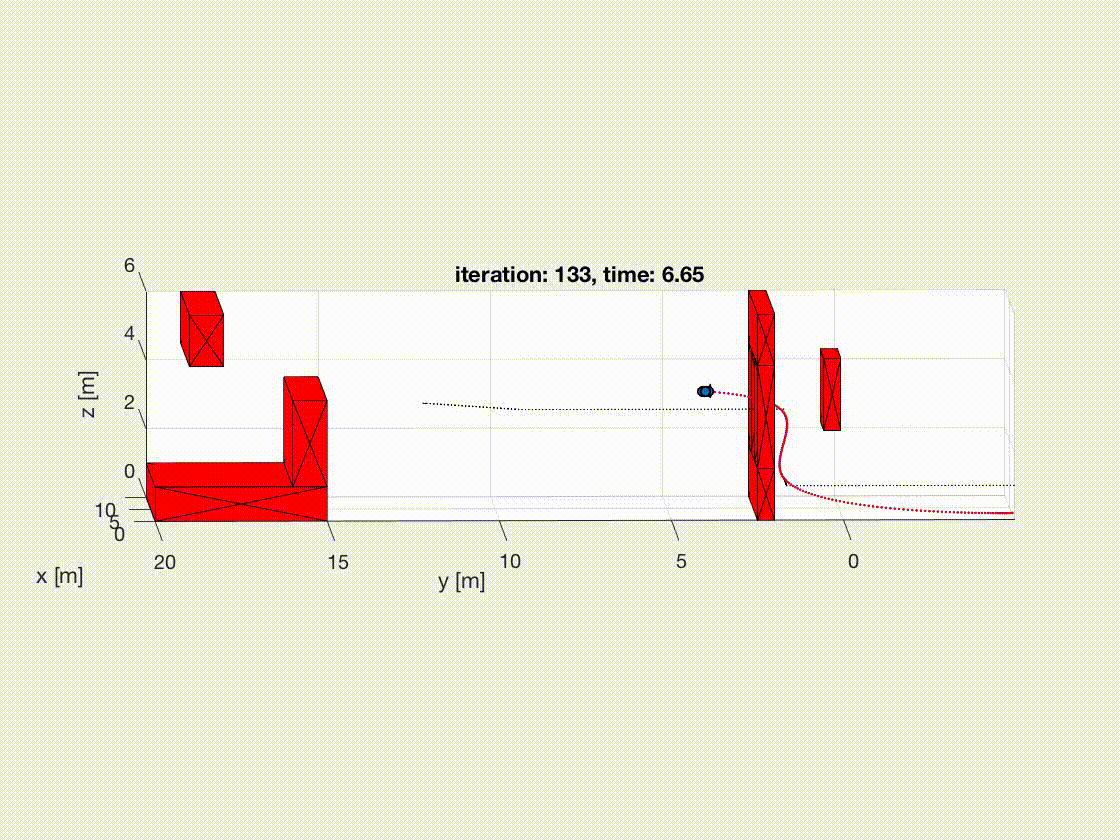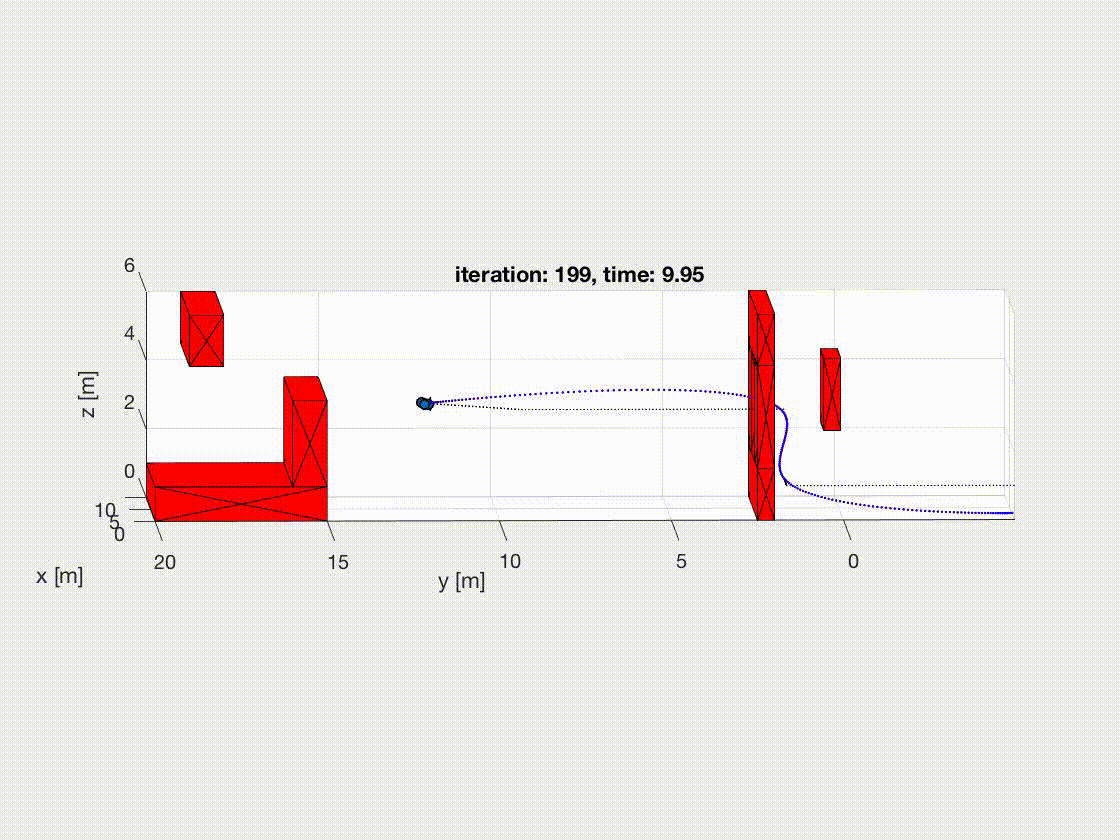
traj_planning/traj_opt5.mfor implementations of minimium acceleration trajectory. - Visualization below.
Minimum Acceleration Trajectory


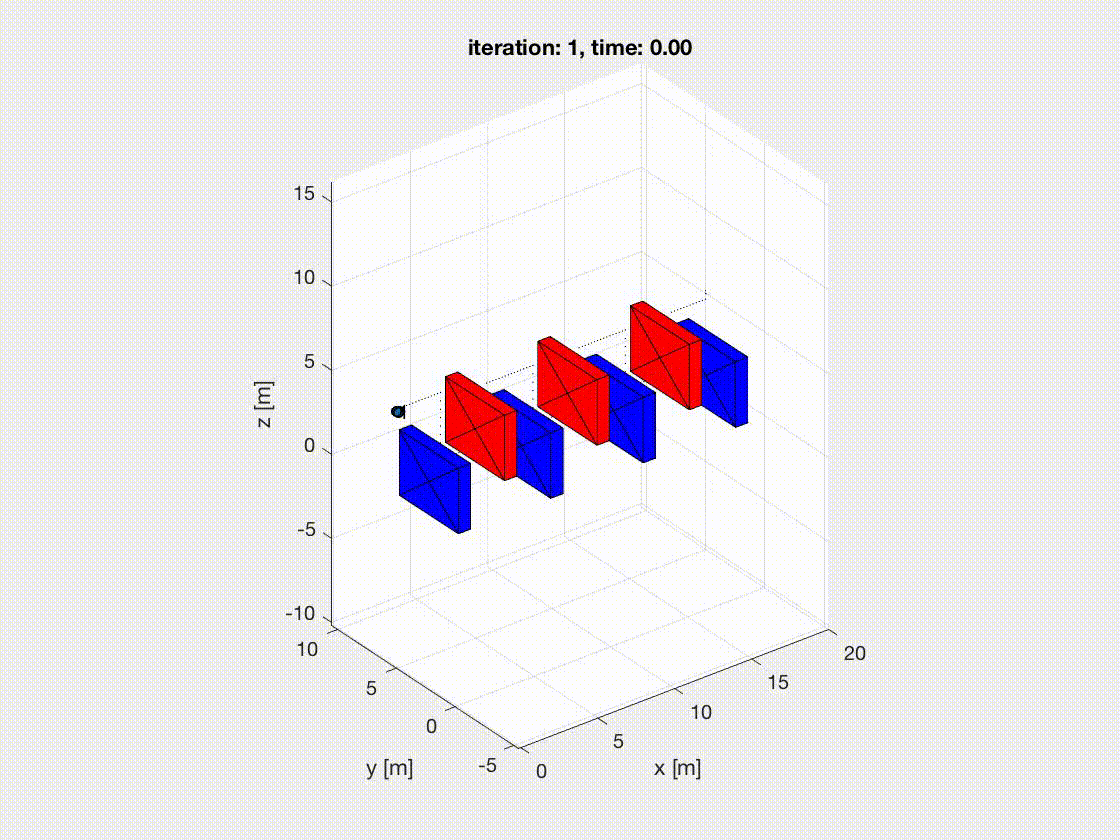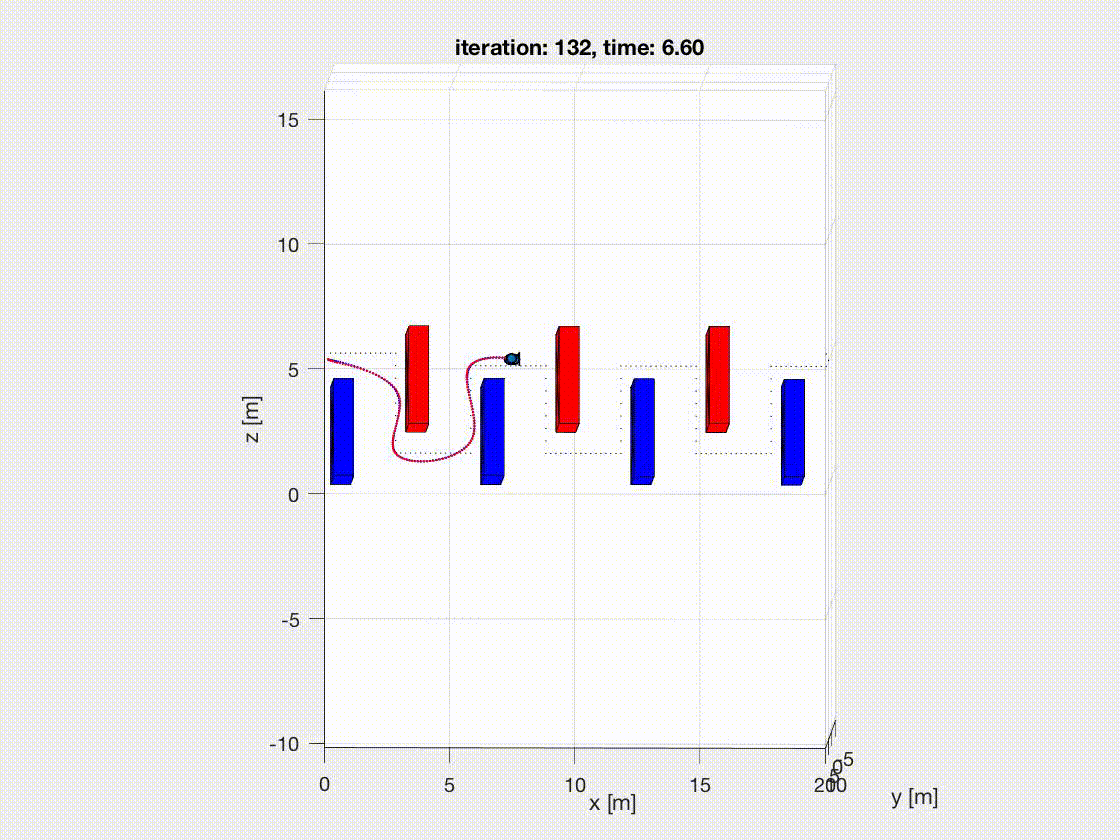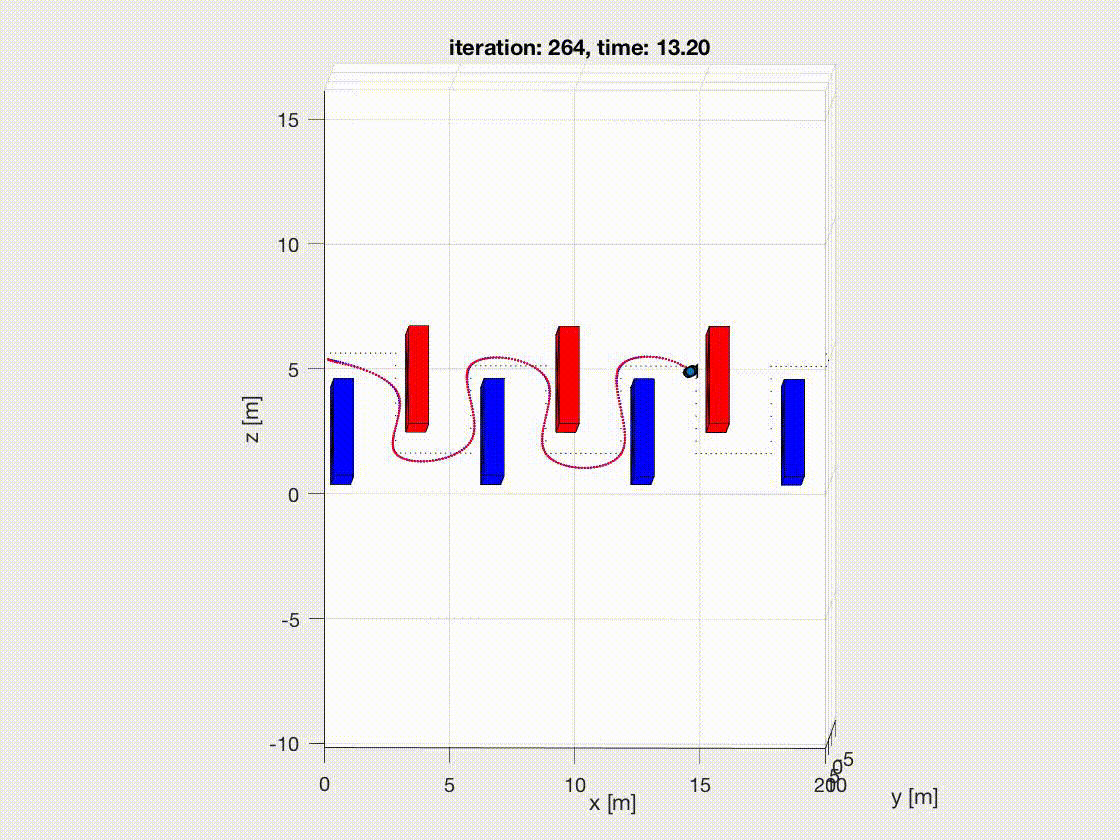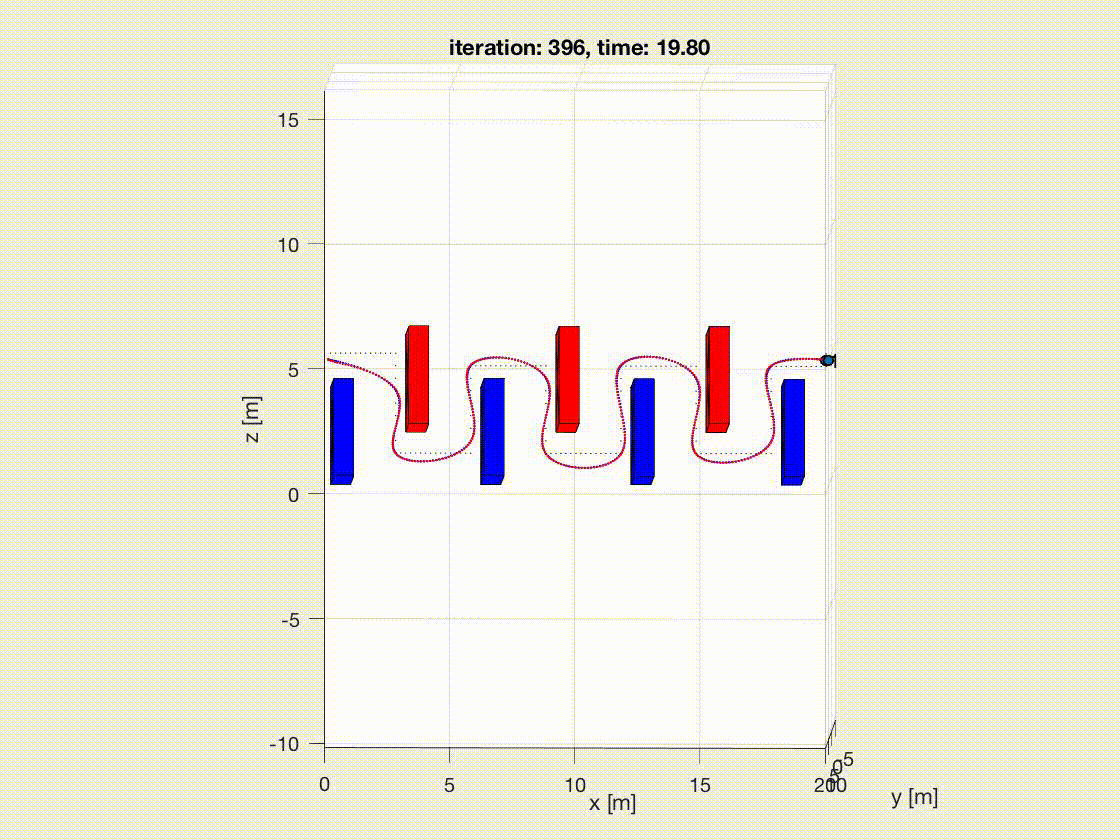

Minimum Snap Trajectory


(with way points constraints)


