项目 在 GitHub 查看
but0n/Avem
but0n/Avem has 2,943 GitHub stars and 584 forks. GitHot measured 0 stars in 24 hours, +4 in 7 days, and +7 in 15 days. Last checked 2026-11-19 15:58 UTC. Last push 2023-10-03.
实测星标增长
- 24小时
- 0
- 7天
- +4
- 15天
- +7
- 1个月
- 更新延迟
各周期内的星标净变化,周期相互重叠,并非每日新增。缺失的测量保持空白。星标代表关注度,不代表软件质量。
关于
🚁 轻量级无人机飞控-[Drone]-[STM32]-[PID]-[BLDC]
开发工具README.md
原文


Avem :bird:
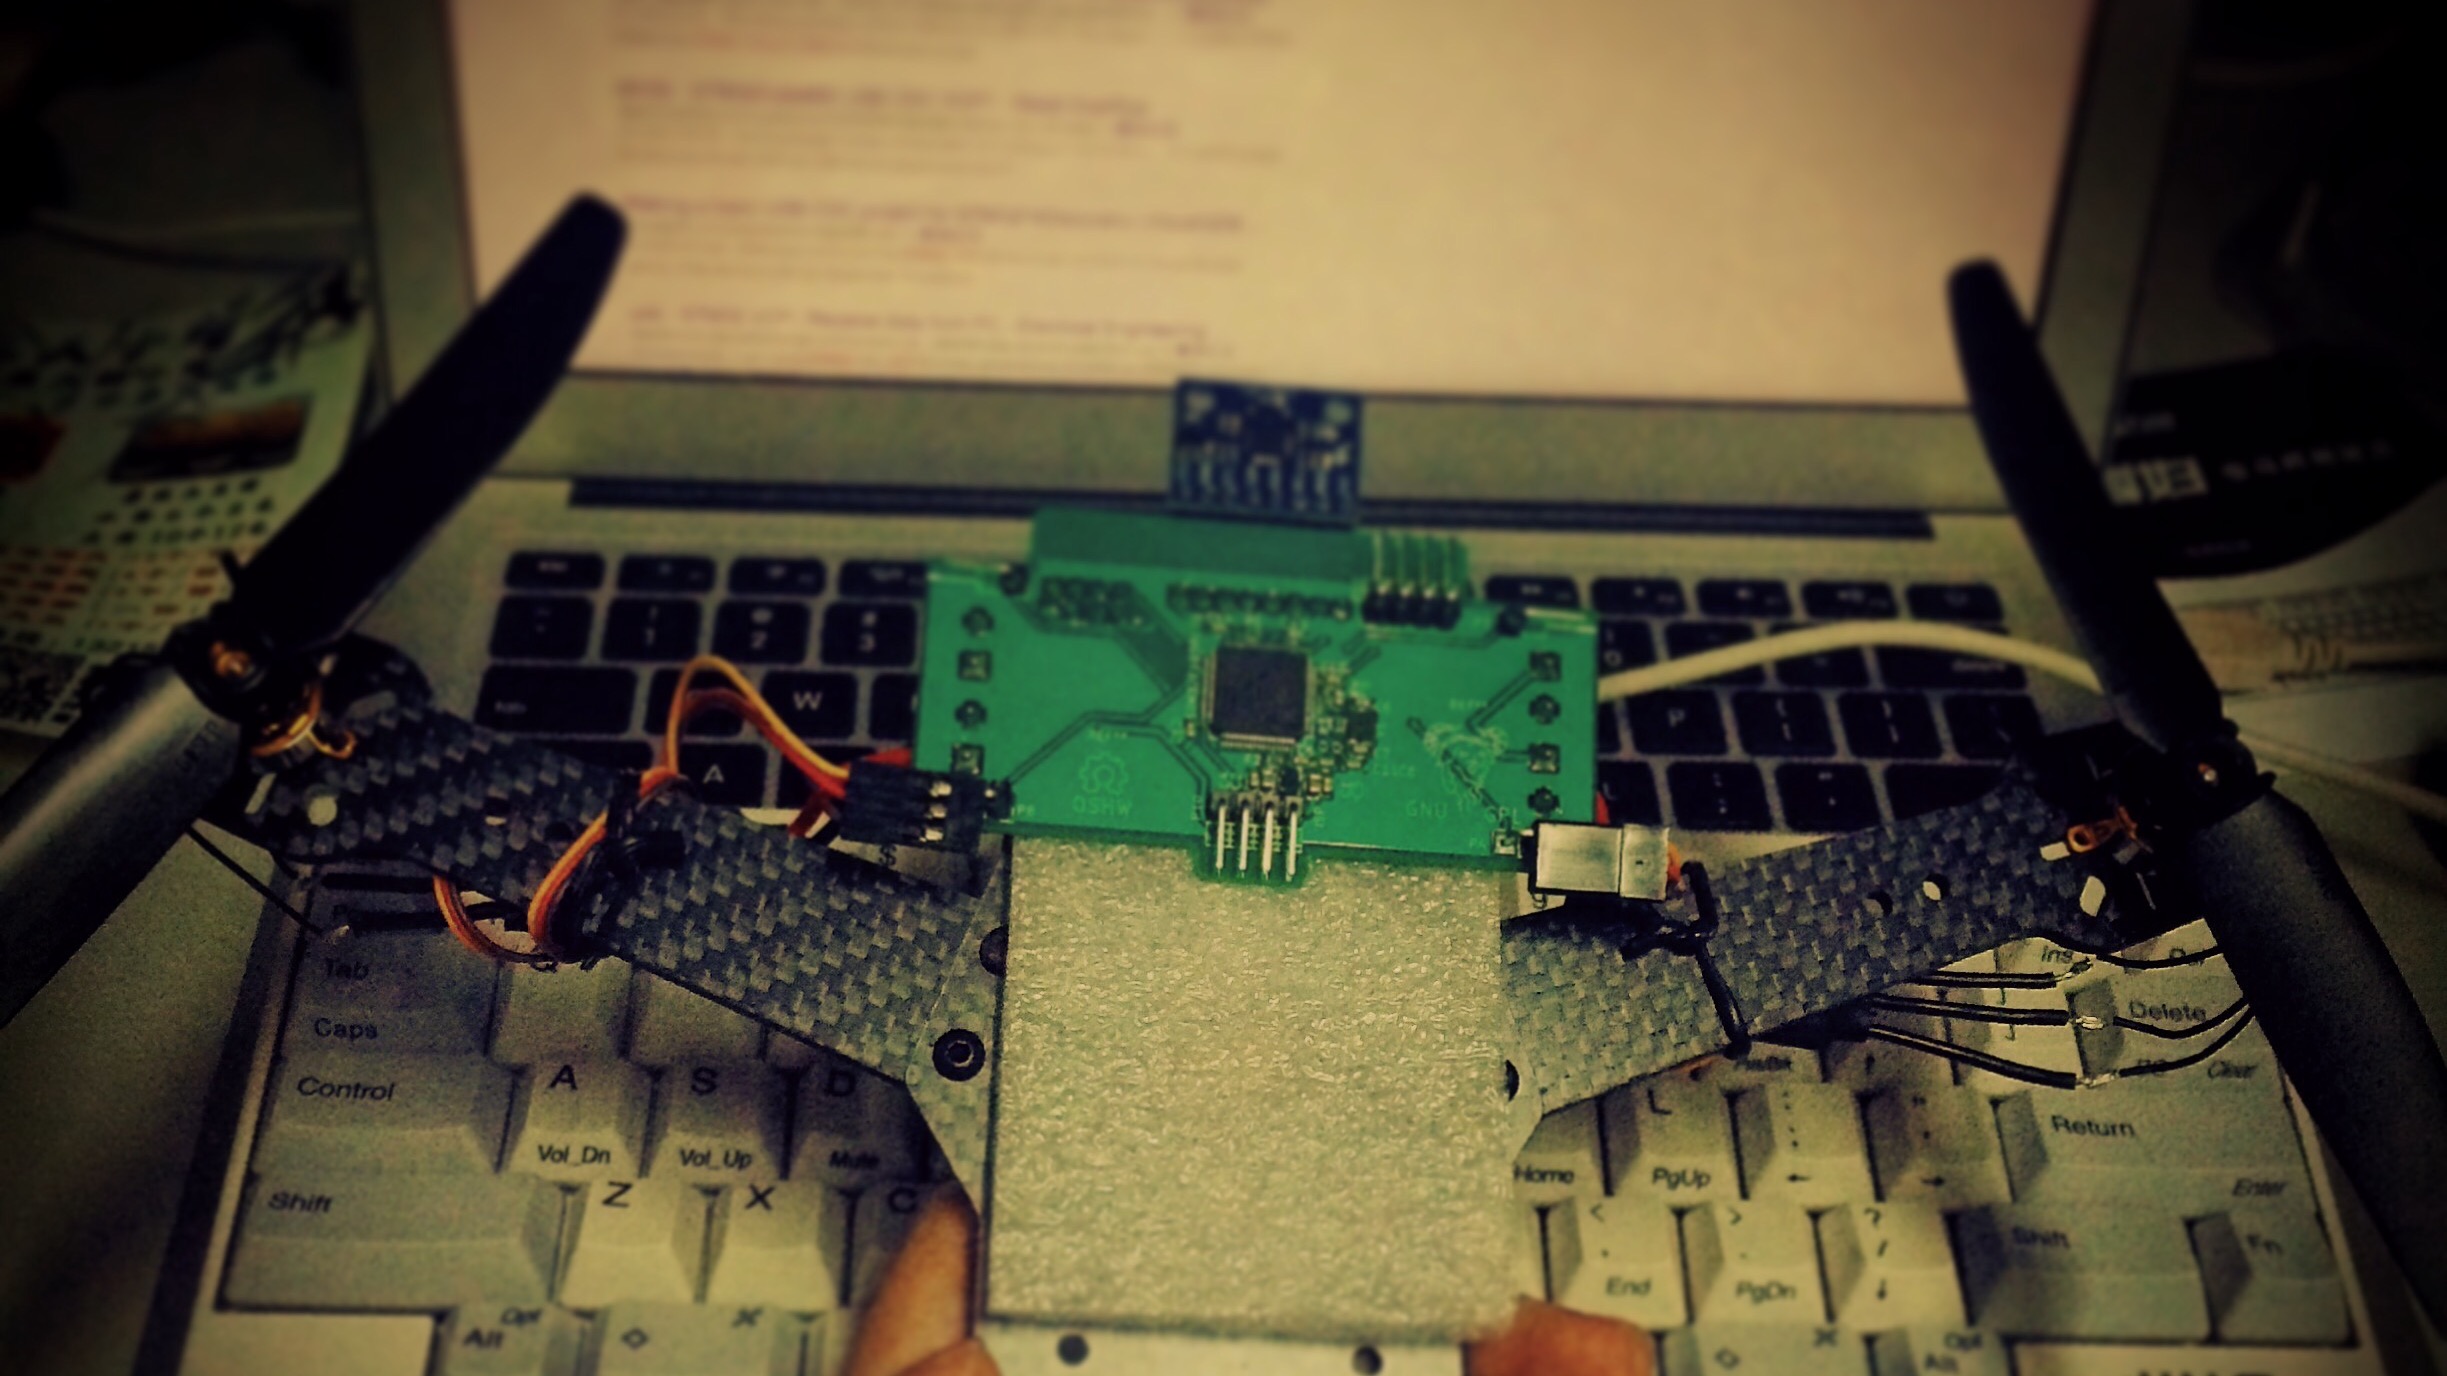
[UAV] - [STM32F103] - 6 Axes sensor MPU6050 - Quaternion & Euler Angles Compute - PID Controller
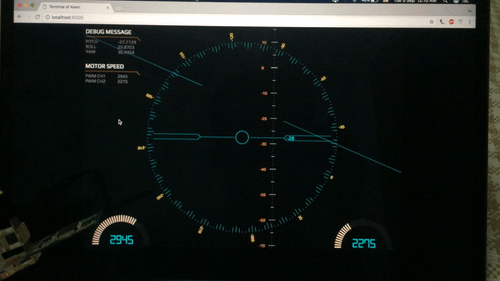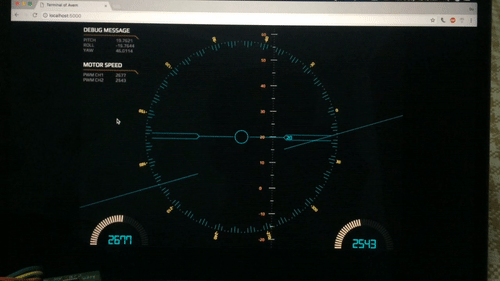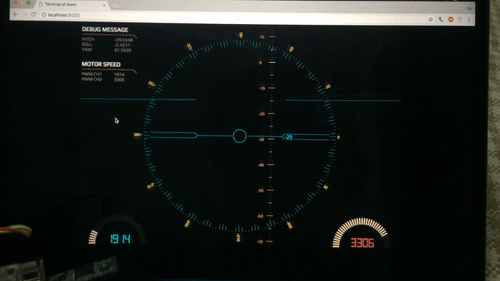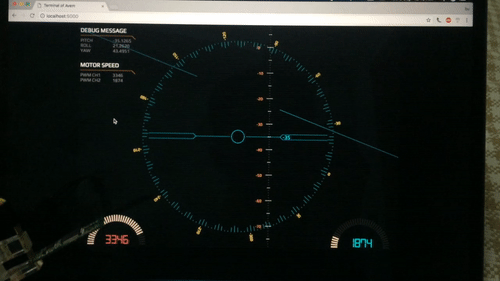
Terminal demo

https://github.com/but0n/Avem_HUD
I/O List
MPU6050 | BLDC | Wi-Fi | GPS
:----: |:----: |:----: |:---:
SCL PB15 |Channel 1 PA6|USART3_TX PB10 |TBD
SDA PB14 |Channel 2 PA7|USART3_RX PB11 |TBD
||Channel 3 PB0| | |
||Channel 4 PB1| | |
To-do list
- Software I2C
- Init MPU6050
- Get 3 axes
Gryoand 3 axesAcceldata from MPU6050 - Cumpute Quaternion and Euler Angles
- PWM output
- Driving motors with L9110S
- PID Control
- Schematic
- PCB Layout
- Brushless DC motor-Video via YouTube
- Wi-Fi(
ESP8266) - Cascade PID control
- FreeRTOS
- Host: Flask + pyserial
- PID debug
- GPS
Hardware

Schematic

PCB Layout
Version 3.0

Made with ♥ by but0n