
zhm-real/MotionPlanning
zhm-real/MotionPlanning has 2,763 GitHub stars and 640 forks. GitHot measured +1 stars in 24 hours. Last checked 2026-11-06 20:38 UTC. Last push 2024-01-13.
Motion planning algorithms commonly used on autonomous vehicles. (path planning + path tracking)
Measured star growth
- in 24h
- +1
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.md
OriginalOverview
This repository implemented some common motion planners used on autonomous vehicles, including
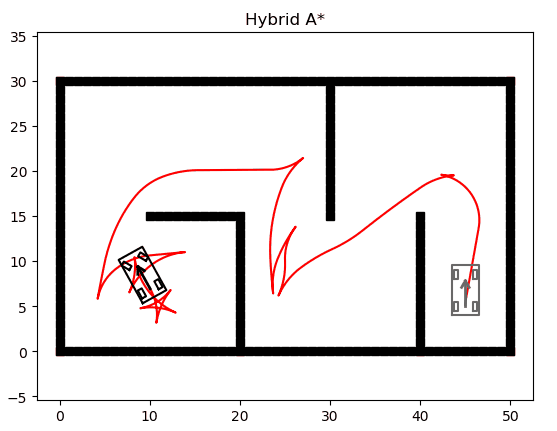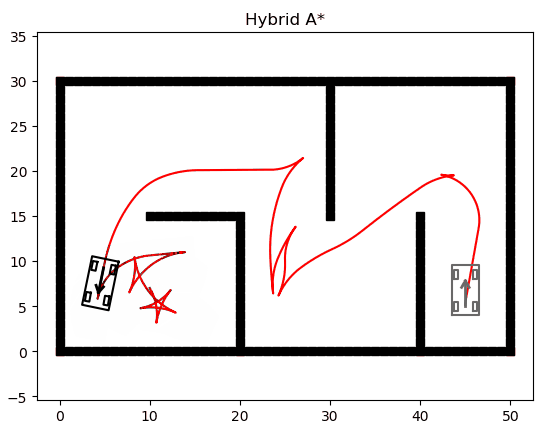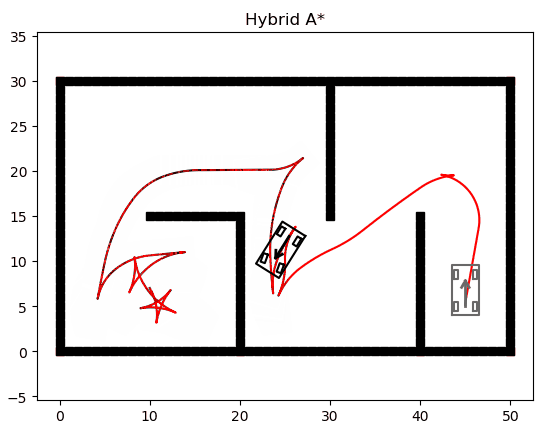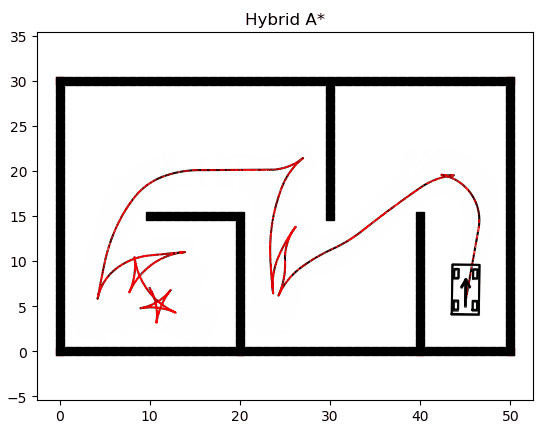
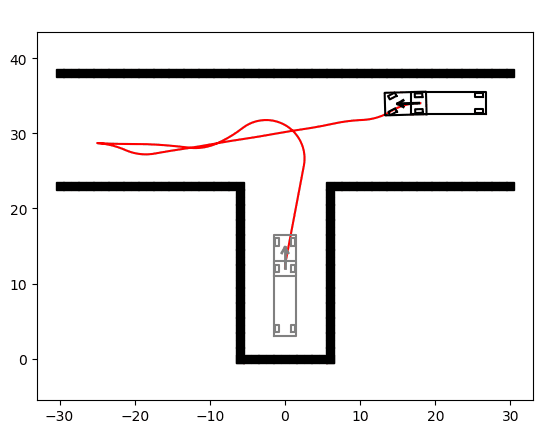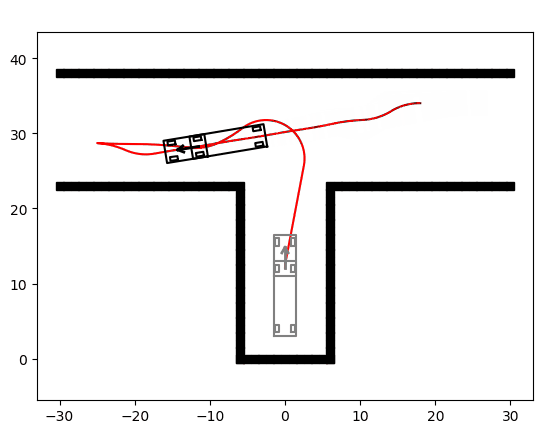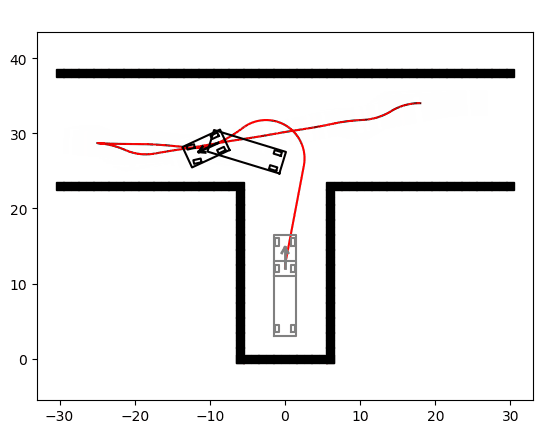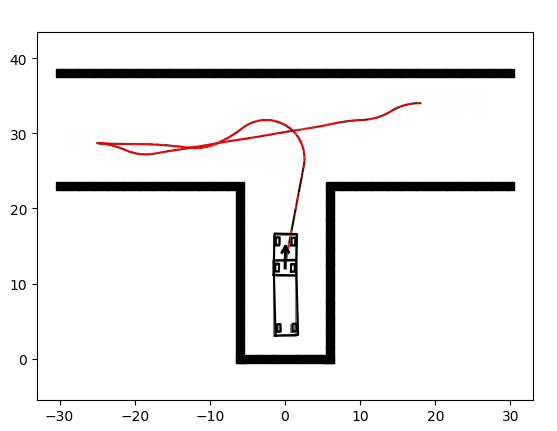
- Hybrid A* Planner
- Frenet Optimal Trajectory
- Hierarchical Optimization-Based Collision Avoidance (H-OBCA) (Incomplete)
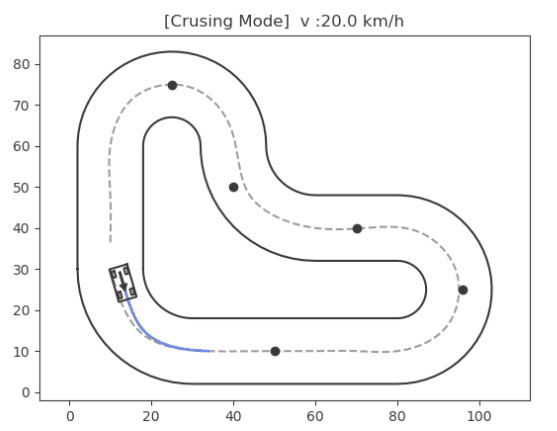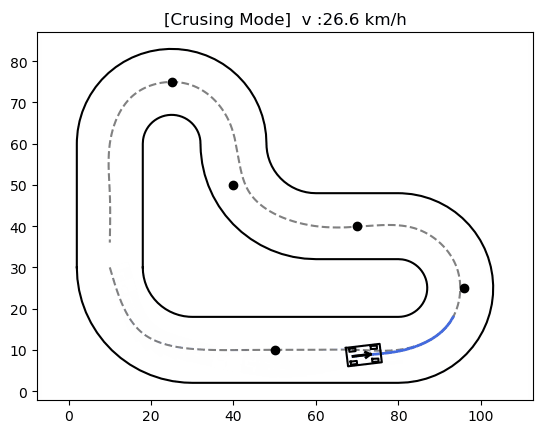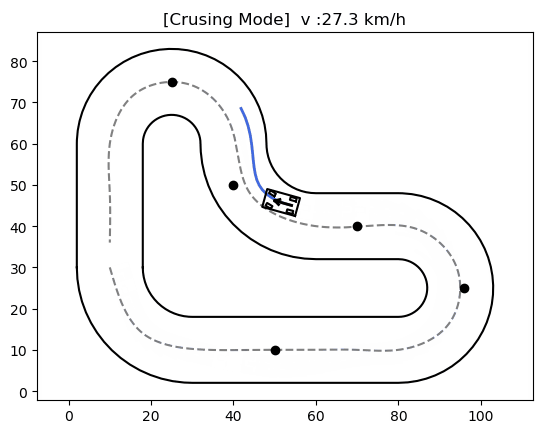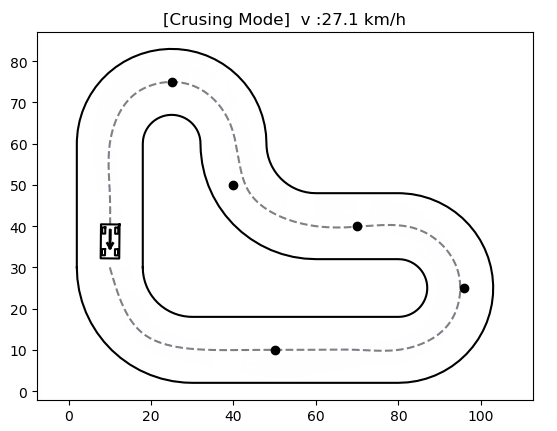
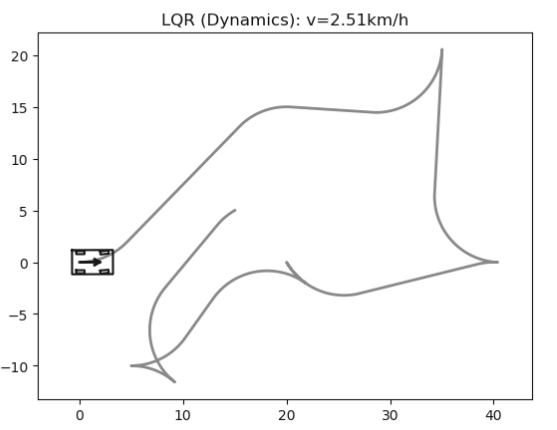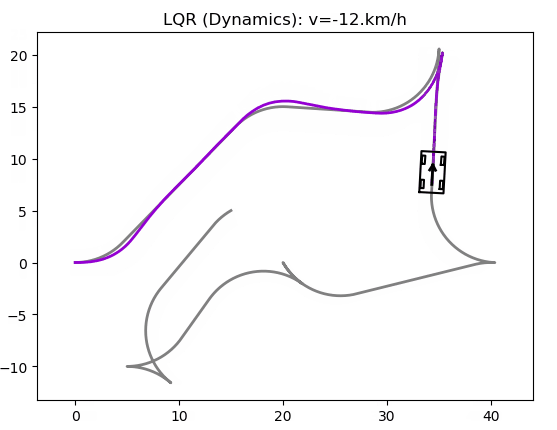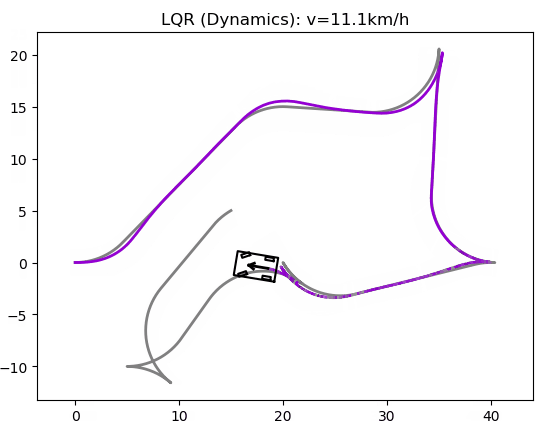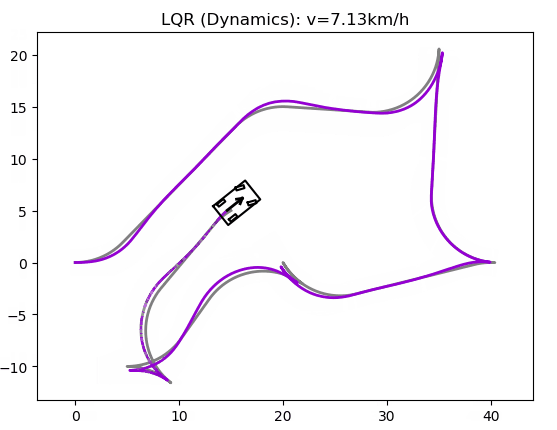
Also, this repository provides some controllers for path tracking, including
- Pure Pursuit + PID
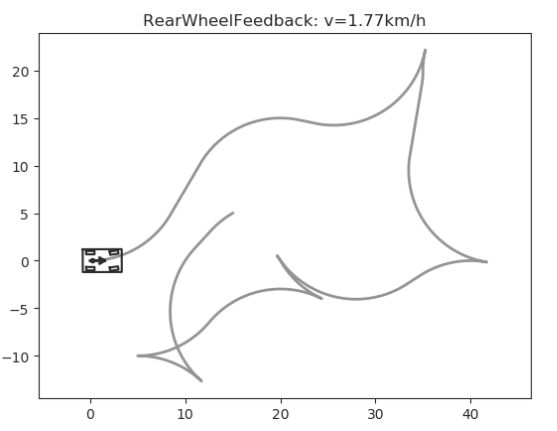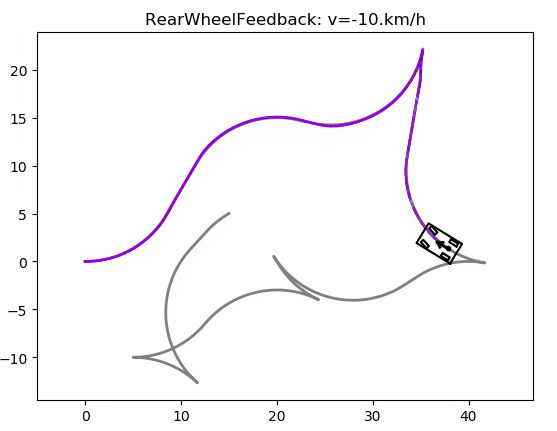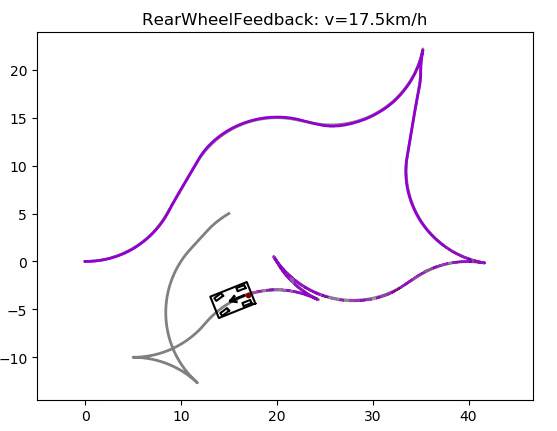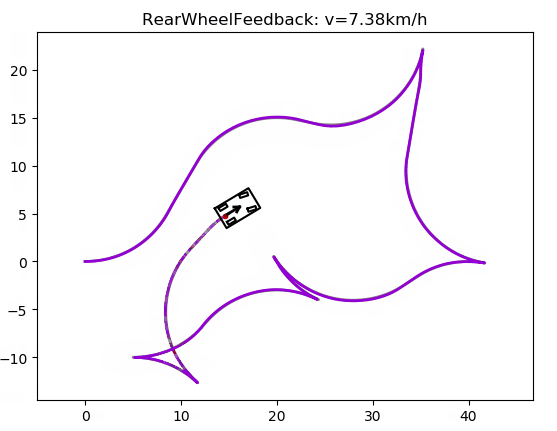
- Rear-Wheel Feedback + PID
- Front-Wheel Feedback / Stanley + PID
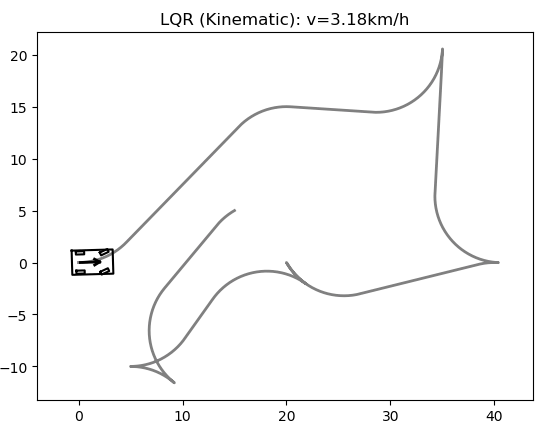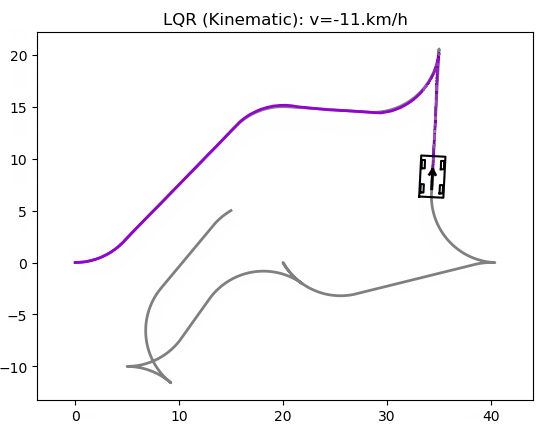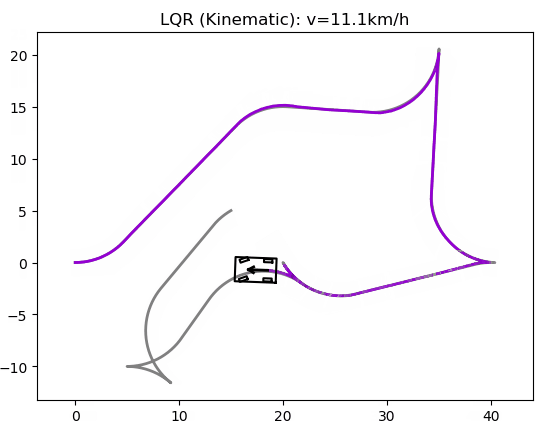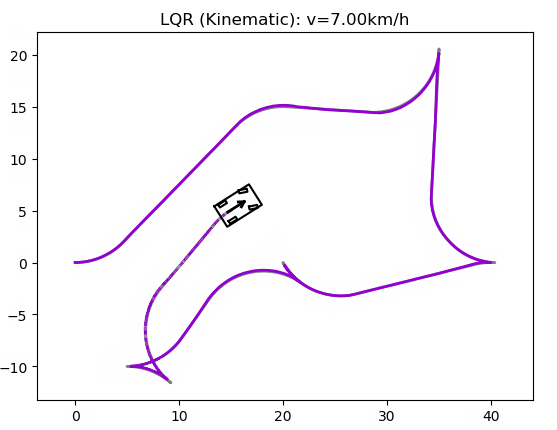
- LQR + PID
- Linear MPC
Requirement
- Python 3.6 or above
- SciPy
- cvxpy
- Reeds-Shepp Curves
- pycubicspline
Vehicle models
This repository uses two models: simple car model and car pulling trailers model.
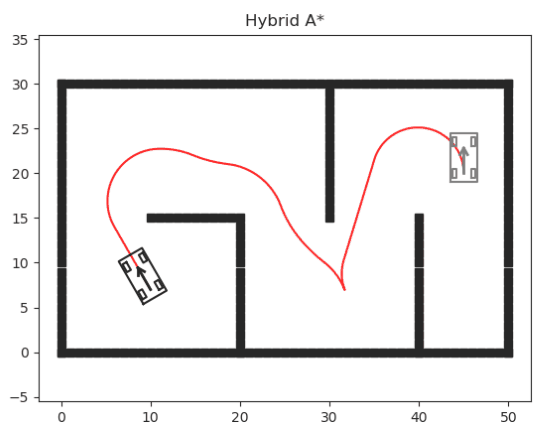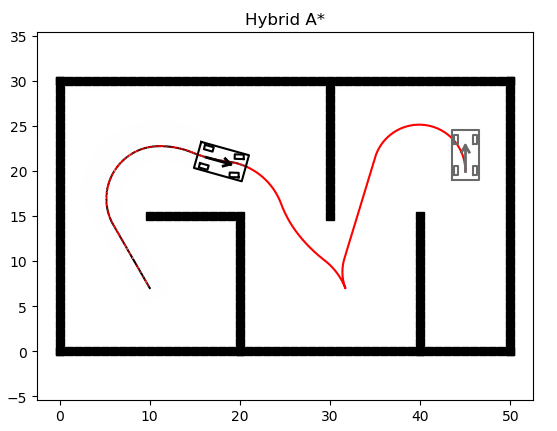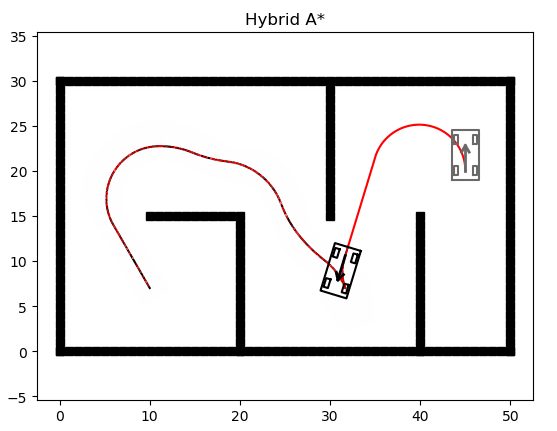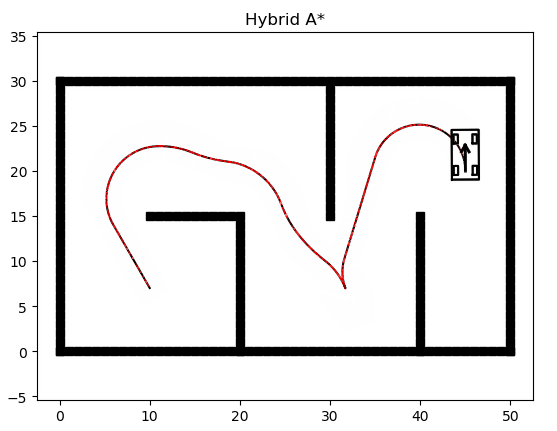
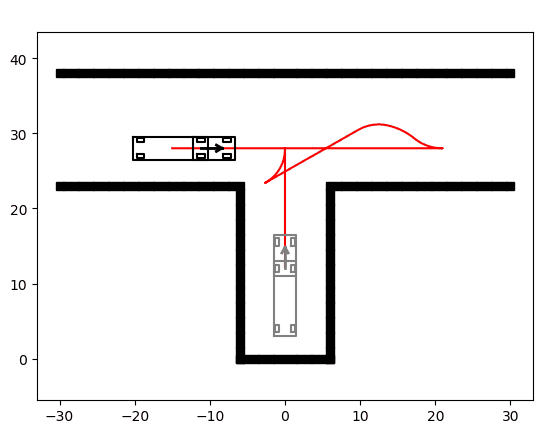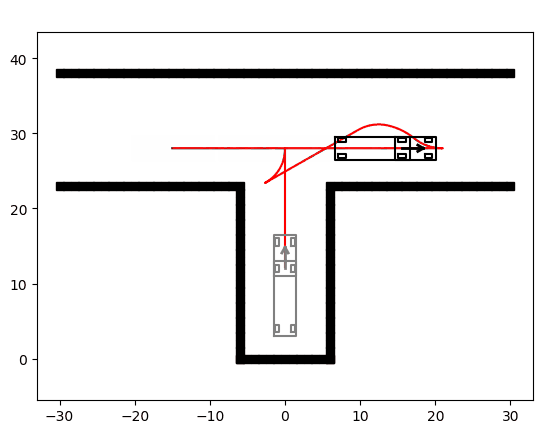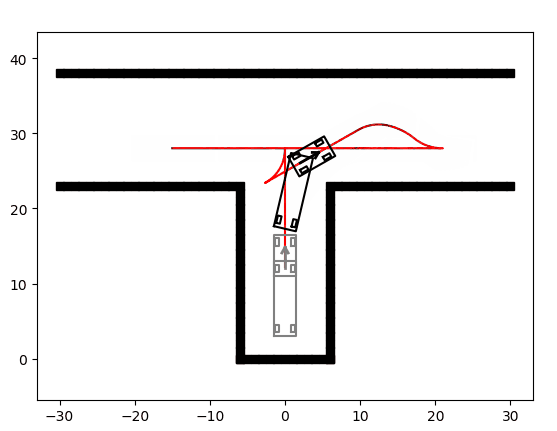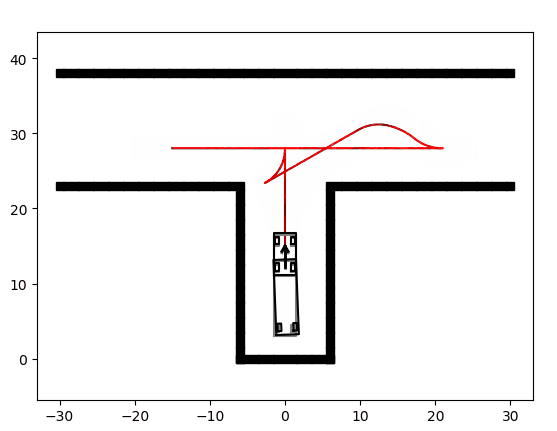
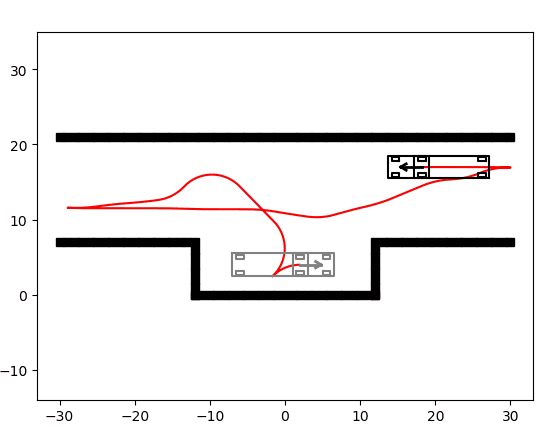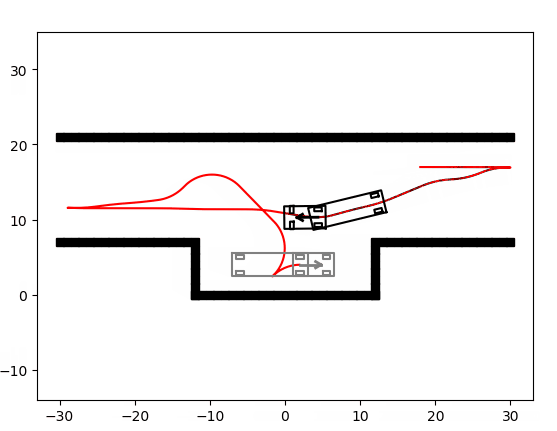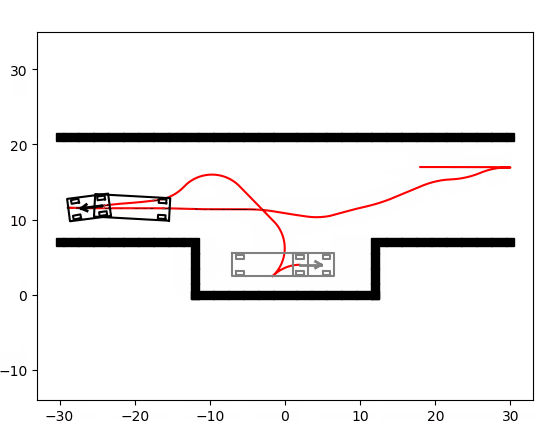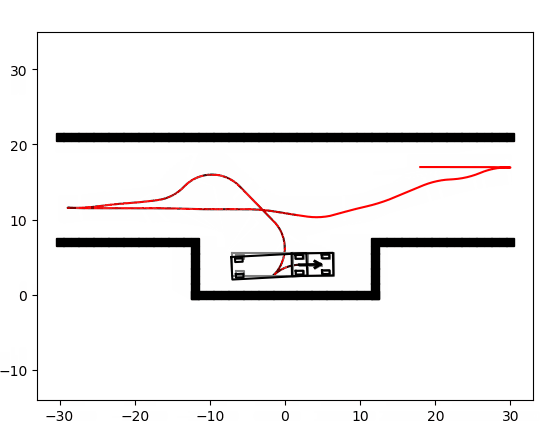
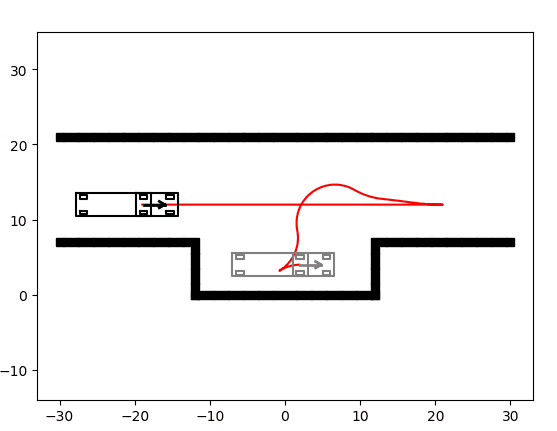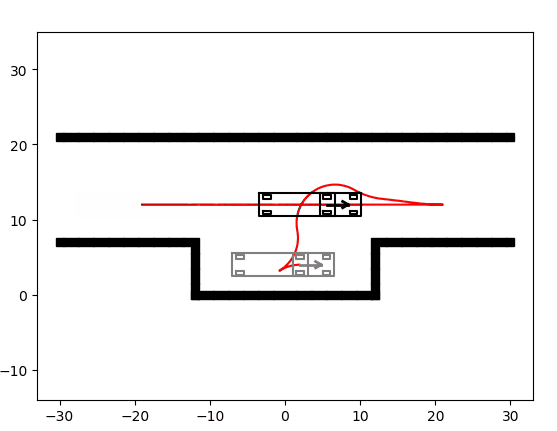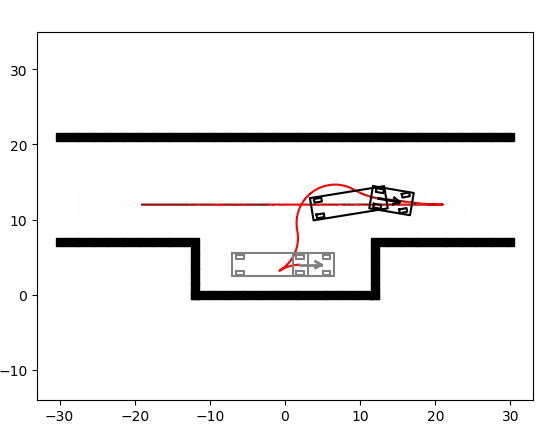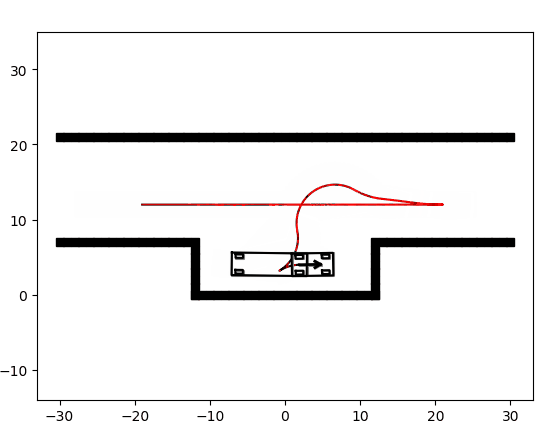
Hybrid A* Planner
 |
 |
 |
 |
 |
 |
State Lattice Planner
 |
 |
Controllers
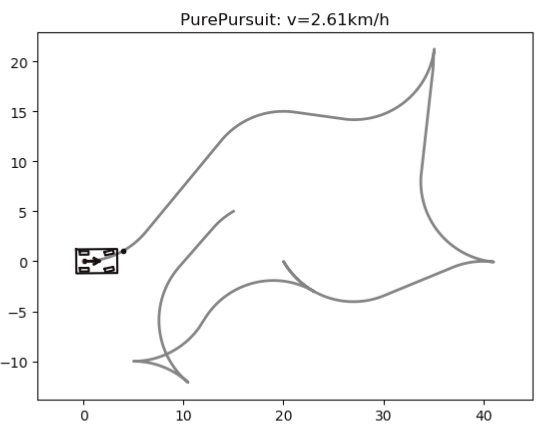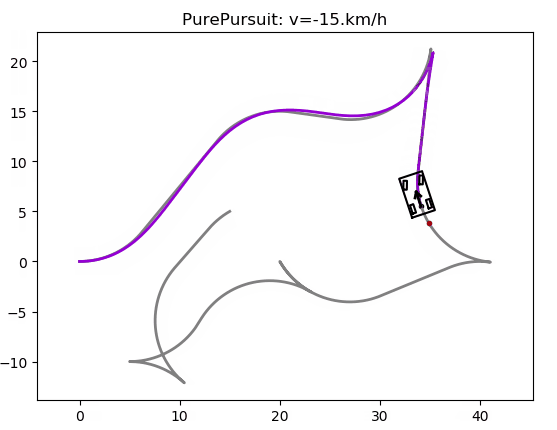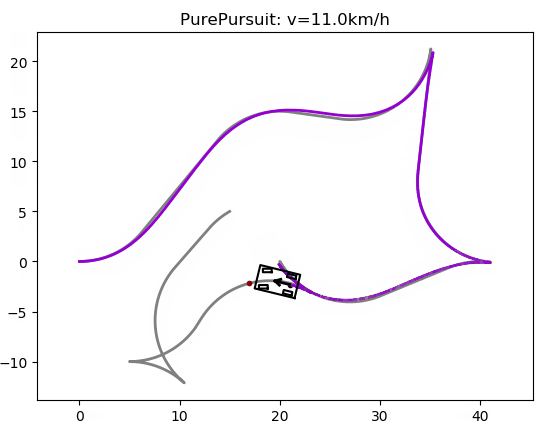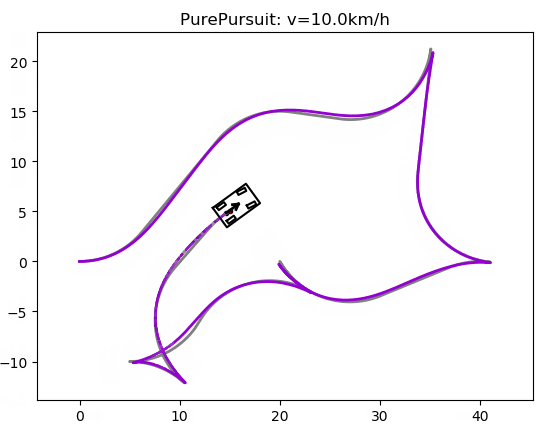 |
 |
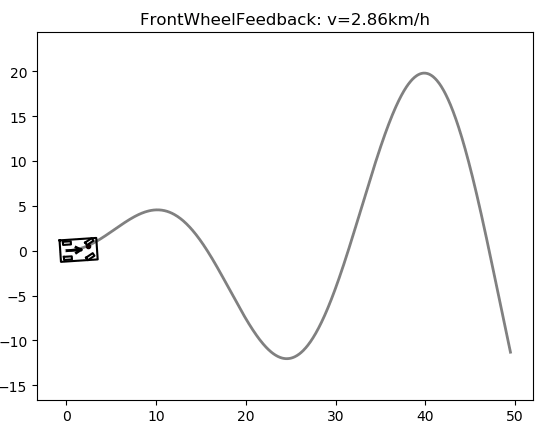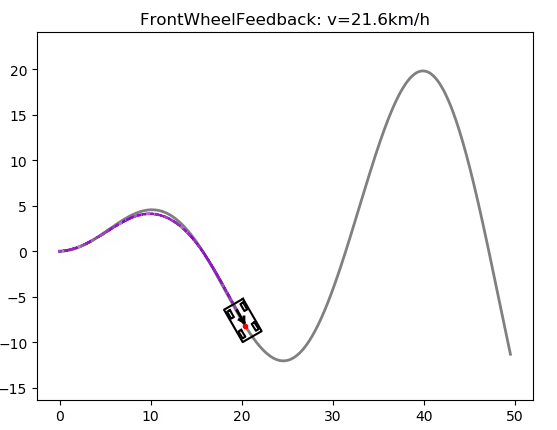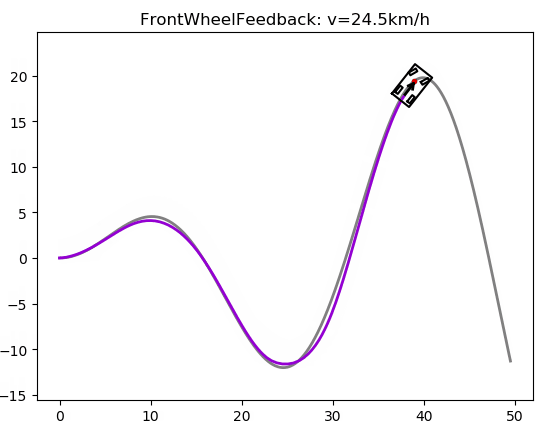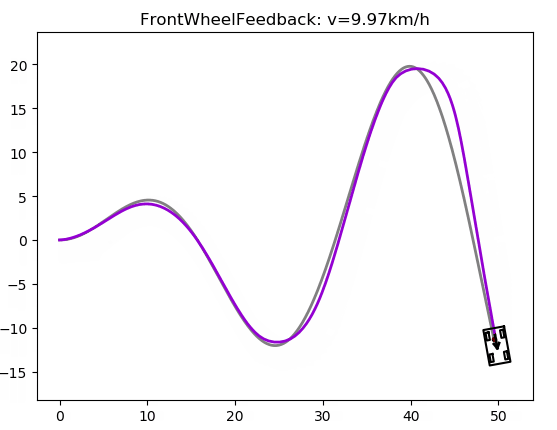 |
 |
 |
 |
Paper
Planning
- Basic Path Planning Algorithms: PathPlanning
- Baidu Apollo Planning module: Recommended Materials
- Survey of Planning and Control algos: A Survey of Motion Planning and Control Techniques for Self-driving Urban Vehicles
- Hybrid A* Planner: Practical Search Techniques in Path Planning for Autonomous Driving
- Frenet Optimal Trajectory: Optimal Trajectory Generation for Dynamic Street Scenarios in a Frenet Frame
Control
- Baidu Apollo Control module: Recommended Materials
- Pure Pursuit: Implementation of the Pure Pursuit Path Tracking Algorithm
- Rear-Wheel Feedback: Automatic Steering Methods for Autonomous Automobile Path Tracking
- Front-Wheel Feedback / Stanley: Stanley: The Robot that Won the DARPA Grand Challenge
- LQR: ApolloAuto/apollo: An open autonomous driving platform
- Linear MPC: MPC-Based Approach to Active Steering for Autonomous Vehicle Systems
Useful Material
- HybridAStarTrailer (Julia): by AtsushiSakai
- Hybrid Path Planner (C++): by KTH Research Concept Vehicle
Explore related projects
codecrafters-io/build-your-own-x
Master programming by recreating your favorite technologies from scratch.
560,417 starspublic-apis/public-apis
A collective list of free APIs
496,752 starsmorluto/rea
Reverse engineer anything with agents, from app behavior down to native binaries.
437,885 starsopenclaw/openclaw
The AI that really does things. Any OS. Any Platform. The lobster way. 🦞
394,065 stars