
snt-arg/visual_sgraphs
snt-arg/visual_sgraphs has 83 GitHub stars and 9 forks. GitHot measured 0 stars in 24 hours and 0 in 7 days. Last checked 2026-11-15 06:55 UTC. Last push 2026-10-09.
Measured star growth
- in 24h
- 0
- in 7 days
- 0
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
About
🚀 [RA-L 2026] vision-driven Situational Graphs (vS-Graphs)
Developer ToolsREADME.md
OriginalVisual S-Graphs (vS-Graphs)
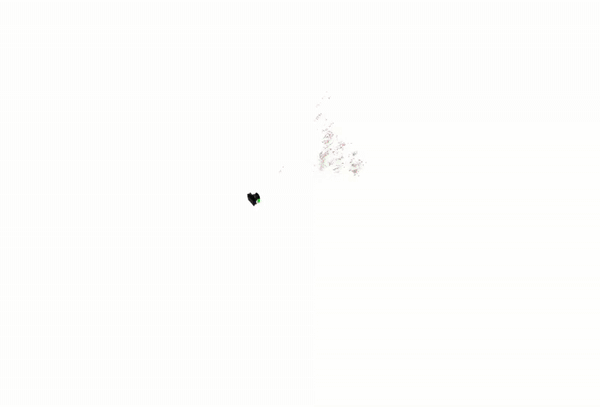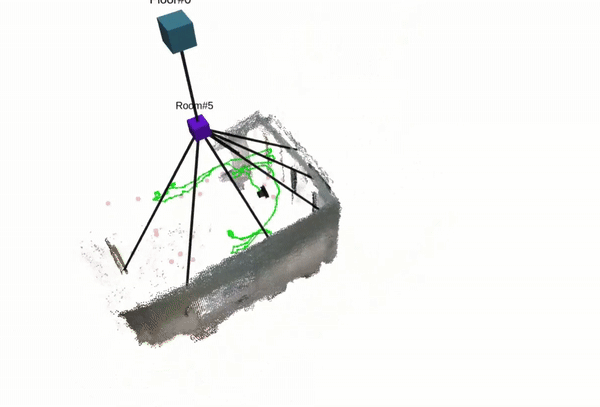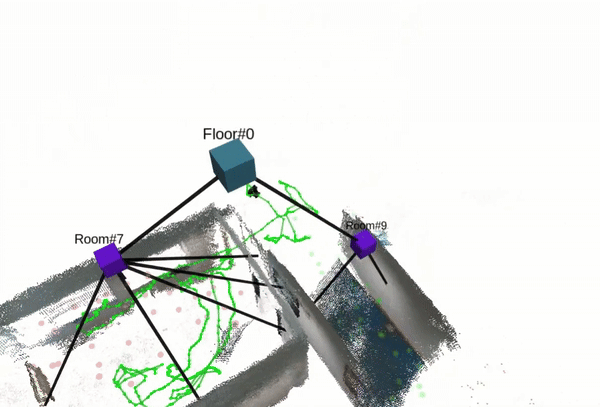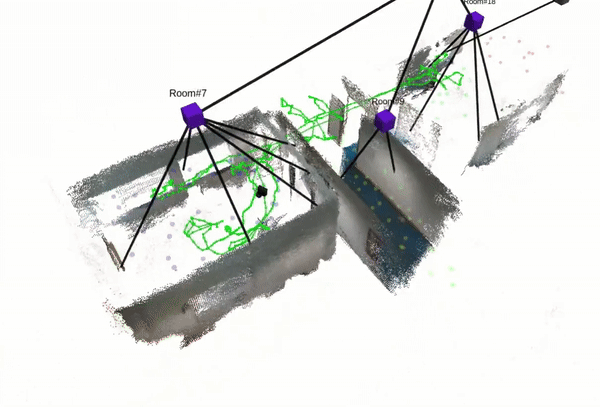


vS-Graphs is inspired by LiDAR S-Graphs and extends ORB-SLAM 3.0 by integrating optimizable 3D scene graphs, enhancing mapping and localization accuracy through scene understanding. It improves scene representation by incorporating building components (i.e., wall and ground surfaces) and inferring structural elements (i.e., rooms and corridors), making SLAM more robust and efficient.
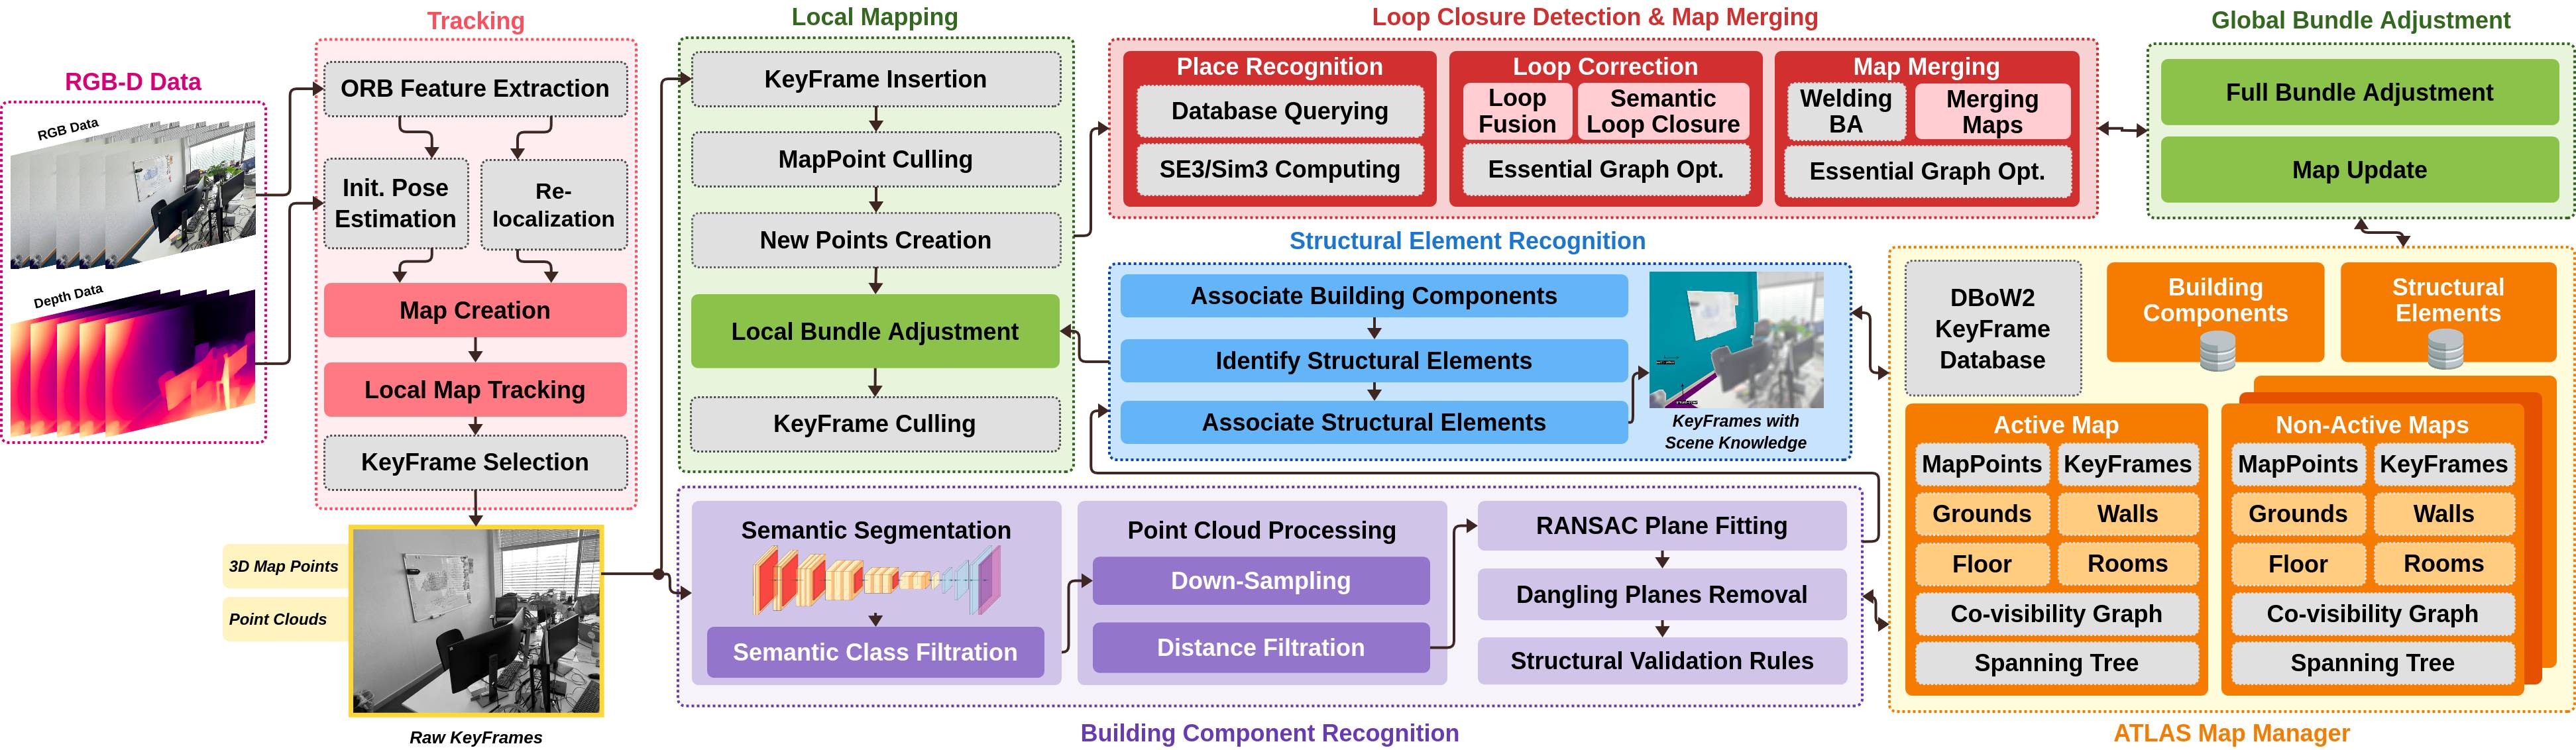
🧠 vS-Graphs Architecture
The diagram below shows the detailed architecture of the vS-Graphs framework, highlighting the key threads and their interactions. Modules with a light gray background are inherited directly from the baseline (ORB-SLAM 3.0), while the remaining components are newly added or modified components.
⚙️ Prerequisites and Installation
For system requirements, dependencies, and setup instructions, please refer to the Installation Guide.
🔨 Configurations
You can read about the SLAM-related configuration parameters (independent of the ROS2 wrapper) in the config folder. These configurations can be modified in the system_params.yaml file. For more information on ROS-related configurations and usage, see the ROS parameter documentation page.
🚀 Getting Started
Once you have installed the required dependencies and configured the parameters, you are ready to run vS-Graphs! Follow the steps below to get started:
Source vS-Graphs and run it by
ros2 launch vs_graphs rgbd.launch.pyfor RGB-D version (orrgbd-imu.launch.pyfor RGB-D-Inertial). It will automatically run the vS-Graphs core and the semantic segmentation module for building component (walls and ground surfaces) recognition.(Optional) If you intend to detect structural elements (rooms, corridors, and floors) too, check the Voxblox Integration procedure in the Installation Guide.
(Optional) If you have a database of ArUco markers representing room/corridor labels, do not forget to run
aruco_rosusingros2 launch aruco_ros marker_publisher.launch.Now, play a recorded
bagfile by runningros2 bag play [sample].bag --clock. You can also run vS-Graphs with live feed of RealSense D400 series cameras (read more).
✨ For a complete list of configurable launch arguments, check the Launch Parameters.
🛎️ Note: The current version of vS-Graphs supports ROS2 Jazzy and is primarily tested on Ubuntu 24.04.2 LTS.
🐋 Docker
For a fully reproducible, environment-independent setup, see the Docker section.
📏 Benchmarking
To evaluate vS-Graphs against other visual SLAM frameworks, read the evaluation and benchmarking documentation. You can find sample evaluation results on the vS-Graphs results page.
📚 Citation
@article{tourani2025vsgraphs,
  title={vS-Graphs: Tightly Coupling Visual SLAM and 3D Scene Graphs Exploiting Hierarchical Scene Understanding},
  author={Tourani, Ali and Ejaz, Saad and Bavle, Hriday and Fernandez-Cortizas, Miguel and Morilla-Cabello, David and Sanchez-Lopez, Jose Luis and Voos, Holger},
  journal={IEEE Robotics and Automation Letters},
  volume={11},
  number={8},
  pages={9239-9246},
  year={2026},
  doi={https://doi.org/10.1109/LRA.2026.3703649}
}
📎 Related Repositories
- 🔨 vS-Graphs Tools
- 🔧 LiDAR S-Graphs
- 🎞️ Scene Segmentor (ROS2 Jazzy)
- 🦊 Voxblox Minimal (ROS2 Jazzy)
🔑 License
This project is licensed under the GPL-3.0 license - see the LICENSE for more details.