
mangdangroboticsclub/mini_pupper
mangdangroboticsclub/mini_pupper has 1,201 GitHub stars and 200 forks. GitHot measured 0 stars in 24 hours and +7 in 7 days. Last checked 2026-11-10 22:19 UTC. Last push 2026-10-29.
Open-source physical AI platform bridging ROS and RL — from learning to earning.
What you can do
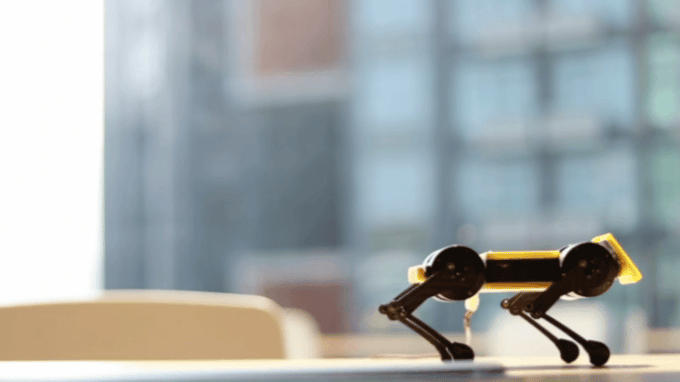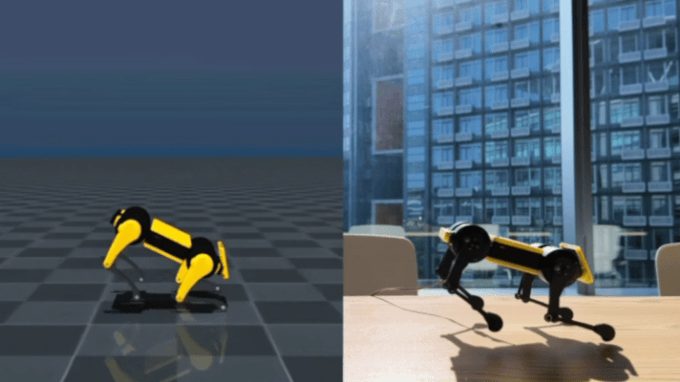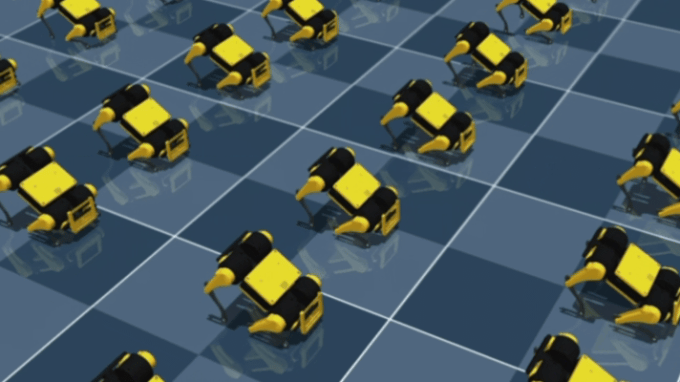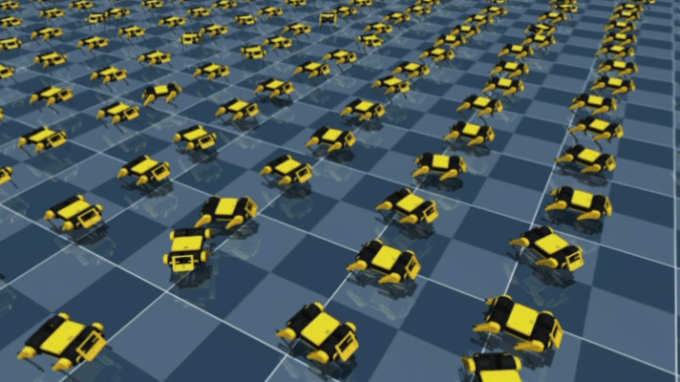
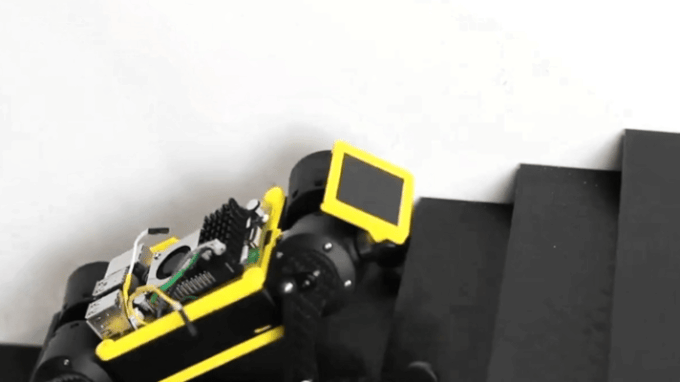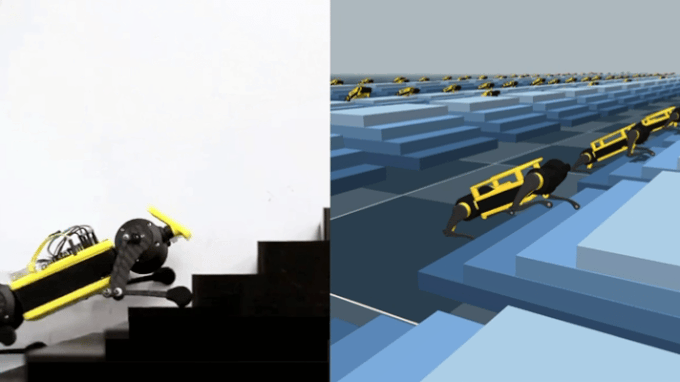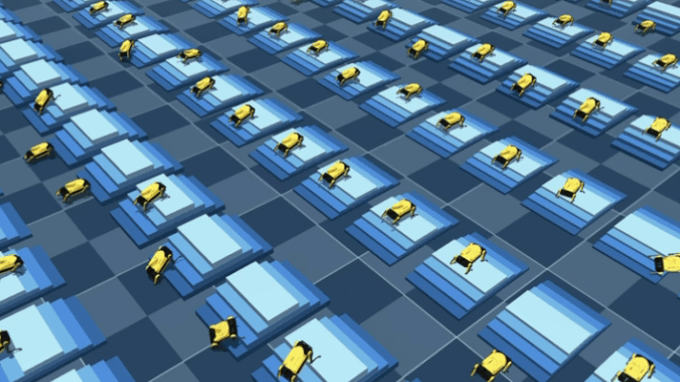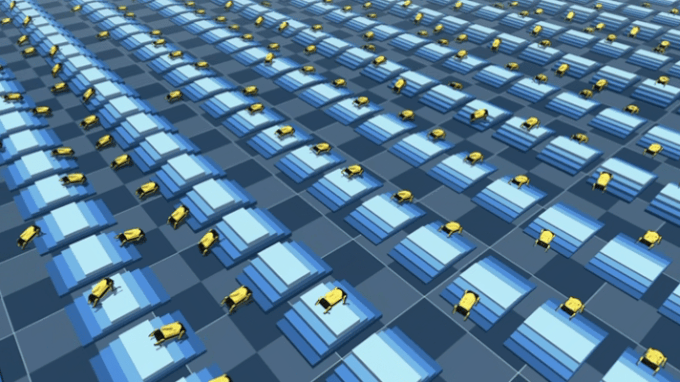
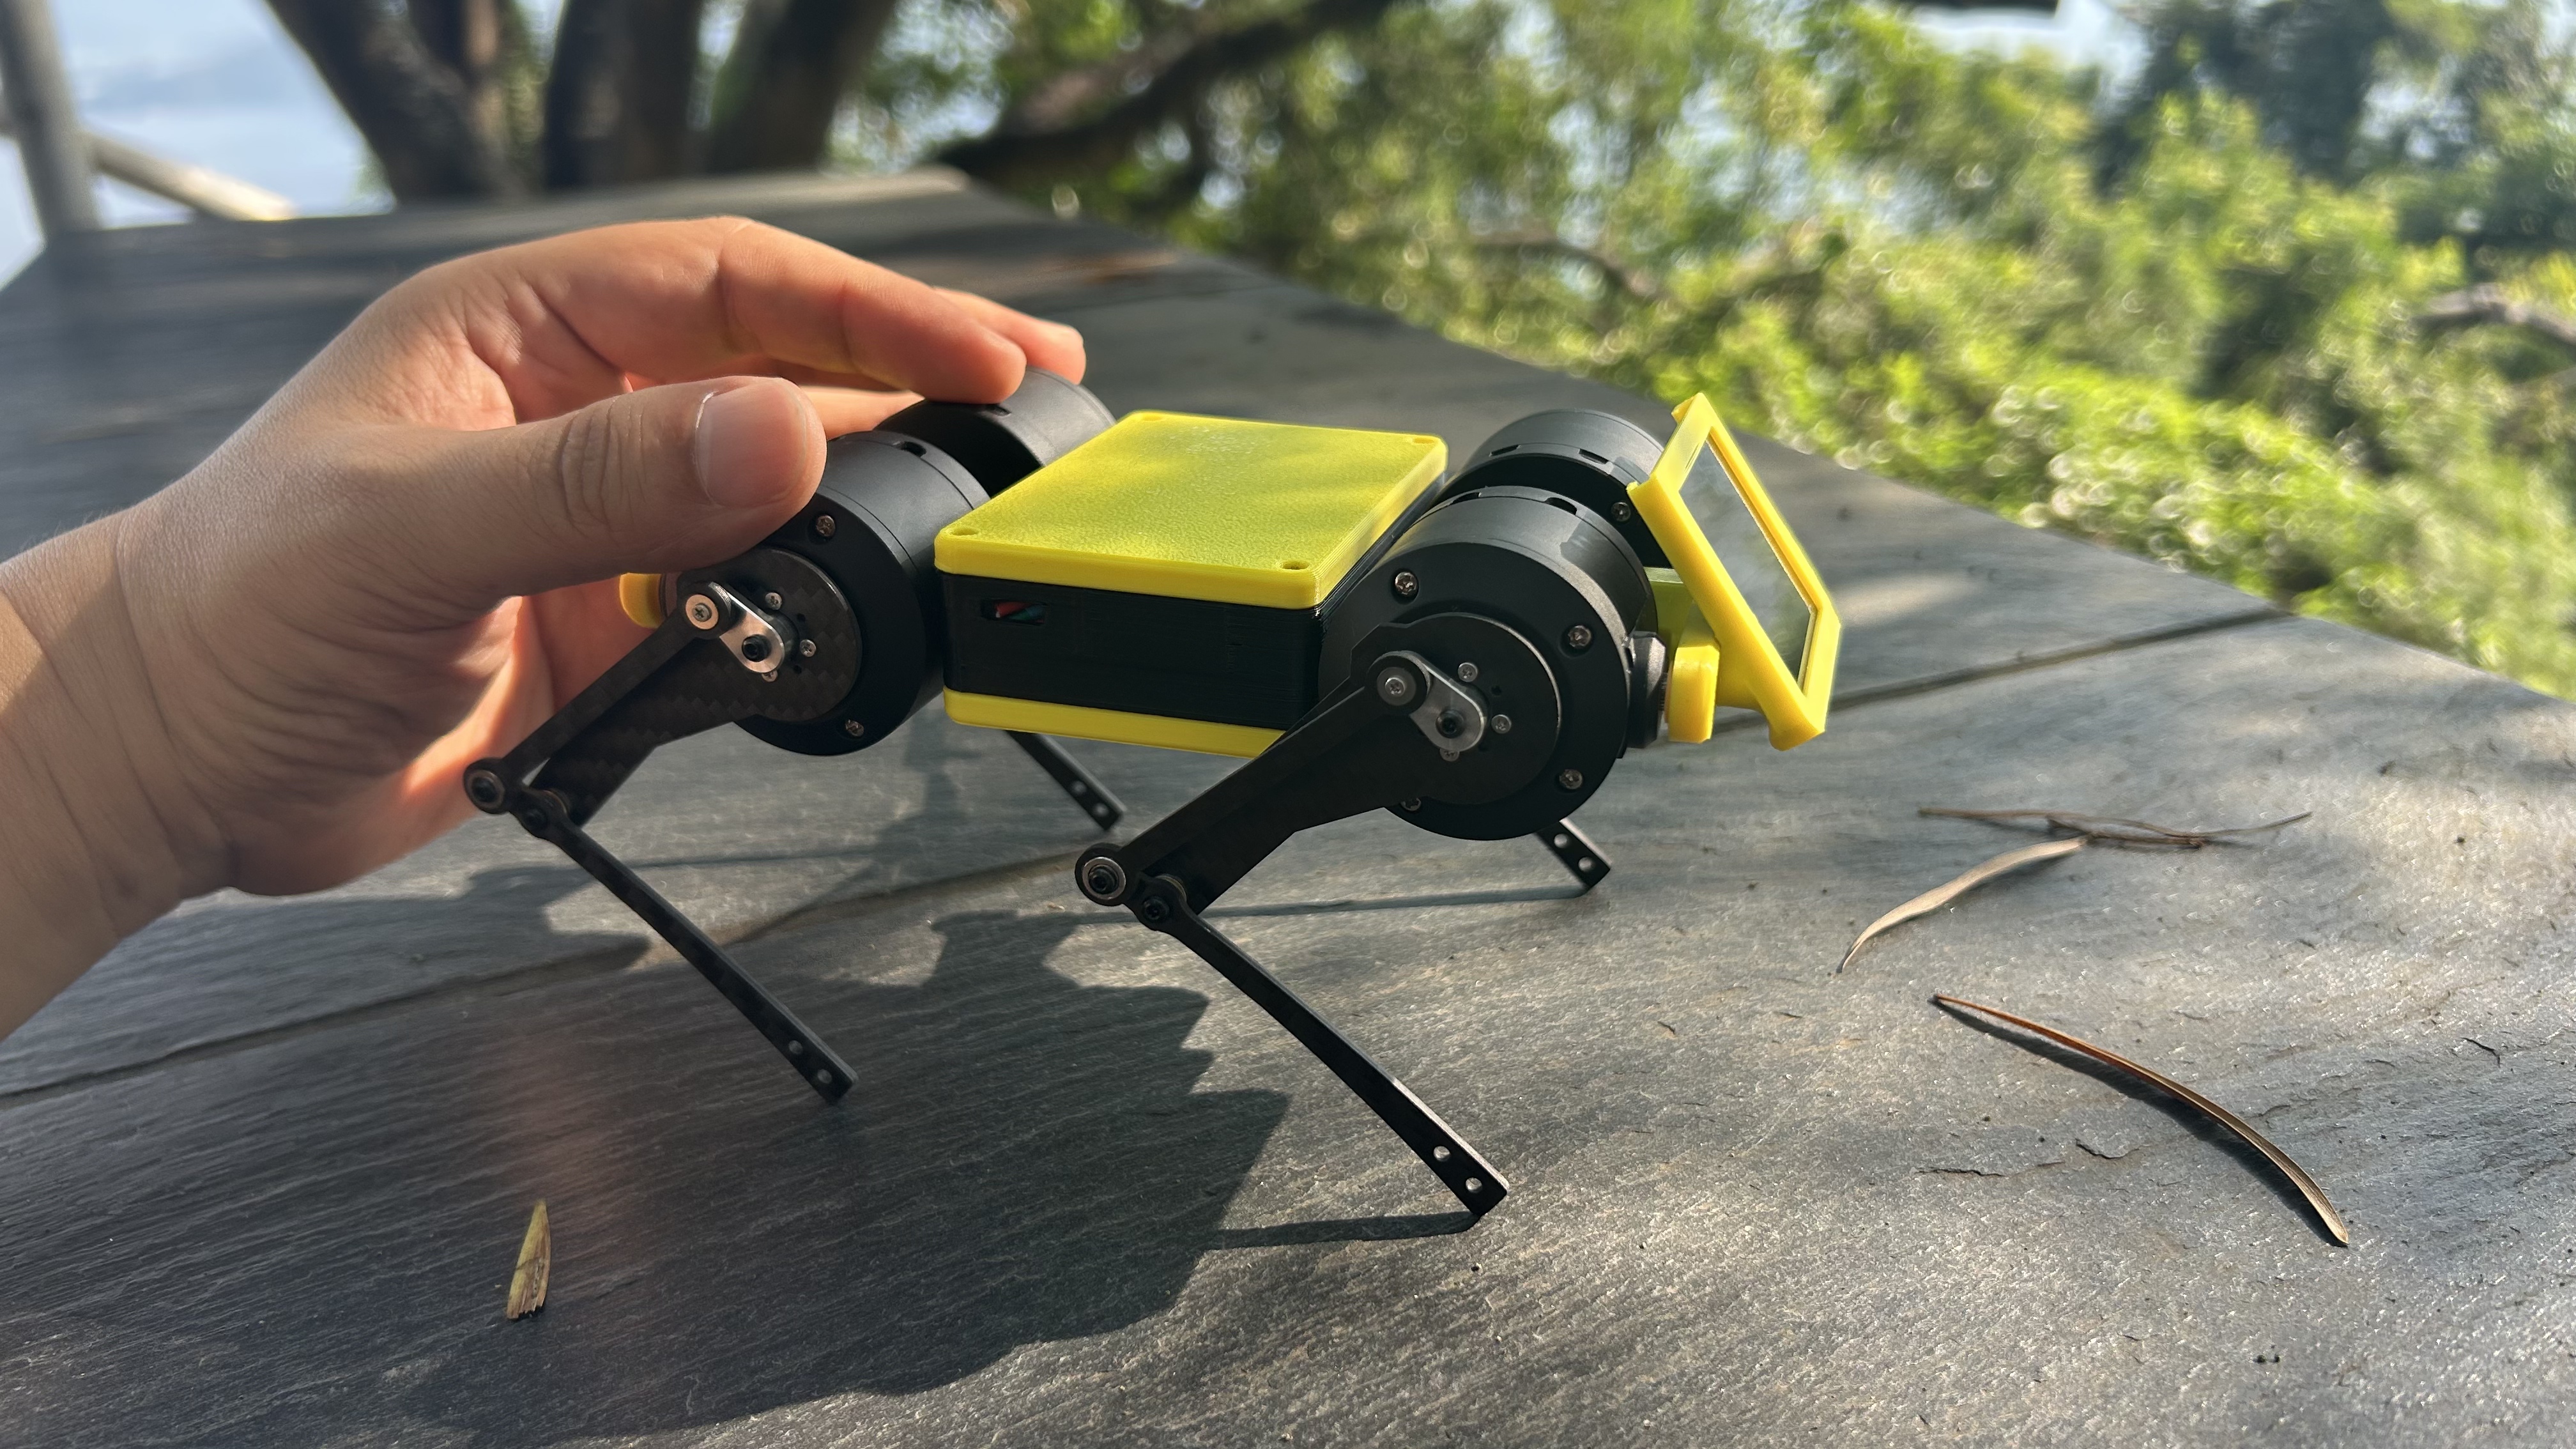
- Close the Sim2Real Gap: Train complex neural network policies flawlessly in high-fidelity simulation, and deploy straight to the real physical robot. - Adapt to Diverse Terrains: Powered by proprietary 3-DoF coreless actuators, Mini Pupper 4 effortlessly climbs stairs and clear complex obstacles.
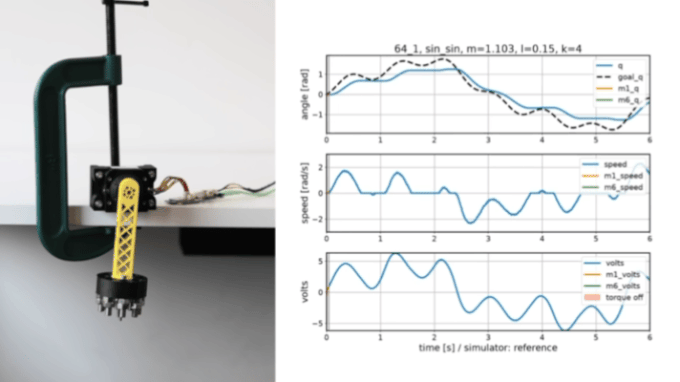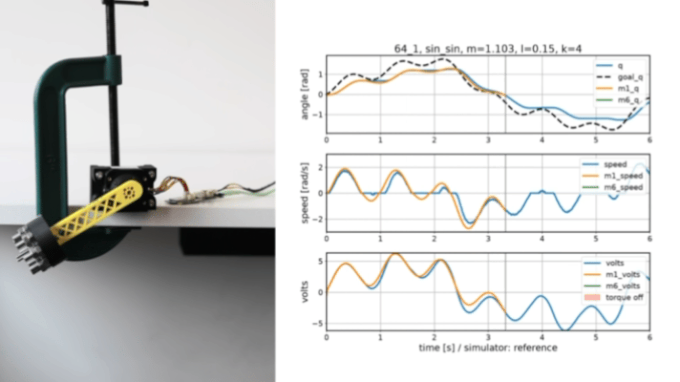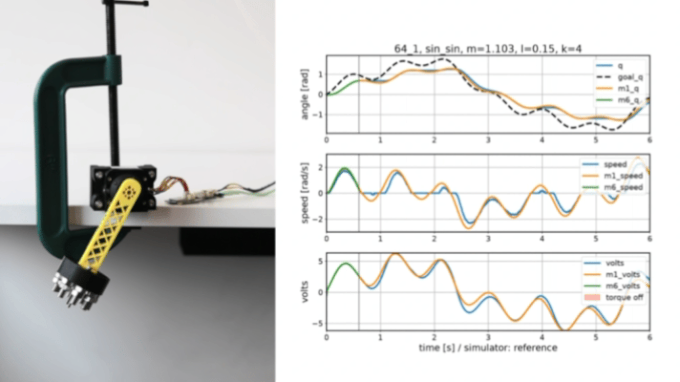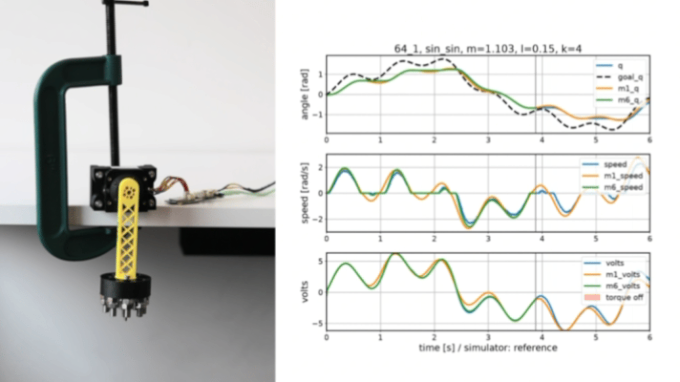
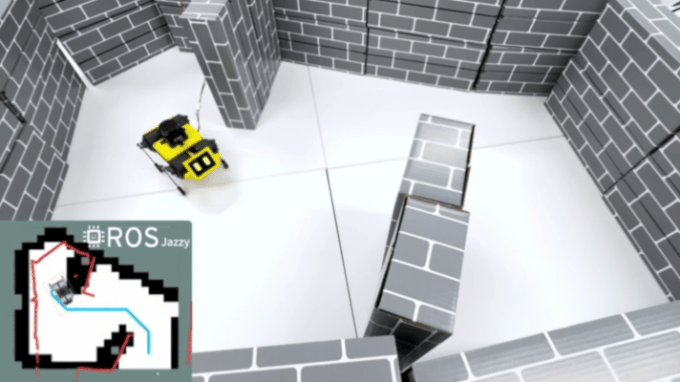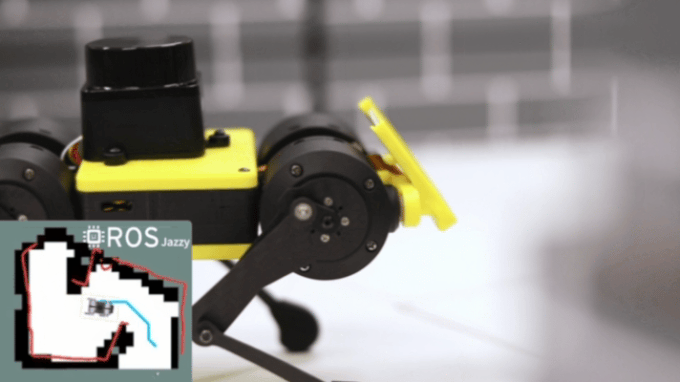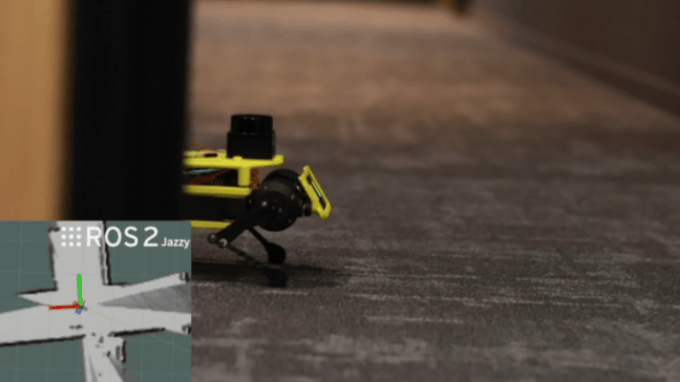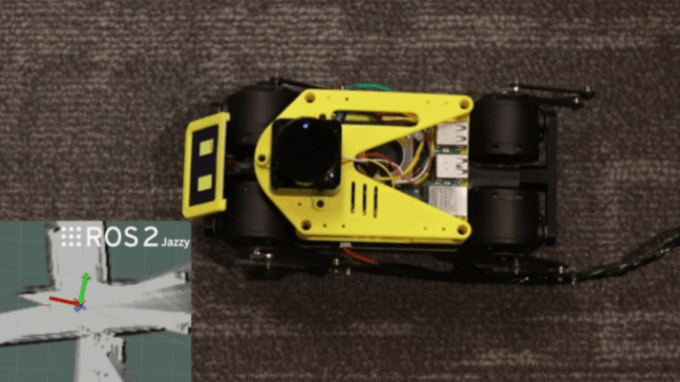
- Native BAM Integration: Fully compatible with Better Actuator Models (BAM) to capture precise joint friction physics, letting you focus on your advanced applications. - Advanced ROS 2 Stack: Out-of-the-box templates featuring ROS 2 Jazzy and micro-ROS for SLAM, Nav2 path planning, and rapid development.
Measured star growth
- in 24h
- 0
- in 7 days
- +7
- in 15 days
- Update delayed
- in 1 month
- Update delayed
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.md
Original
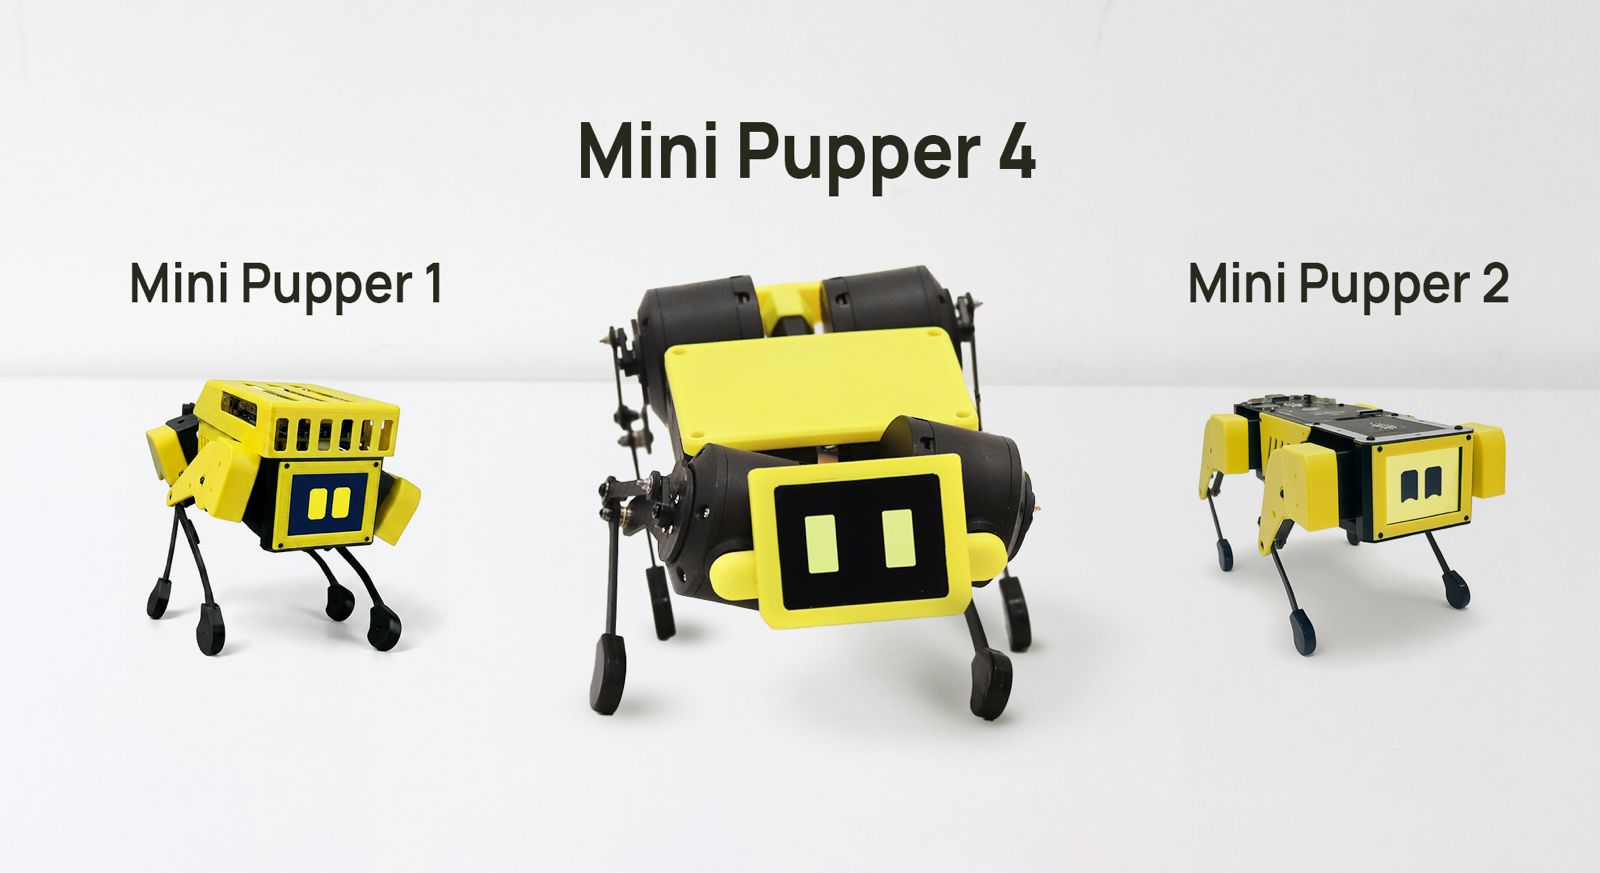
Mini Pupper 4
From Learning to Earning — Powered by 3-DoF Coreless Smart Servos.
Official Website · Facebook Group · Discord Community · Online Shop · Contributing Guide
Capabilities & Frameworks
|
|
| Close the Sim2Real Gap: Train complex neural network policies flawlessly in high-fidelity simulation, and deploy straight to the real physical robot. | Adapt to Diverse Terrains: Powered by proprietary 3-DoF coreless actuators, Mini Pupper 4 effortlessly climbs stairs and clear complex obstacles. |
|
|
| Native BAM Integration: Fully compatible with Better Actuator Models (BAM) to capture precise joint friction physics, letting you focus on your advanced applications. | Advanced ROS 2 Stack: Out-of-the-box templates featuring ROS 2 Jazzy and micro-ROS for SLAM, Nav2 path planning, and rapid development. |
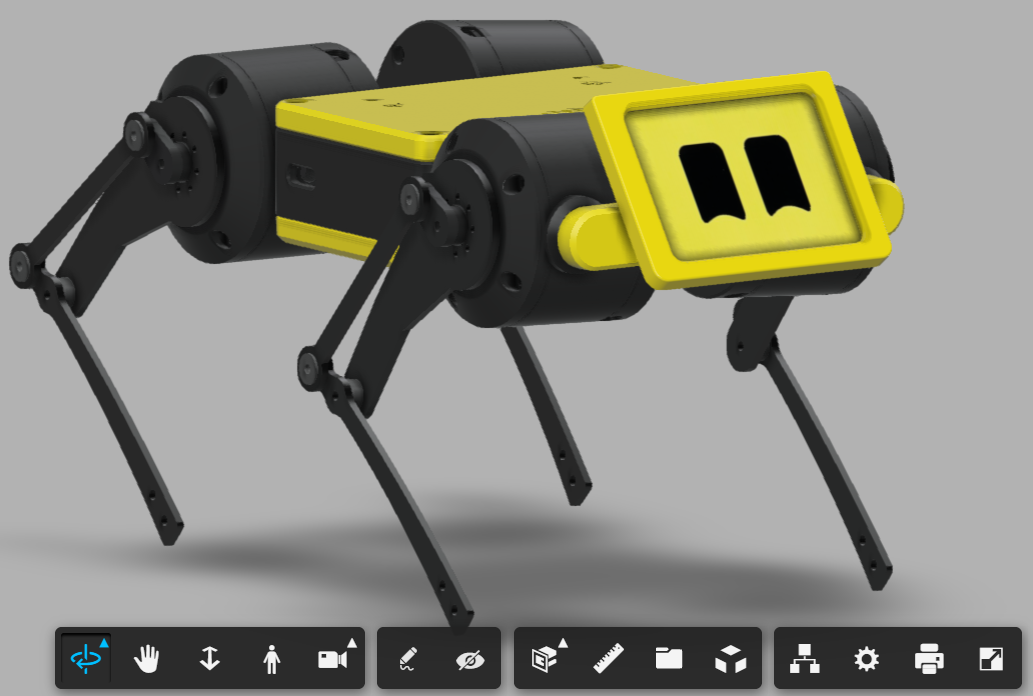
Fusion 360 CAD model: https://a360.co/3W7VBkx
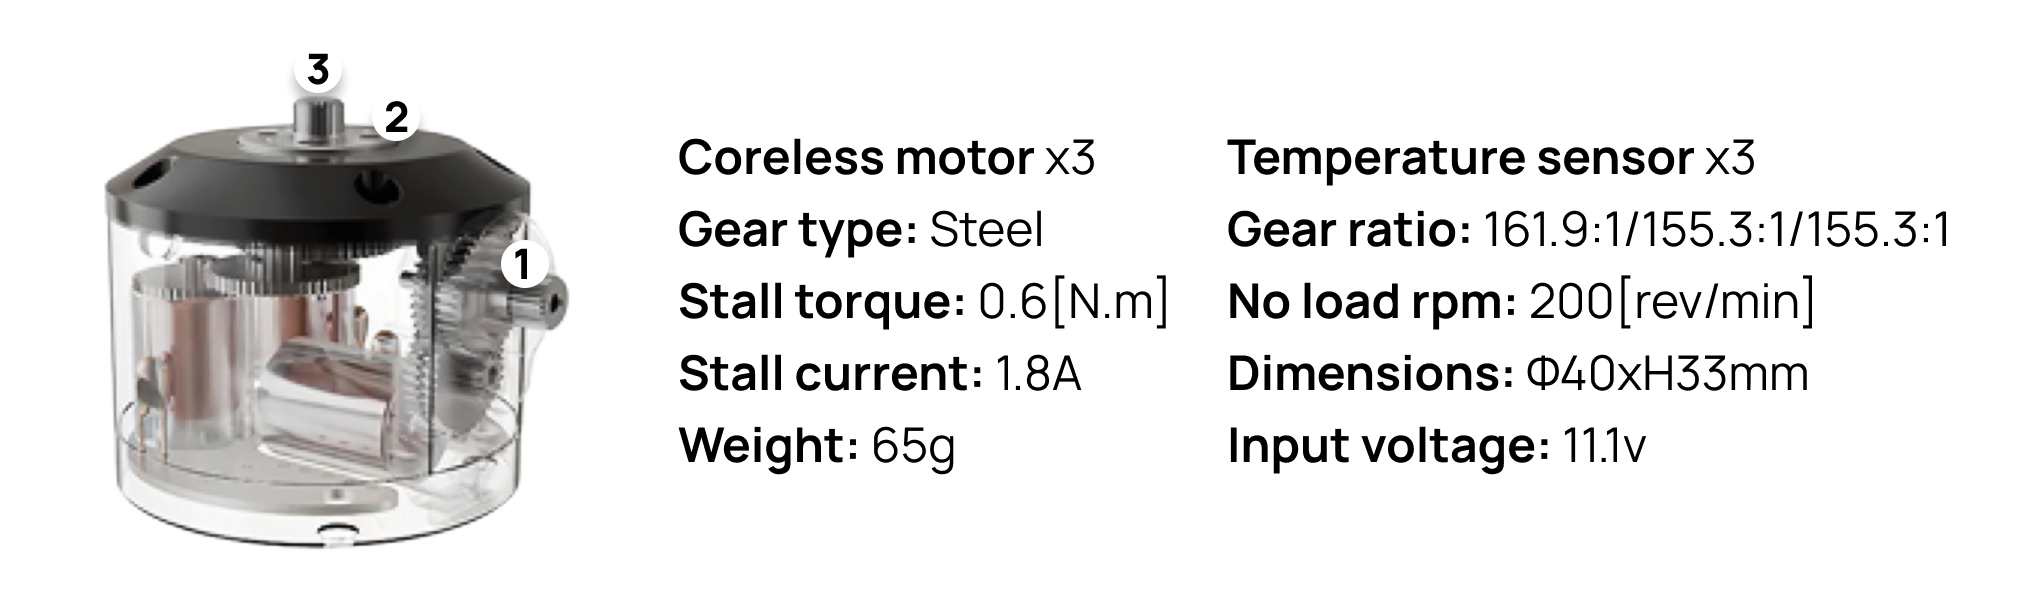
All capabilities stem from our proprietary high-performance, 3-DoF coreless smart actuator: MD-300-150 — the ultimate, versatile building block for modern open-source robotics.For the detailed information, please refer to the MD-300-150 specification.
Open Source Repo Guide
| Github Repo | Description |
|---|---|
| 🤖 RL | The physics engine backend: MuJoCo and NVIDIA Isaac environments, PPO pipelines, domain randomization, and the baked-in ONNX export runtime. |
| ⚙️ BAM Friction Engine | Hardware actuator physics repository. The MangDang MD-300C-150 servo is fully benchmarked and adapted to BAM. |
| 🛹 ROS 2 Core Stack | ROS software platform. We follow the official Open Robotics roadmap with stable support up to ROS 2 Jazzy and Lyrical. |
| 📡 micro-ROS Stack | micro ROS software platform. Real-time lower-level agent bridging. |
| 🧠 MCU Brain | Complete firmware layer source code for the onboard microcontroller, including embedded local AI routing. |
| 🍓 Raspberry Pi Brain | High-level application space source code tailored for the Raspberry Pi computing chassis. |
| 🤝 CONTRIBUTING.md | Developer guidelines for compiling, local simulation testing, layout conventions, and code submission rules. |
| 📖 Online Manual | Comprehensive documentation hub, including modular mechanical blueprints, PCB schematics, and open research challenges. |
| mini pupper 1 bsp | BSP(board support package) for Mini Pupper 1. |
| mini pupper 2 bsp | BSP(board support package) for Mini Pupper 2. |
| mini pupper web controller | This code provides a web GUI for Mini Pupper 1&2 running StanfordQuadruped. |
Contributions
Repositories
| Repository | Description | Status |
|---|---|---|
| minipupper_kinematics | This repositories contains Jupyter notebook that used to gain a better understanding of the kinematics of a quadruped robot in general and Mini Pupper 1 in particular. | experimental |
| mini-pupper-jupyter-notebooks | ROSCon2022 Jupyter Notebooks for Mini Pupper 1. | experimental |
Explore related projects
sindresorhus/awesome
😎 Awesome lists about all kinds of interesting topics [NOTE: Pull requests are temporarily disabled until I have a chance to catch up with the existing ones]
535,276 starsEbookFoundation/free-programming-books
:books: Freely available programming books
401,420 starsnilbuild/developer-roadmap
Interactive roadmaps, guides and other educational content to help developers grow in their careers.
371,821 starsvinta/awesome-python
The definitive list that answers "I want to do X in Python, which tool should I use?"
334,073 stars