
leomariga/pyRANSAC-3D
leomariga/pyRANSAC-3D has 677 GitHub stars and 81 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-19 11:43 UTC. Last push 2026-08-28.
Measured star growth
- in 24h
- 0
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
About
Python library for fitting 3D primitive shapes to point clouds with RANSAC. Detect planes, spheres, cylinders, cuboids, circles, and lines.
Creative & MediaREADME.md
Original


What is pyRANSAC-3D?
pyRANSAC-3D is an open source Python implementation of the Random Sample Consensus (RANSAC) method. It fits primitive shapes such as planes, cuboids, and cylinders to point clouds for applications including 3D SLAM, 3D reconstruction, object tracking, and more.
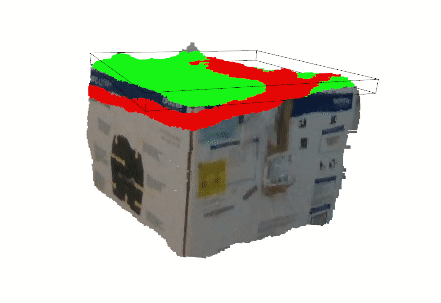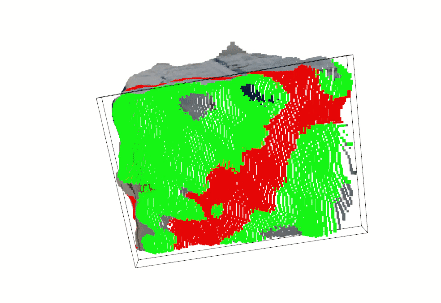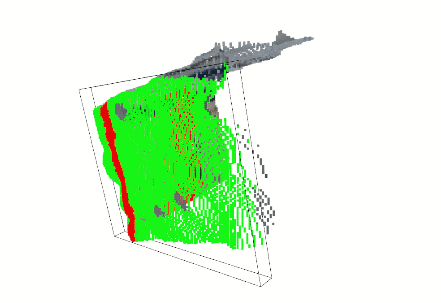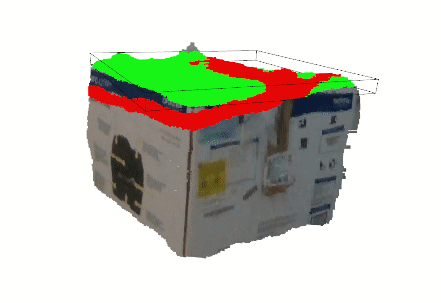
Features
Installation
Requirement: NumPy
Install from PyPI:
pip install pyransac3d
For a complete introduction see the Getting Started guide.
Quick start
Example 1 - Planar RANSAC
import pyransac3d as pyrsc

points = load_points(.) # Load your point cloud as a NumPy array with shape (N, 3)

plane1 = pyrsc.Plane()
best_eq, best_inliers = plane1.fit(points, 0.01)
The result is the plane equation Ax + By + Cz + D = 0:
[0.720, -0.253, 0.646, 1.100]
Example 2 - Spherical RANSAC
To fit a noisy sphere with r = 5 centered at the origin, use:
import pyransac3d as pyrsc

points = load_points(.) # Load your point cloud as a NumPy array with shape (N, 3)

sph = pyrsc.Sphere()
center, radius, inliers = sph.fit(points, thresh=0.4)
Results:
center: [0.010462385575072288, -0.2855090643954039, 0.02867848979091283]
radius: 5.085218633039647
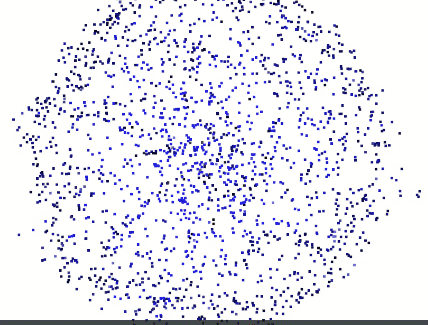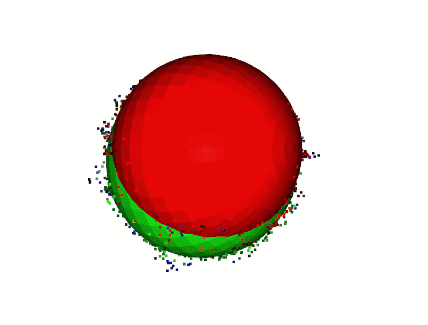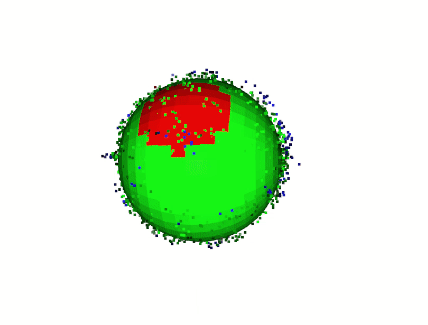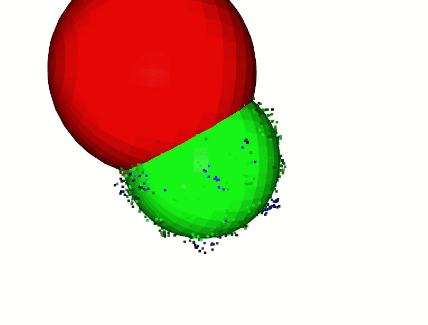
More examples
Runnable examples of every shape are in the examples folder.
When should I use pyRANSAC-3D?
Use pyRANSAC-3D when you need to:
- Fit a plane to a 3D point cloud in Python, such as a floor, wall, roof, or tabletop.
- Detect cylinders in LiDAR or depth-sensor data, such as pipes, poles, trunks, or columns.
- Segment geometric shapes from noisy point clouds with RANSAC.
- Fit spheres, cuboids, circles, lines, or point clusters from NumPy-compatible
(N, 3)arrays. - Combine lightweight NumPy-based shape fitting with optional Open3D visualization.
Documentation and other links
- Read the documentation.
- Browse the source code in the GitHub repository.
- Install the PyPI package.
- Explore the animation examples to watch each RANSAC fitter update through its callback.
License
Citation
Was this repository useful for your work? Please cite it:
@software{Mariga_pyRANSAC-3D,
  author = {Mariga, Leonardo},
  doi = {10.5281/zenodo.7212567},
  month = {8},
  title = {{pyRANSAC-3D}},
  url = {https://github.com/leomariga/pyRANSAC-3D},
  version = {v0.7.0},
  year = {2026}
}
Contributing is awesome!
See CONTRIBUTING
Contact
Developed with :heart: by the internet
Maintainer: Leonardo Mariga
Did you like it? Remember to click the :star2: button.