
leggedrobotics/robotic_world_model_lite
leggedrobotics/robotic_world_model_lite has 254 GitHub stars and 16 forks. GitHot measured +1 stars in 24 hours. Last checked 2026-11-18 01:58 UTC. Last push 2026-04-08.
Measured star growth
- in 24h
- +1
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
About
Lightweight implementation of Robotic World Model (RWM) and Uncertainty-Aware Robotic World Model (RWM-U)
Developer ToolsREADME.md
OriginalRobotic World Model Lite


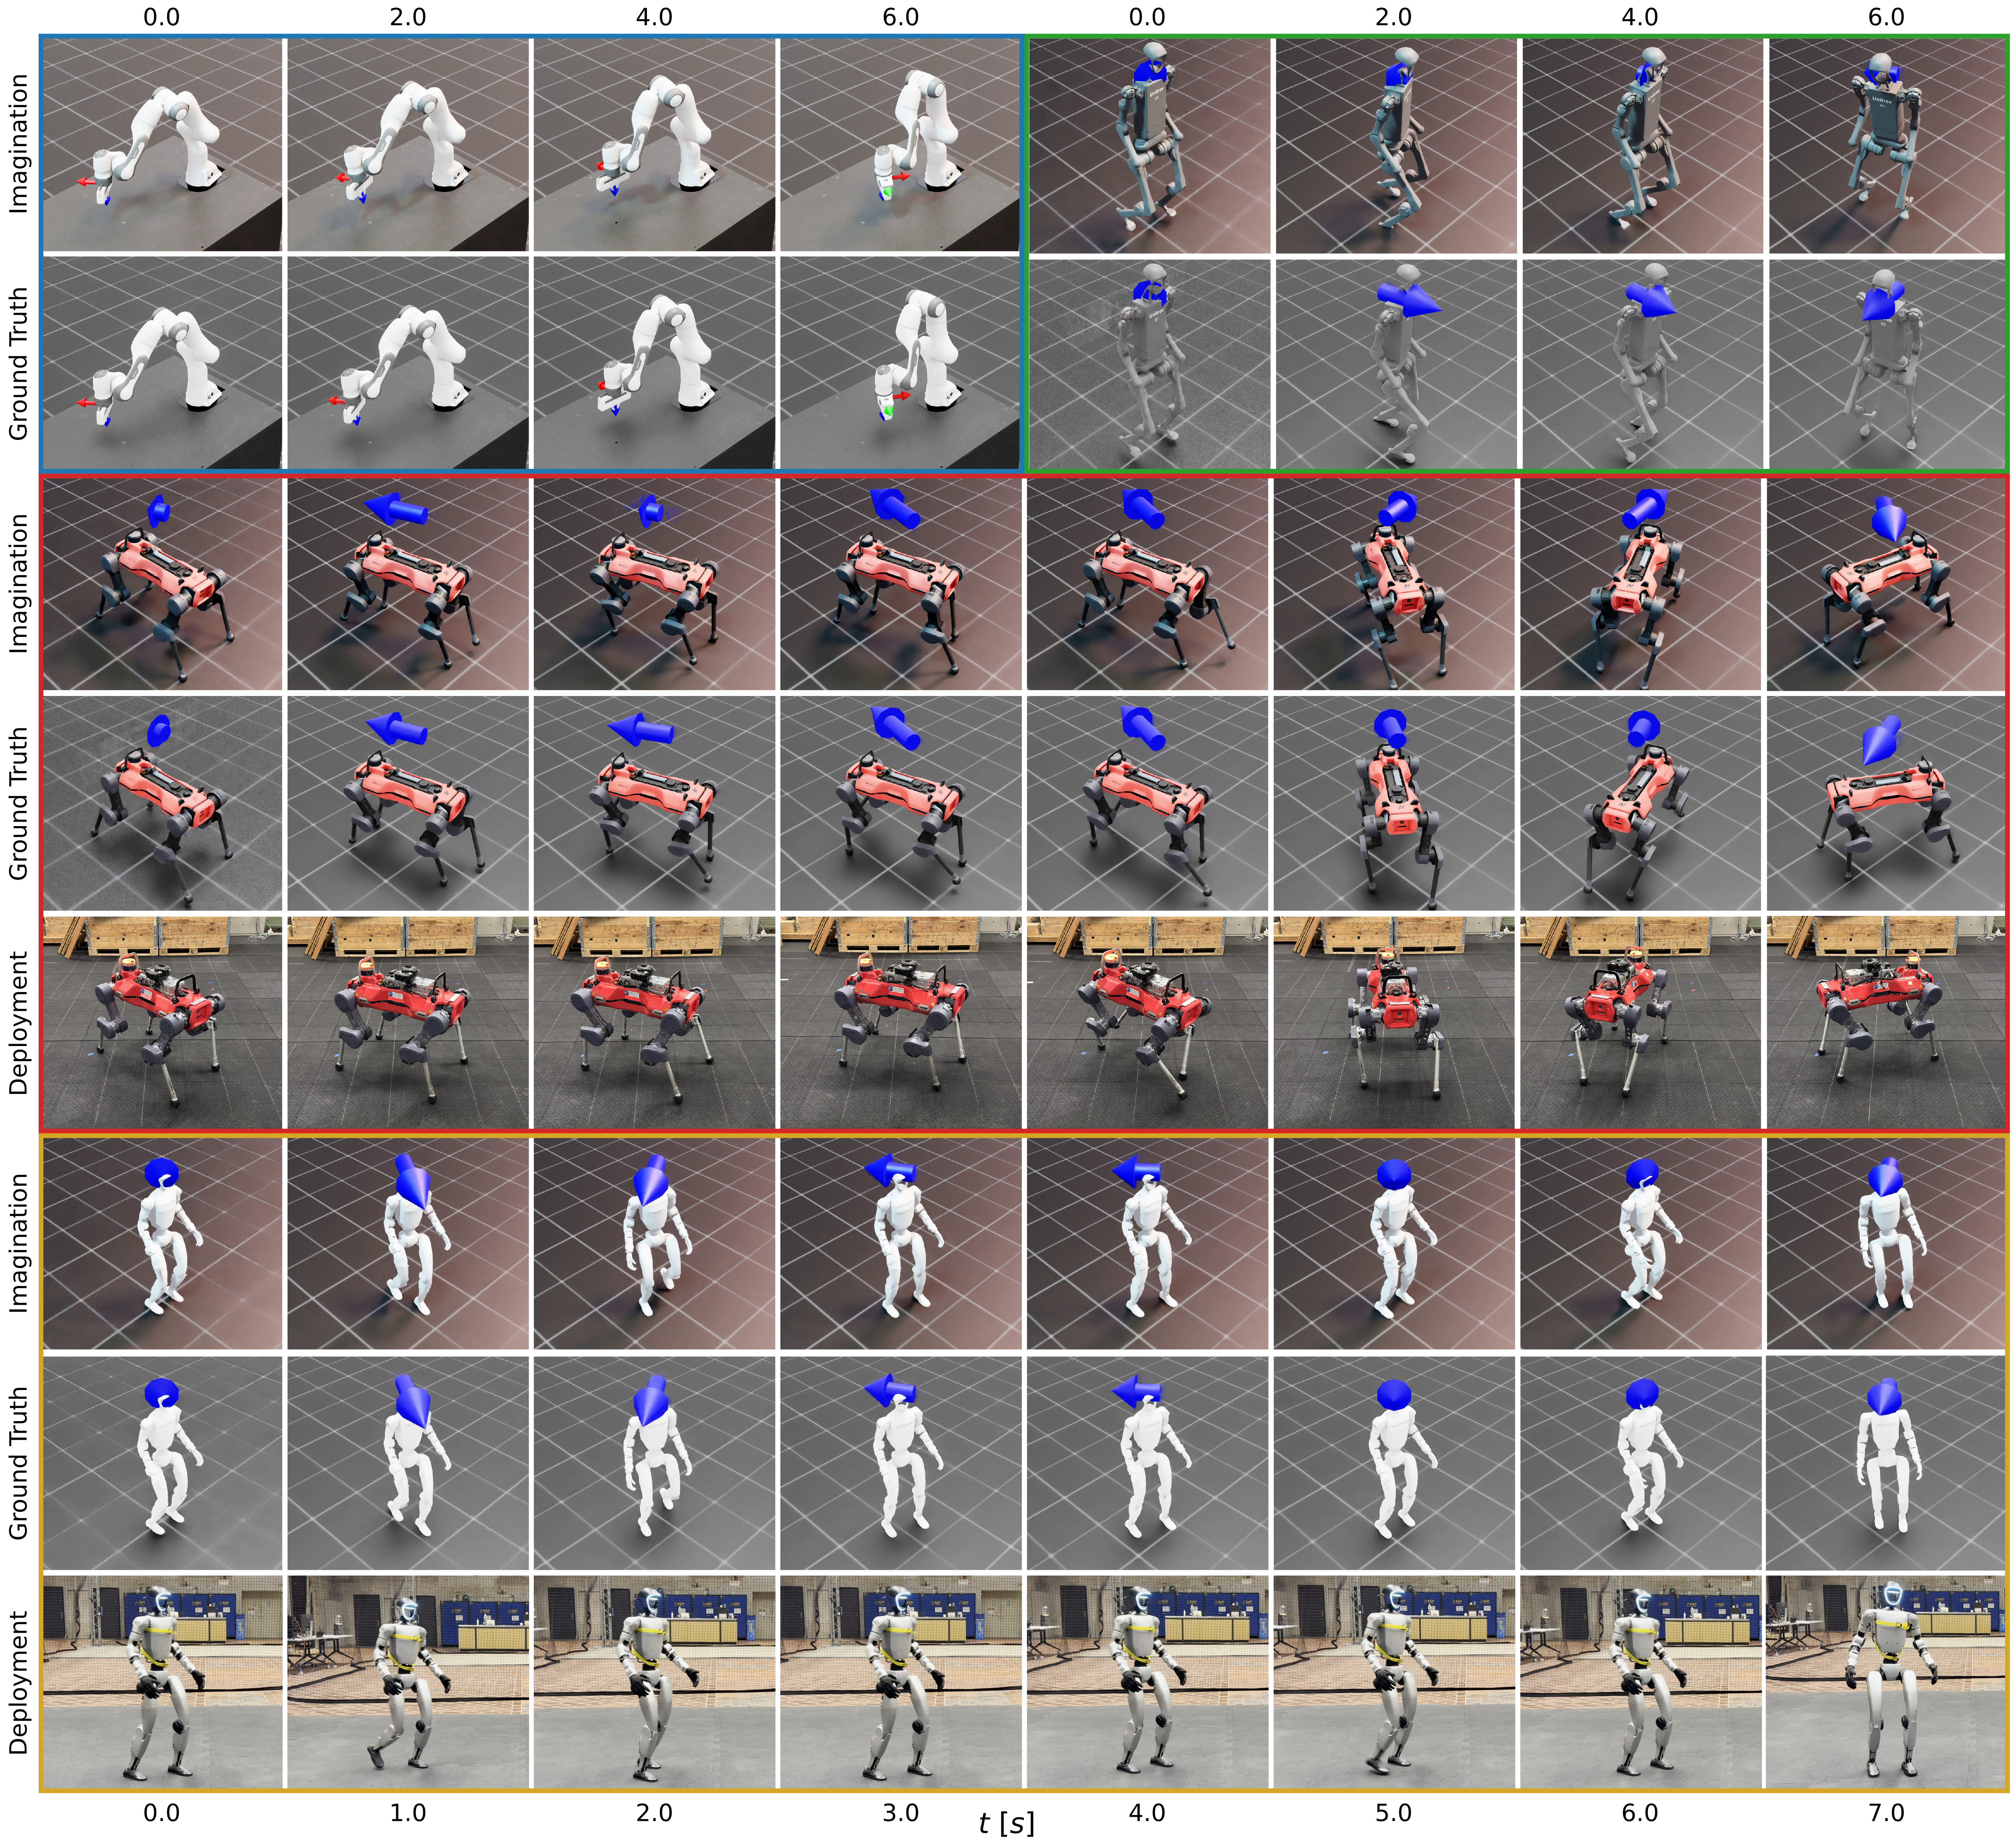
This repository is a lightweight implementation intended for users who want to train dynamics models from offline data and model-based policies only, without the need to set up a full robotics simulator like Isaac Lab.
We provide a Google Colab notebook for quick start: RWM Lite Colab Notebook.
:star: For the full version with online simulator-based data collection, model and policy training and evaluation pipeline, please refer to our full Isaac Lab RWM Extension implementation.
Overview
This repository provides a lightweight training pipeline for
and related model-based reinforcement learning methods, without any simulator dependency.
It enables:
- training of dynamics models with ensemble recurrent neural networks,
- training of policies with learned neural network dynamics without any simulator,
- WandB logging support for experiment tracking.
Authors: Chenhao Li, Andreas Krause, Marco Hutter
Affiliation: ETH AI Center, Learning & Adaptive Systems Group and Robotic Systems Lab, ETH Zurich
Installation
- Create Conda environment with
python>=3.10and activate it
conda create -n rwm_lite python=3.10 -y
conda activate rwm_lite
- Clone this repository inside your Isaac Lab directory
git clone [email protected]:leggedrobotics/robotic_world_model_lite.git
cd robotic_world_model_lite
- Install
rwm_lite
python -m pip install -e .
Model-Based Policy Training & Evaluation
- Login WandB
wandb login
- Train policy with RWM
python scripts/train.py --task anymal_d_flat
The policy is saved under logs/.
- Evaluate the policy with a simulator or hardware
The learned policy can be played and evaluated with our full Isaac Lab RWM Extension or the original Isaac Lab task registry.
python scripts/reinforcement_learning/rsl_rl/play.py --task Isaac-Velocity-Flat-Anymal-D-Play-v0 --checkpoint <checkpoint_path>
Code Structure
We provide a reference pipeline that enables RWM and RWM-U on ANYmal D.
Key files:
- Environment configurations + Imagination rollout logic (constructs policy observations & rewards from model outputs)
anymal_d_flat.py. - Algorithm configuration + training parameters
anymal_d_flat_cfg.py. - Pretrained RWM-U checkpoint
pretrain_rnn_ens.pt. - Initial states for imagination rollout
state_action_data_0.csv.
Citation
If you find this repository useful for your research, please consider citing:
@article{li2025robotic,
  title={Robotic world model: A neural network simulator for robust policy optimization in robotics},
  author={Li, Chenhao and Krause, Andreas and Hutter, Marco},
  journal={arXiv preprint arXiv:2501.10100},
  year={2025}
}
@article{li2025uncertainty,
  title={Uncertainty-Aware Robotic World Model Makes Offline Model-Based Reinforcement Learning Work on Real Robots},
  author={Li, Chenhao and Krause, Andreas and Hutter, Marco},
  journal={arXiv preprint arXiv:2504.16680},
  year={2025}
}