
leggedrobotics/ocs2 has 1,537 GitHub stars and 328 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-08 04:19 UTC. Last push 2026-09-29.
Optimal Control for Switched Systems
What you can do
- SLQ: continuous-time constrained DDP (SLQ/DDP family)
- iLQR: discrete-time constrained DDP
- SQP: multiple-shooting SQP (QP subproblems via HPIPM/BLASFEO)
- SLP: sequential linear programming (PIPG)
Measured star growth
- in 24h
- 0
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.md
OriginalOCS2 Toolbox
OCS2 (Optimal Control for Switched Systems) is a C++ toolbox for formulating and solving nonlinear optimal control problems, with an emphasis on real-time Model Predictive Control (MPC) for robotics.
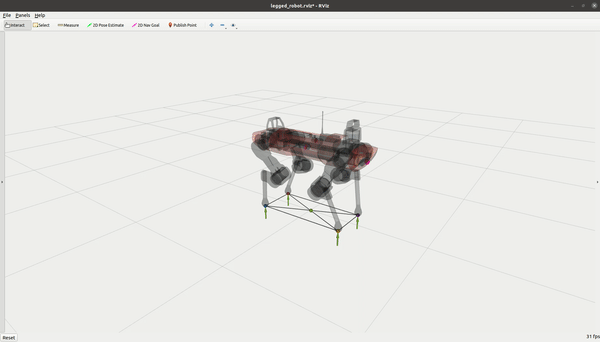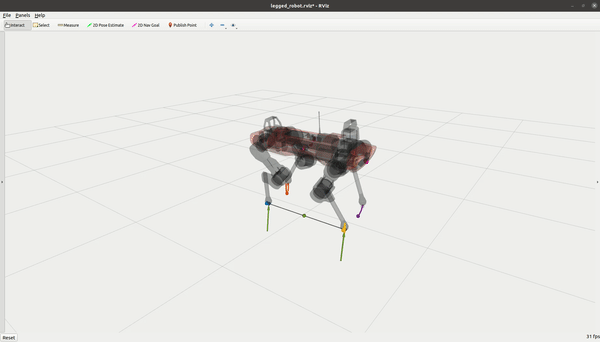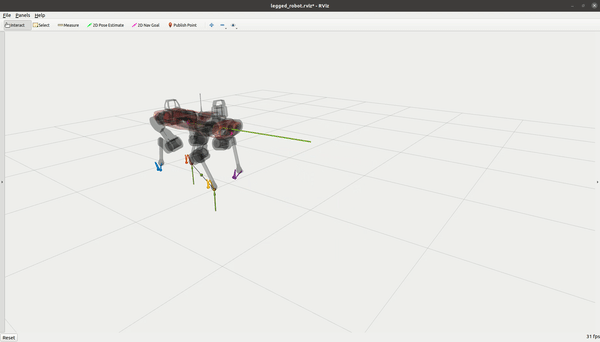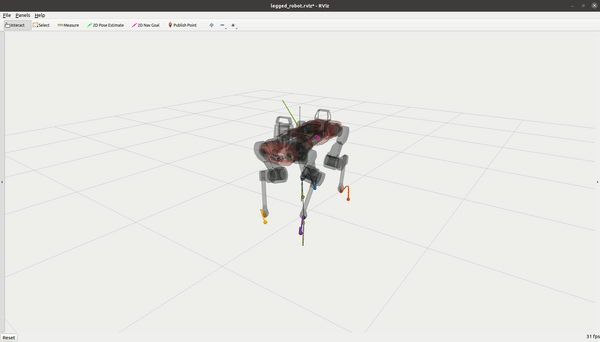
OCS2 handles general path constraints through Augmented Lagrangian or relaxed barrier methods. To facilitate the application of OCS2 in robotic tasks, it provides additional tools to set up the system dynamics (such as kinematic or dynamic models) and cost/constraints (such as self-collision avoidance and end-effector tracking) from a URDF model. The library also provides an automatic differentiation tool to calculate derivatives of the system dynamics, constraints, and cost. To facilitate deployment on robotic platforms, OCS2 provides tools for ROS interfaces. The toolbox’s efficient and numerically stable implementations in conjunction with its user-friendly interface have paved the way for employing it on numerous robotic applications with limited onboard computation power.
ROS 2 port available: use branch
ros2.
ROS branches
| ROS version | Branch |
|---|---|
| ROS 1 | main |
| ROS 2 | ros2 |
Highlights
- Multiple solvers
- SLQ: continuous-time constrained DDP (SLQ/DDP family)
- iLQR: discrete-time constrained DDP
- SQP: multiple-shooting SQP (QP subproblems via HPIPM/BLASFEO)
- SLP: sequential linear programming (PIPG)
- IPM: multiple-shooting nonlinear interior-point method
- Switched-system OCP support: mode schedules and jump maps (single- and multi-domain problems).
- Constraints: hard/soft constraints with Augmented Lagrangian and relaxed barrier methods.
- Derivatives: analytic derivative interfaces + automatic differentiation (CppAD) and optional code generation (CppADCodeGen).
- Robotics tooling: URDF→model helpers (Pinocchio), kinematics, centroidal models, self-collision constraints (HPP-FCL).
- ROS integration: messages, nodes, and visualization/plotting tools for deploying MPC on robots.
- Robotic examples: end-to-end MPC examples (and ROS wrappers) for double integrator, cartpole, ballbot, quadrotor, mobile manipulator, legged robot, and more.
Repository structure (high level)
ocs2_core: core data types, math utilities, rollout interfaces, AD utilities.ocs2_oc: optimal control problem building blocks (costs, constraints, dynamics, pre-computation, reference management).ocs2_ddp,ocs2_mpc: DDP-family solvers + MPC infrastructure and runtime interfaces.ocs2_sqp,ocs2_slp,ocs2_ipm: alternative solvers (SQP / SLP / IPM).ocs2_pinocchio/*: URDF/Pinocchio tooling (centroidal model, kinematics, self-collision, visualization).ocs2_ros_interfaces,ocs2_msgs: ROS interfaces and message definitions.ocs2_robotic_examples/*: robotic examples and their ROS nodes.ocs2_python_interface: Python bindings for selected components.ocs2_mpcnet: MPC-Net tooling for learned policy deployment/training.ocs2_doc: documentation sources (Sphinx/Doxygen).
Documentation
- Online documentation: https://leggedrobotics.github.io/ocs2/
Installation
- ROS 1 (
main): follow the installation instructions in the documentation (Installation page): https://leggedrobotics.github.io/ocs2/ - ROS 2 (
ros2): followinstallation.mdon that branch: https://github.com/leggedrobotics/ocs2/blob/ros2/installation.md
Citing OCS2
@misc{OCS2,
  title  = {{OCS2}: An open source library for Optimal Control of Switched Systems},
  note   = {[Online]. Available: \url{https://github.com/leggedrobotics/ocs2}},
  author = {Farbod Farshidian and others}
}
License
BSD 3-Clause, see LICENCE.txt.
Explore related projects
codecrafters-io/build-your-own-x
Master programming by recreating your favorite technologies from scratch.
560,836 starspublic-apis/public-apis
A collective list of free APIs
497,079 starsmorluto/rea
Reverse engineer anything with agents, from app behavior down to native binaries.
441,506 starsopenclaw/openclaw
The AI that really does things. Any OS. Any Platform. The lobster way. 🦞
394,157 stars