
fehimornek/DeepForSpeed
fehimornek/DeepForSpeed has 250 GitHub stars and 23 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-21 09:54 UTC. Last push 2022-03-19.
Measured star growth
- in 24h
- 0
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
About
ConvNet learns to play Need For Speed
Machine LearningREADME.md
OriginalDeepForSpeed: Data Wanted
A self-driving car in Need For Speed
The inspiration comes from how Nvidia built a self-driving car with just a single convolutional neural network instead of many fancy algorithms combined. Here my goal is to replicate the amazing results they've gotten but inside a game. But i also tried to create it as a platform/interface in which different architectures can be tested relatively easily, so it can also be used as a benchmark. So it's like a fun driving simulator (of course not an accurate one) that you can test your own neural networks at and maybe conduct some experiments.
Watch The Latest Version
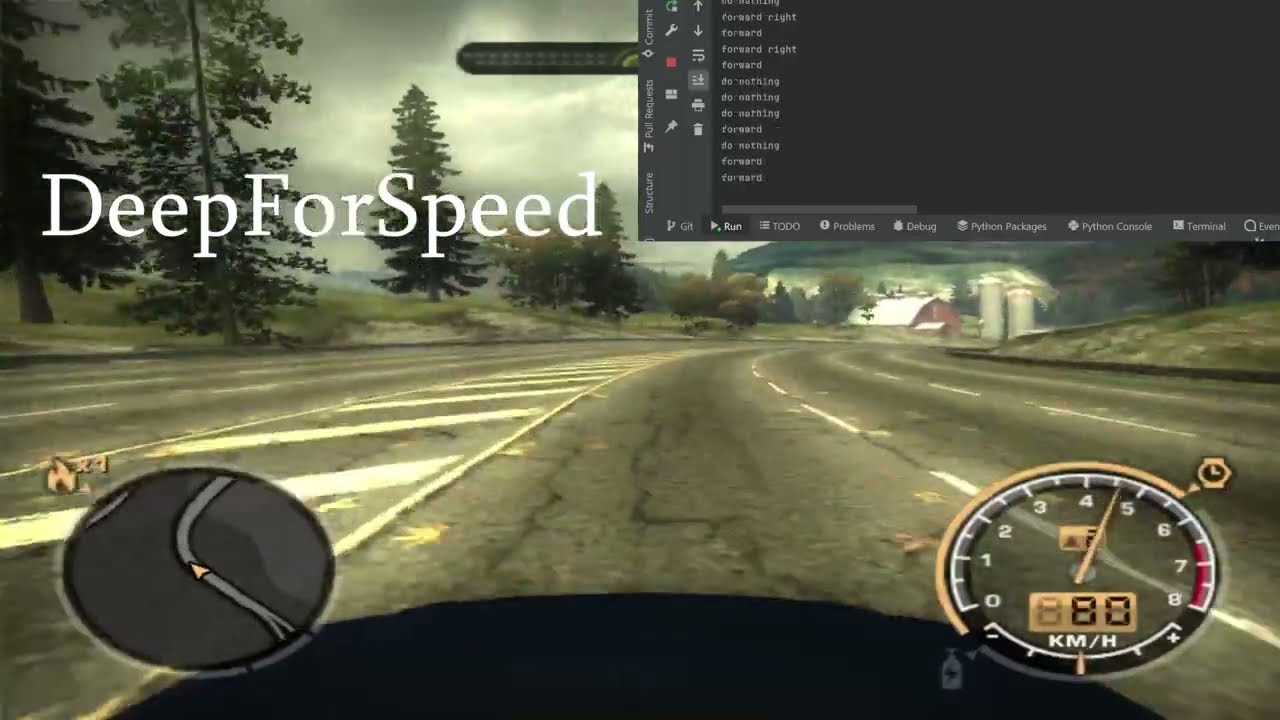 note: this is a cherry picked example and many times model will not perform this well. Im hoping to change that in future versions.
Things used
Python 3.9
Pytorch 1.10
Numpy
OpenCV
Matplotlib
Need For Speed: Most Wanted 2005
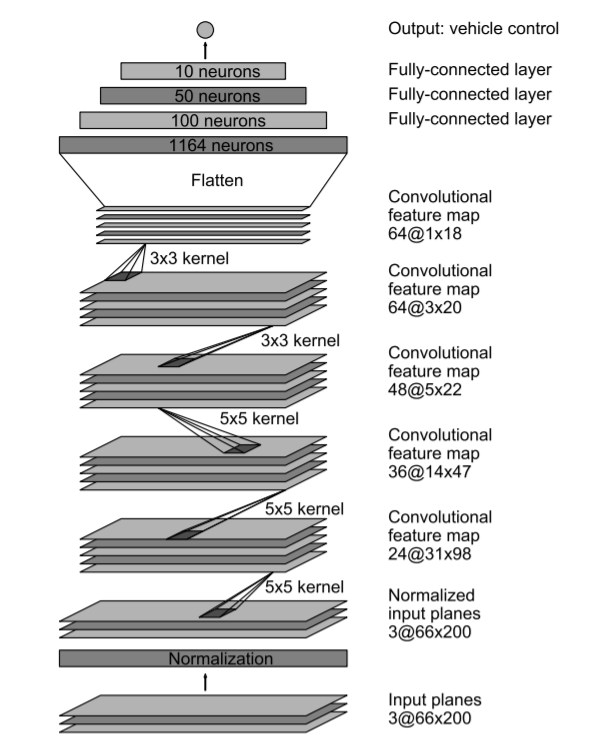
Base architecture
How to use it
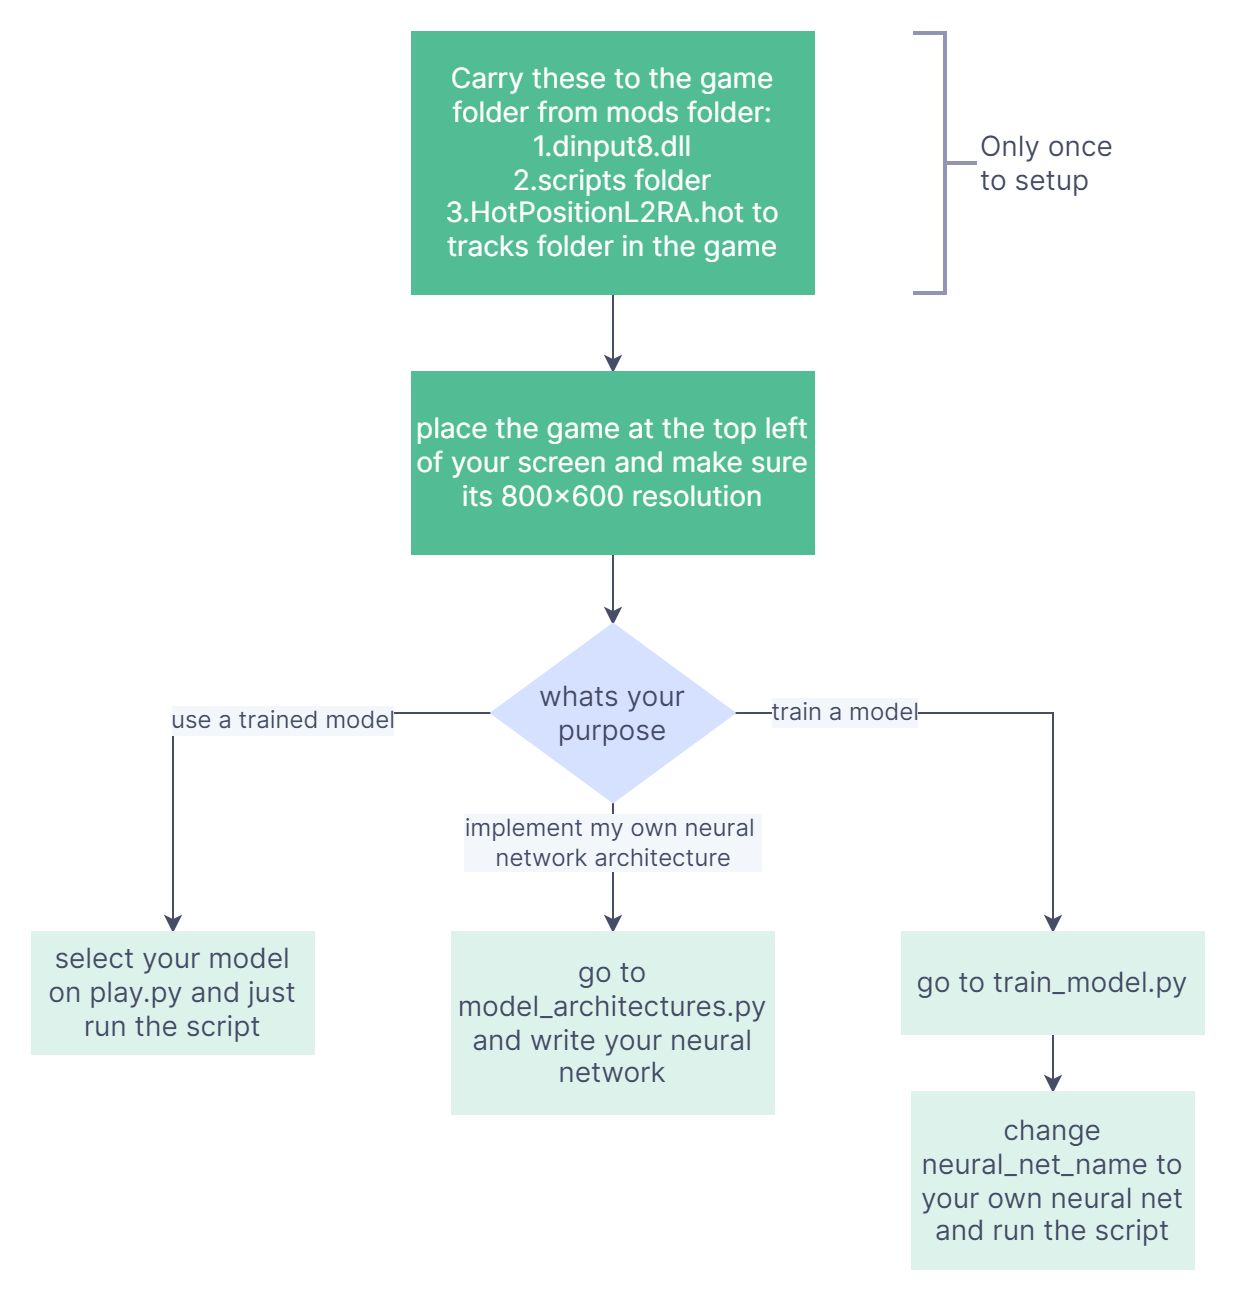
There is different ways to use it depending on what you want. Additional info can be found inside the scripts.
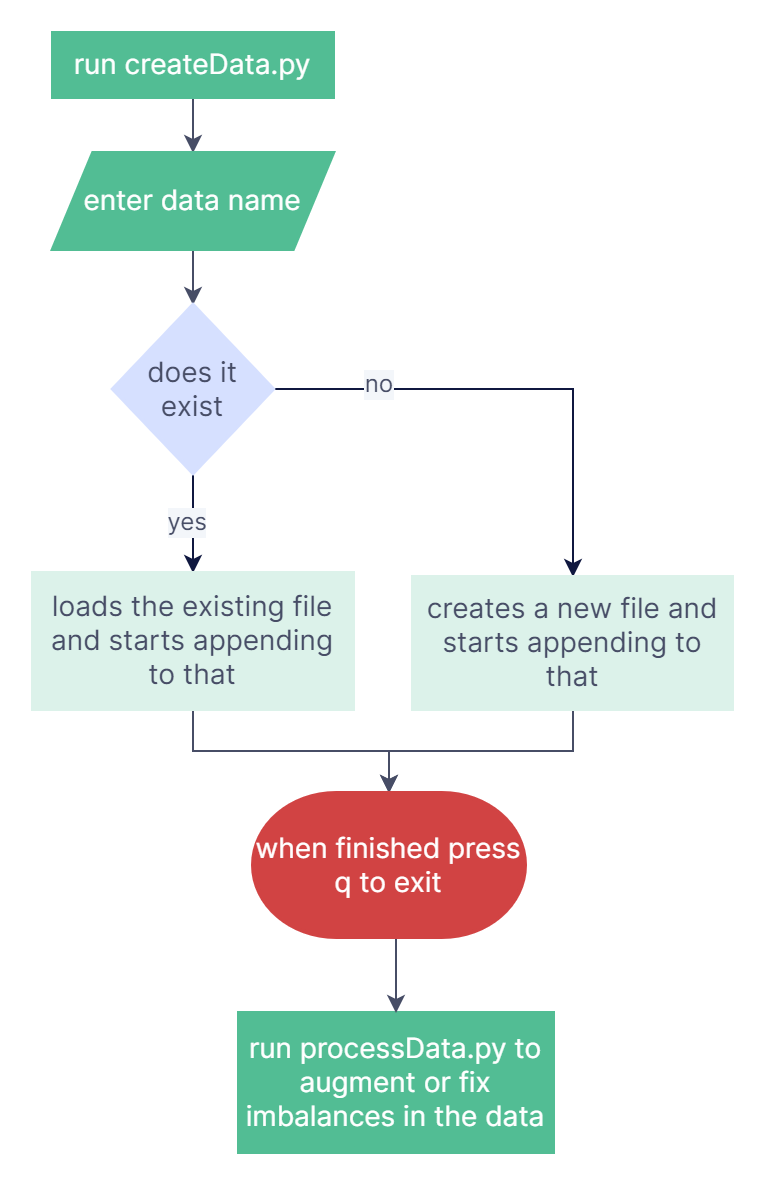
Creating and processing data
Using models
Pull requests
TLDR: Basically any improvements are really appreciated.
- Other Neural Network architectures
- Refinements in the code
- Trained Models
- Anything you can get done on future updates part
For Future Updates:
- Add tensorflow board
- Only use np arrays instead of both lists and np arrays in data
- RGB images instead of gray images
- Train on more data
- Increase data resolution
- Controller or a steering wheel to get the input
- Different activation functions
- Try Weight Decay
- Add merging data function for easing data creation
- Save models whilst training
References:
paper by nvidia: https://images.nvidia.com/content/tegra/automotive/images/2016/solutions/pdf/end-to-end-dl-using-px.pdf
Sentdex's PyGta5 playlist: https://www.youtube.com/watch?v=ks4MPfMq8aQ&list=PLQVvvaa0QuDeETZEOy4VdocT7TOjfSA8a
NFS:MW mods are taken from: https://github.com/ExOptsTeam/NFSMWExOpts