
ethz-asl/maplab
ethz-asl/maplab has 2,887 GitHub stars and 750 forks. GitHot measured -1 stars in 24 hours. Last checked 2026-11-06 19:58 UTC. Last push 2024-05-31.
A Modular and Multi-Modal Mapping Framework
Measured star growth
- in 24h
- -1
- in 7 days
- Update delayed
- in 15 days
- Update delayed
- in 1 month
- Update delayed
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.md
Original
Ubuntu 18.04+ROS melodic:
News
- November 2022: maplab 2.0 initial release with new features and sensors. Paper.
- July 2018: Check out our release candidate with improved localization and lots of new features! Release 1.3.
- May 2018: maplab was presented at ICRA in Brisbane. Paper / Initial Release.
Description
This repository contains maplab 2.0, an open research-oriented mapping framework, written in C++, for multi-session and multi-robot mapping. For the original maplab release from 2018 the source code and documentation is available here.
For documentation, tutorials and datasets, please visit the wiki.
Features
Robust visual-inertial odometry with localization
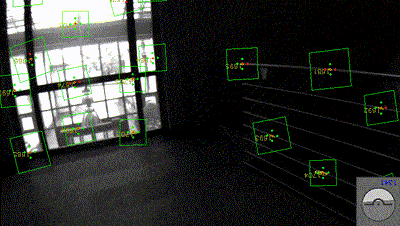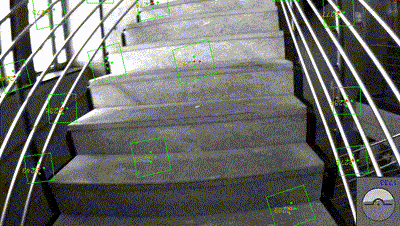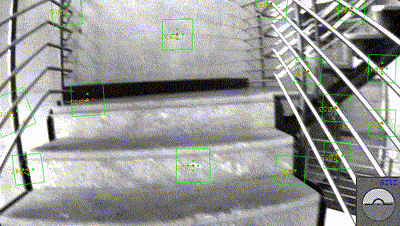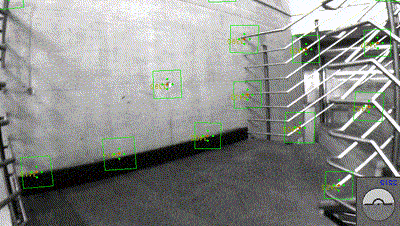
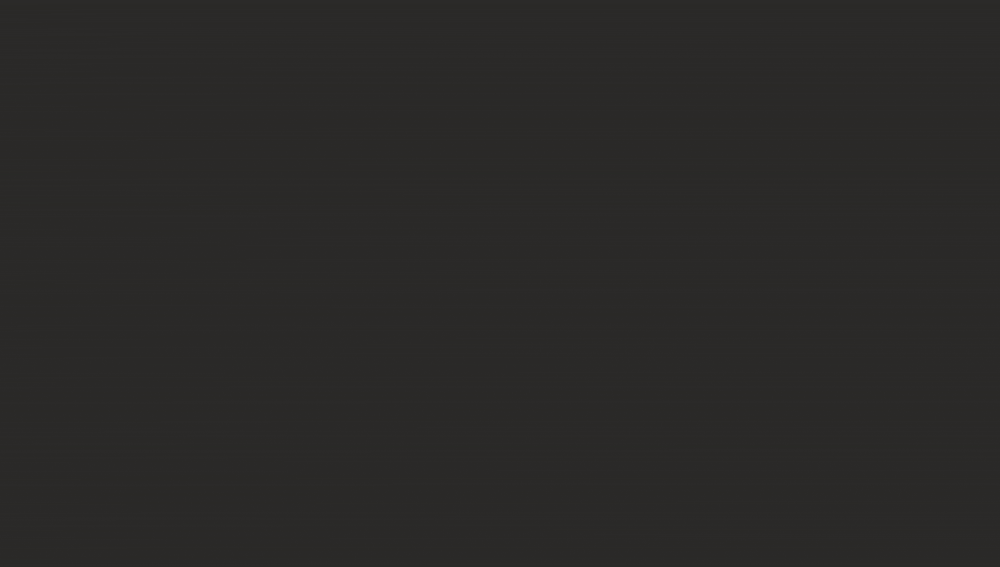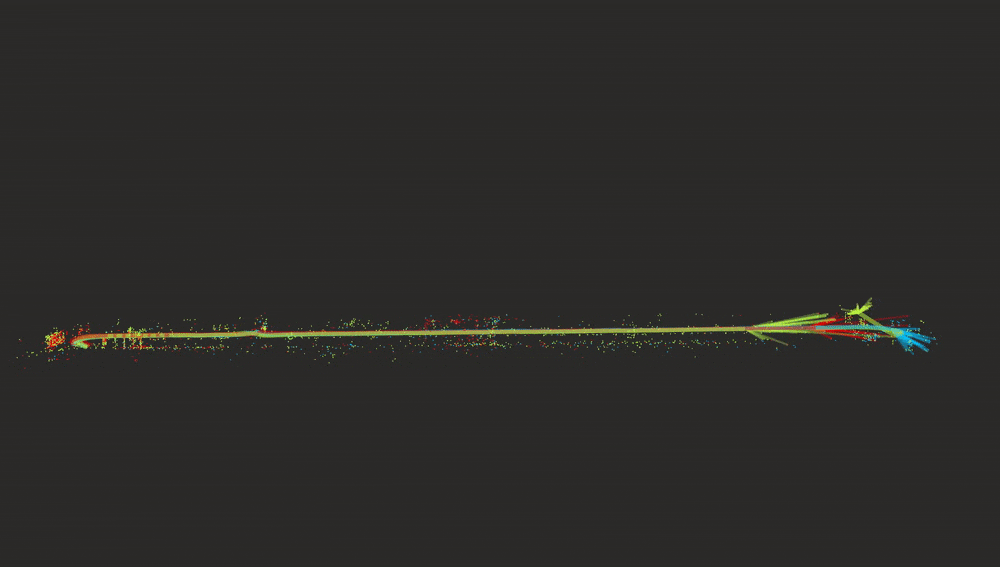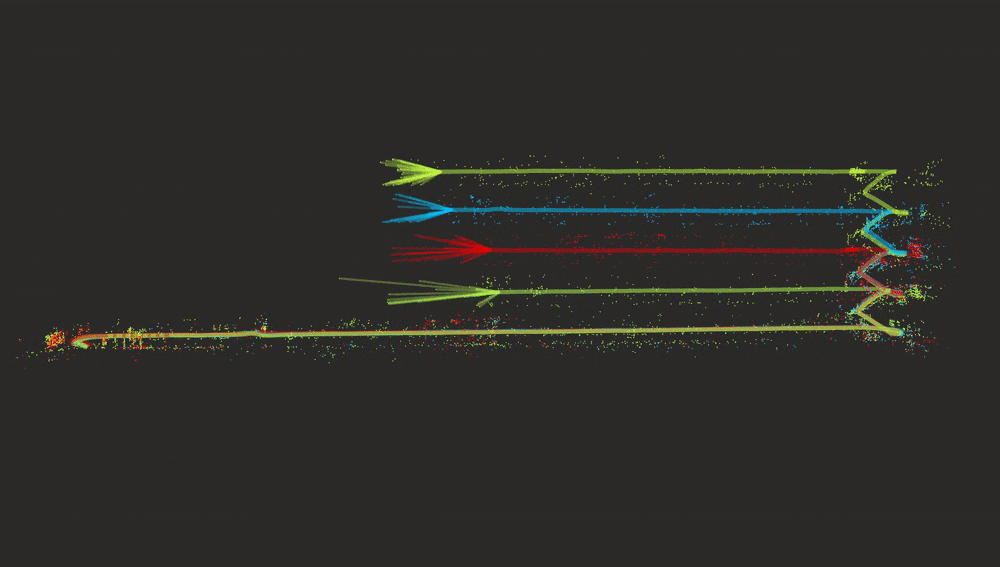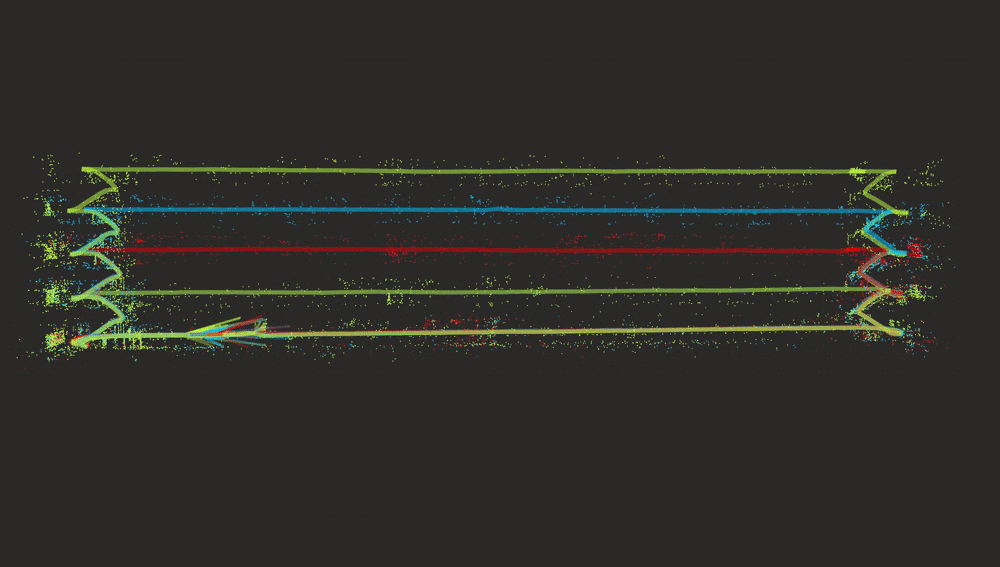
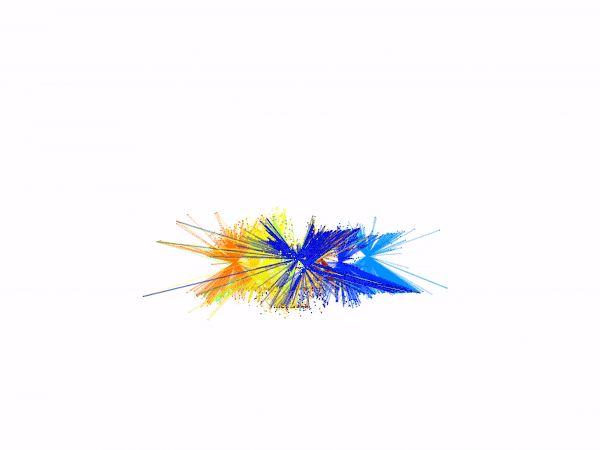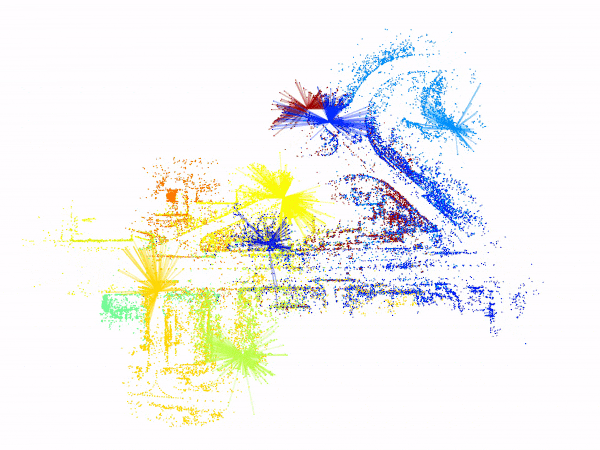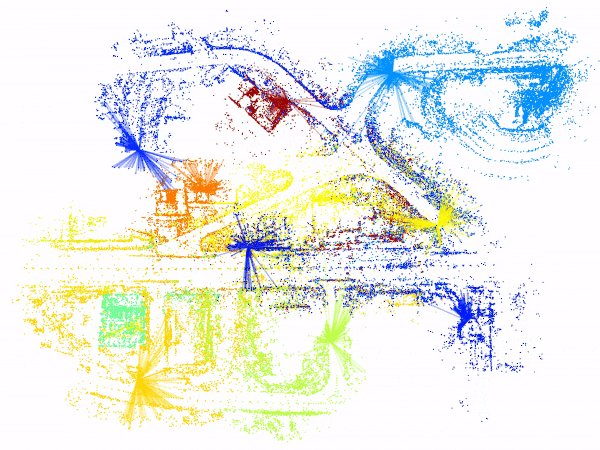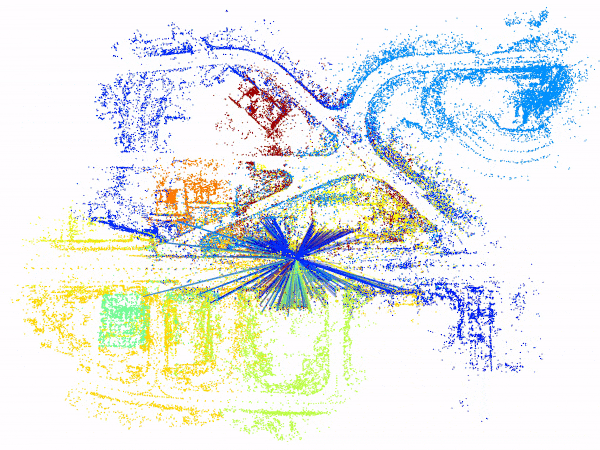
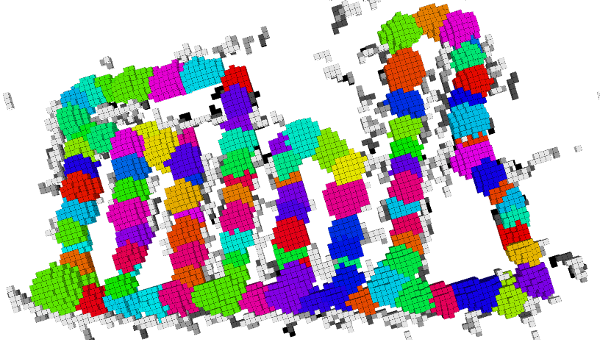
Large-scale multisession mapping and optimization
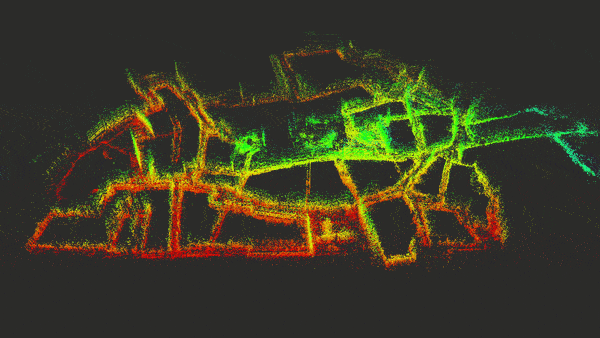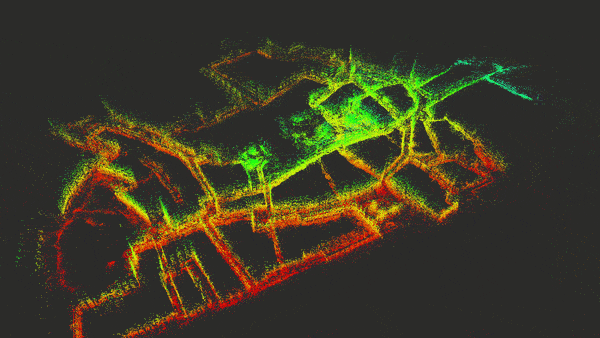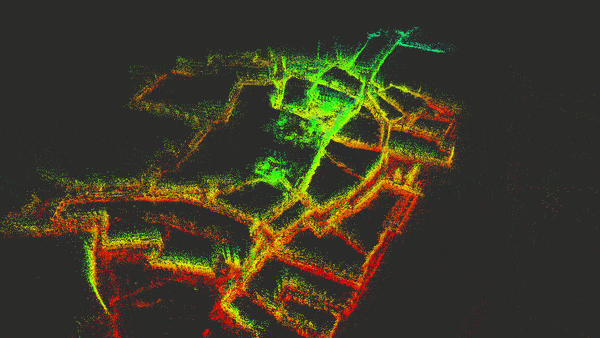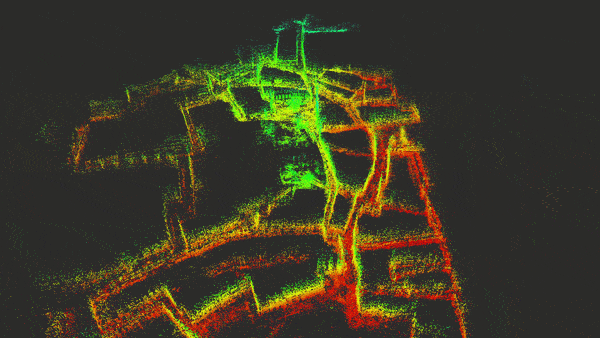
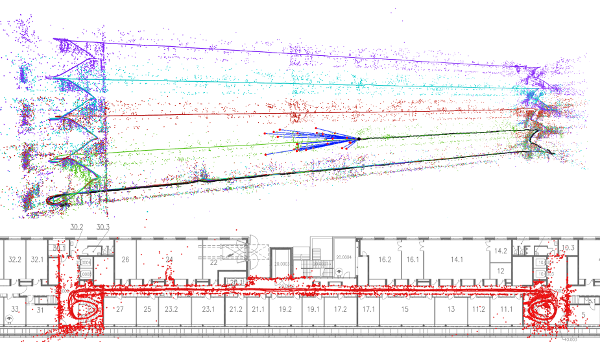
Multi-robot mapping and online operation
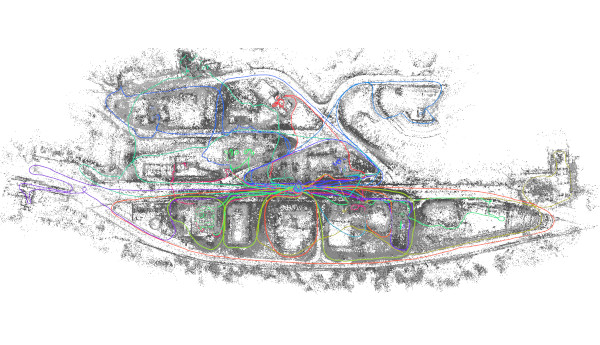
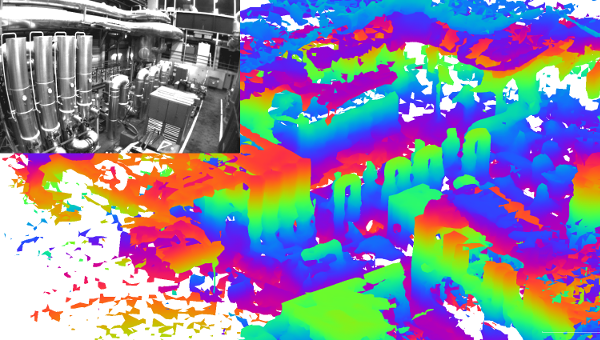
Dense reconstruction
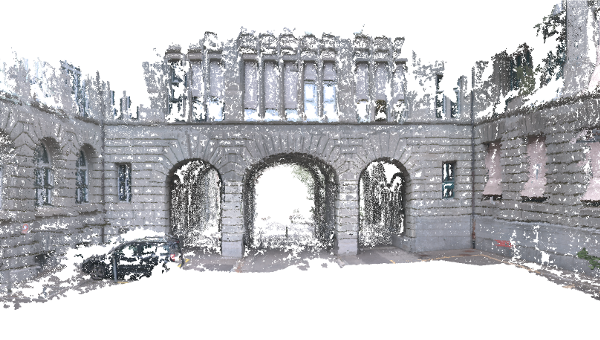
A research platform extensively tested on real robots
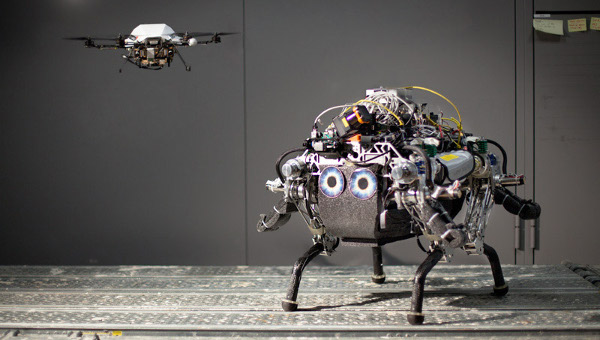
Installation and getting started
The following articles help you with getting started with maplab and ROVIOLI:
- Installation on Ubuntu 18.04 or 20.04
- Introduction to the maplab framework
- Running ROVIOLI in VIO mode
- Basic console usage
- Console map management
More detailed information can be found in the wiki pages.
Research Results
The maplab framework has been used as an experimental platform for numerous scientific publications. For a complete list of publications please refer to Research based on maplab.
Citing
Please cite the following papers maplab and maplab 2.0 when using our framework for your research:
@article{schneider2018maplab,
  title={{maplab: An Open Framework for Research in Visual-inertial Mapping and Localization}},
  author={T. Schneider and M. T. Dymczyk and M. Fehr and K. Egger and S. Lynen and I. Gilitschenski and R. Siegwart},
  journal={IEEE Robotics and Automation Letters},
  volume={3},
  number={3},
  pages={1418--1425},
  year={2018},
  doi={10.1109/LRA.2018.2800113}
}
@article{cramariuc2022maplab,
  title={{maplab 2.0 – A Modular and Multi-Modal Mapping Framework}},
  author={A. Cramariuc and L. Bernreiter and F. Tschopp and M. Fehr and V. Reijgwart and J. Nieto and R. Siegwart and C. Cadena},
  journal={IEEE Robotics and Automation Letters},
  volume={8},
  number={2},
  pages={520-527},
  year={2023},
  doi={10.1109/LRA.2022.3227865}
}
Additional Citations
Certain components of maplab are directly based on other publications.
Credits
- Thomas Schneider
- Marcin Dymczyk
- Marius Fehr
- Kevin Egger
- Simon Lynen
- Mathias Bürki
- Titus Cieslewski
- Timo Hinzmann
- Mathias Gehrig
- Florian Tschopp
- Andrei Cramariuc
- Lukas Bernreiter
For a complete list of contributors, have a look at CONTRIBUTORS.md
Explore related projects
codecrafters-io/build-your-own-x
Master programming by recreating your favorite technologies from scratch.
560,534 starspublic-apis/public-apis
A collective list of free APIs
496,817 starsmorluto/rea
Reverse engineer anything with agents, from app behavior down to native binaries.
438,889 starsopenclaw/openclaw
The AI that really does things. Any OS. Any Platform. The lobster way. 🦞
394,094 stars