
datawhalechina/every-embodied
datawhalechina/every-embodied has 4,431 GitHub stars and 432 forks. GitHot measured +13 stars in 24 hours and +96 in 7 days. Last checked 2026-11-09 13:53 UTC. Last push 2026-10-30.
仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能
Measured star growth
- in 24h
- +13
- in 7 days
- +96
- in 15 days
- Update delayed
- in 1 month
- Update delayed
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.en.md
Original🤖 AI Hardware and Robotics Tutorial 🛠️
中文 | English
A one-stop open-source tutorial library for learning robotics technology
Introduction • Table of Contents • Learning Path • Environment Requirements • Update Log
📖 Project Introduction
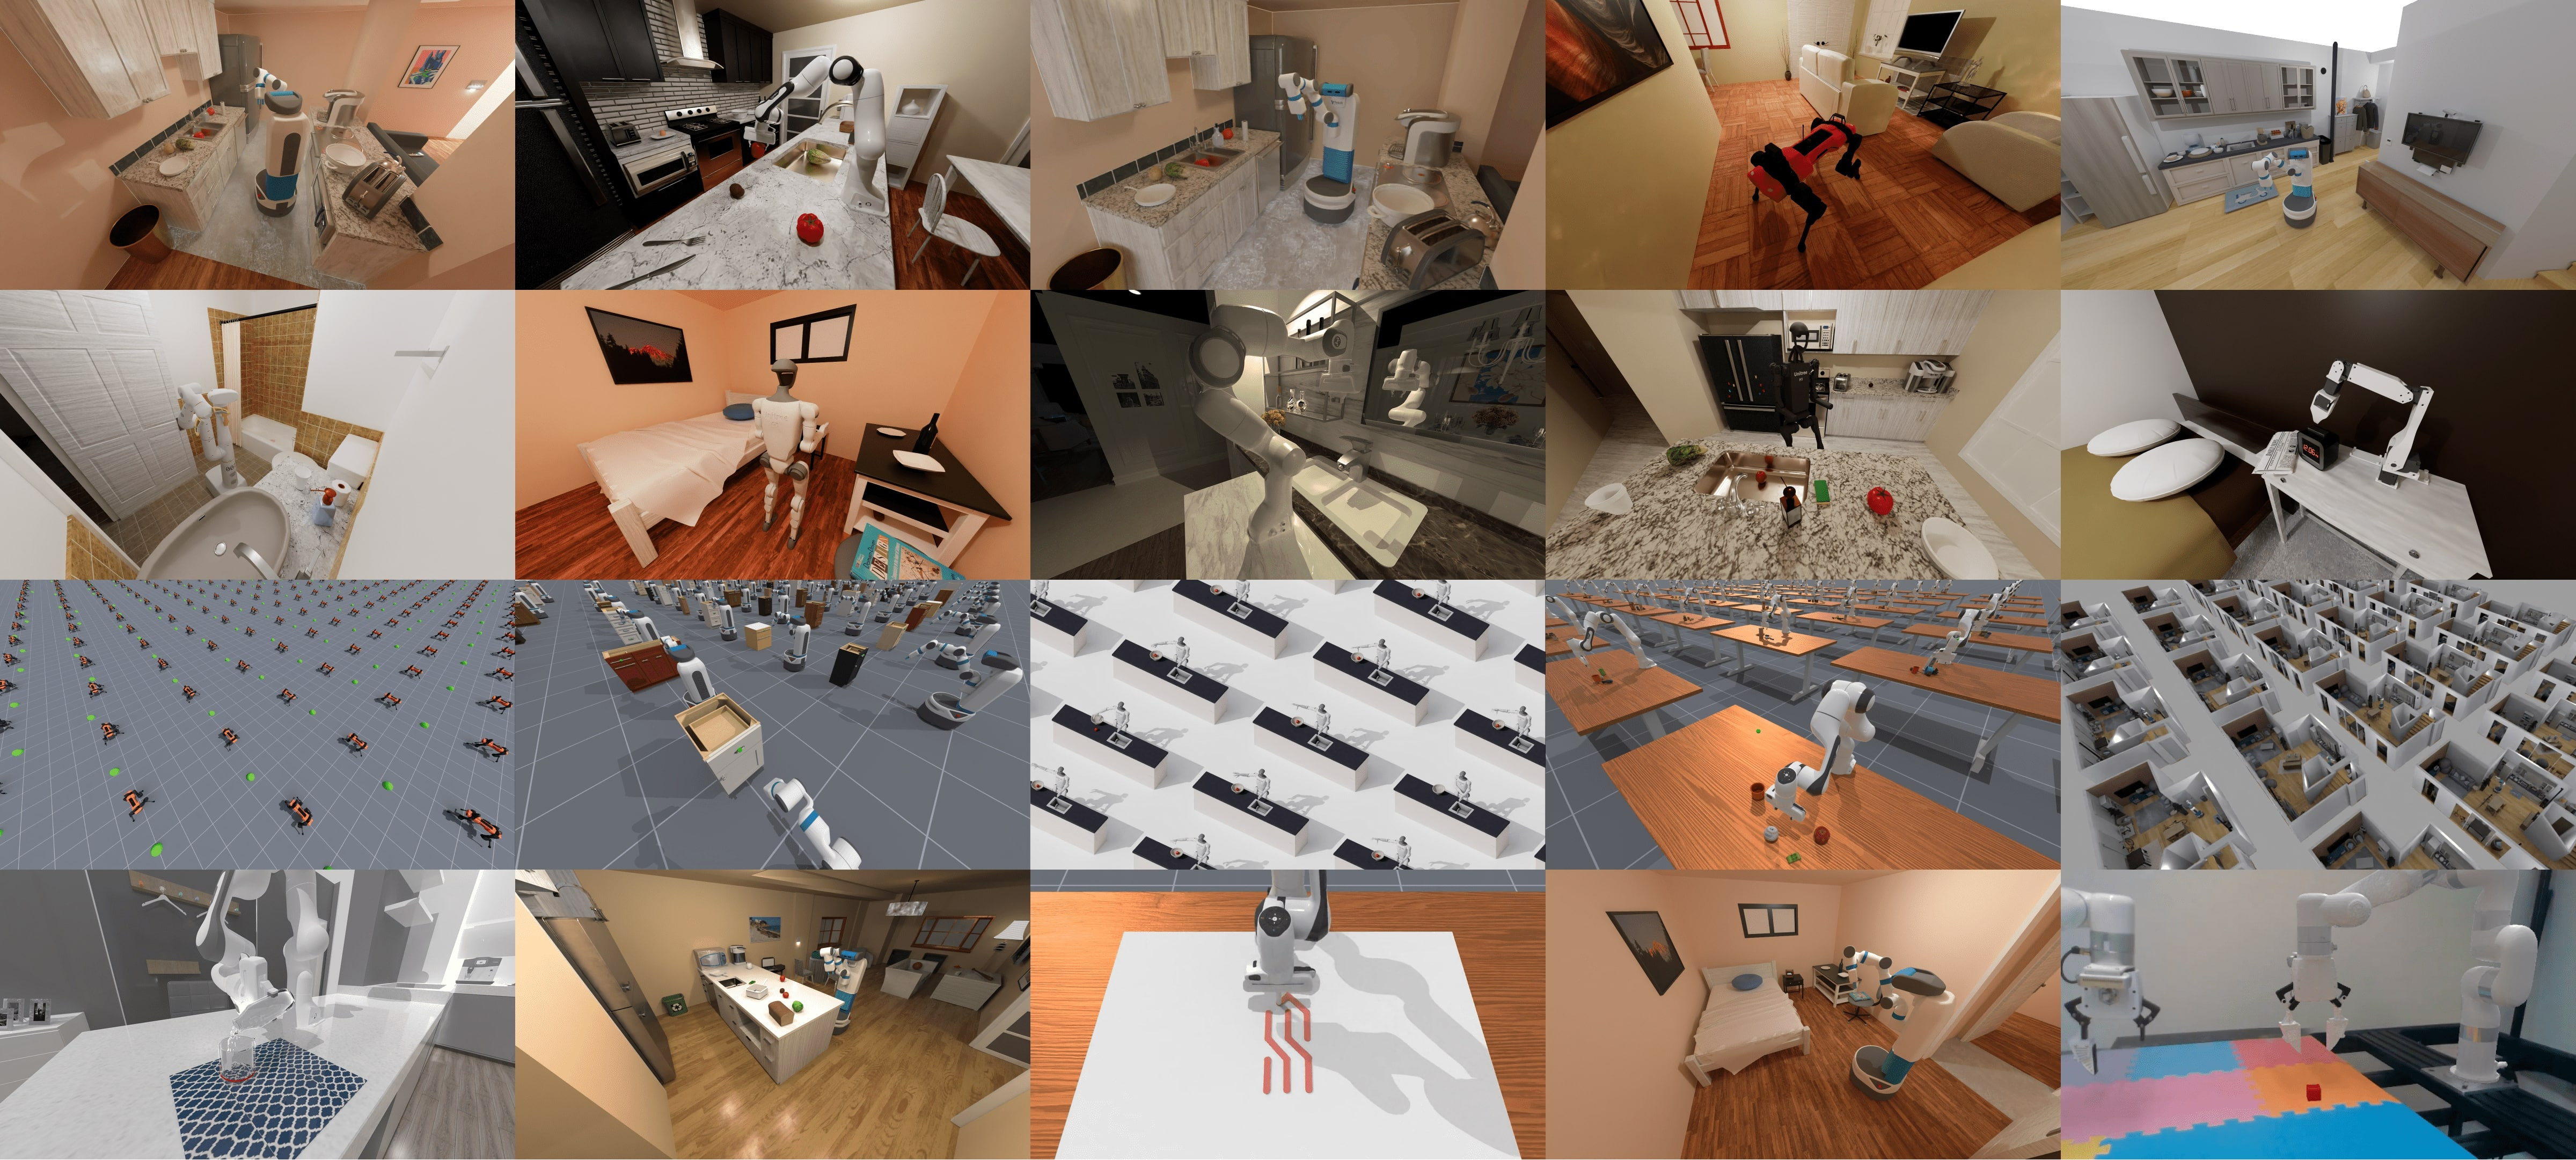
This repository collects and organizes tutorial materials related to AI hardware and robotics technology, covering various aspects such as robot simulation environment configuration, control algorithm implementation, hardware development, and hand-eye coordination. It is suitable for beginners and researchers in robotics technology to learn and reference.
💡 Why choose this tutorial?
- 📚 Comprehensive content: A systematic learning path from basic to advanced
- 🔧 Practical orientation: Contains a large number of practical code examples and application cases
- 🌐 Continuous updates: Tracks the latest technological developments and application trends
- 👨👩👧👦 Community support: Provides a platform for communication and problem-solving
✨ Latest Highlights
[2026-10-25] HIL-SERL and MuJoCo insertion (Chinese guide): illustrated intervention data flow, dual replay buffers, insertion success criteria, and official Panda simulation and training entry points.
[2026-10-23] Agnes Harness device demos (Chinese guide): pinned source, Ubuntu setup, real virtual-device checks, plugin tests, and focused screenshots. Manual and simulated-model routes require no API key.
🍳 Smart Home Assistant
Our new home robot module can perform multiple kitchen tasks, including:
- Object recognition and grasping (vegetables, fruits, kitchen utensils, etc.)
- Environmental cleaning and organization (detailed tutorial to be implemented)
🧠 Reinforcement Learning Framework
The new reinforcement learning module supports:
- Implementation of multiple algorithms (PPO, SAC, TD3, etc.)
- Hybrid learning from imitation to reinforcement
- Performance evaluation and visualization tools
 |
 |
 |
| Robotic Arm Light and Shadow Rendering | Getting Coffee | Indoor Gaussian Splatting |
 |
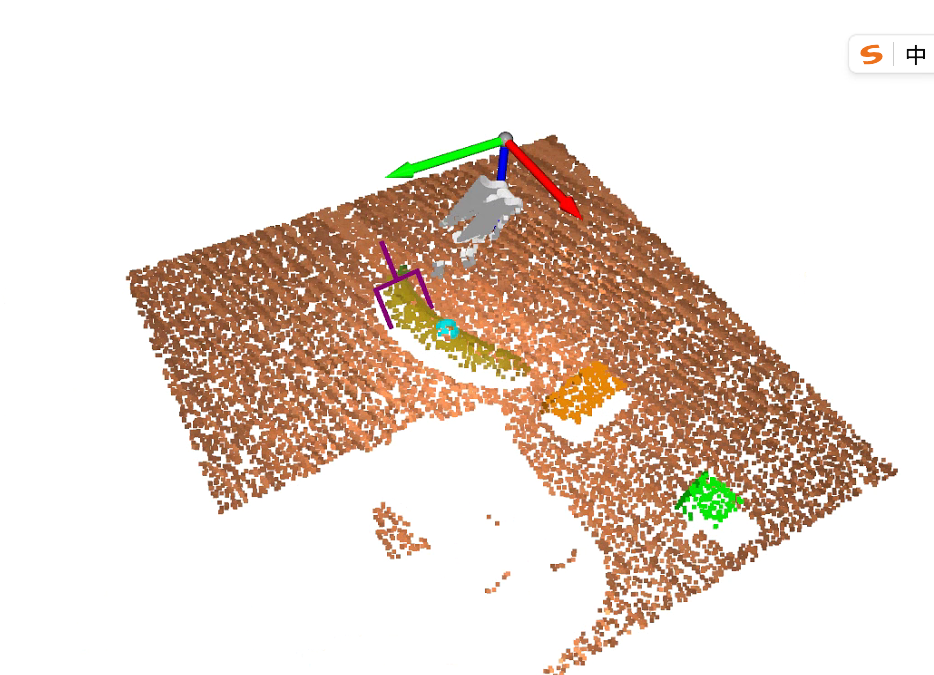 |
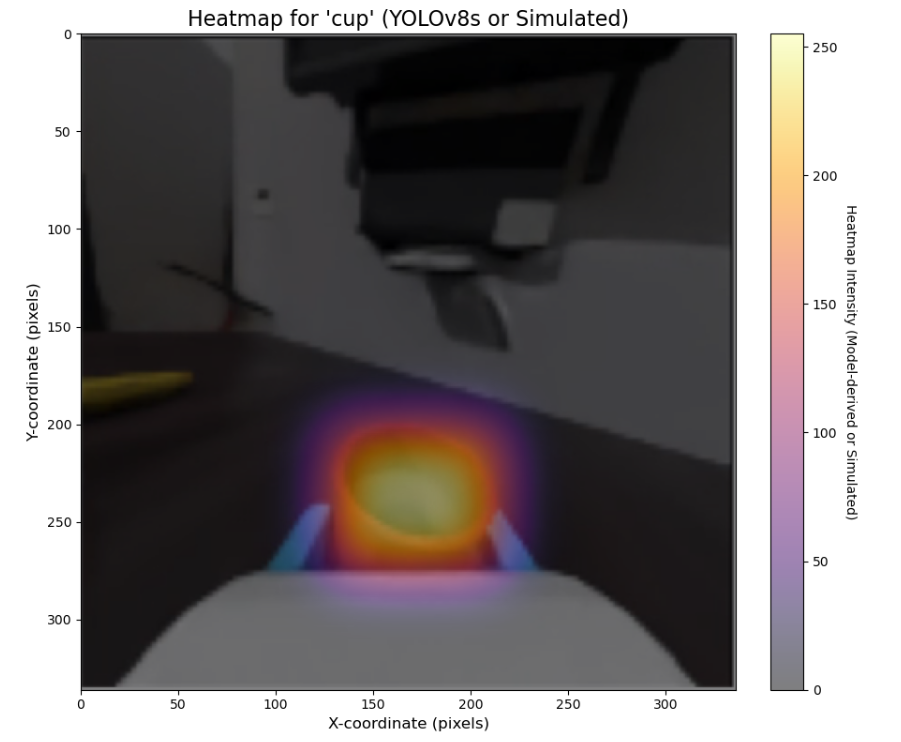 |
| Indoor Scene Segmentation | Robotic Arm Banana Grasping | Grasping Attention Visualization |
 |
 |
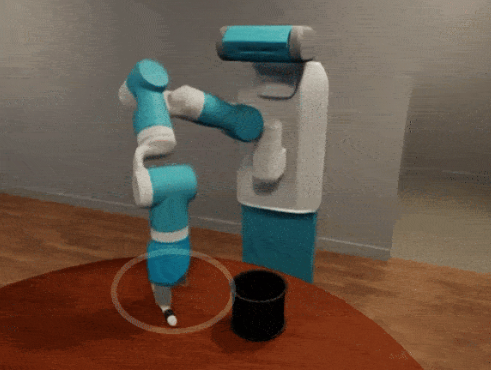 |
| Robotwin 1.0 Reproduction | Lerobot Simulation Support | OmniGibson |
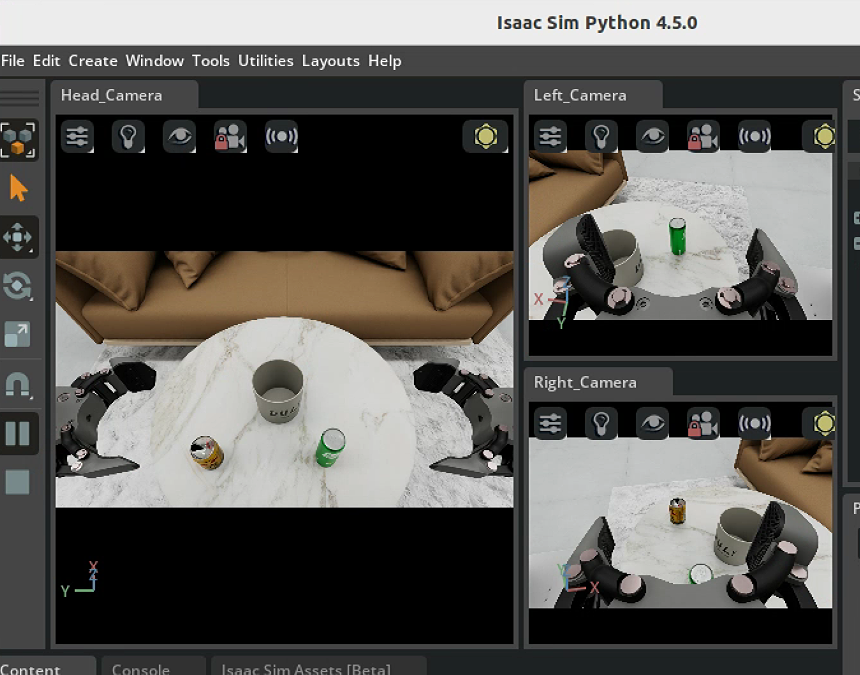 |
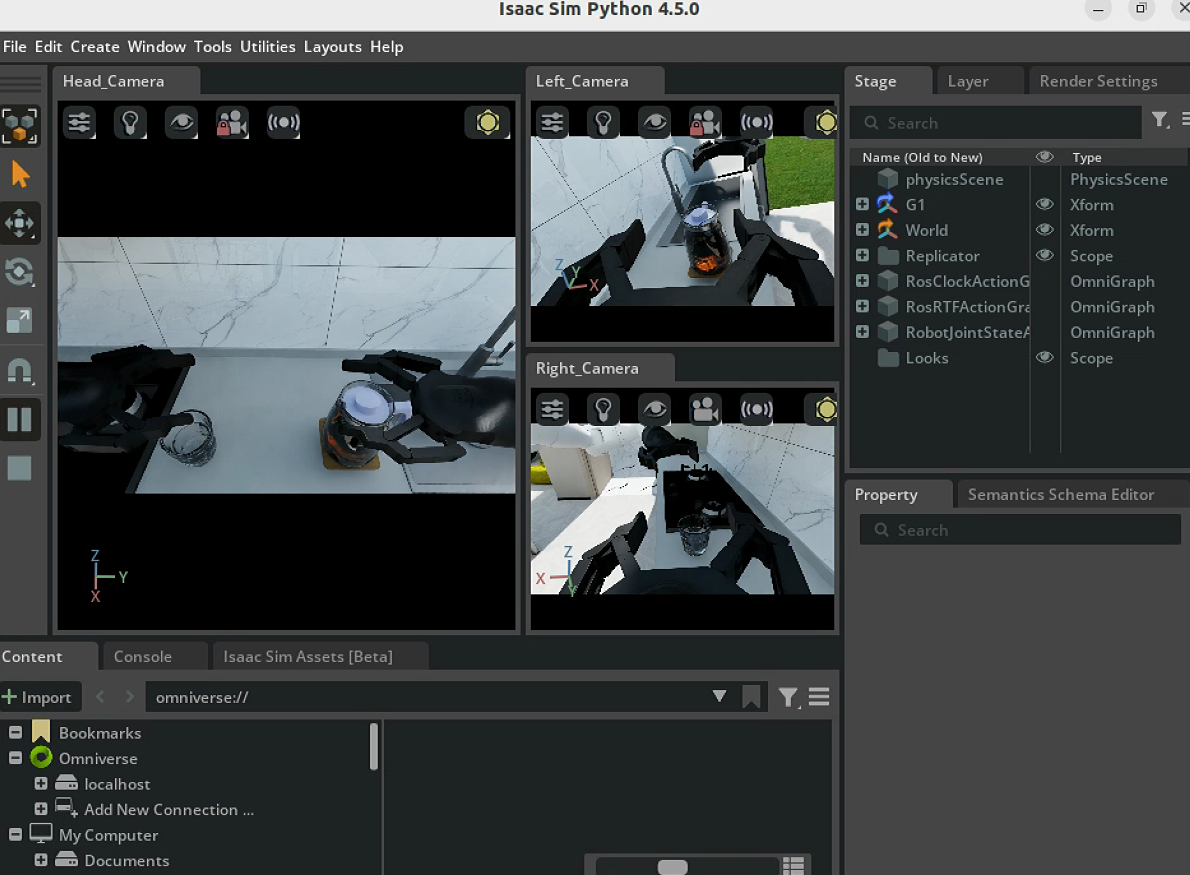 |
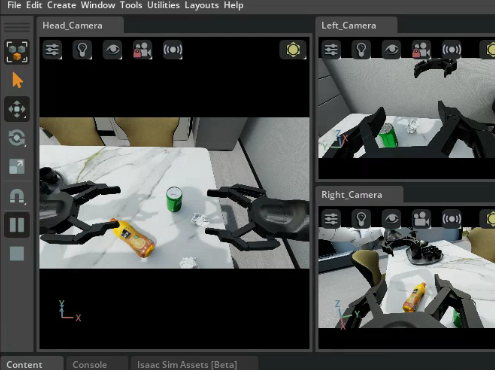 |
| Zhiyuan Robot Multi-task 1 | Zhiyuan Robot Multi-task 2 | Zhiyuan Robot Multi-task 3 |
 |
|
|
| DiGua RDK-X5 connects to lerobot-so101 for teleoperation | Zhiyuan Robot Keyboard Operation | Zhiyuan Robot Trajectory Recording |
Lightweight World-Action Models
- SmolWAM (Chinese guide): five interface changes distilled from Cosmos Policy, with three official figures, LIBERO results, and inference and training entry points.
🚀 Learning Path Suggestion
Embodied AI Robot
Overview of Embodied Intelligence
- Definition and Background
- Development History
- Application Areas
Robot Basics
- Basic Concepts of Robotics
- Kinematics and Dynamics
- Sensors and Actuators
- Robot Hardware Selection
- Using DiGua Robot RDK and connecting to LeRobot SO101
- Ajiaxi Development Board Tutorial
- Circuit Design (todo)
- AutoCAD and Solidworks (todo)
- Communication Protocols (todo)
- ROS Basics (todo)
Computer Vision
- Basics of Image Processing
- Object Detection and Recognition
- Image Segmentation
- Pose Estimation
Robot Control
- Motion Planning
- Path Planning
- Control Algorithms
Deep and Reinforcement Learning in Embodied Scenarios
- Reinforcement Learning
Hand-Eye Coordination
- Hand-Eye Calibration
- Grasping and Manipulation
Simulation Environment Learning
- Issac Sim/Issac Gym
- Pybullet
- Gazebo (todo)
- Genie-Sim
Cutting-edge Embodied Intelligence Projects (Reproduced)
- Google Embodied Projects: RT-RT1, RT2, RTX (todo)
- OmniGibson
- BitVLA
- RoboBrain2.0 (todo)
- Aloha-ACT (todo)
- OpenVLA (todo)
- Octo (todo)
- AngGrasp (todo)
- Other paper reproductions and code
🔧 Environment Requirements
- Python 3.8+
- CUDA support (for 3D simulation rendering, some experiments can be run on CPU)
- ROS/ROS2 (optional, for actual robot control)
- MuJoCo (physics engine)
- Isaac Sim (NVIDIA advanced simulation platform)
Thanks to the following partners for their participation and contributions:
howe, Miles, Maimang, HAO
Thanks to the following partners for their translation contributions:
- Chapters 1~3 Lune
- Chapters 4~5 Liu Yuanyang
- Chapters 6~7 Su Jiayu
- Chapters 8~9 Liang Jianbin leoliang023
🌟 Learning Community
- Join the discussion group: Exchange experiences with other learners
- FAQ: View common questions and solutions
- Technical Sharing Sessions: Regular online technical sharing sessions
👨💻 Contribution Guide
Welcome to submit Pull Requests to contribute more tutorials and sample code! 👏
- Fork this repository
- Open a Pull Request
Please ensure that the submitted content is relevant to the repository's theme and follows the existing file organization structure.
📬 Contact Information
If you have any questions or suggestions, please contact us through the following ways:
- 💬 WeChat Official Account: datawhale
- 🌐 Website: [https://datawhale.club/home]
Explore related projects
codecrafters-io/build-your-own-x
Master programming by recreating your favorite technologies from scratch.
561,398 starspublic-apis/public-apis
A collective list of free APIs
497,679 starsmorluto/rea
Reverse engineer anything with agents, from app behavior down to native binaries.
447,495 starsopenclaw/openclaw
The AI that really does things. Any OS. Any Platform. The lobster way. 🦞
394,261 stars