
but0n/Avem
but0n/Avem has 2,938 GitHub stars and 584 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-06 19:52 UTC. Last push 2023-10-03.
🚁 轻量级无人机飞控-[Drone]-[STM32]-[PID]-[BLDC]
Measured star growth
- in 24h
- 0
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.md
Original


Avem :bird:
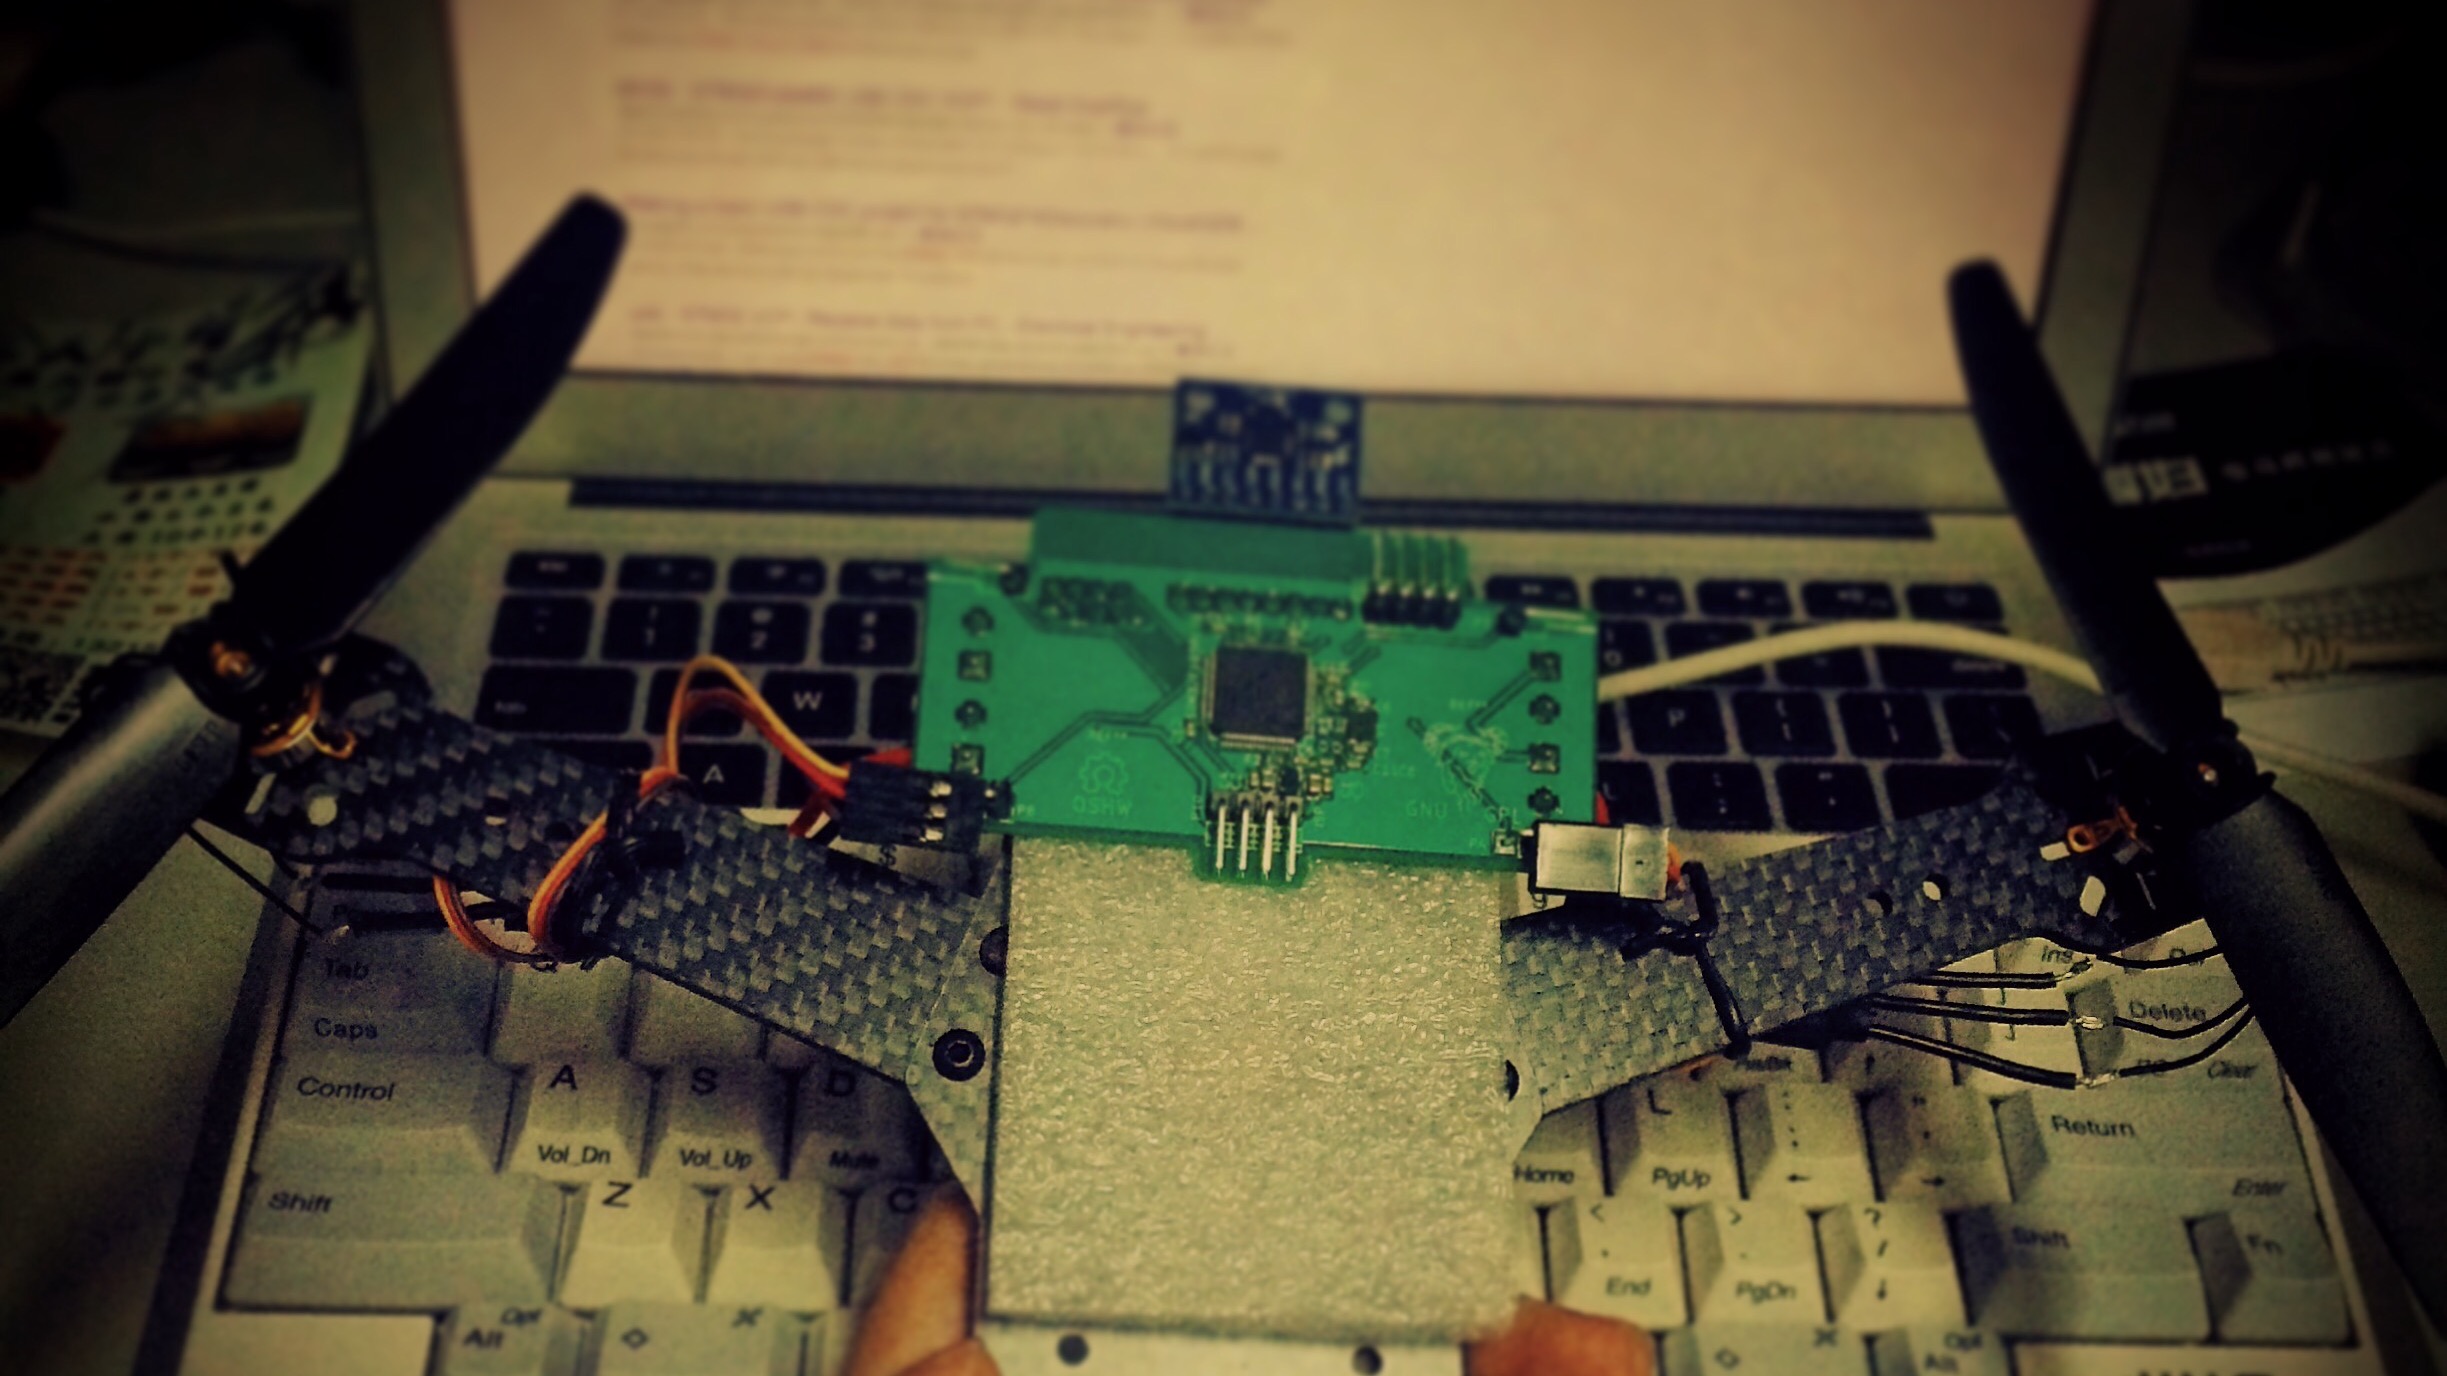
[UAV] - [STM32F103] - 6 Axes sensor MPU6050 - Quaternion & Euler Angles Compute - PID Controller
Terminal demo
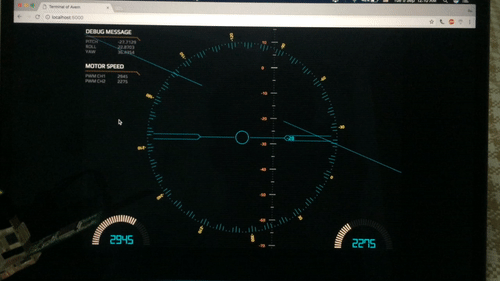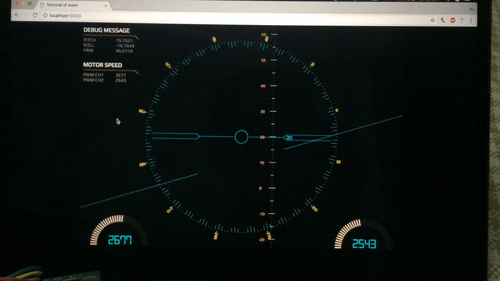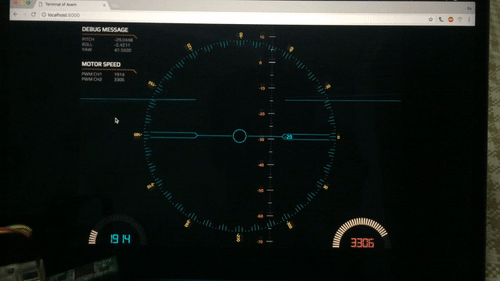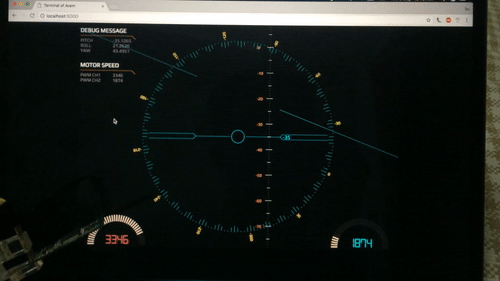

https://github.com/but0n/Avem_HUD
I/O List
MPU6050 | BLDC | Wi-Fi | GPS
:----: |:----: |:----: |:---:
SCL PB15 |Channel 1 PA6|USART3_TX PB10 |TBD
SDA PB14 |Channel 2 PA7|USART3_RX PB11 |TBD
||Channel 3 PB0| | |
||Channel 4 PB1| | |
To-do list
- Software I2C
- Init MPU6050
- Get 3 axes
Gryoand 3 axesAcceldata from MPU6050 - Cumpute Quaternion and Euler Angles
- PWM output
- Driving motors with L9110S
- PID Control
- Schematic
- PCB Layout
- Brushless DC motor-Video via YouTube
- Wi-Fi(
ESP8266) - Cascade PID control
- FreeRTOS
- Host: Flask + pyserial
- PID debug
- GPS
Hardware

Schematic

PCB Layout
Version 3.0

Made with ♥ by but0n
Explore related projects
codecrafters-io/build-your-own-x
Master programming by recreating your favorite technologies from scratch.
560,478 starspublic-apis/public-apis
A collective list of free APIs
496,785 starsmorluto/rea
Reverse engineer anything with agents, from app behavior down to native binaries.
438,437 starsopenclaw/openclaw
The AI that really does things. Any OS. Any Platform. The lobster way. 🦞
394,086 stars