
atb033/multi_agent_path_planning
atb033/multi_agent_path_planning has 1,472 GitHub stars and 309 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-08 05:18 UTC. Last push 2023-04-05.
Python implementation of a bunch of multi-robot path-planning algorithms.
Measured star growth
- in 24h
- 0
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.md
OriginalMulti-Agent path planning in Python
Introduction
This repository consists of the implementation of some multi-agent path-planning algorithms in Python. The following algorithms are currently implemented:
- Multi-Agent path planning in Python
Dependencies
Install the necessary dependencies by running.
python3 -m pip install -r requirements.txt
Centralized Solutions
In these methods, it is the responsibility of the central planner to provide a plan to the robots.
Prioritized Safe-Interval Path Planning
SIPP is a local planner, using which, a collision-free plan can be generated, after considering the static and dynamic obstacles in the environment. In the case of multi-agent path planning, the other agents in the environment are considered as dynamic obstacles.
Execution
For SIPP multi-agent prioritized planning, run:
cd ./centralized/sipp
python3 multi_sipp.py input.yaml output.yaml
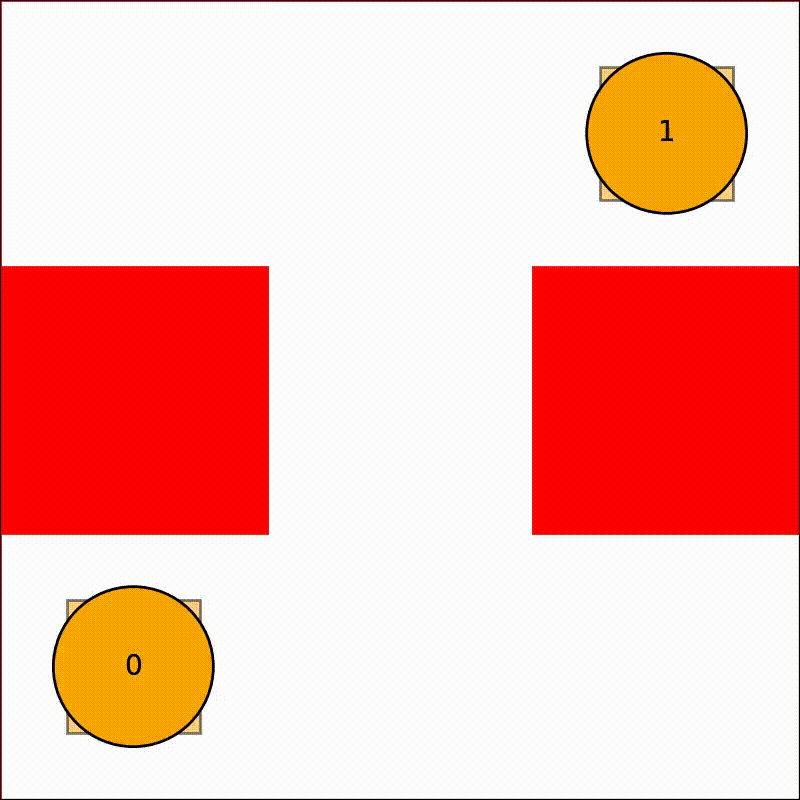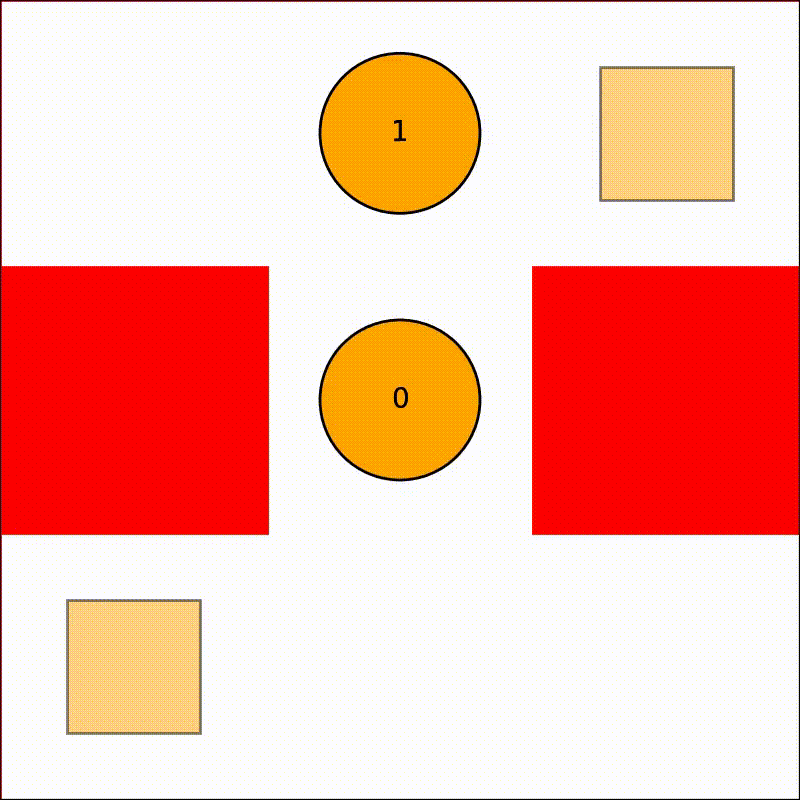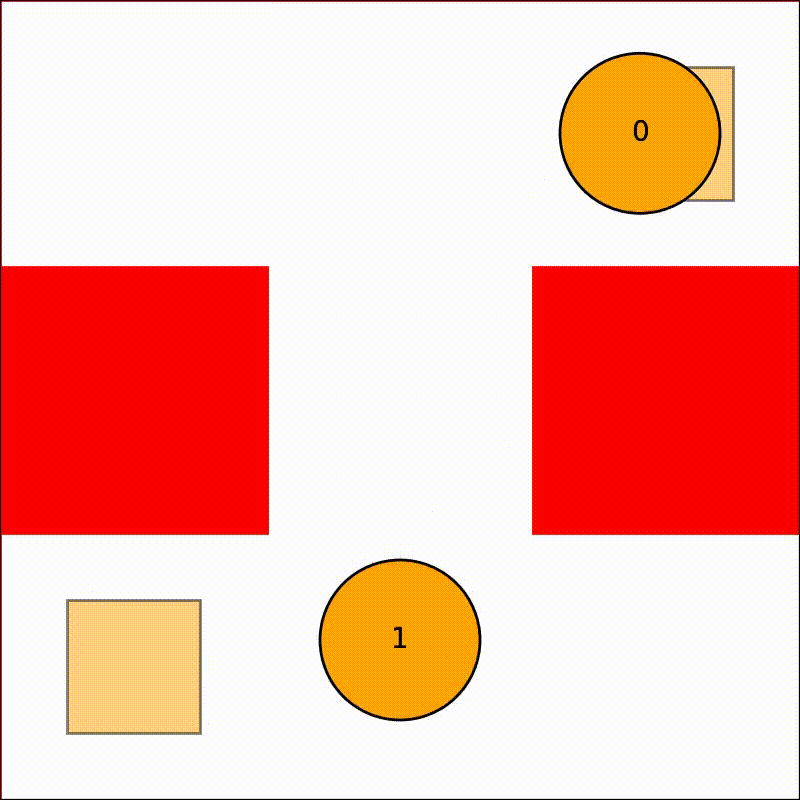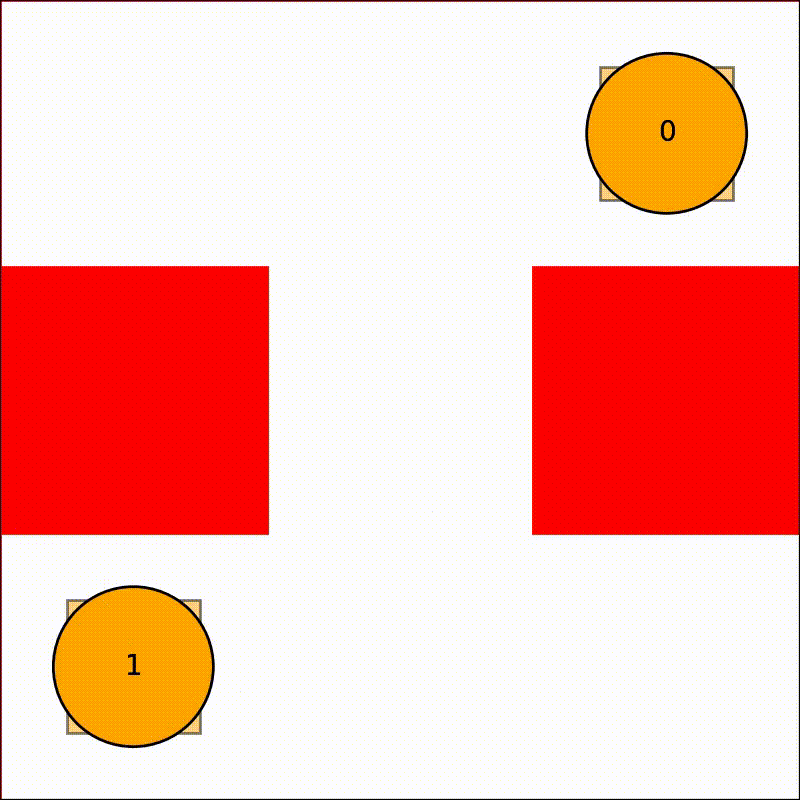
Results
To visualize the generated results
python3 visualize_sipp.py input.yaml output.yaml
To record video
python3 visualize_sipp.py input.yaml output.yaml --video 'sipp.avi' --speed 1
| Test 1 (Success) | Test 2 (Failure) |
|---|---|
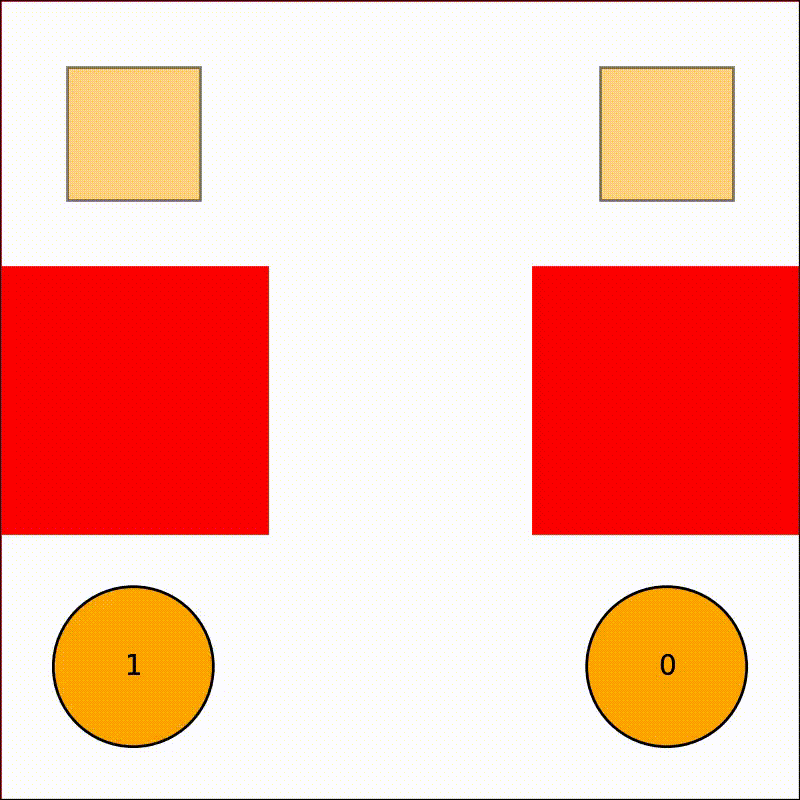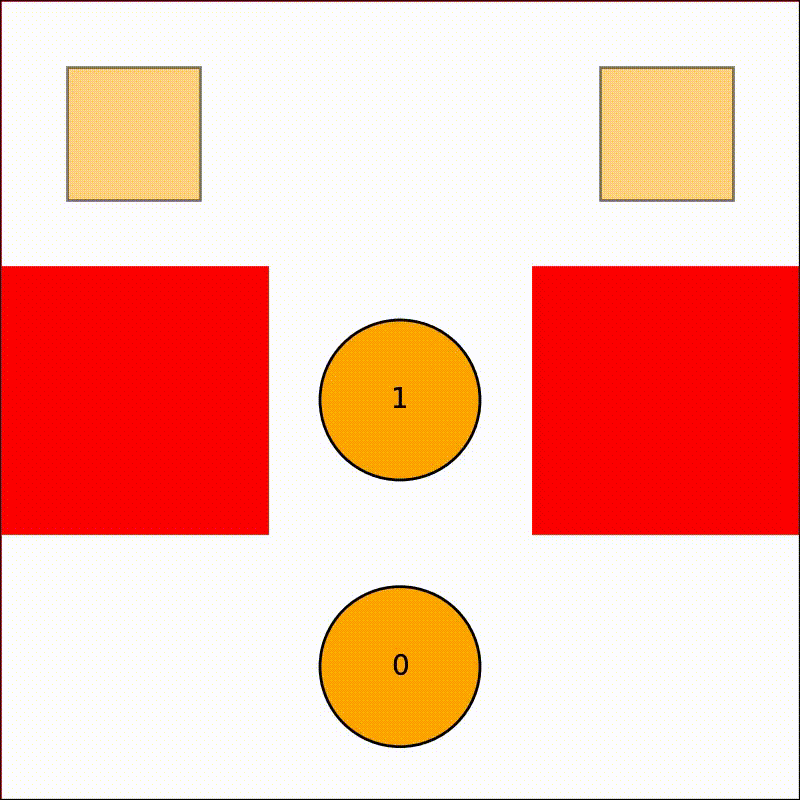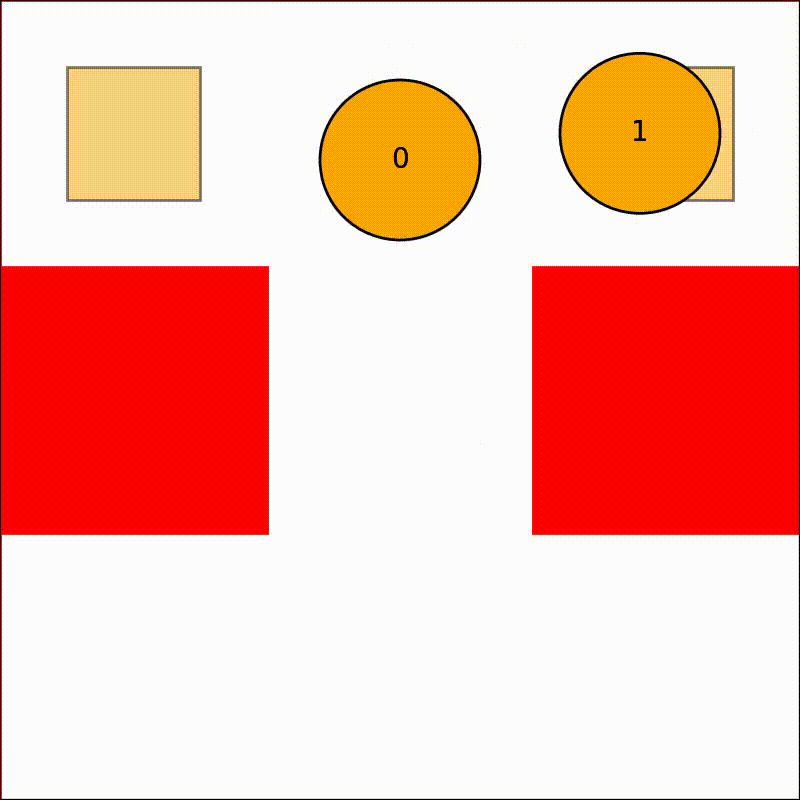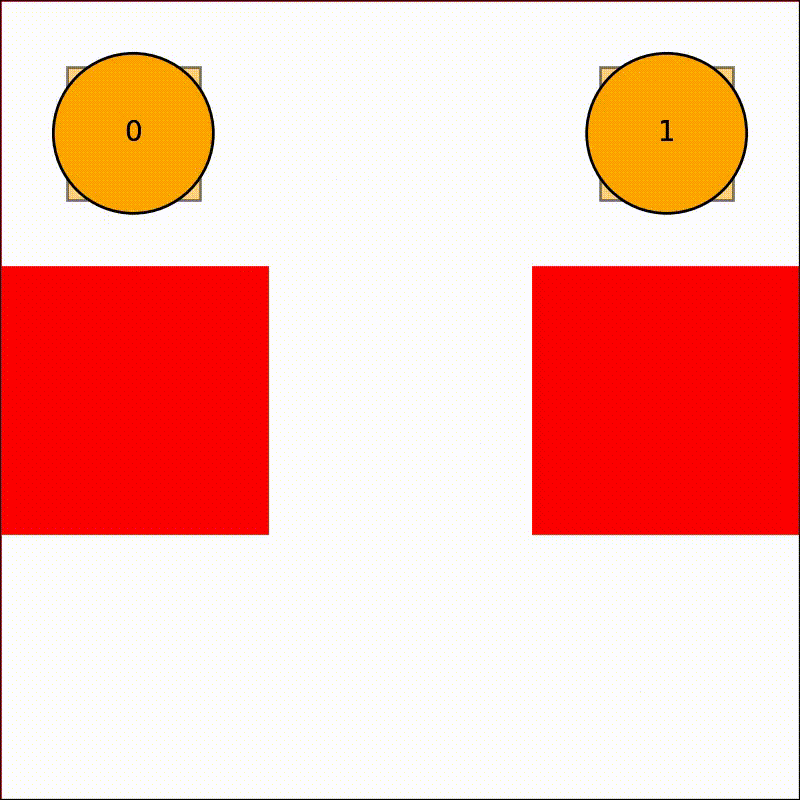 |
 |
Reference
Conflict Based Search
Conclict-Based Search (CBS), is a multi-agent global path planner.
Execution
Run:
cd ./centralized/cbs
python3 cbs.py input.yaml output.yaml
Results
To visualize the generated results:
python3 ../visualize.py input.yaml output.yaml
| Test 1 (Success) | Test 2 (Success) |
|---|---|
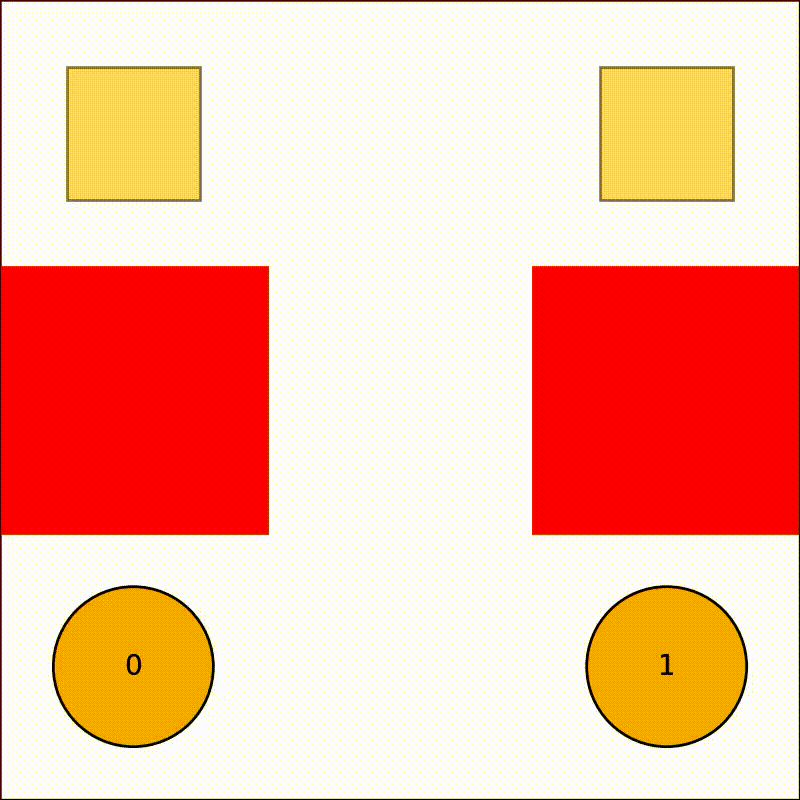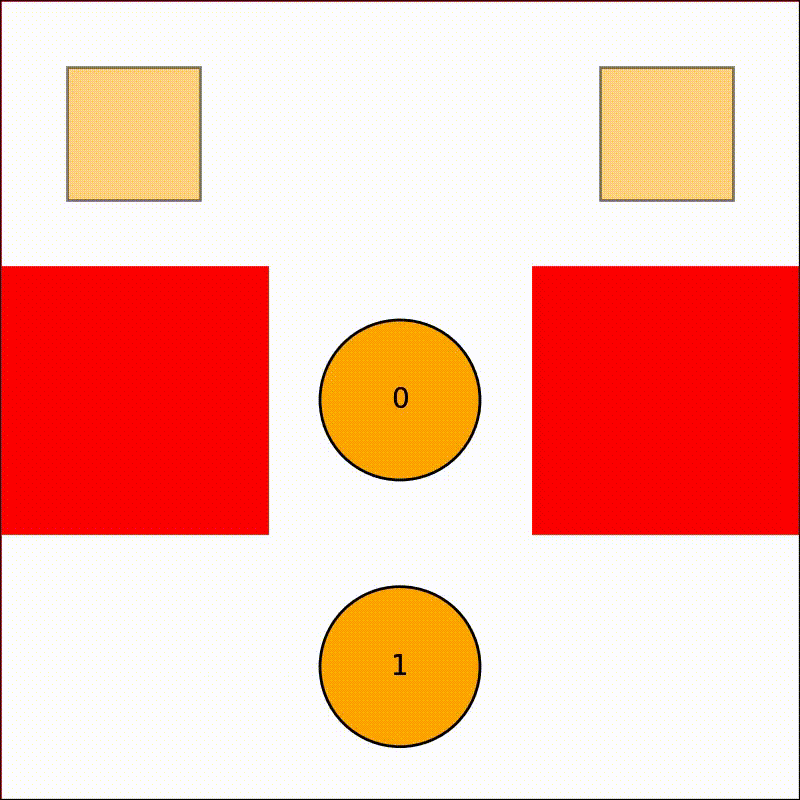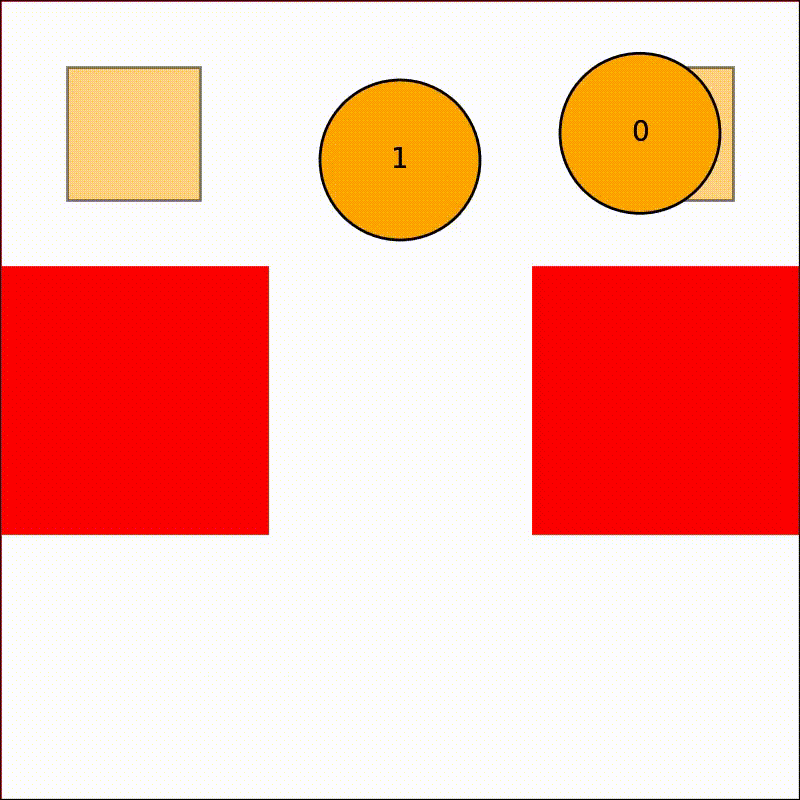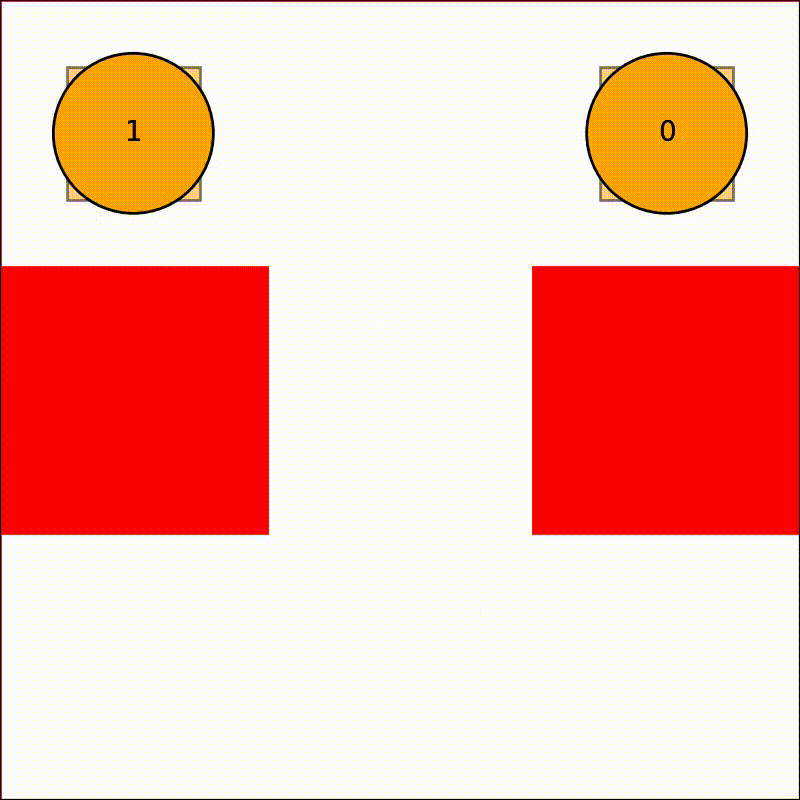 |
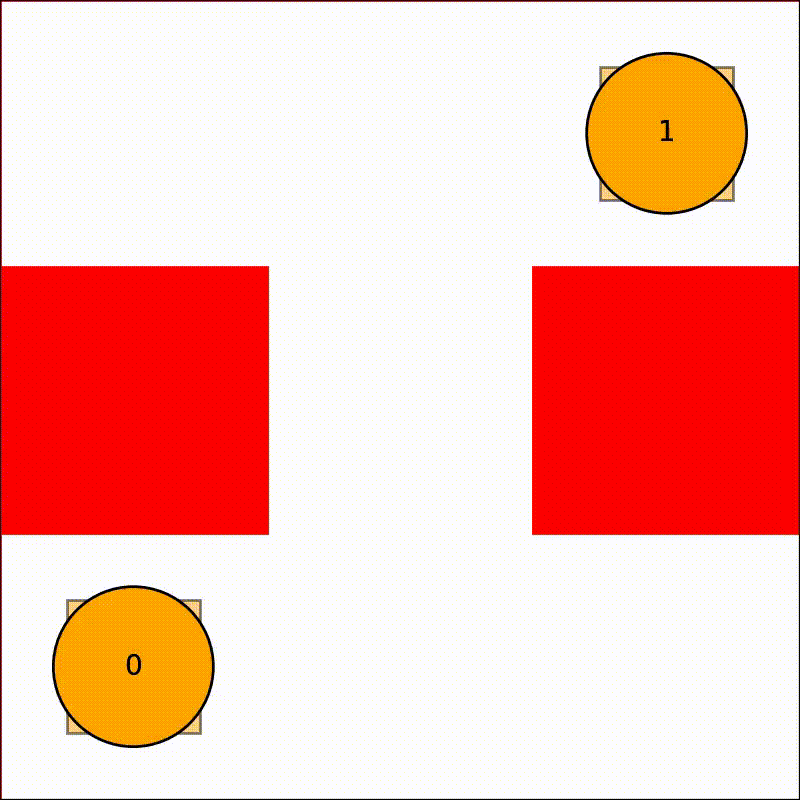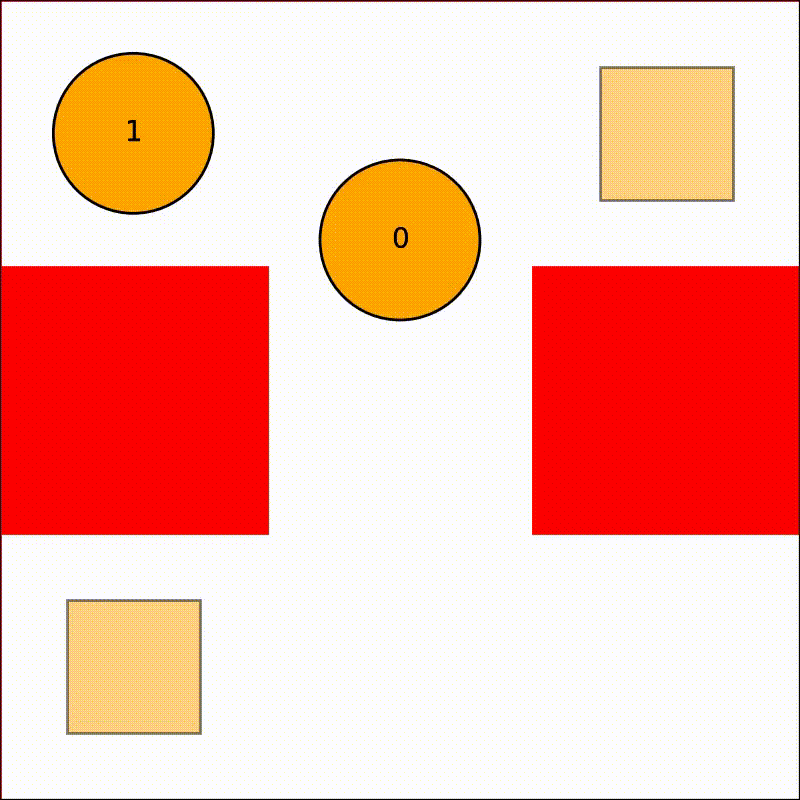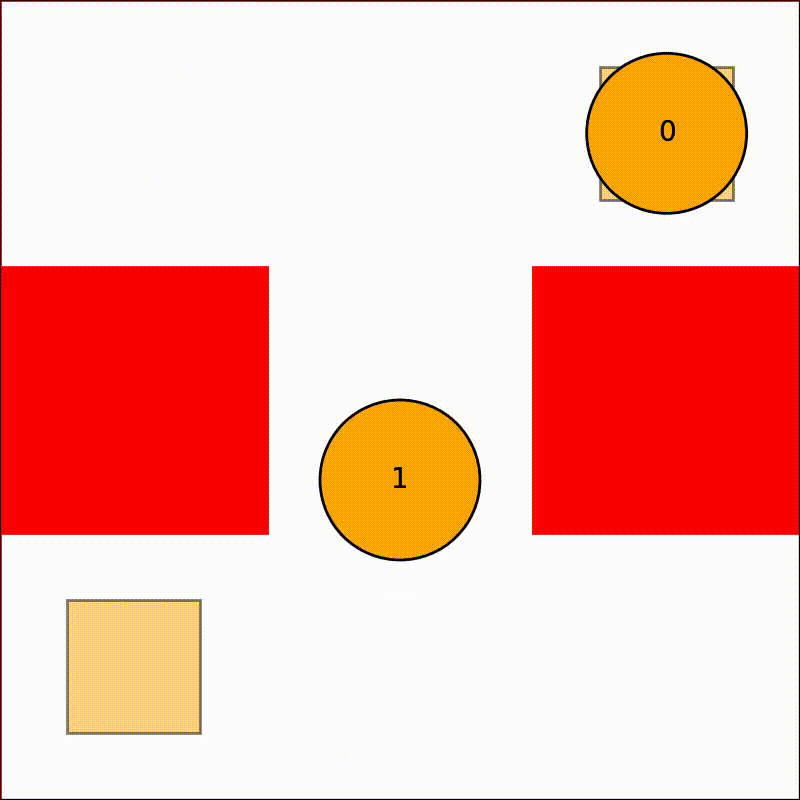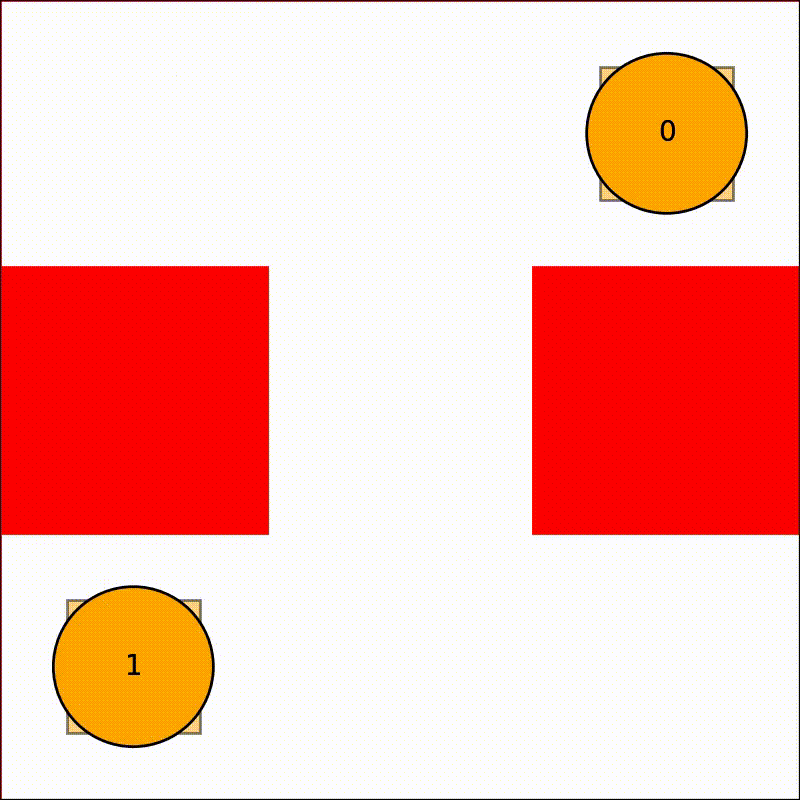 |
| 8x8 grid | 32x32 grid |
|---|---|
 |
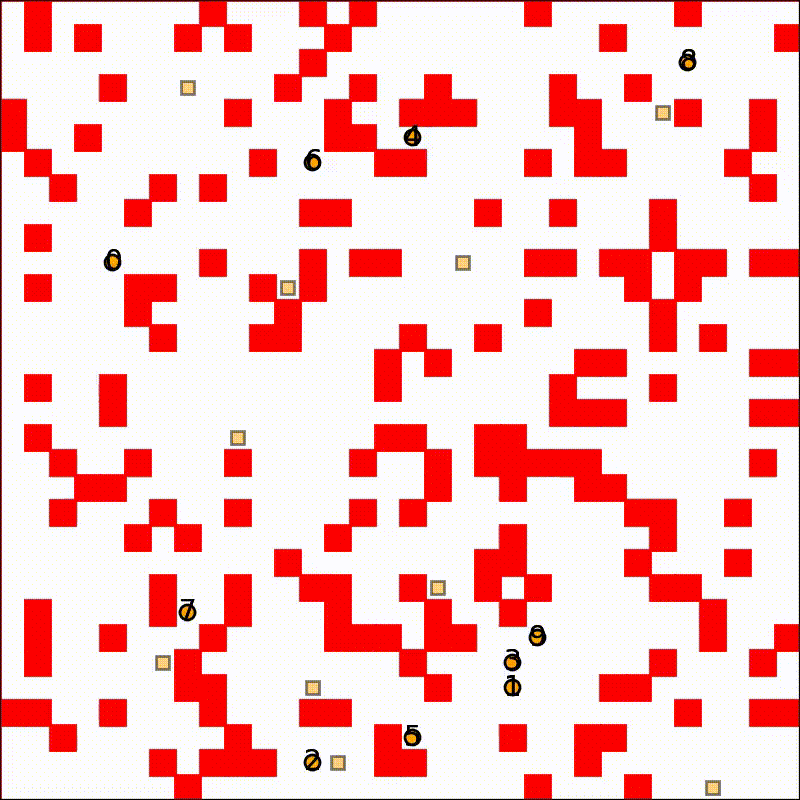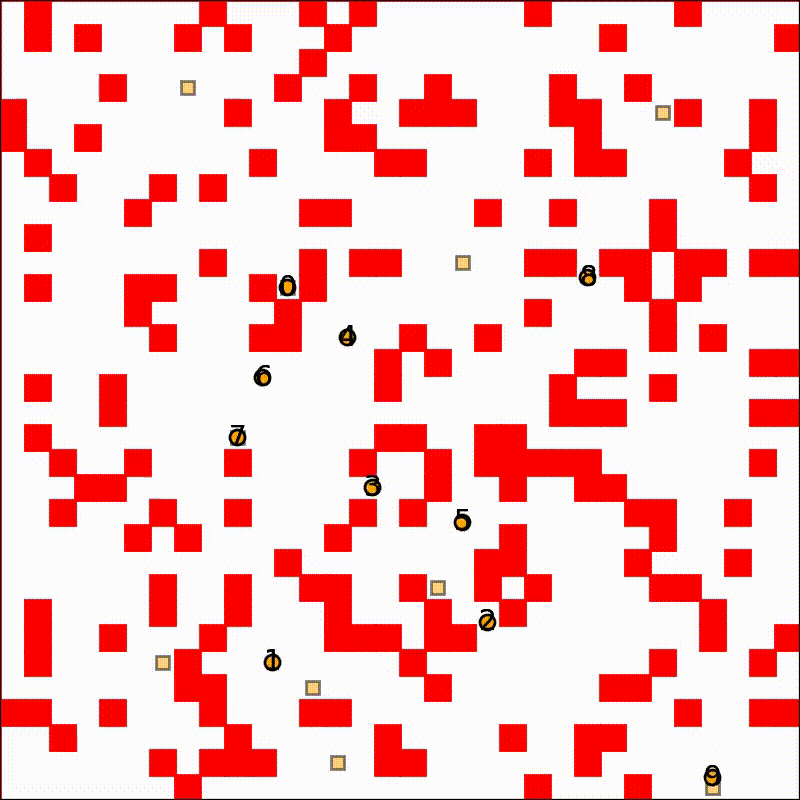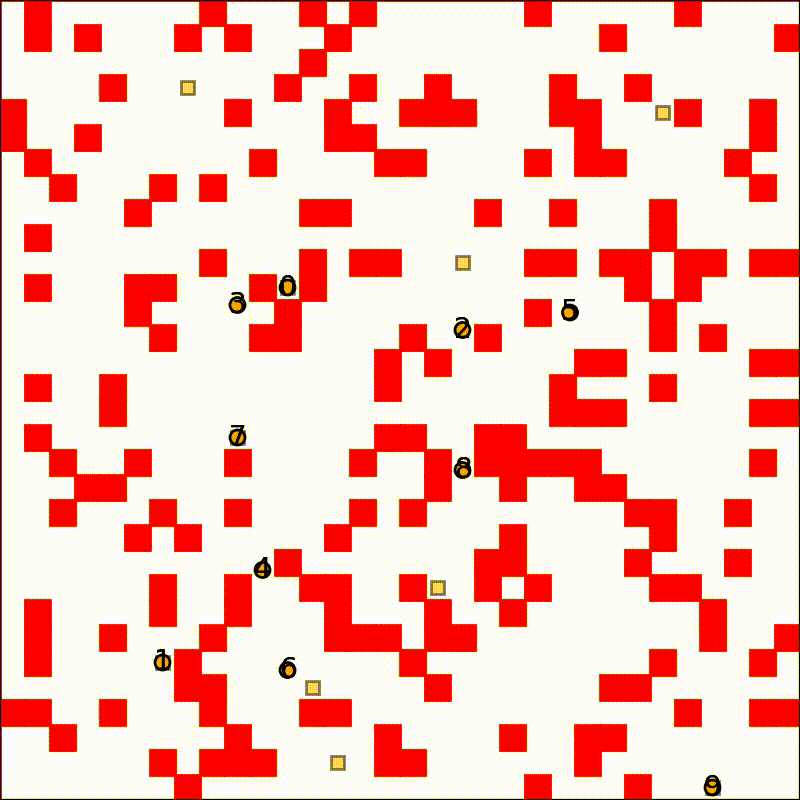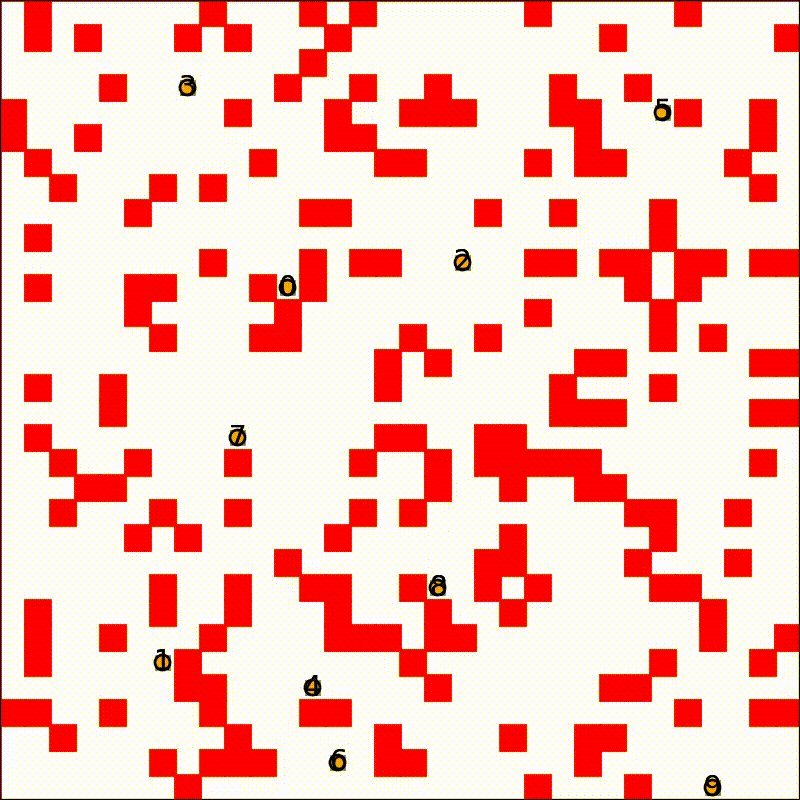 |
Reference
Post-Processing
Post-processing with TPG
The plan, which is computed in discrete time, can be postprocessed to generate a plan-execution schedule, that takes care of the kinematic constraints as well as imperfections in plan execution.
This work is based on: Multi-Agent Path Finding with Kinematic Constraints
Once the plan is generated using CBS, please run the following to generate the plan-execution schedule:
cd ./centralized/scheduling
python3 minimize.py ../cbs/output.yaml real_schedule.yaml
Decentralized solutions
In this approach, it is the responsibility of each robot to find a feasible path. Each robot sees other robots as dynamic obstacles, and tries to compute a control velocity which would avoid collisions with these dynamic obstacles.
Velocity obstacles
Execution
cd ./decentralized
python3 decentralized.py -f velocity_obstacle/velocity_obstacle.avi -m velocity_obstacle
Results
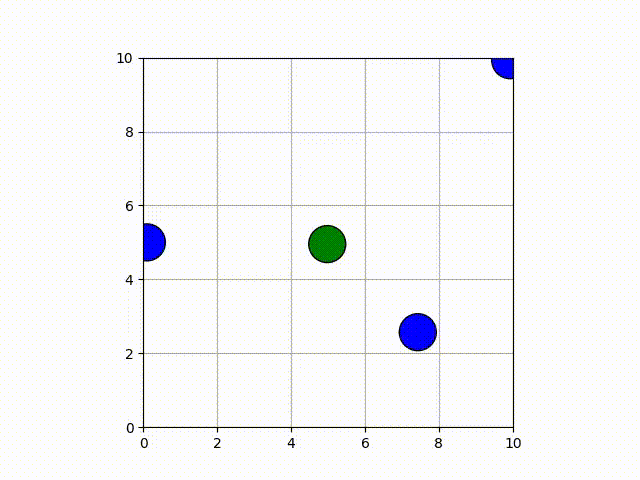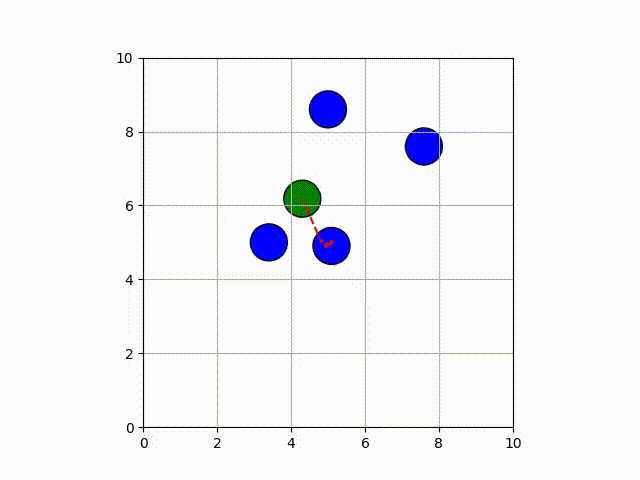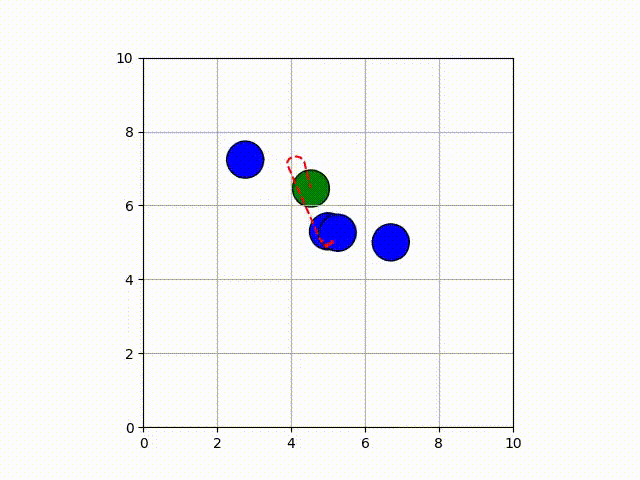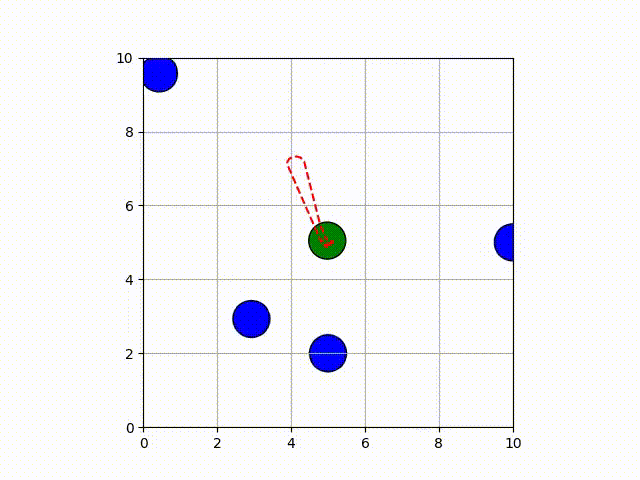
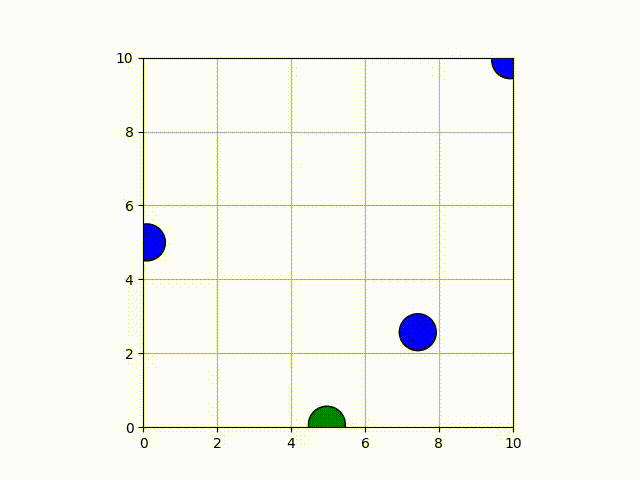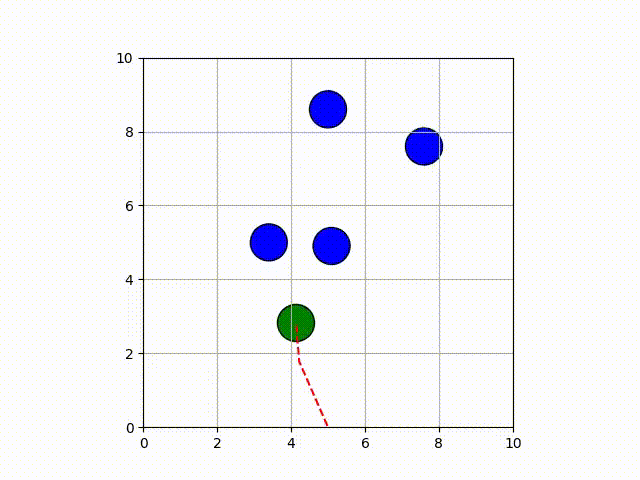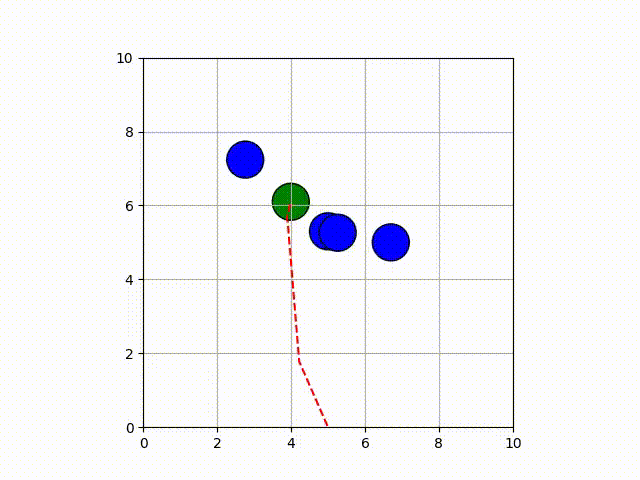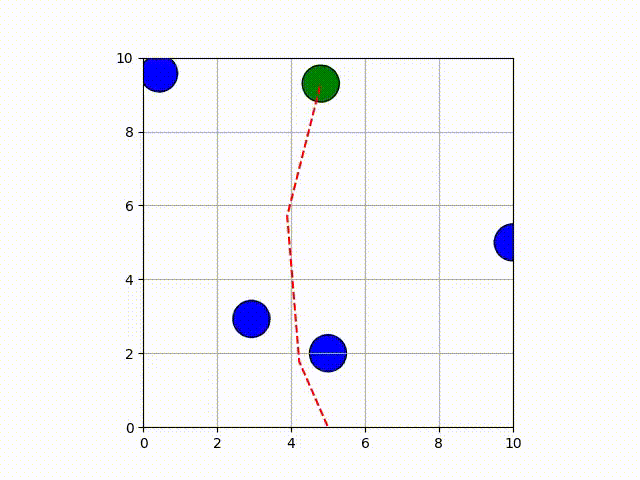
- Test 1: The robot tries to stay at (5, 5), while avoiding collisions with the dynamic obstacles
- Test 2: The robot moves from (5, 0) to (5, 10), while avoiding obstacles
| Test 1 | Test 2 |
|---|---|
 |
 |
References
Nonlinear Model-Predictive Control
Execution
cd ./decentralized
python3 decentralized.py -m nmpc
Results
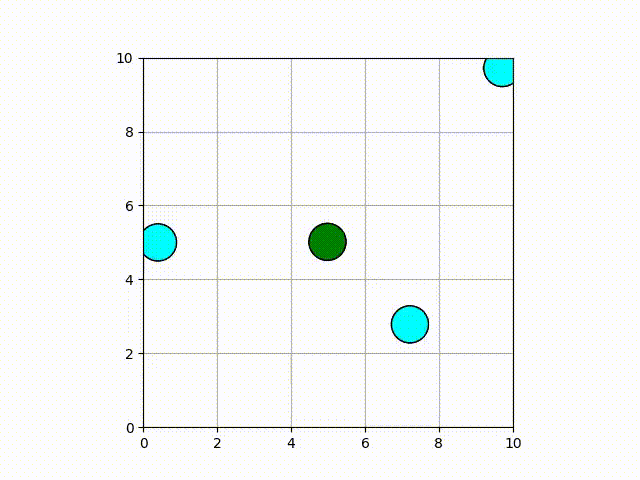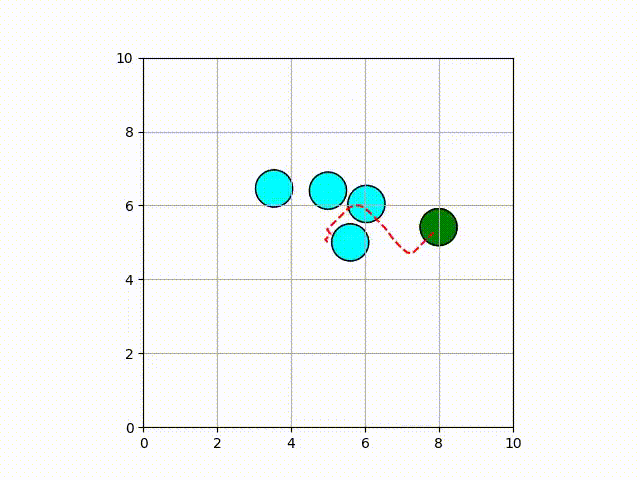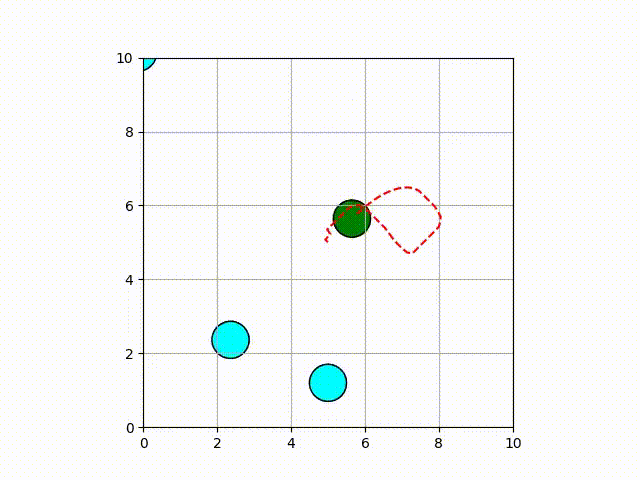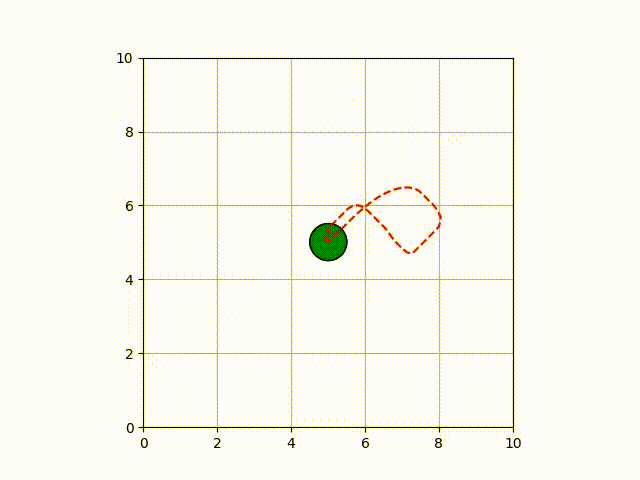
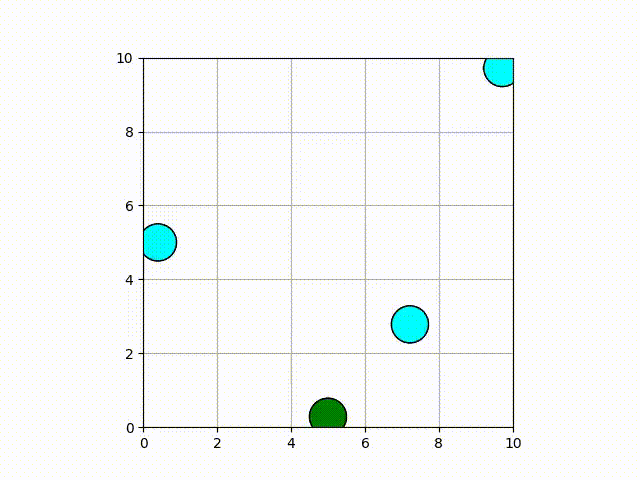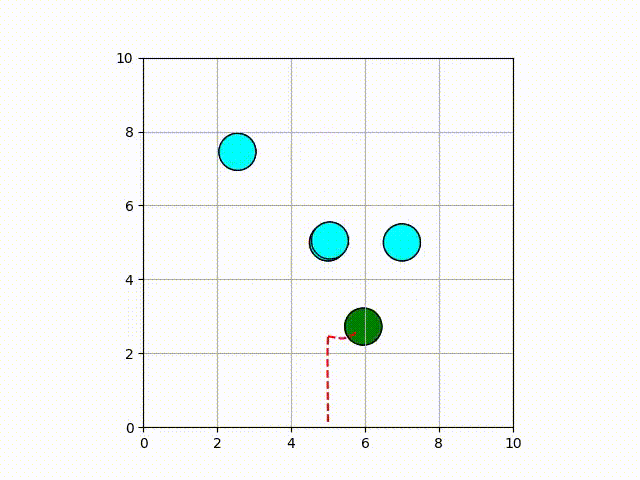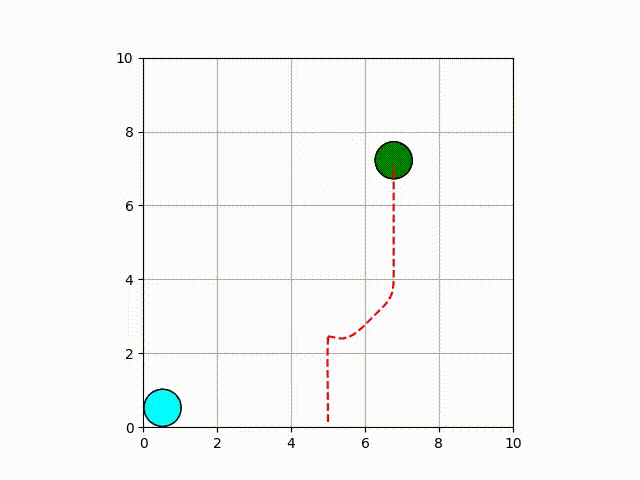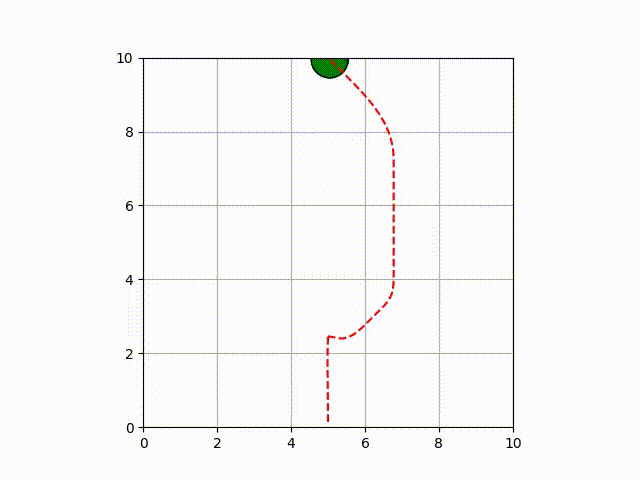
- Test 1: The robot tries to stay at (5, 5), while avoiding collisions with the dynamic obstacles
- Test 2: The robot moves from (5, 0) to (5, 10), while avoiding obstacles
| Test 1 | Test 2 |
|---|---|
 |
 |
References
Explore related projects
codecrafters-io/build-your-own-x
Master programming by recreating your favorite technologies from scratch.
560,836 starspublic-apis/public-apis
A collective list of free APIs
497,076 starsmorluto/rea
Reverse engineer anything with agents, from app behavior down to native binaries.
441,480 starsopenclaw/openclaw
The AI that really does things. Any OS. Any Platform. The lobster way. 🦞
394,157 stars