
VANdexj/OmniRisk
VANdexj/OmniRisk has 65 GitHub stars and 9 forks. GitHot measured 0 stars in 24 hours, +2 in 7 days, and +7 in 15 days. Last checked 2026-11-19 17:48 UTC. Last push 2026-11-16.
Measured star growth
- in 24h
- 0
- in 7 days
- +2
- in 15 days
- +7
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
About
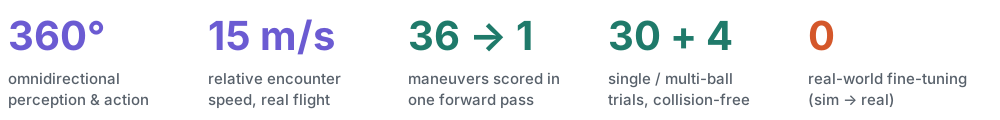
OmniRisk: omnidirectional trajectory-risk learning for agile quadrotor dynamic avoidance. One forward pass scores every maneuver onboard; real-world evasion at up to 15 m/s.
Machine LearningREADME.md
Original
Omnidirectional Trajectory-Risk Learning for Agile Quadrotor Dynamic Avoidance
Yifan He†1 · Yang Liu†1,2 · Wenhao Zhao†1 · Hai Lin1 · Deping Zhang1 · Mingze Ma1 · Xin Zhou1
Fei Gao1,2 · Huan Yu*1,2 · Zipeng Dai*1 · Ziming Ding*1
1Differential Robotics · 2Zhejiang University †equal contribution · *corresponding





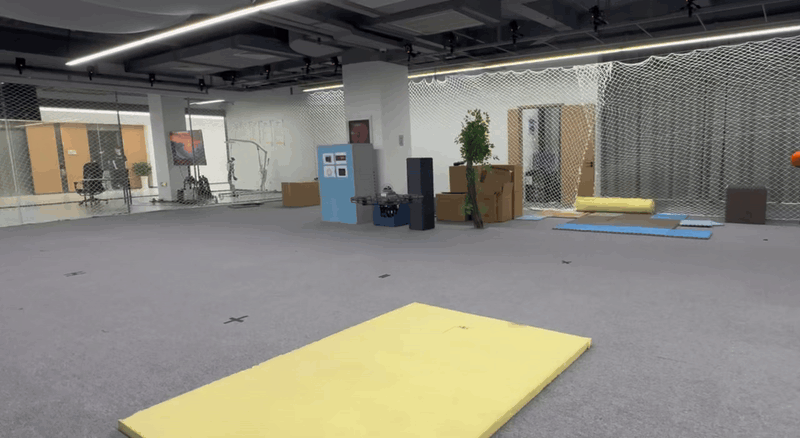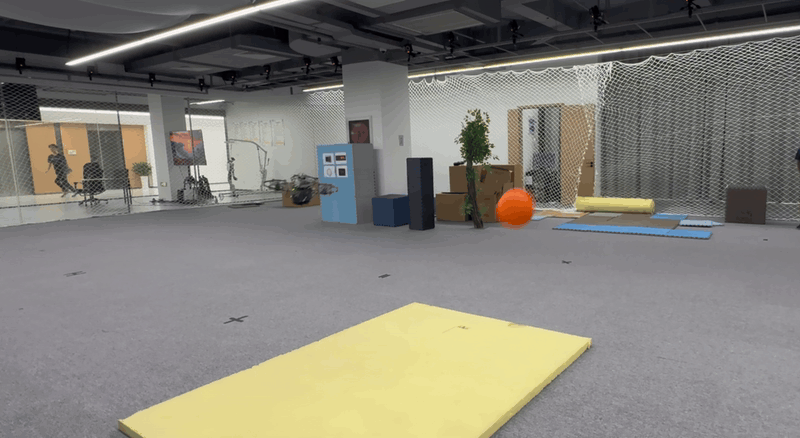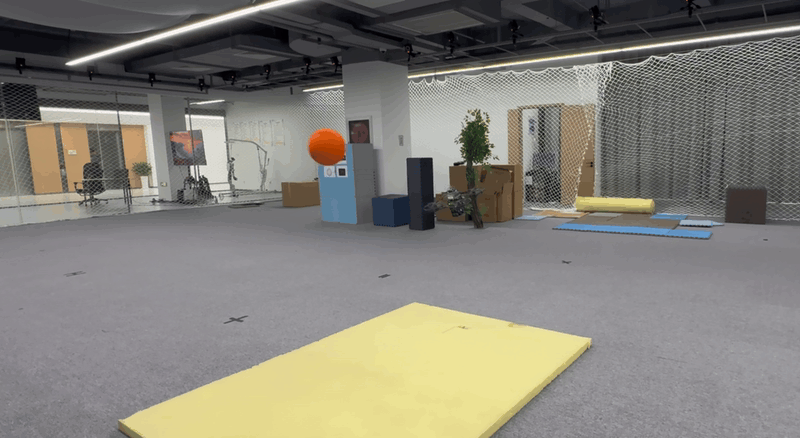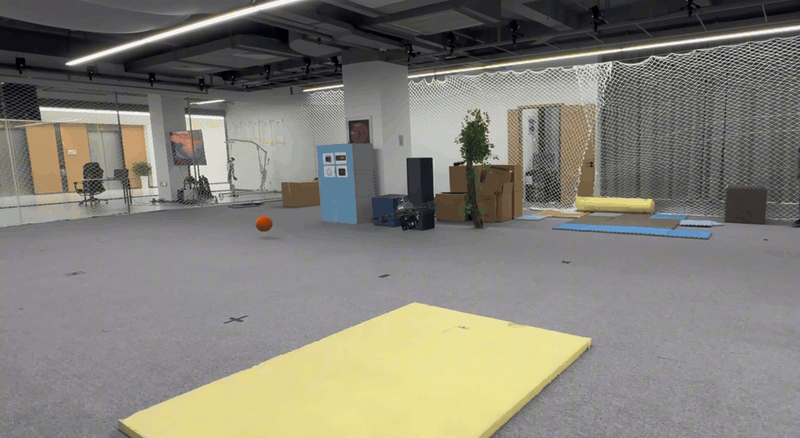
OmniRisk moves trajectory-risk evaluation offline. Onboard, one forward pass scores every candidate
maneuver around the drone, so planning cost does not grow with the number of obstacles.
Demos
Repeated trials
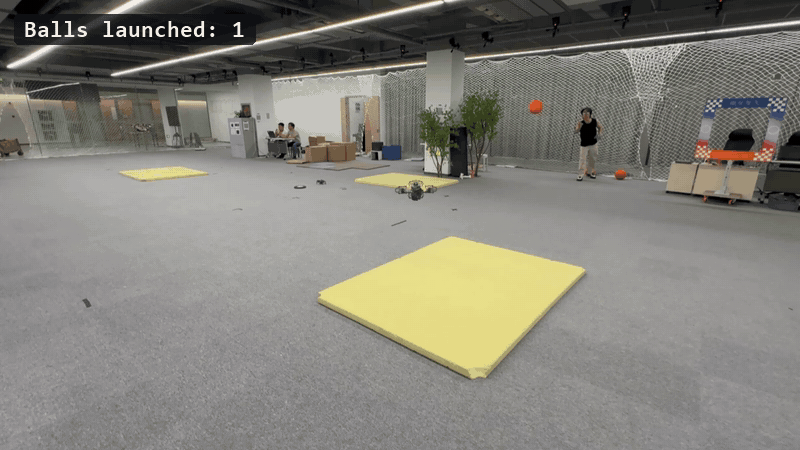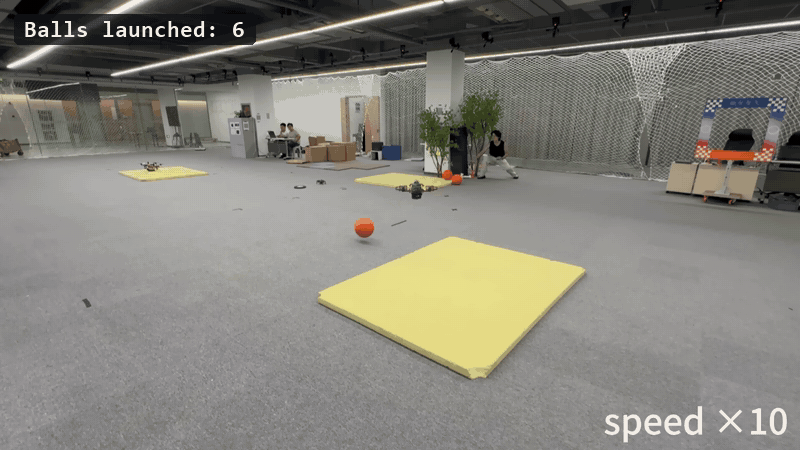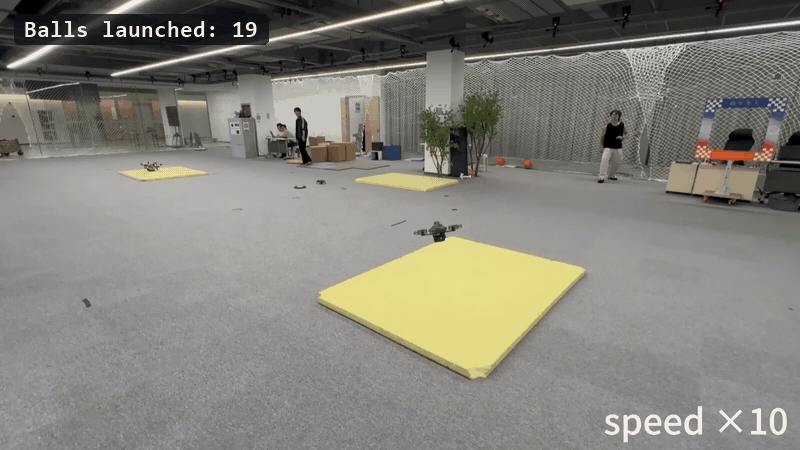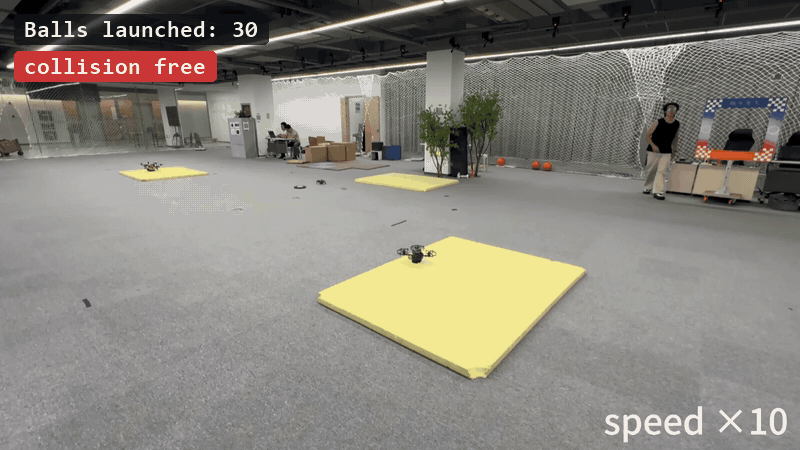 Single-ball tests 30 trials, all collision-free |
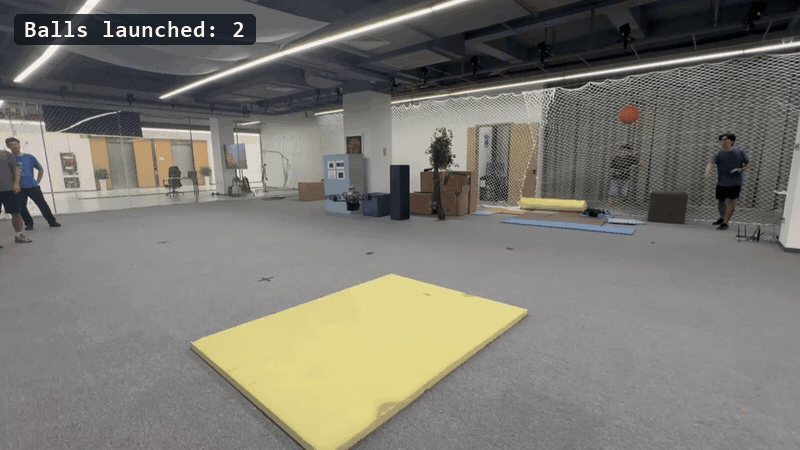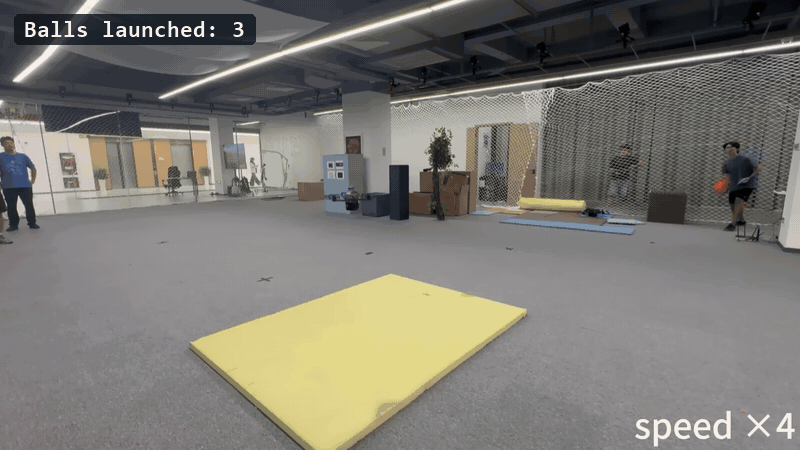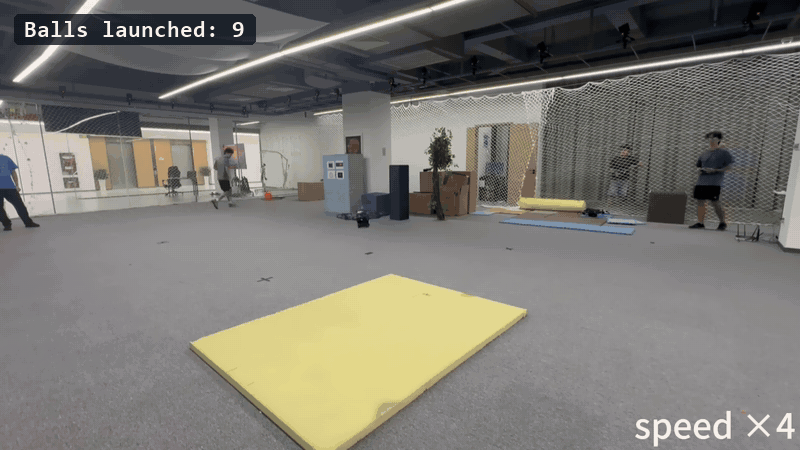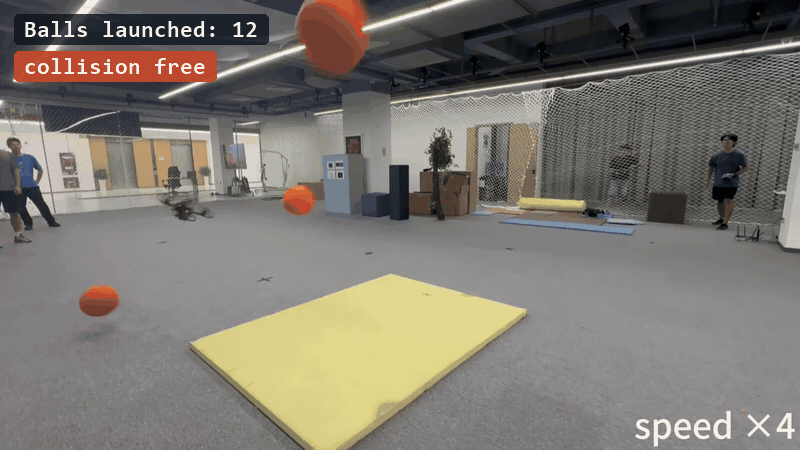 Multi-ball tests 4 trials, 12 balls in total, all collision-free |
Open vs. constrained space
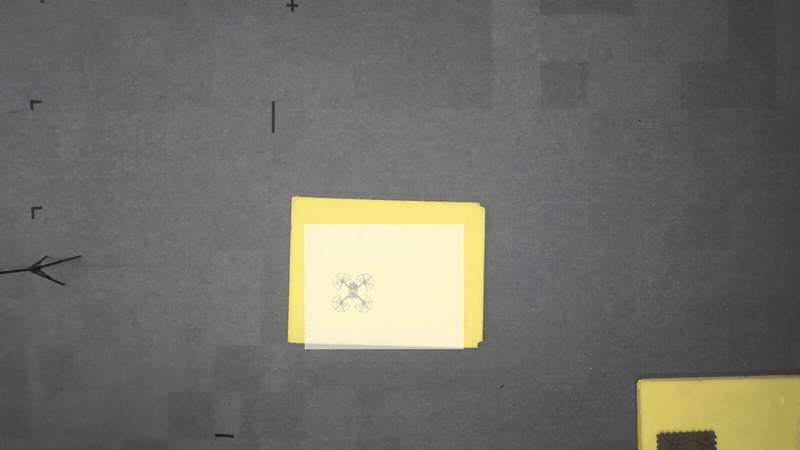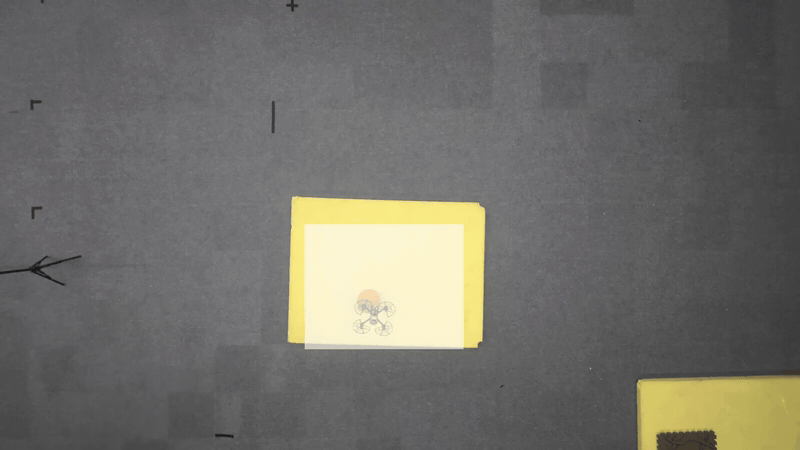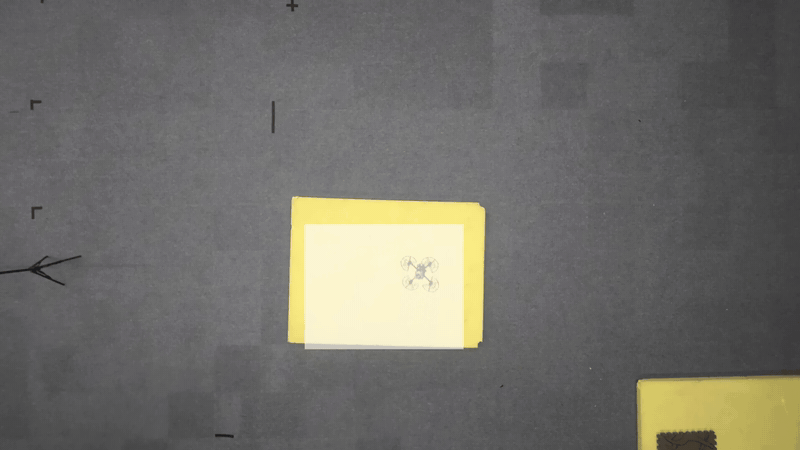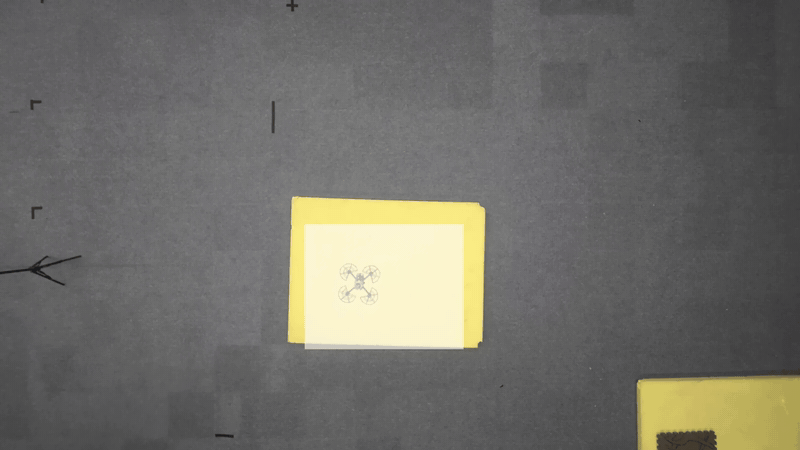 Open space top view · ×0.2 · nothing nearby, free to dodge in any direction |
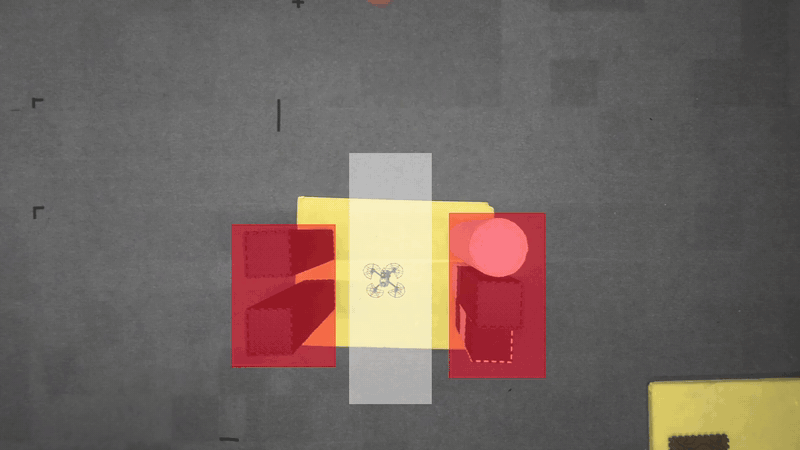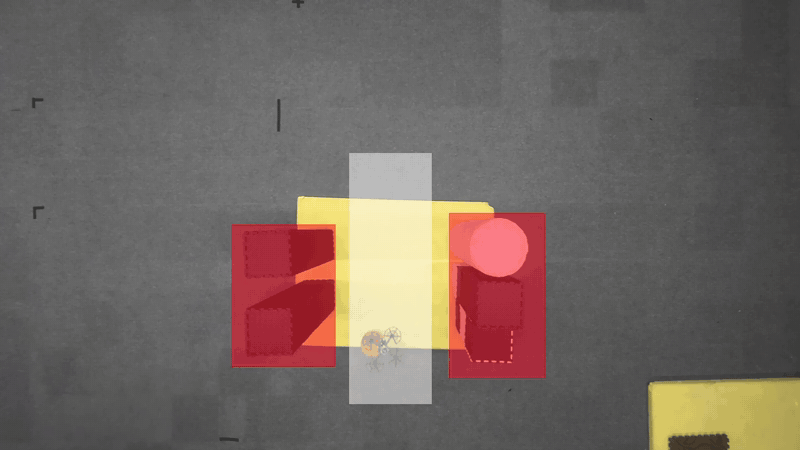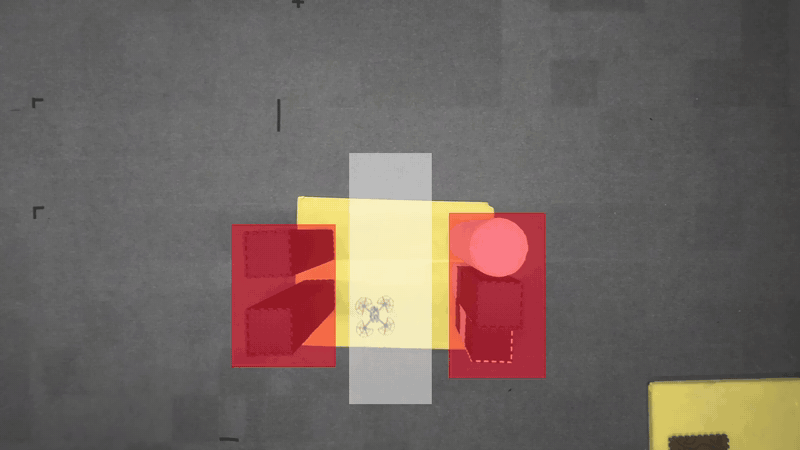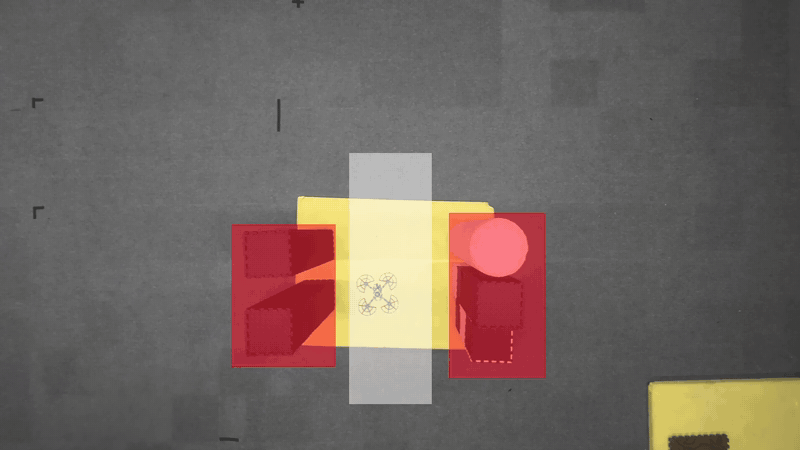 Constrained space top view · ×0.2 · obstacles on both sides, escape stays in the free corridor |
Dynamic + static obstacles
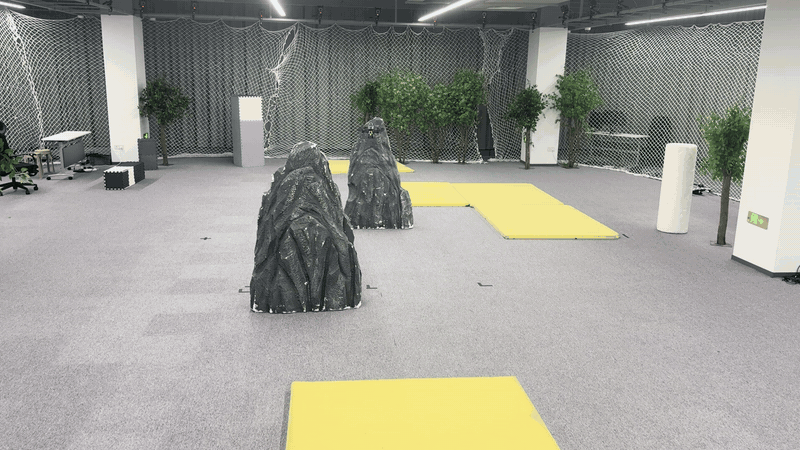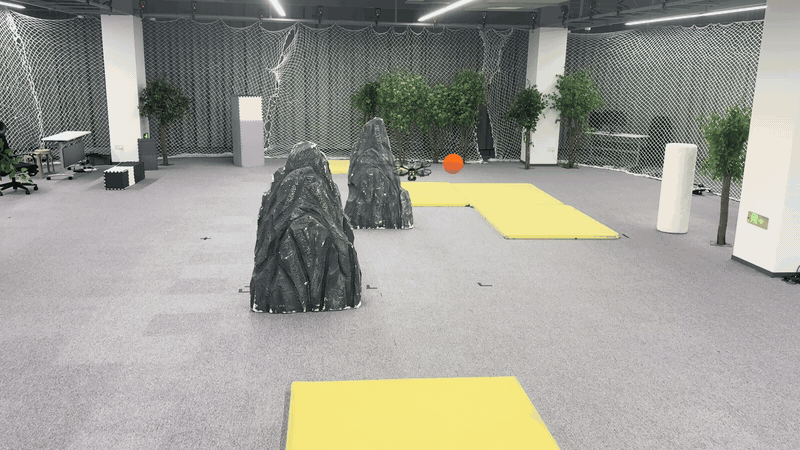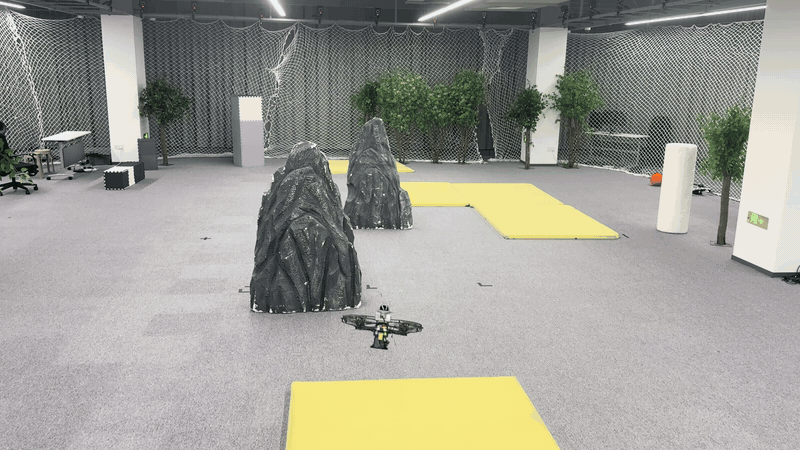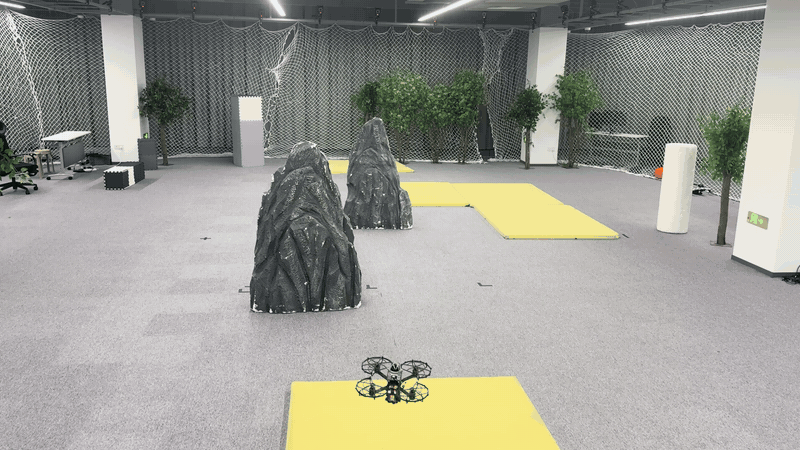
Crossing ball among rocks
dodges a ball thrown across its path while clearing rock-shaped obstacles
Different thrown objects
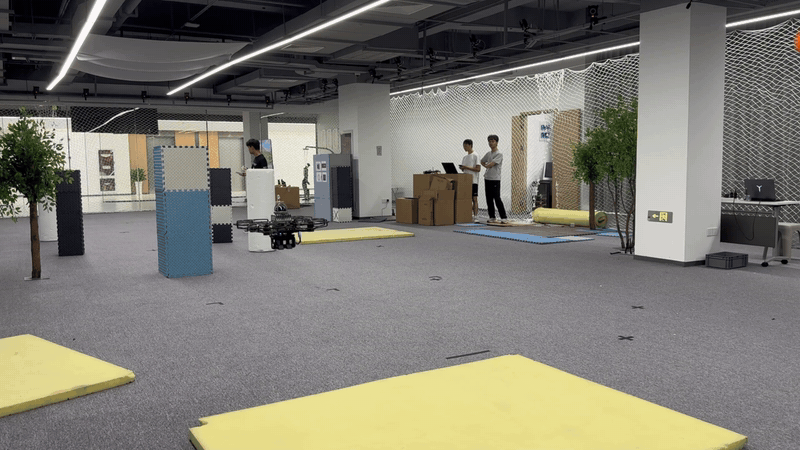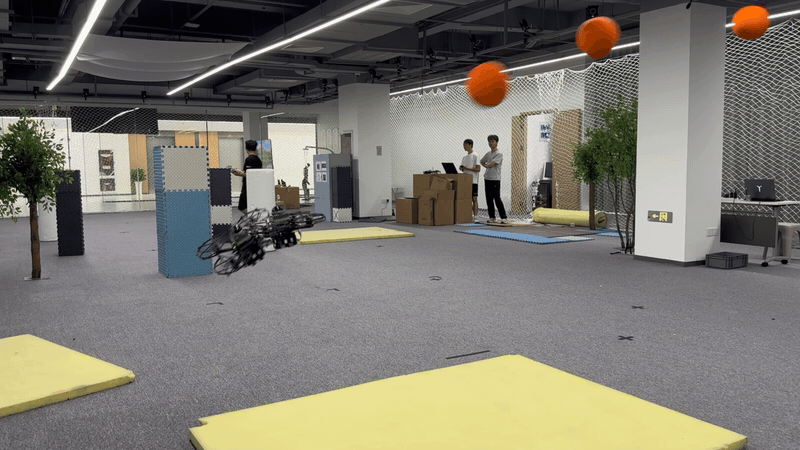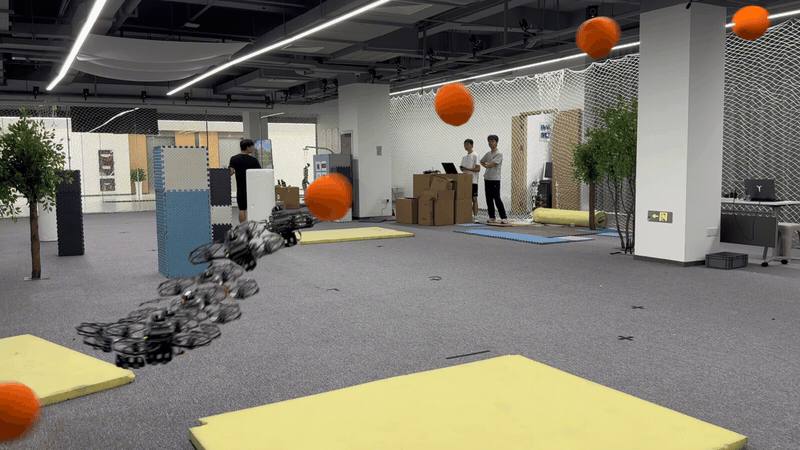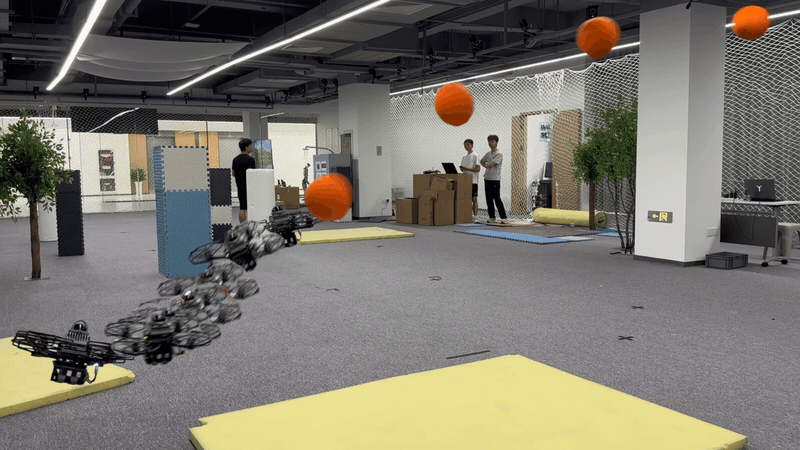 Thrown ball motion trails show the ball's arc and the escape path |
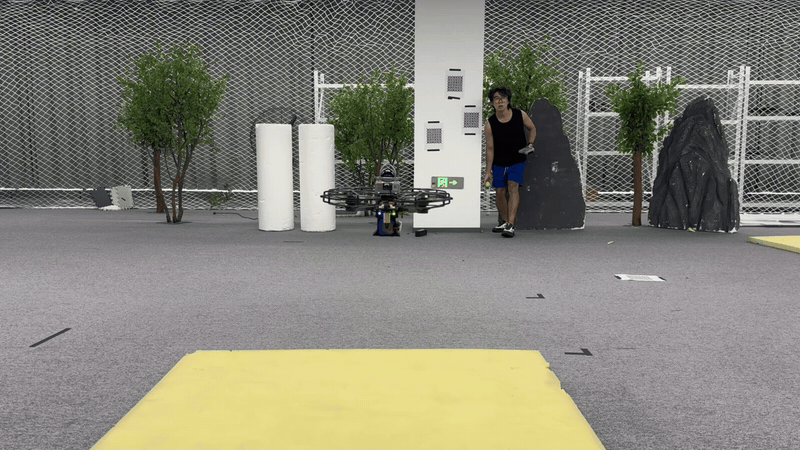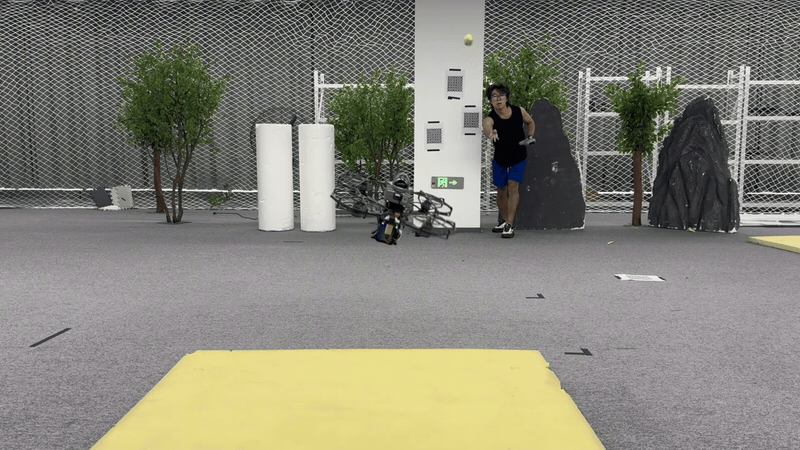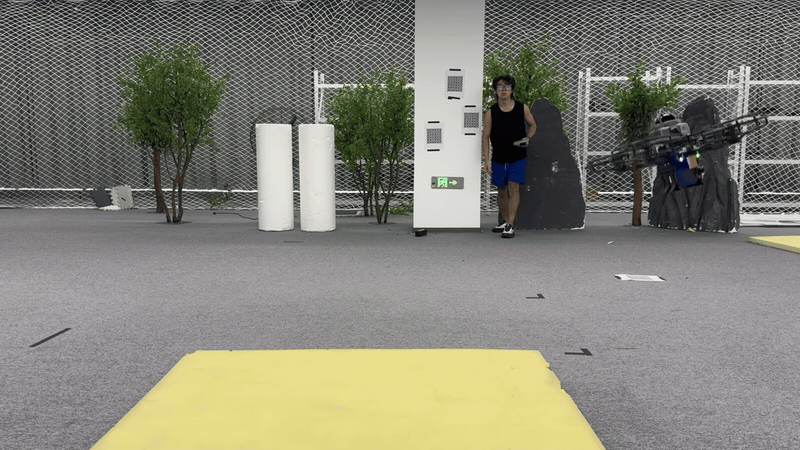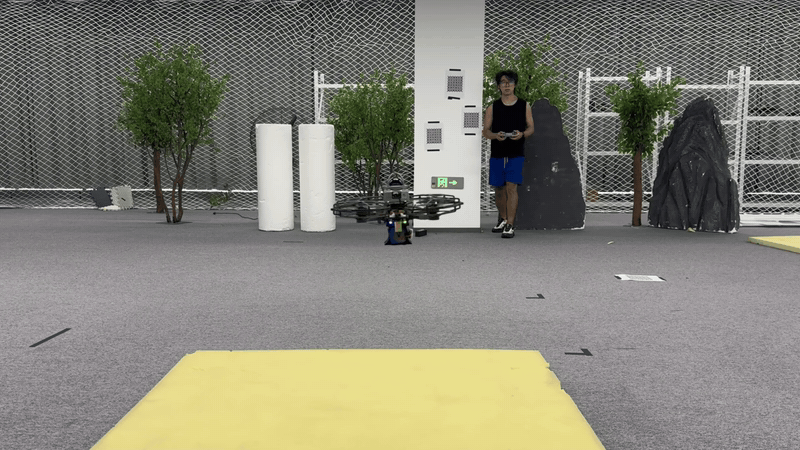 Tennis ball small and fast, only a few LiDAR returns |
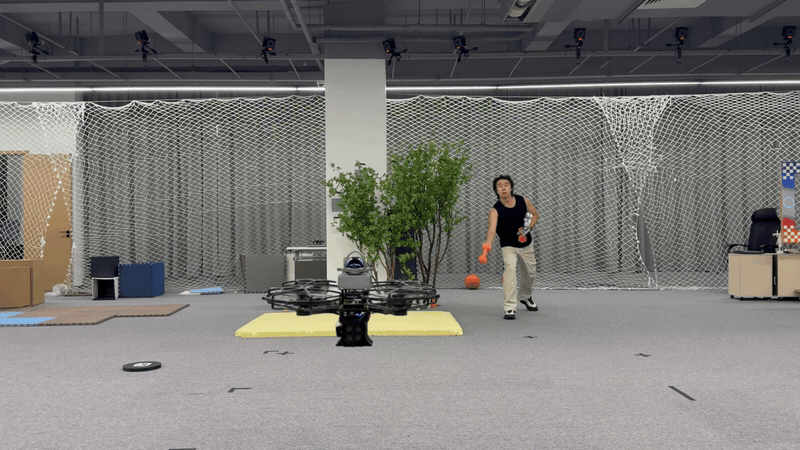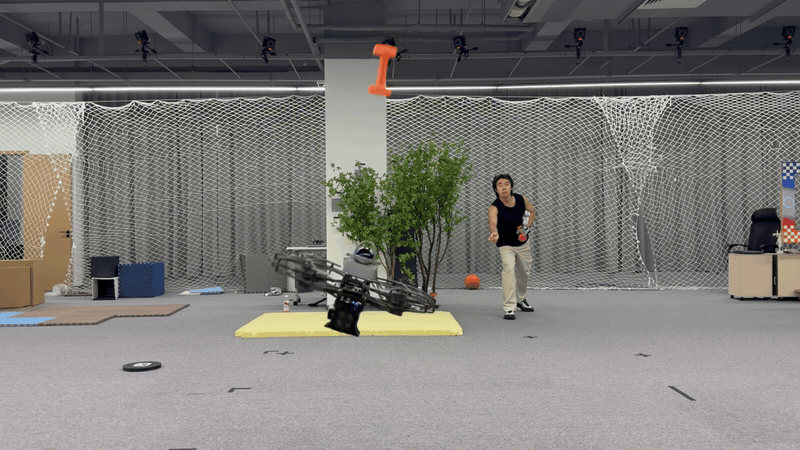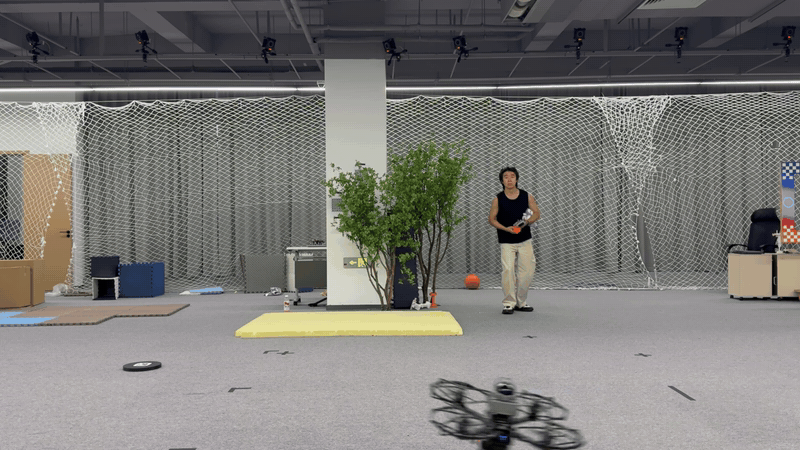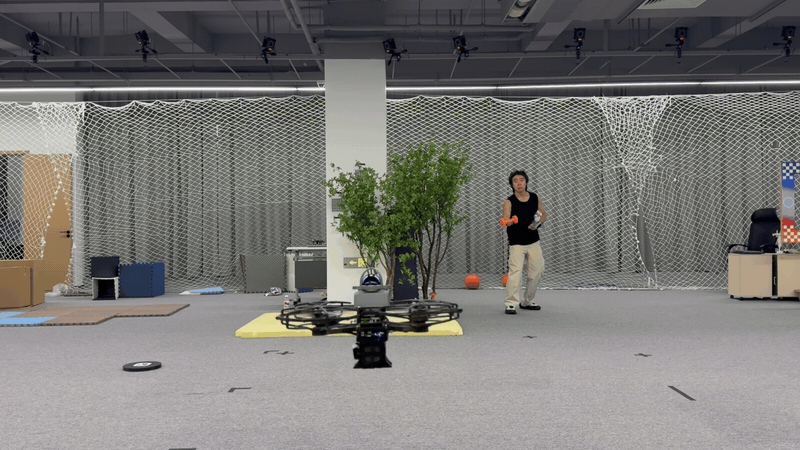 Dumbbell irregular rigid body, tumbling in flight |
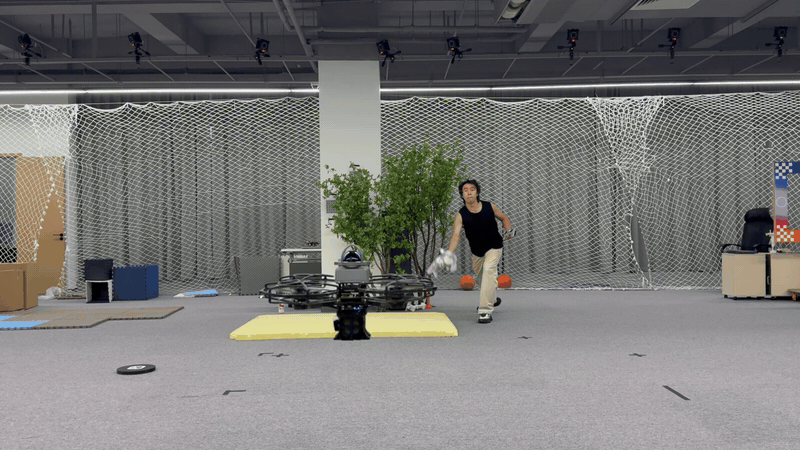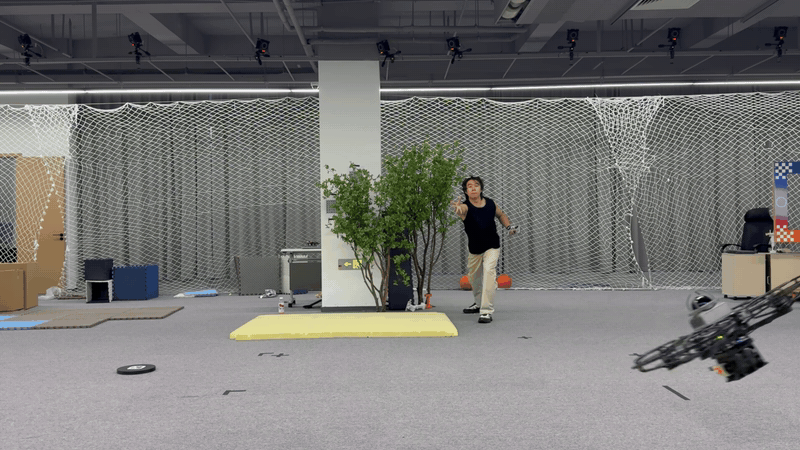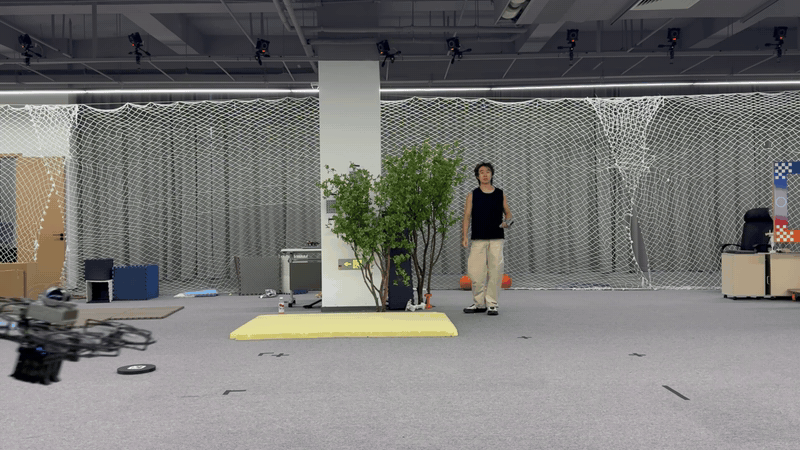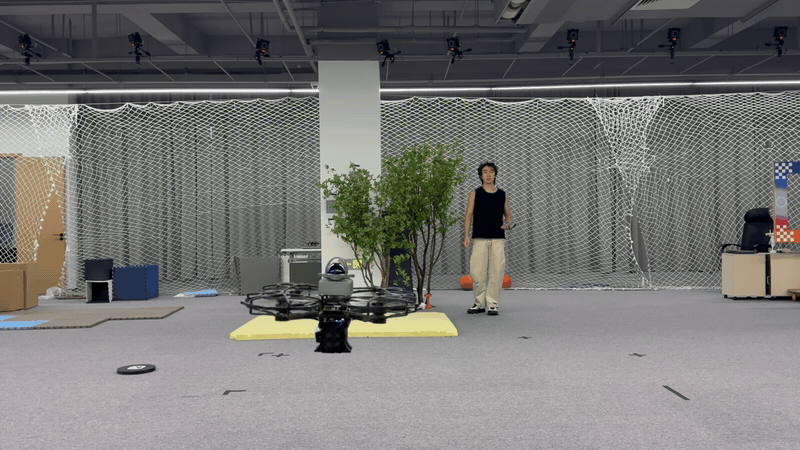 Plush toy soft, deforms mid-air |
Results
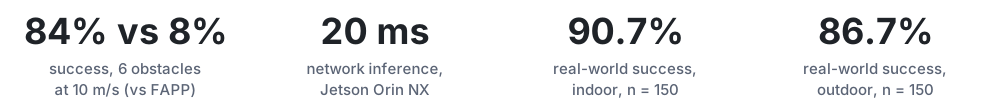
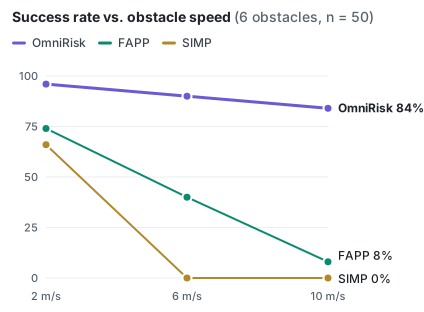 |
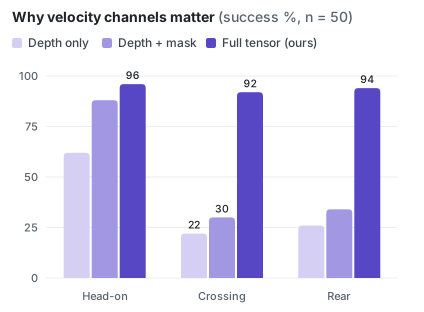 |
Planning latency on Jetson Orin NX (6 obstacles)
|
Zero-shot real-world success (n = 50 per cell)
|
[!NOTE] FAPP plans faster (~17 ms) but refines a single trajectory; with 6 obstacles at 10 m/s its success drops to 8% vs. 84% for OmniRisk.
Hardware
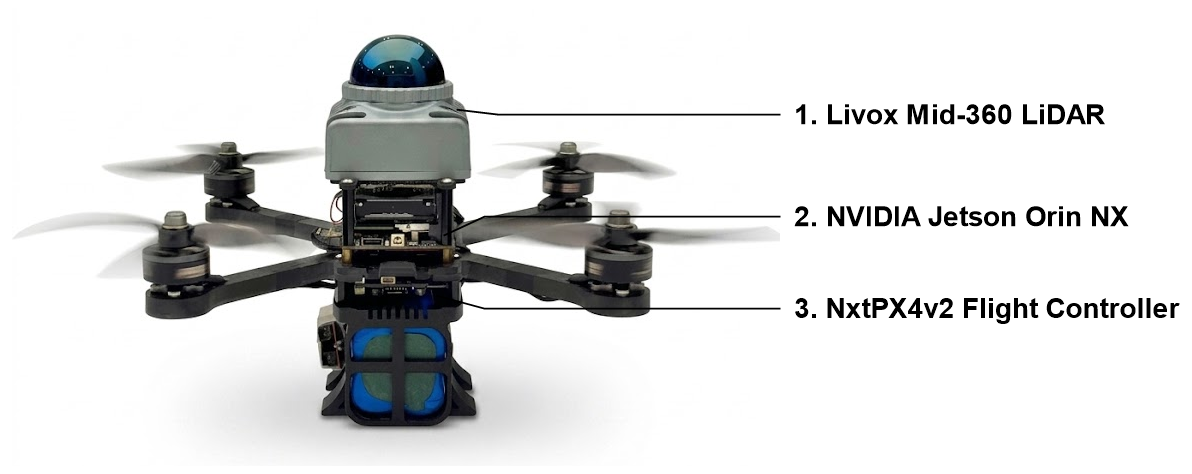 |
|
Roadmap
- Training code, simulator & dataset generator
- ROS planner & real-world deployment guide
- Pretrained models
- Simulation demos
- Project page
Quick start
Tested on Ubuntu 20.04 + ROS Noetic + CUDA (x86) and Jetson Orin NX (JetPack 5.1.x).
Repository structure
OmniRisk/     learning-based planner: network, training and the ROS planning node
Simulator/    CUDA LiDAR / depth simulator and dataset generator
Controller/   SO(3) quadrotor dynamics and controller for simulation
ros_ws/       onboard stack: FAST-LIO, M-detector, px4ctrl, EKF, Livox driver
docker/       simulation (x86) and deployment (Jetson) images
scripts/      one-shot install and build
Installation
bash scripts/build.sh               # install dependencies + build
bash scripts/build.sh --build-only  # rebuild only
bash scripts/build.sh --no-sim      # skip Controller / Simulator
Pretrained model
mkdir -p OmniRisk/saved/run_1
wget -O OmniRisk/saved/run_1/epoch60.pth \
  https://github.com/VANdexj/OmniRisk/releases/download/v1.0/omnirisk_epoch60.pth
Then run with --trial 1 --epoch 60 (trt_transfer.py uses this checkpoint by default).
Simulation
# T1 Dynamics
source Controller/devel/setup.bash
roslaunch so3_quadrotor_simulator simulator_attitude_control.launch

# T2 Environment + LiDAR
source Simulator/devel/setup.bash
rosrun sensor_simulator sensor_simulator_cuda

# T3 M-detector
source ros_ws/devel/setup.bash
roslaunch m_detector detector_mid360.launch points_topic:=/lidar_points points_in_world_frame:=false odom_topic:=/sim/odom

# T4 OmniRisk (add --flight_mode nav, then set the goal with RViz 2D Nav Goal)
source ros_ws/devel/setup.bash && source omnirisk_env/bin/activate
cd OmniRisk && python omnirisk_node.py --trial <n> --epoch <k> --odom_topic /sim/odom --lidar_topic /lidar_points

# T5 RViz
source ros_ws/devel/setup.bash
rviz -d OmniRisk/omnirisk.rviz

# T6 Joystick goal
source ros_ws/devel/setup.bash
cd OmniRisk && python3 rc_goal_teleop.py _odom_topic:=/sim/odom
Training
cd Simulator && source devel/setup.bash
rosrun sensor_simulator dataset_generator   # → dataset/

cd ../OmniRisk && source ../omnirisk_env/bin/activate
python train.py                             # → saved/run_<n>/epoch<k>.pth
tensorboard --logdir saved
TensorRT acceleration
cd OmniRisk
python trt_transfer.py --trial <n> --epoch <k>   # run on the deployment device
python omnirisk_node.py --use_tensorrt 1
Real-world deployment
# In every terminal
source ros_ws/devel/setup.bash

# T1 MAVROS
sudo chmod 666 /dev/ttyACM0
roslaunch mavros px4.launch fcu_url:=/dev/ttyACM0:57600

# After MAVROS connects: IMU / attitude at 200Hz
rosrun mavros mavcmd long 511 105 5000 0 0 0 0 0  # HIGHRES_IMU
rosrun mavros mavcmd long 511 31  5000 0 0 0 0 0  # ATTITUDE_QUATERNION
rosrun mavros mavcmd long 511 83  5000 0 0 0 0 0  # ATTITUDE_TARGET

# T2 MID360 + FAST-LIO + EKF
roslaunch fast_lio fastlio_ekf.launch

# T3 px4ctrl
roslaunch px4ctrl run_ctrl.launch

# T4 M-detector
roslaunch m_detector detector_mid360.launch

# T5 OmniRisk
source omnirisk_env/bin/activate
cd OmniRisk && python omnirisk_node.py --use_tensorrt 1

# T6 RViz
rviz -d OmniRisk/omnirisk.rviz

# T7 Joystick goal (_input_mode:=usb | mavros)
cd OmniRisk && python3 rc_goal_teleop.py _input_mode:=usb

# Takeoff / land
rostopic pub -1 /px4ctrl/takeoff_land quadrotor_msgs/TakeoffLand "takeoff_land_cmd: 1"
rostopic pub -1 /px4ctrl/takeoff_land quadrotor_msgs/TakeoffLand "takeoff_land_cmd: 2"

# Checks
rostopic hz /ekf_quat/ekf_odom              # > 50Hz
rostopic hz /mavros/setpoint_raw/attitude   # > 100Hz
rostopic hz /so3_control/pos_cmd
Citation
@article{he2026omnirisk,
  title   = {OmniRisk: Omnidirectional Trajectory-Risk Learning for Agile Quadrotor Dynamic Avoidance},
  author  = {He, Yifan and Liu, Yang and Zhao, Wenhao and Lin, Hai and Zhang, Deping and Ma, Mingze and Zhou, Xin and Gao, Fei and Yu, Huan and Dai, Zipeng and Ding, Ziming},
  journal = {arXiv preprint arXiv:2609.18191},
  year    = {2026}
}
Acknowledgements
This work was carried out at Differential Robotics; we are especially grateful to Zipeng Dai for his invaluable mentorship.
License
Released under the MIT License.