
StuckAtPrototype/Racer has 3,806 GitHub stars and 549 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-06 17:53 UTC. Last push 2026-02-01.
thank you for the overwhelmingly positve support!! such an inspiration to keep making fun open source content!
Measured star growth
- in 24h
- 0
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.md
OriginalMicro Racer Car - StuckAtPrototype
thank you for the overwhelmingly positve support!! such an inspiration to keep making fun open source content!
New Youtube video about improvements
Lots of new improvements and I am now selling a kit for these! Check out the video here:
https://www.youtube.com/watch?v=FulhEs5R5WU

Original Youtube Video
A bit of a back-story of how this project came to be.
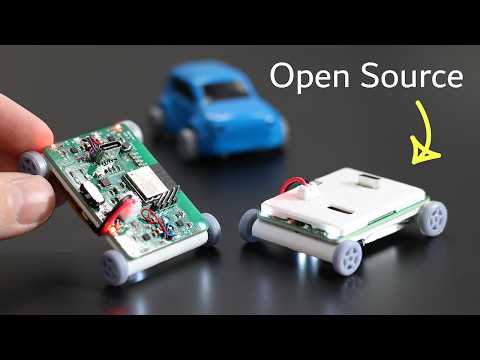
Sub if you like what you see.
Some pictures of the project
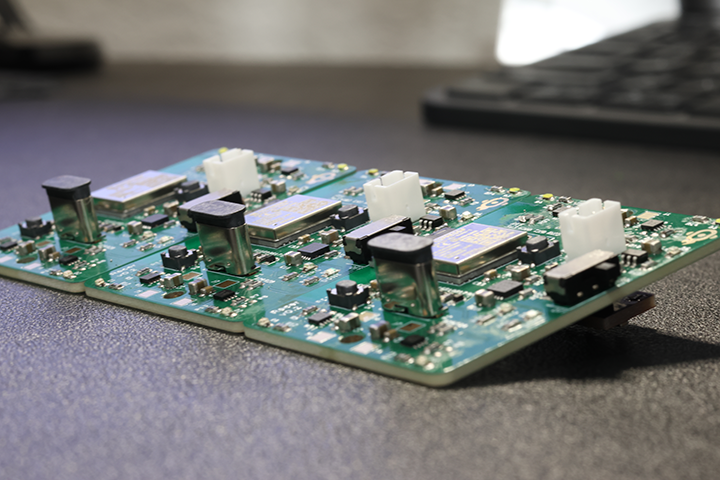
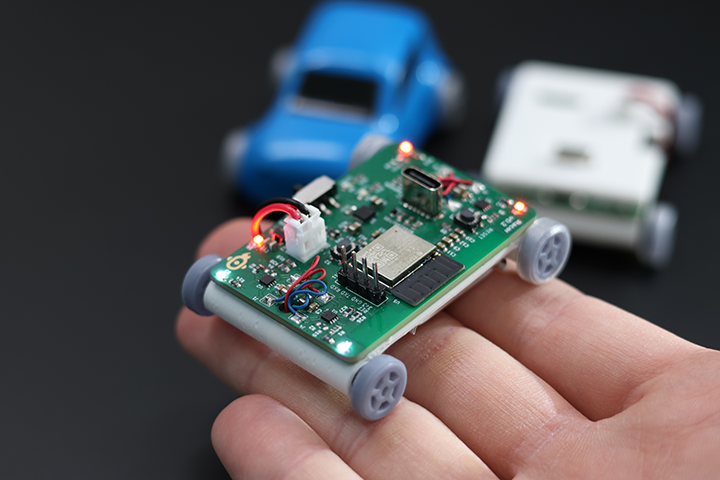
Hardware Remote for this car
https://github.com/StuckAtPrototype/Thumbtroller
Project Structure
The project consists of
- Firmware
- Hardware
- Mechanical
- Scripts
These are structured into their own files. I could have used submodules, but decided against it.
1. Firmware
Code for the little car. This lives on the ESP32
Requirements
- ESP32 IDF version 5.3.1
- USB to Serial dongle
- Target set to ESP32-H2
2. Hardware
Schematic
PDF schematic included for your viewing pleasure.
PCBs
All the gerber files you'd need to send to a fab house.
Kicad
All the files you'd need to expand and work on this further. If you'd like.
3. Mechanical
Enclosure
All the step files you need to make one of these. Extrusion printer works well for this part.
Wheels
A bit of caution on this one.. you'll need an SLA printer.
4. Scripts
Did anyone say neural networks?
This folder has all the python code you'd need to train up your own neural network for the car. It also consists scripts that let you drive it using a keyboard -- just in case you dont want to make a physical controller.
Requirements
- Python 3
- You'll need to install a bunch of pip modules
Training the neural network
Training the neural network is as simple as running the training script with the data in the color_data.txt file. For data format see the sample data in the file. You need to stick to the formatting.
To train run python trainer.py
Keyboard controller
To run the script python controller.py
Use w s a d for control. Modify the script for different speeds, etc
Protocol for motor control
60,1,60,1,5 -- translates to:
motor side A: speed 60, direction forward
motor side B: speed 60, direction forward
500 miliseconds run time
See firmware file motor.c if you need more details
What the project could use
- Cleanup, but thats true for almost anything out there
- Some fun code that makes the little car drive using the color sensor -- think very fancy line follower
- LLM integration -- ChatGPT driving a physical little robot? anyone? :)
If you take it further
Let me know if you ever make one of these, I'd love to see it. Seriously, that'd be exciting and inspiring to keep making my projects open source!
License
Apache 2.0 -- i.e. use as you'd like
http://www.apache.org/licenses/LICENSE-2.0
Special Thanks
Thanks to Michael Angerer for his open sourced esp32_ble_ota project. I used it to get BLE running in this project. His blog post and github repo are a great resource. Check it out. https://github.com/michael-angerer/esp32_ble_ota
Explore related projects
codecrafters-io/build-your-own-x
Master programming by recreating your favorite technologies from scratch.
560,449 starspublic-apis/public-apis
A collective list of free APIs
496,767 starsmorluto/rea
Reverse engineer anything with agents, from app behavior down to native binaries.
438,142 starsopenclaw/openclaw
The AI that really does things. Any OS. Any Platform. The lobster way. 🦞
394,076 stars