
OpenWAM/OpenWAM
OpenWAM/OpenWAM has 253 GitHub stars and 14 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-19 02:36 UTC. Last push 2026-11-13.
What you can do
- Video pretraining: train causal predictors on single-view and multiview robot video.
- Video-action interaction: configure video-first, action-first, joint, and decoupled generation with shared-transformer or dual-expert architectures.
- Inverse and forward dynamics: infer actions from supplied video trajectories (IDM), or predict future observations conditioned on actions (FDM).
- Custom experiments: add datasets, policies, action decoders, and simulators through the extension SDK.
Measured star growth
- in 24h
- 0
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
About
Official code for "OpenWAM: An Open Framework for Composable World-Action Models" (Stanford University)
Developer ToolsREADME.md
OriginalOpenWAM: An Open Framework
for Composable World-Action Models
Heng Yu*, David D. Yuan*, Juze Zhang*, Changan Chen, Yao Feng,
Michelle Baldonado, Steve Cousins, Li Fei-Fei, Jiajun Wu, Ehsan Adeli
Stanford University
* Equal contribution





Paper (PDF) · Research blog · Technical documentation · Models and data · Citation
OpenWAM is an extensible and composable framework for world-action models and the official implementation of our paper. It brings causal robot-video pretraining, video-action policies, and independently trained dynamics models into a shared training and evaluation framework.
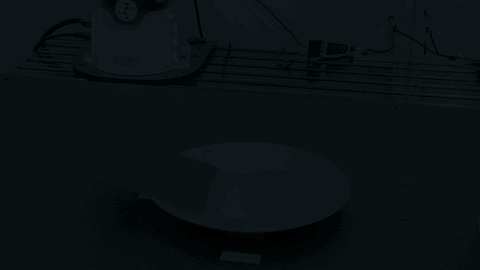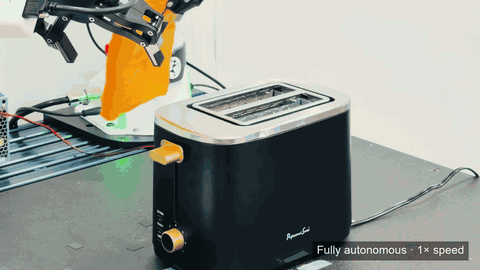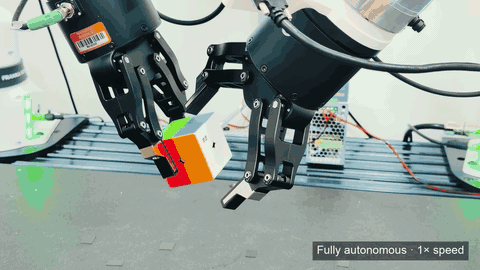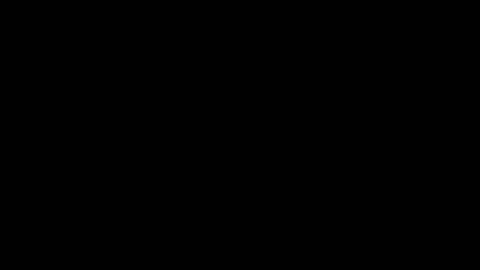
Capabilities
- Video pretraining: train causal predictors on single-view and multiview robot video.
- Video-action interaction: configure video-first, action-first, joint, and decoupled generation with shared-transformer or dual-expert architectures.
- Inverse and forward dynamics: infer actions from supplied video trajectories (IDM), or predict future observations conditioned on actions (FDM).
- Custom experiments: add datasets, policies, action decoders, and simulators through the extension SDK.
The framework includes LIBERO, RoboTwin, CALVIN, and LeRobot data integrations. See architectures and interaction programs for supported configurations, including generalist joint denoising.
Models and data
Released models are available on Hugging Face:
| Model | Purpose |
|---|---|
| Video-pretrained backbone | Causal robot-video prediction |
| VTA for LIBERO-10 | Video-then-action policy with both video and action experts |
| Mixed IDM CF64k | Inverse dynamics, post-trained on 60% counterfactual data and 40% demonstrations |
| CF-only IDM CF64k | Inverse dynamics, post-trained on counterfactual data only |
The IDMs translate supplied video futures into robot actions; see video-to-action composition. See the artifact guide for release contents and setup.
LIBERO-CF64k contains 64,000 counterfactual motion segments across LIBERO-Long's ten tasks, with two-view video, actions, and proprioception for learning inverse and forward dynamics. Raw data, a reader, and integrity checks are publicly available.
Release roadmap
- Training and evaluation framework
- Causal robot-video pretrained weights
- Inverse dynamics (IDM) checkpoints
- LIBERO video-then-action policy checkpoint
- LIBERO-CF64k counterfactual dataset
- End-to-end inference examples with released checkpoints
Quickstart
Linux · Python 3.11 or 3.12 · Alpha-stage research software
Install uv, then run a small CPU example:
git clone https://github.com/OpenWAM/OpenWAM.git
cd OpenWAM
uv sync --frozen --group dev --extra train --extra eval

uv run --extra train openwam-sanity \
  --cfg configs/examples/public_tiny_synthetic_contract.yaml \
  --device cpu --max-batches 1 --rollout-steps 1
This checks the installation with synthetic data; no GPU, downloaded weights, or simulator is required. It does not reproduce the paper's results.
Alternatively, install the package from PyPI in a virtual environment:
python -m pip install 'openwam[train,eval]'
See the quickstart guide for a complete train–resume–evaluate example and optional dependencies. For version changes and migration notes, see releases.
Train a policy
Prepare the required data and model assets, then register their paths:
cp configs/local_paths.sample.yaml configs/local_paths.yaml
Fill in the paths required by your configuration. The reference dual-expert LIBERO configuration uses four GPUs and was characterized on four 48 GB GPUs:
uv run --extra train torchrun --standalone --nproc-per-node=4 \
  -m open_wam.cli.train \
  --cfg configs/experiments/dual_expert_libero_joint.yaml \
  --save-root runs/dual-expert-joint \
  --expected-world-size 4
To use video-then-action generation with this configuration, add
--set policy_variant.program=video_then_action and choose a new --save-root.
See training and evaluation for checkpoint initialization, resume, dynamics training, and benchmark rollouts.
Documentation
| Task | Guide |
|---|---|
| Prepare data and pretrain video models | Video pretraining |
| Configure architectures and interaction programs | Model configurations |
| Set up datasets and simulators | Benchmarks and data |
| Add your own components | Extension SDK |
| Reproduce an experiment | Reproducibility |
Citation
If you use OpenWAM in your research, please cite our paper:
@article{yu2026openwam,
  title   = {{OpenWAM}: An Open Framework for Composable World-Action Models},
  author  = {Yu, Heng and Yuan, David D. and Zhang, Juze and Chen, Changan and
             Feng, Yao and Baldonado, Michelle and Cousins, Steve and
             Fei-Fei, Li and Wu, Jiajun and Adeli, Ehsan},
  journal = {arXiv preprint arXiv:2610.07922},
  year    = {2026},
  url     = {https://arxiv.org/pdf/2610.07922}
}
The BibTeX entry is also available in CITATION.bib.
Contributing and license
See Contributing for development guidance.
OpenWAM is licensed under AGPL-3.0-only. See NOTICE and Third-party notices for attribution requirements and separately governed components and institutional marks.