
MOLAorg/mola has 1,057 GitHub stars and 152 forks. GitHot measured 0 stars in 24 hours and +6 in 7 days. Last checked 2026-11-10 02:03 UTC. Last push 2026-11-04.
A Modular Optimization framework for Localization and mApping (MOLA)
What you can do
- 📍 LiDAR Odometry (LO), LiDAR-Inertial Odometry (LIO), geo-referenced maps, sensor fusion
- 🧩 Fully configurable YAML pipelines - no recompilation needed to change sensors, filters, or map layers
- 🎯 Flexible accuracy: fast real-time navigation or survey-grade (<1 cm) mapping
- 🌍 Map-less RTK-quality outdoor georeferencing with low-cost GNSS + LiDAR + IMU
Measured star growth
- in 24h
- 0
- in 7 days
- +6
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
README.md
Original
:robot: MOLA :compass:
Modular Optimization framework for Localization and mApping


A modern, modular C++ and ROS 2 framework for Localization and SLAM. Configurable pipelines for LiDAR Odometry, LIO, and more.
Why MOLA | Solutions | Plans & Pricing | Documentation
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) |  |
|
| ROS 2 Jazzy (u24.04) |  |
|
| ROS 2 Kilted (u24.04) |  |
|
| ROS 2 Lyrical (u26.04) |  |
|
| ROS 2 Rolling (u26.04) |  |
| EOL Distro | Last Release |
|---|---|
| ROS 2 Iron (u22.04) |  |
🤖 What is MOLA?
MOLA (Modular Optimization framework for Localization and mApping) is a modular, extensible, and high-performance framework for robotics localization and 🗺️ mapping.
This repository contains the base open-sourced packages for the MOLA project. Other packages exist under the MOLAorg organization.
Refer to the official documentation for build instructions, demos, API reference, etc.
🗺️ Features
- 📍 LiDAR Odometry (LO), LiDAR-Inertial Odometry (LIO), geo-referenced maps, sensor fusion
- 🧩 Fully configurable YAML pipelines - no recompilation needed to change sensors, filters, or map layers
- 🎯 Flexible accuracy: fast real-time navigation or survey-grade (<1 cm) mapping
- 🌍 Map-less RTK-quality outdoor georeferencing with low-cost GNSS + LiDAR + IMU
- 🛠️ Rich
.mmmetric map ecosystem: viewer, LAS/PLY/TXT export, filtering, georeferencing tools - 🤖 ROS 2 ready (Humble, Jazzy, Kilted, Rolling) but also usable from standalone pure C++
🚀 Demo videos
Lidar-Inertial-Odometry (LIO) demo with Oxford Spires:
Lidar-Odometry (LO) demo with GrandTour legged dataset:
Lidar-Odometry (LO) demo with KITTI:
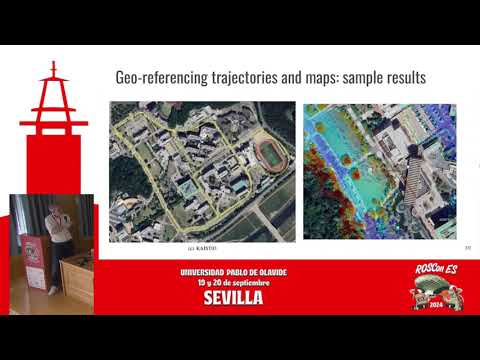
ROSCon Talk introducing MOLA
Video (Slides):
Individual package build status
Binary package build status per package and ROS 2 distro:
| Package | ROS 2 Humble (u22.04) |
ROS 2 Jazzy (u24.04) |
ROS 2 Kilted (u24.04) |
ROS 2 Lyrical (u26.04) |
ROS 2 Rolling (u26.04) |
|---|---|---|---|---|---|
| mola | |||||
| mola_bridge_ros2 | |||||
| mola_demos | |||||
| mola_input_lidar_bin_dataset | |||||
| mola_input_rawlog | |||||
| mola_input_rosbag2 | |||||
| mola_input_video | |||||
| mola_kernel | |||||
| mola_launcher | |||||
| mola_metric_maps | |||||
| mola_msgs | |||||
| mola_pose_list | |||||
| mola_relocalization | |||||
| mola_traj_tools | |||||
| mola_viz | |||||
| mola_yaml |
Each cell stacks the badges for that ROS 2 distro, in this order (when available):
- Ubuntu (
amd64) - Ubuntu (
arm64) - RHEL (
x86_64) -- not available for Humble, sincemrpt3cannot be built there. - Fedora (
x86_64) -- only available since ROS 2 Lyrical.
Citations
The latest publications on MOLA are (ArXiV).
@article{blanco2025mola_lo,
    author = {Jose Luis Blanco-Claraco},
    title = {{A flexible framework for accurate LiDAR odometry, map manipulation, and localization}},
    journal = {The International Journal of Robotics Research},
    volume = {44},
    number = {9},
    pages = {1553--1599},
    year = {2025},
    doi = {10.1177/02783649251316881},
    URL = { https://doi.org/10.1177/02783649251316881},
    eprint = {https://doi.org/10.1177/02783649251316881},
}
MOLA was initially presented in 2019 in (PDF):
@INPROCEEDINGS{Blanco-Claraco-RSS-19,
    AUTHOR    = {Jose Luis Blanco-Claraco},
    TITLE     = {{A Modular Optimization Framework for Localization and Mapping}},
    BOOKTITLE = {Proceedings of Robotics: Science and Systems},
    YEAR      = {2019},
    ADDRESS   = {FreiburgimBreisgau, Germany},
    MONTH     = {June},
    DOI       = {10.15607/RSS.2019.XV.043}
}
License
MOLA follows an Open Core model. Core modules are released under the GNU GPL v3 license, while foundational libraries (MRPT, mp2p_icp) are BSD-3.
Commercial use: Companies needing to deploy MOLA in closed-source products can obtain a commercial license (MOLA Pro).
See the Plans & Pricing page for details on Community vs Pro editions.
Contributions require acceptance of the Contributor License Agreement (CLA).
Star History
Explore related projects
codecrafters-io/build-your-own-x
Master programming by recreating your favorite technologies from scratch.
561,375 starspublic-apis/public-apis
A collective list of free APIs
497,650 starsmorluto/rea
Reverse engineer anything with agents, from app behavior down to native binaries.
447,211 starsopenclaw/openclaw
The AI that really does things. Any OS. Any Platform. The lobster way. 🦞
394,260 stars