
KumarRobotics/CoverageControl
KumarRobotics/CoverageControl has 28 GitHub stars and 6 forks. Star changes are not measured yet. Last checked 2026-11-14 08:38 UTC. Last push 2026-09-14.
Measured star growth
- in 24h
- Collecting history
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
About
Environment for coverage control and learning using GNN
Machine LearningREADME.md
OriginalSee full documentation at https://KumarRobotics.github.io/CoverageControl/
Introduction
Coverage control is the problem of navigating a robot swarm to collaboratively monitor features or a phenomenon of interest not known a priori.
The library provides a simulation environment, algorithms, and GNN-based architectures for the coverage control problem.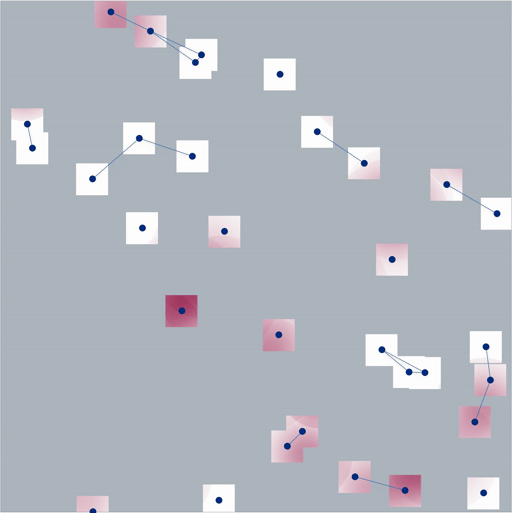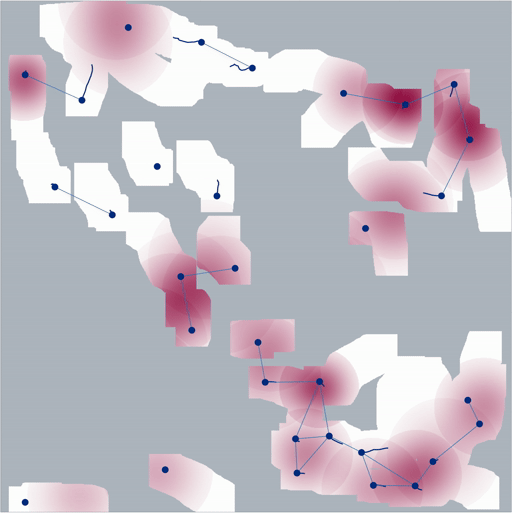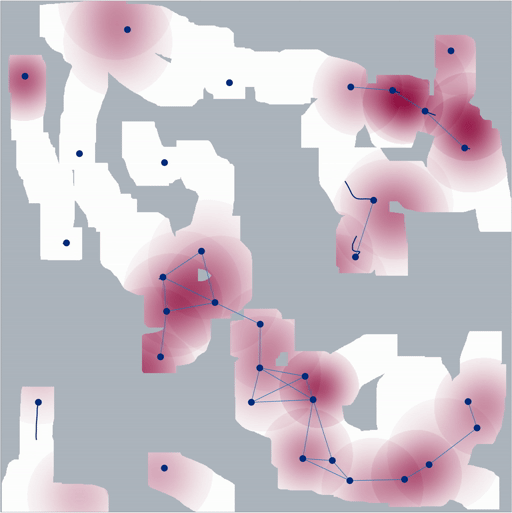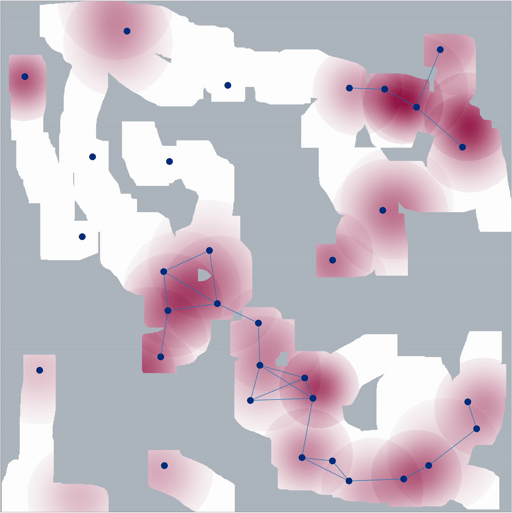
Key features:
- The core library is written in
C++andCUDAto handle large-scale simulations - There are
pythonbindings that interface with the core library - Several Centroidal Voronoi Tessellation (CVT)-based algorithms (aka Lloyd's algorithms)
- Learnable Perception-Action-Communication (LPAC) architecture for the coverage control problem is implemented in
PyTorchandPyTorch Geometric
Getting Started
The library is available as a pip package. To install the package, run the following command:
pip install coverage_control
See Installation for more details on installation.
See Quick Start guide for a quick introduction to the library.
Citation
@article{agarwal2024lpac,
      title         =   {LPAC: Learnable Perception-Action-Communication Loops with
                            Applications to Coverage Control},
      author        =   {Saurav Agarwal and Ramya Muthukrishnan and
                            Walker Gosrich and Vijay Kumar and Alejandro Ribeiro},
      year          =   {2024},
      eprint        =   {2401.04855},
      archivePrefix =   {arXiv},
      primaryClass  =   {cs.RO}
}
LPAC: Learnable Perception-Action-Communication Loops with Applications to Coverage Control.
Saurav Agarwal, Ramya Muthukrishnan, Walker Gosrich, Vijay Kumar, and Alejandro Ribeiro.
arXiv preprint arXiv:2401.04855 (2024).
Acknowledgements
- PyTorch
- PyTorch Geometric
- Eigen
- pybind11
- CGAL
- JSON for Modern C++
- CUDA Samples
- gnuplot-iostream
- hungarian-algorithm-cpp
- toml++
Support and Funding
The work was performed at the GRASP Laboratory and the Alelab, University of Pennsylvania, USA.
This work was supported in part by grants ARL DCIST CRA W911NF-17-2-0181 and ONR N00014-20-1-2822.
Contributors
- Saurav Agarwal
- Ramya Muthukrishnan
License
The library is licensed under the GPL-3.0 License. The documentation is not under the GPL-3.0 License and is licensed under the CC BY-NC-SA 4.0 License.
Explore related projects
tensorflow/tensorflow
An Open Source Machine Learning Framework for Everyone
201,593 starshuggingface/transformers
🤗 Transformers: the model-definition framework for state-of-the-art machine learning models in text, vision, audio, and multimodal models, for both inference and training.
168,960 starsAUTOMATIC1111/stable-diffusion-webui
Stable Diffusion web UI
165,311 starsComfy-Org/ComfyUI
The most powerful and modular diffusion model GUI, api and backend with a graph/nodes interface. The fastest local inference engine in the world.
146,747 stars