
IMPL-Lab/IAL has 32 GitHub stars and 5 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-14 18:46 UTC. Last push 2026-08-26.
Measured star growth
- in 24h
- 0
- in 7 days
- Collecting history
- in 15 days
- Collecting history
- in 1 month
- Collecting history
Net star changes over overlapping periods, not daily totals. Missing measurements are left blank. Stars measure attention, not software quality.
About
[ICML2025] Official Code for IAL (Multi-modal 3D Panoptic Segmentation Model)
Creative & MediaREADME.md
Original
🔥How Do Images Align and Complement LiDAR? Towards a Harmonized Multi-modal 3D Panoptic Segmentation
🥳Accepted at ICML 2025🥳
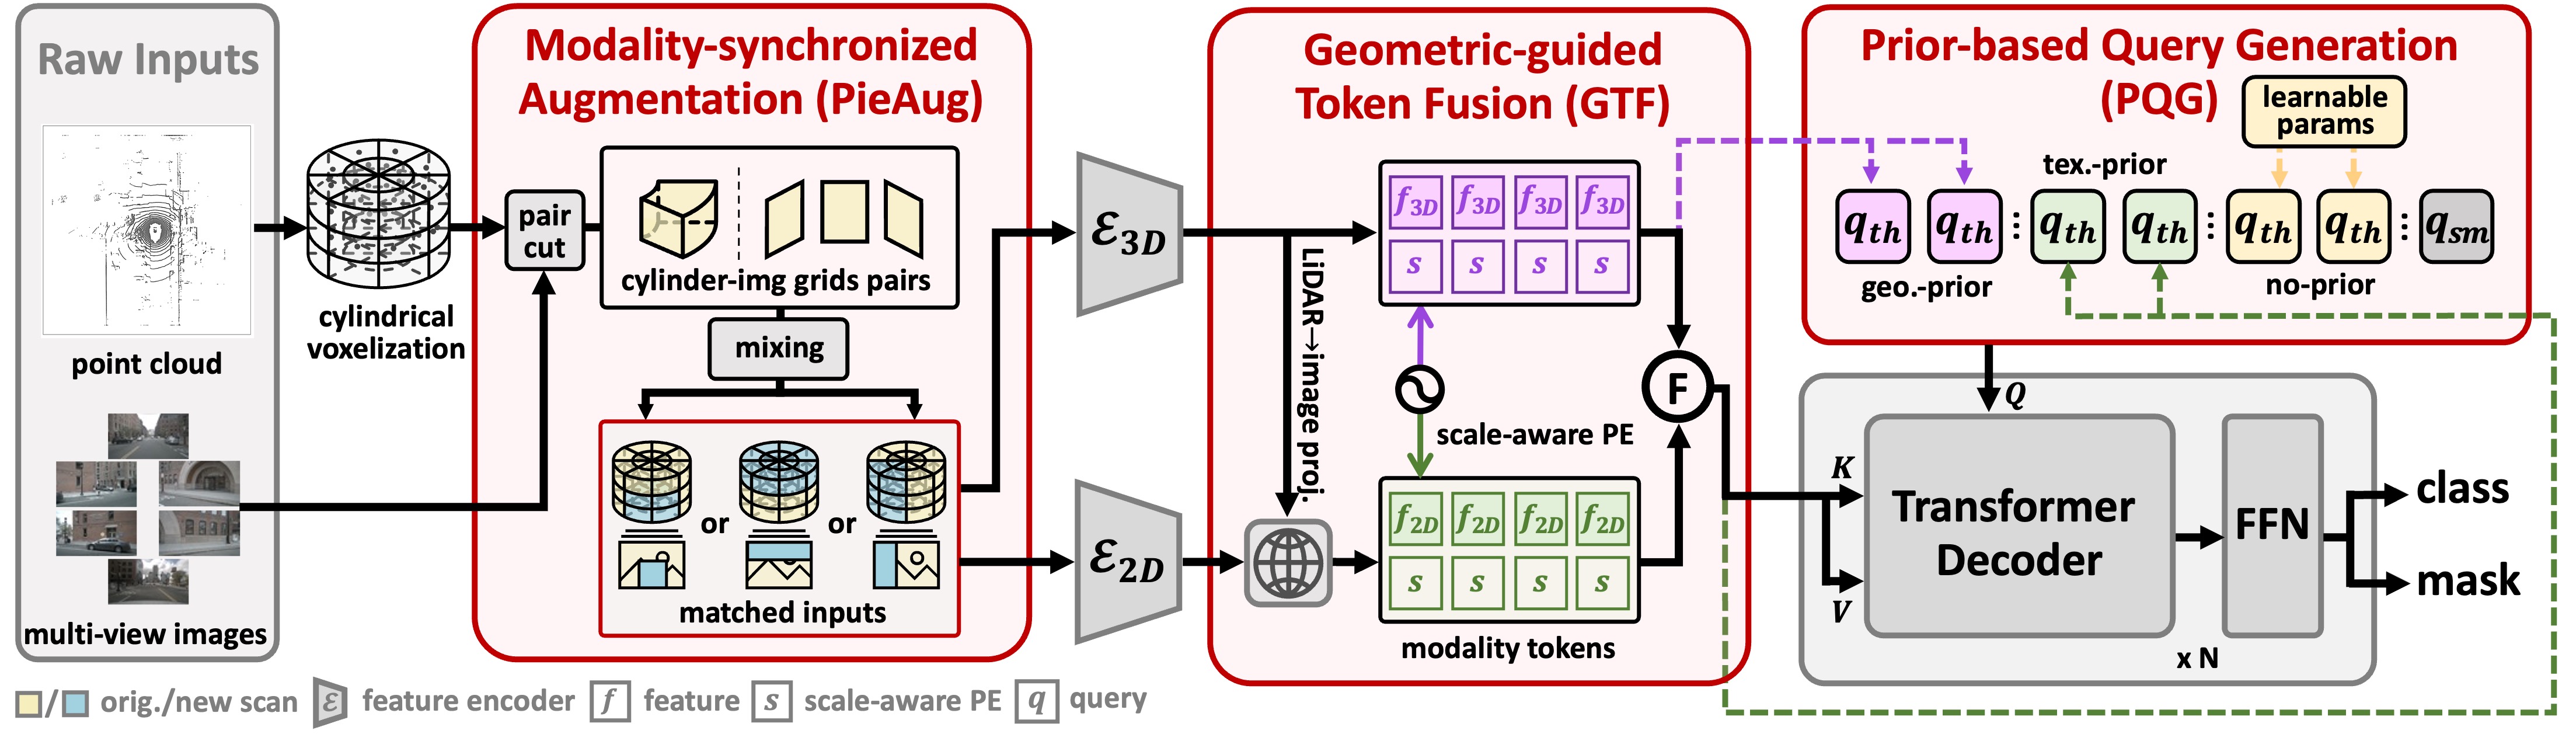
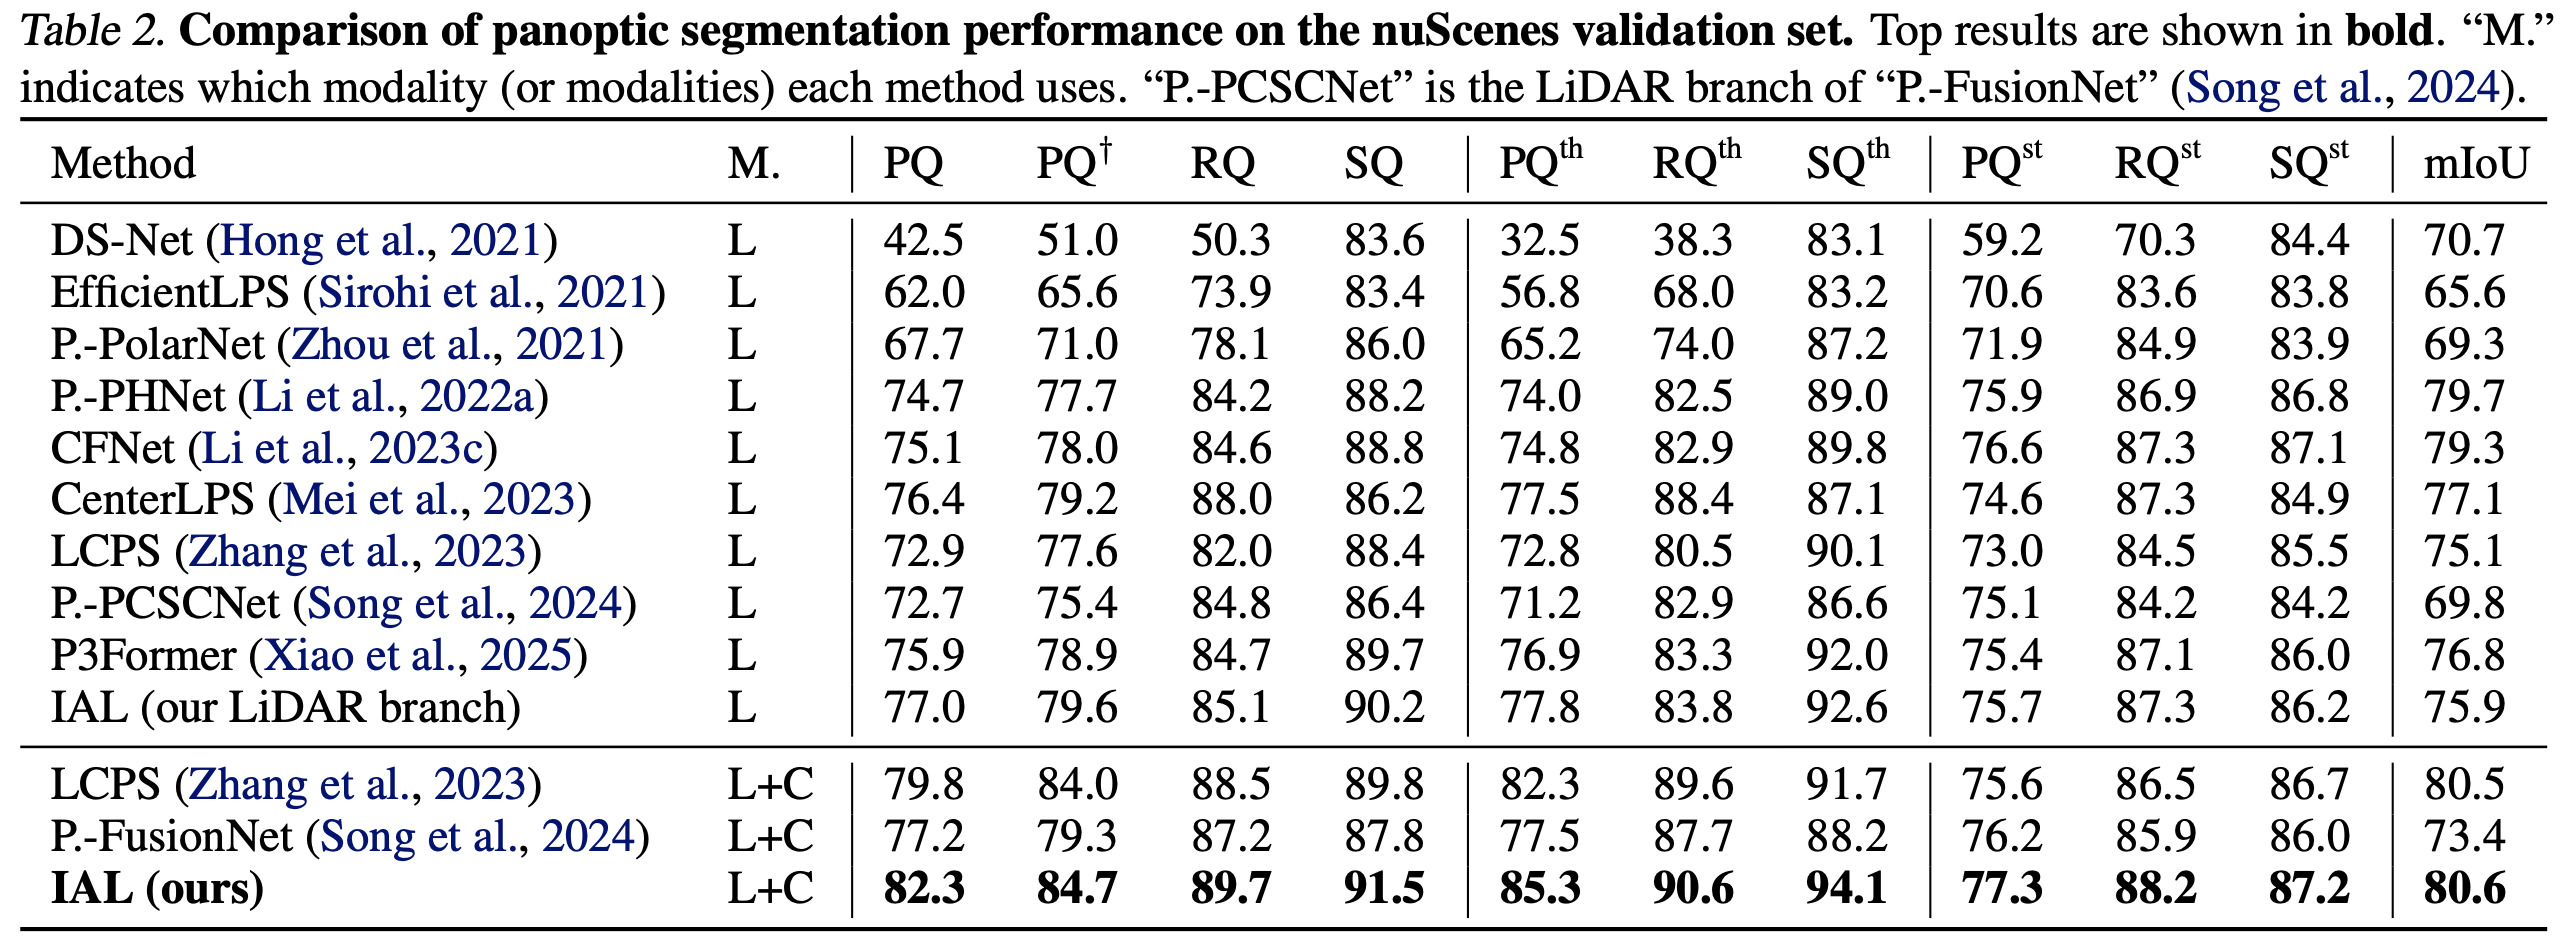
IAL is a novel multi-modal framework for LiDAR-camera 3D panoptic segmentation. To address misalignment and weak fusion, IAL designs a synchronized augmentation (PieAug) and a geometric-guided fusion module (GTF) to align LiDAR and image features. Moreover, it leverages complementary priors from both modalities as queries through PQG for stronger instance prediction. On nuScenes, IAL achieves 82.3% PQ, and on SemanticKITTI, it obtains 63.1% PQ, significantly surpassing previous methods.
Demo
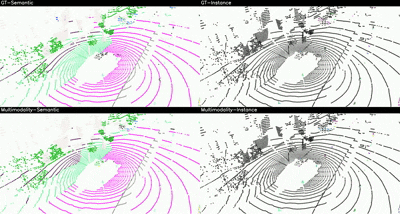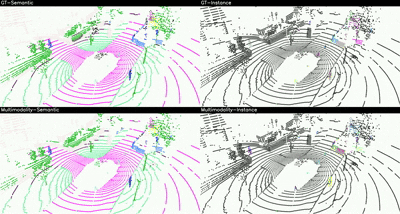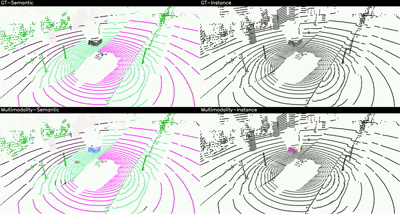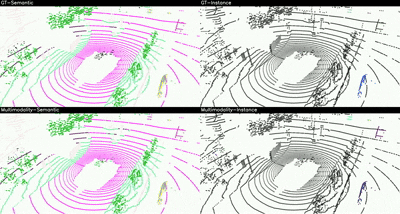
Framework Diagram
Preparation
Environments
Python == 3.8
CUDA == 11.1
pytorch == 1.10.1
mmcv == 2.0.0rc4
mmdet == 3.0.0
mmdet3d == 1.1.0
torch-scatter == 2.0.9
nms_lib
*Please see install.sh for more details.
Data Structure
Follow the mmdet3d to process the nuScenes dataset.
data/nuscenes_full/
├── gsam # save 2d proposals
├── lidarseg
├── maps
├── nuscenes_infos_test.pkl
├── nuscenes_infos_train.pkl
├── nuscenes_infos_val.pkl
├── panoptic
├── samples
├── sweeps
├── v1.0-trainval
You can generate *.pkl by excuting
python tools/create_data.py nuscenes --root-path data/nuscenes_full --out-dir data/nuscenes_full --extra-tag nuscenes
2D proposal Generation
# setup for Grounding-DINO
cd tools
git clone https://github.com/IDEA-Research/GroundingDINO.git
cd GroundingDINO
pip install -e .
# infer & save results
3-infer-gsam.sh
*Checkpoints and 2D preprocessing data are available huggingface and OneDrive.
Train & Inference
# train
sh 1-train.sh
# inference
sh 2-val.sh
Main Results
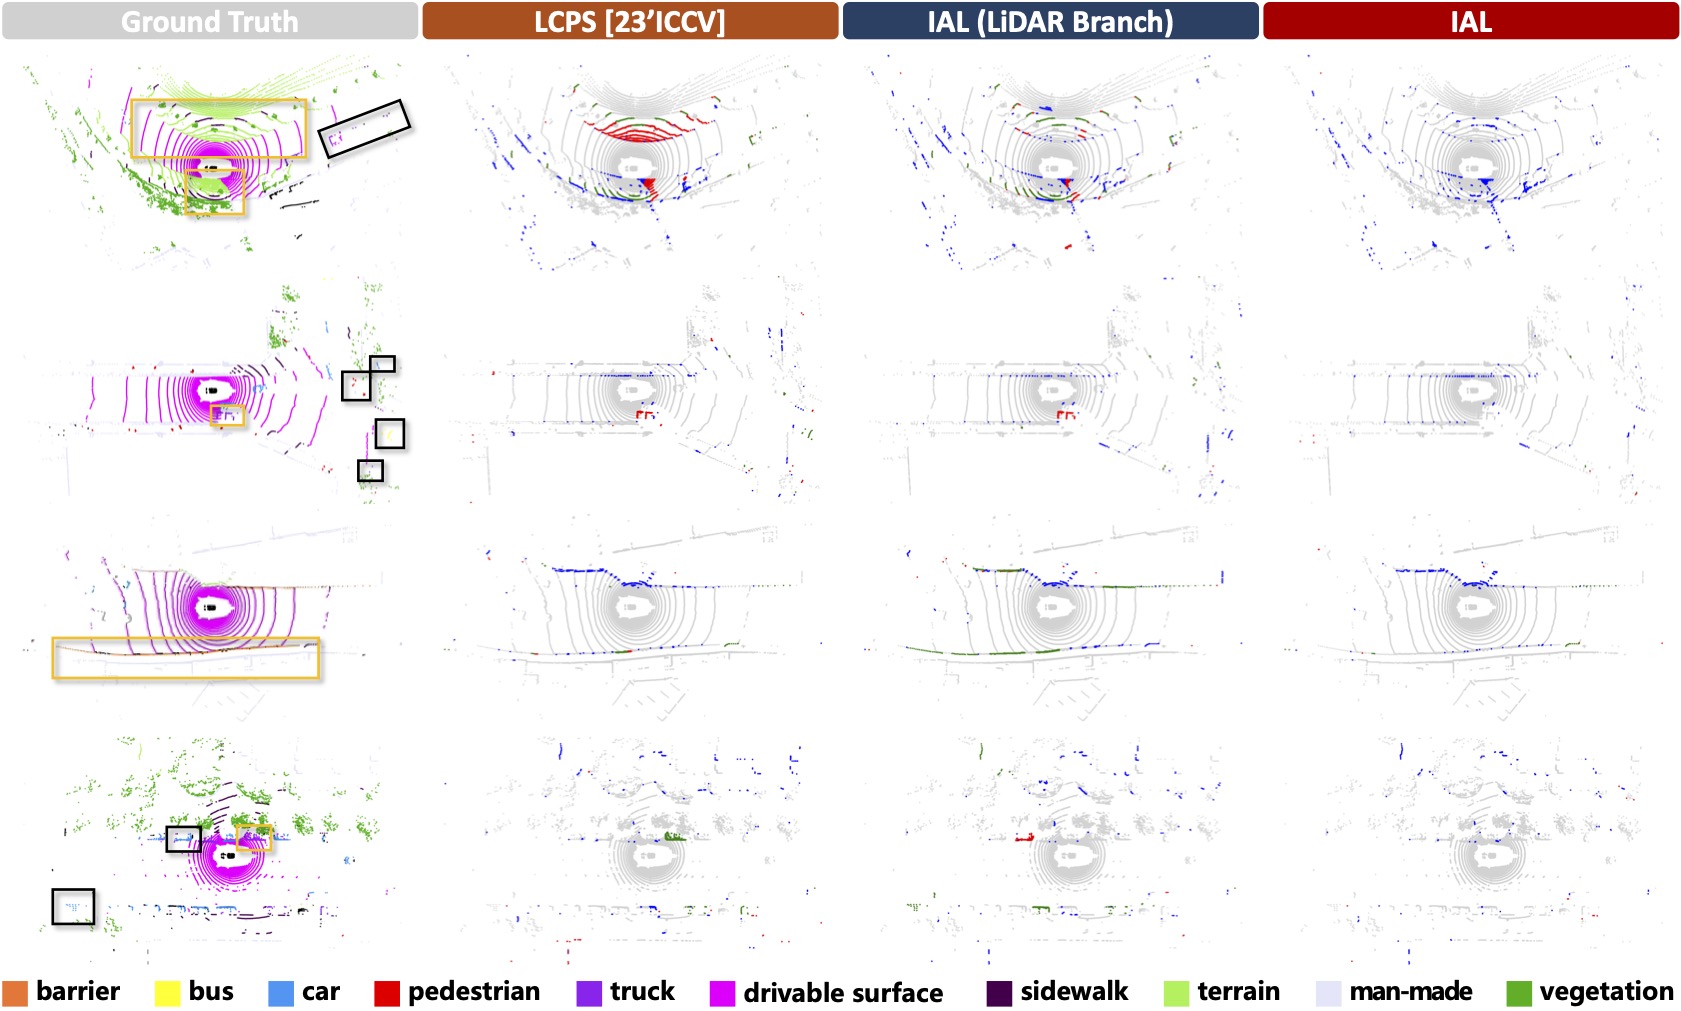
Visualization Results
Instance predictions on LiDAR and corresponding images.
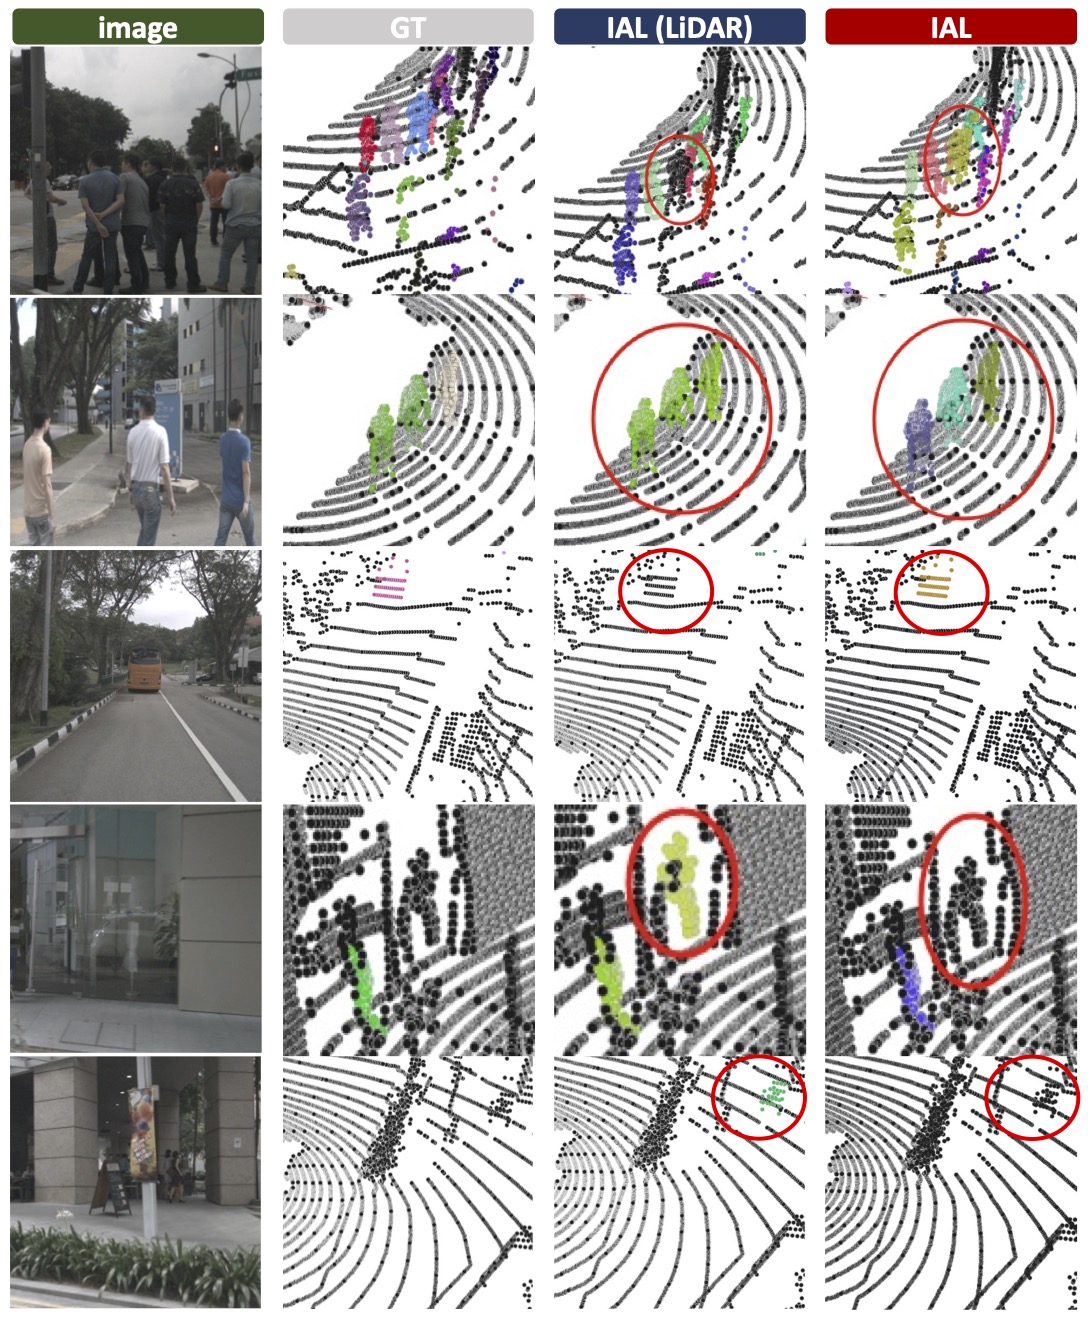 Error maps.
Citation
If you find this project helpful in your research, please consider citing our paper:
@inproceedings{pan2025ial,
      title={How Do Images Align and Complement LiDAR? Towards a Harmonized Multi-modal 3D Panoptic Segmentation},
      author={Yining Pan and Qiongjie Cui and Xulei Yang and Na Zhao},
      booktitle = {Proceedings of the 42st International Conference on Machine Learning},
      year={2025},
      series = {ICML'25}
}
Acknowledgement
Many thanks to the following awesome open-source projects!
Closely Relevant Projects:
Other Awesome Projects: