
TeleHuman/PBHC
TeleHuman/PBHC has 1,072 GitHub stars and 144 forks. GitHot measured 0 stars in 24 hours and +1 in 7 days. Last checked 2026-11-12 07:29 UTC. Last push 2026-07-01.
Official Implementation of "KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills"
측정된 스타 증가
- in 24h
- 0
- in 7 days
- +1
- in 15 days
- 기록 수집 중
- in 1 month
- 기록 수집 중
서로 겹치는 기간의 순증가량이며 일별 합계가 아닙니다. 측정값이 없으면 비워 둡니다. 스타는 관심도를 나타내며 품질을 보장하지 않습니다.
README.md
Original
KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills
Weiji Xie* 1,2,
Jinrui Han* 1,2,
Jiakun Zheng* 1,3,
Huanyu Li1,4,
Xinzhe Liu1,5,
Jiyuan Shi1,
Weinan Zhang2,
Chenjia Bai†1,
Xuelong Li1
* Equal Contribution † Corresponding Author
1Institute of Artificial Intelligence (TeleAI), China Telecom
2Shanghai Jiao Tong University
3East China University of Science and Technology
4Harbin Institute of Technology
5ShanghaiTech University


KungfuBot2: Learning Versatile Motion Skills for Humanoid Whole-Body Control
Jinrui Han 1,2,
Weiji Xie 1,2,
Jiakun Zheng 1,3,
Jiyuan Shi1,
Weinan Zhang2,
Ting Xiao2,
Chenjia Bai†1,
† Corresponding Author
1Institute of Artificial Intelligence (TeleAI), China Telecom
2Shanghai Jiao Tong University
3East China University of Science and Technology

Demo
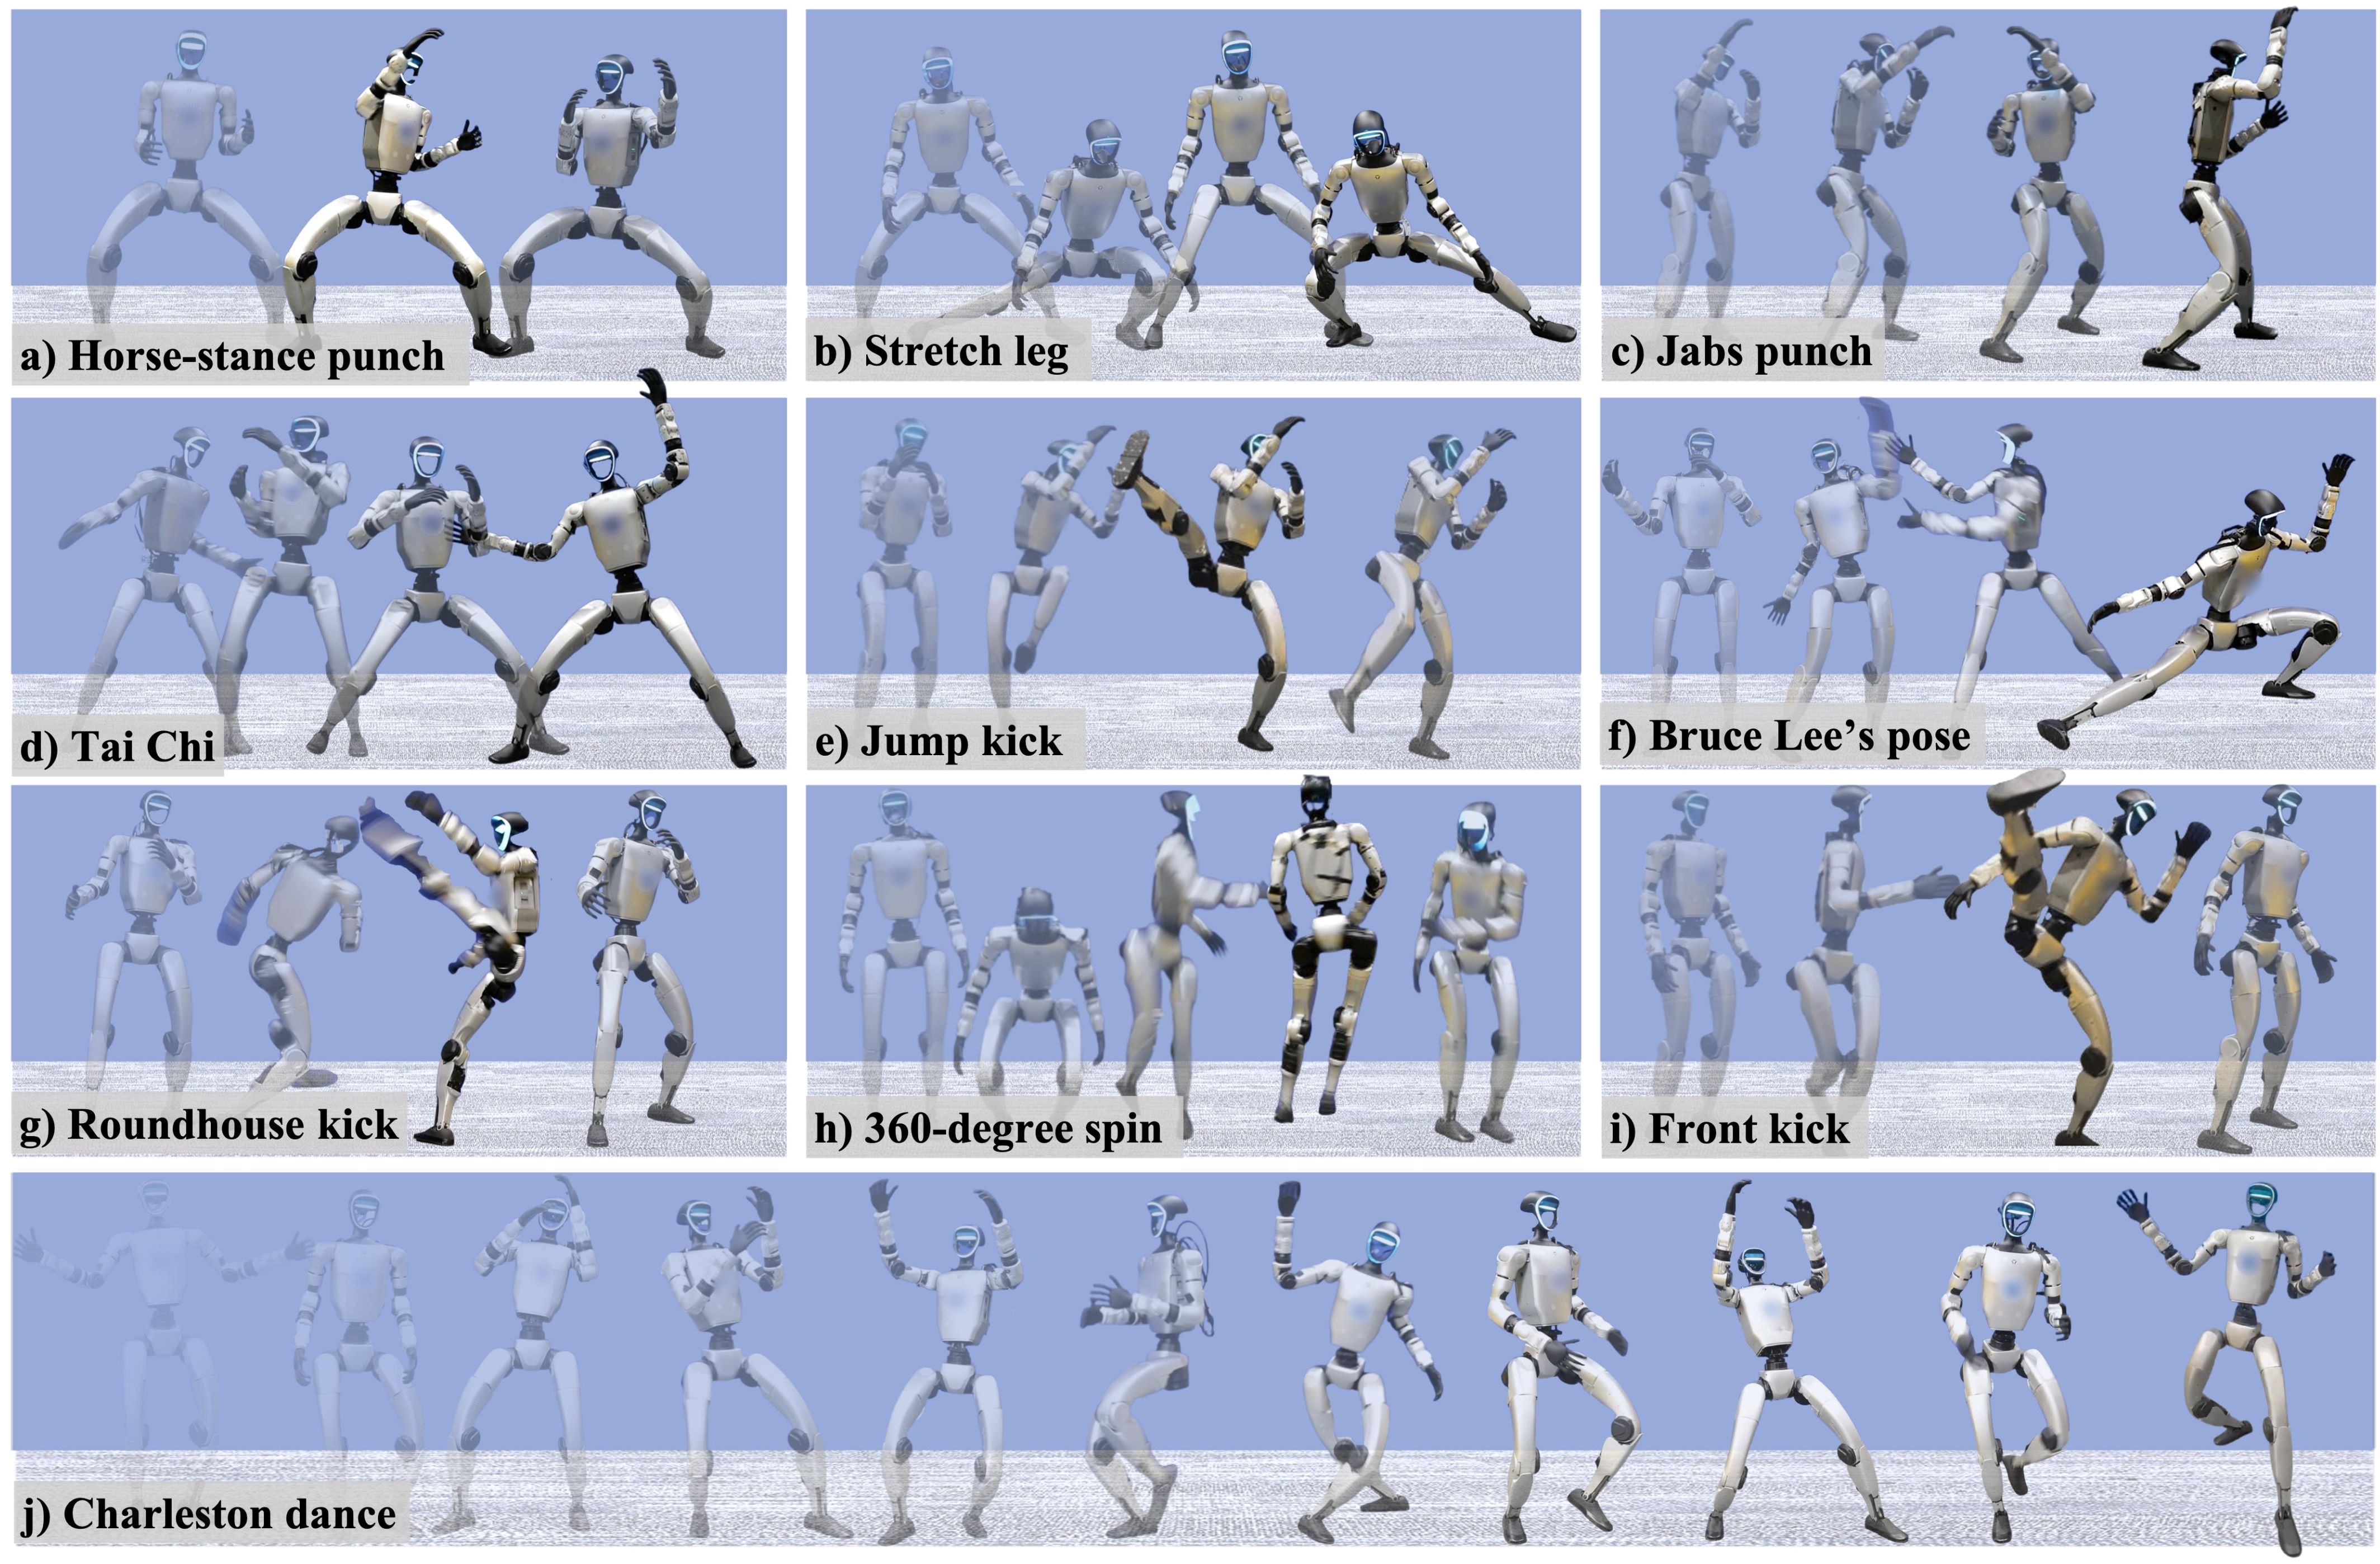
News
- [2025-10] Release support for general motion tracking.
- [2025-09] KungfuBot is accepted by NeurIPS 2025!
- [2025-06] We release the code and paper for PBHC.
Contents
About
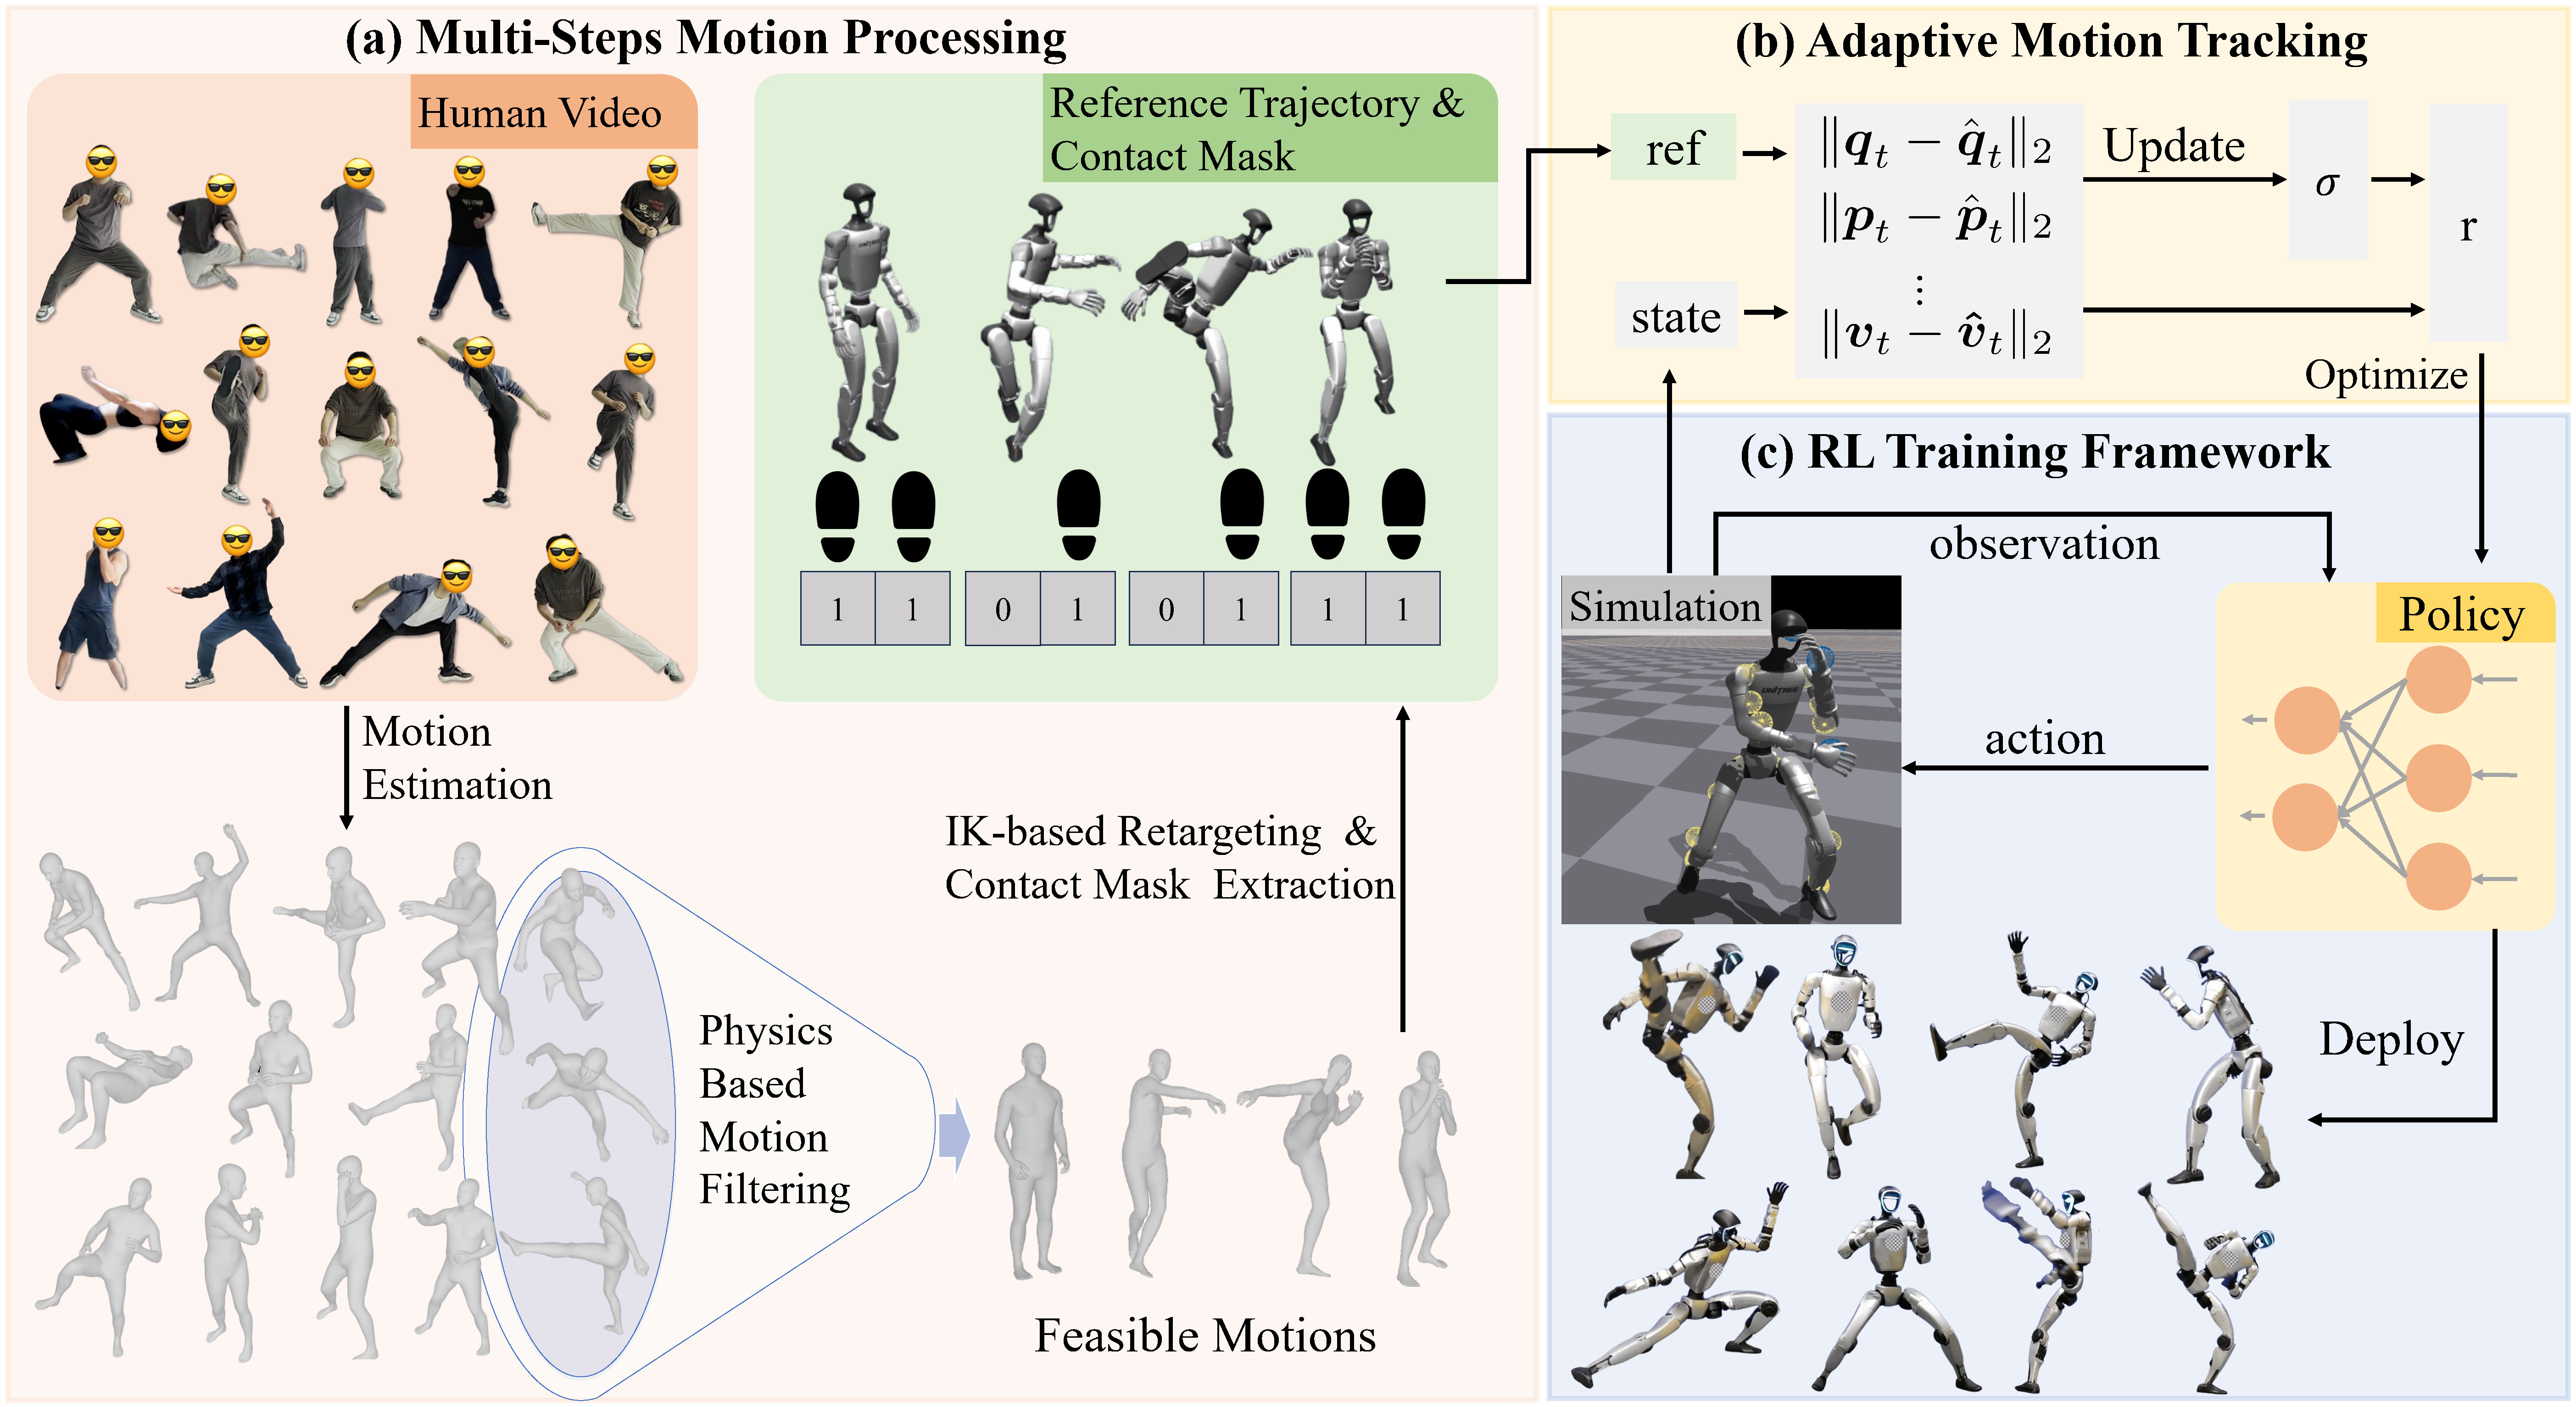
This is the official implementation of the paper KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills, supporting general motion tracking of the paper KungfuBot2: Learning Versatile Motion Skills for Humanoid Whole-Body Control.
Our paper introduces a physics-based control framework that enables humanoid robots to learn and reproduce challenging motions through multi-stage motion processing and adaptive policy training.
This repository includes:
- Motion processing pipeline
- Collect human motion from various sources (video, LAFAN, AMASS, etc.) to a unified SMPL format (
motion_source/) - Filter, correct and retarget human motion to the robot (
smpl_retarget/) - Visualize and analyze the processed motions (
smpl_vis/,robot_motion_process/)
- Collect human motion from various sources (video, LAFAN, AMASS, etc.) to a unified SMPL format (
- RL-based motion imitation framework (
humanoidverse/)- Train the policy in IsaacGym
- Deploy trained policies in MuJoCo for sim2sim verification. The framework is designed for easy extension--custom policies and real-world deployment modules can be plugged in with minimal effort
- Example data (
example/)- Sample motion data in our experiments (
example/motion_data/, you can visualize the motion data with tools inrobot_motion_process/) - A pretrained policy checkpoint (
example/pretrained_hors_stance_pose/)
- Sample motion data in our experiments (
Usage
Refer to
INSTALL.mdfor environment setup and installation instructions.Each module folder (e.g.,
humanoidverse,smpl_retarget) contains a dedicatedREADME.mdexplaining its purpose and usage.How to let your robot perform a new motion?
- Collect the motion data from the source and process the motion data to the SMPL format (
motion_source/). - Retarget the motion data to the robot (
smpl_retarget/, chooseMinkorPHCpipeline as you like). - Visualize the processed motion to check whether the motion quality is satisfiable (
smpl_vis/,robot_motion_process/). - Train a policy for the processed motion in IsaacGym (
humanoidverse/). - Deploy the policy in MuJoCo or real-world robot (
humanoidverse/).
- Collect the motion data from the source and process the motion data to the SMPL format (
Folder Structure
description: provide description file for SMPL and G1 robot.motion_source: docs for getting SMPL format data.smpl_retarget: tools for SMPL to G1 robot retargeting.smpl_vis: tools for visualizing SMPL format data.robot_motion_process: tools for processing robot format motion. Including visualization, interpolation, and trajectory analysis.humanoidverse: training RL policyexample: example motion and ckpt for using PBHC
Citation
If you find our work helpful, please cite:
@article{xie2025kungfubot,
  title={KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills},
  author={Xie, Weiji and Han, Jinrui and Zheng, Jiakun and Li, Huanyu and Liu, Xinzhe and Shi, Jiyuan and Zhang, Weinan and Bai, Chenjia and Li, Xuelong},
  journal={Advances in Neural Information Processing Systems},
  year={2025}
}

@article{han2025kungfubot2,
  title={KungfuBot2: Learning Versatile Motion Skills for Humanoid Whole-Body Control},
  author={Han, Jinrui and Xie, Weiji and Zheng, Jiakun and Shi, Jiyuan and Zhang, Weinan and Xiao, Ting and Bai, Chenjia},
  journal={arXiv preprint arXiv:2509.16638},
  year={2025}
}
License
This codebase is under CC BY-NC 4.0 license. You may not use the material for commercial purposes, e.g., to make demos to advertise your commercial products.
Acknowledgements
- ASAP: We use
ASAPlibrary to build our RL codebase. - Beyondmimic: We incorporate
Beyondmimicfeatures into policy training. - RSL_RL: We use
rsl_rllibrary for the PPO implementation. - Unitree: We use
Unitree G1as our testbed robot. - Maskedmimic: We use the retargeting pipeline in
Maskedmimic, which based on Mink. - PHC: We incorporate the retargeting pipeline from
PHCinto our implementation. - GVHMR: We use
GVHMRto extract motions from videos. - IPMAN: We filter motions based on
IPMANcodebase.
Contact
Feel free to open an issue or discussion if you encounter any problems or have questions about this project.
For collaborations, feedback, or further inquiries, please reach out to:
- Weiji Xie: [email protected] or Weixin
shisoul - Jinrui Han: [email protected] or Weixin
Bw_rooneY - Chenjia Bai (Corresponding Author): [email protected]
We welcome contributions and are happy to support the community in building upon this work!
관련 프로젝트 살펴보기
sindresorhus/awesome
😎 온갖 흥미로운 주제에 관한 Awesome 목록 [참고: 기존 풀 리퀘스트를 따라잡을 여유가 생길 때까지 풀 리퀘스트가 일시적으로 비활성화되어 있습니다]
535,622 스타EbookFoundation/free-programming-books
:books: 무료로 이용할 수 있는 프로그래밍 도서
401,471 스타nilbuild/developer-roadmap
개발자의 커리어 성장을 돕는 인터랙티브 로드맵, 가이드 및 기타 교육 콘텐츠.
371,887 스타vinta/awesome-python
“Python으로 X를 하고 싶은데, 어떤 도구를 써야 할까?”에 답하는 결정판 목록.
334,201 스타