
Everloom-129/Awesome-Memory-for-Robotics
Everloom-129/Awesome-Memory-for-Robotics has 179 GitHub stars and 10 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-17 16:25 UTC. Last push 2026-11-05.
측정된 스타 증가
- in 24h
- 0
- in 7 days
- 기록 수집 중
- in 15 days
- 기록 수집 중
- in 1 month
- 기록 수집 중
서로 겹치는 기간의 순증가량이며 일별 합계가 아닙니다. 측정값이 없으면 비워 둡니다. 스타는 관심도를 나타내며 품질을 보장하지 않습니다.
소개
Research reading list on memory for robotics
학습README.md
OriginalAwesome-Memory-for-Robotics
🤖 Memory is a fundamental capability to store, retrieve, and utilize past experiences for improved perception, planning, and decision-making. This mechanism enables robots to learn from experience, adapt to new situations, and operate effectively in complex, dynamic environments.
Here we organized a list of resources on memory for robotics, including papers, code, datasets, and benchmarks.
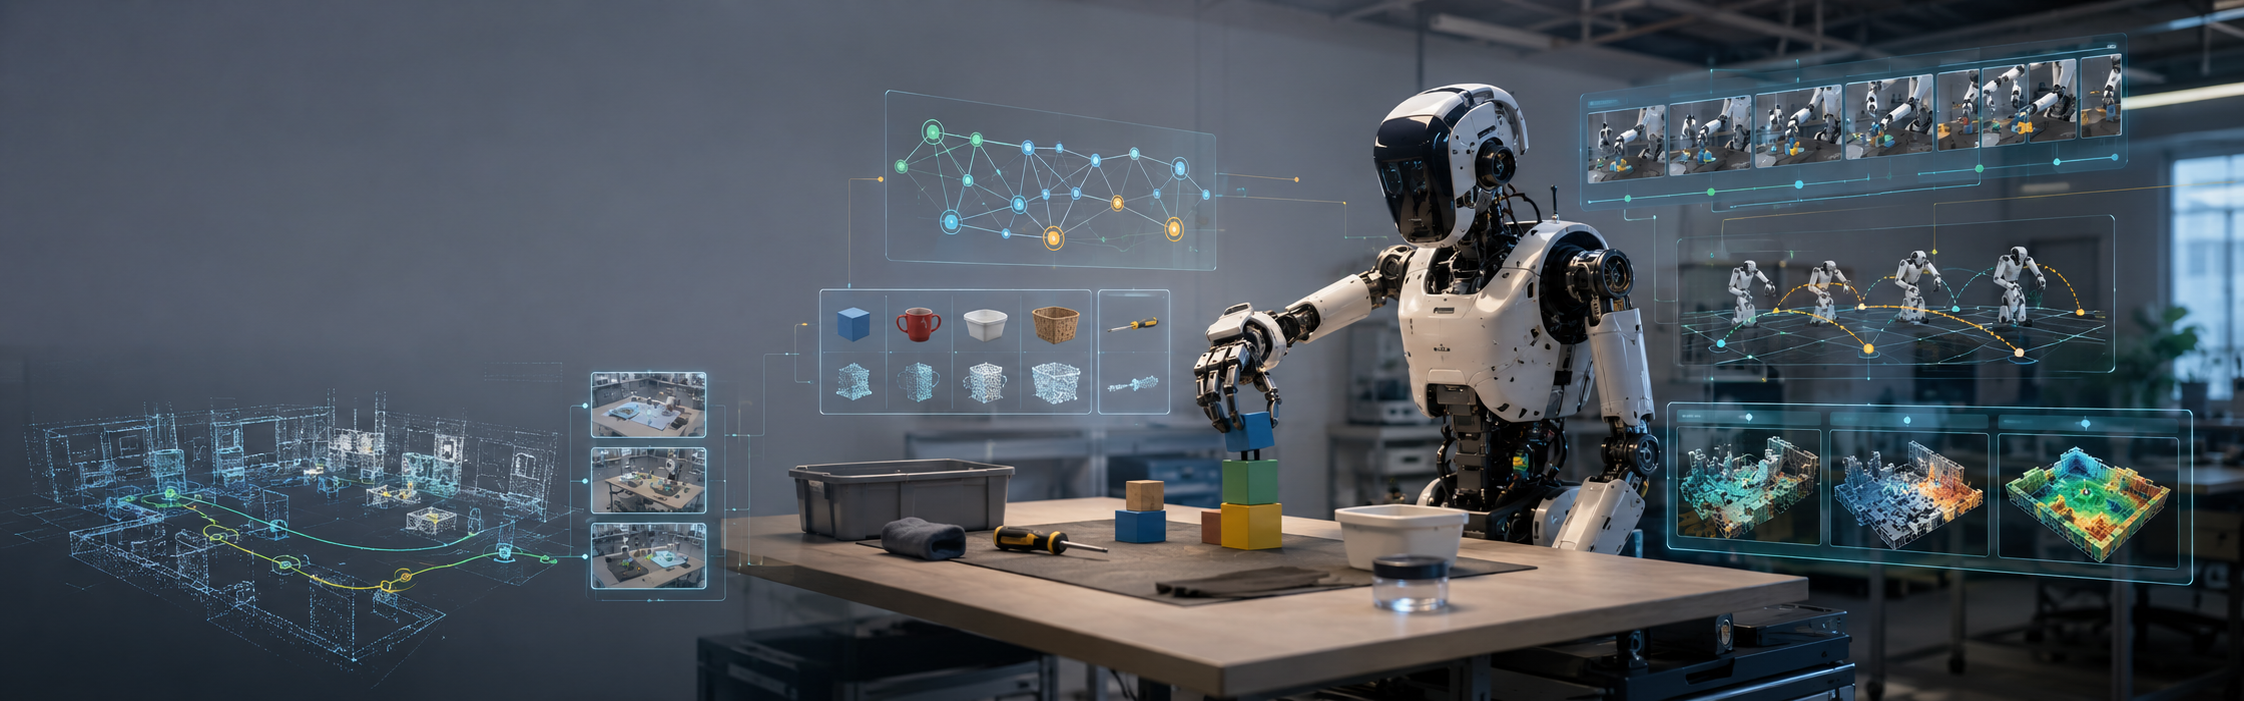
Scope: Robotics + Memory , not generic LLM memory.
📢 Update
2026-11-05: Added a taxonomic index of memory in robotic foundation-model systems.
2026-11-02 — October 2026 edition: Added nine October papers and HuMeGo, covering latent, executable, episodic, and persistent robotic memory. Literature cutoff: 2026-10-31; preprints are labeled arXiv.
2026-10-06: Major update covering June to October 2026, with expanded research categories and evaluation resources.
2026-06-06: Expanded foundation model and manipulation coverage.
2026-06-05: Updated benchmarks and code links.
2026-05-28: Expanded research coverage and foundation model categories.
2026-05-23: Updated memory methods, benchmarks, and the banner.
2026-02-01: Expanded object retrieval and scene memory coverage.
2026-01-15: Expanded the taxonomy to include memory for longer tasks.
2026-01-12: Clarified memory categories and updated the citation.
2026-01-08: Reorganized categories and corrected links and metadata.
2026-01-06: Expanded memory research coverage.
2026-01-05: Initialized the reading list and taxonomy.
Literature indices: October 2026 · Memory in robotic foundation-model systems.
📋 Table of Contents
- Surveys & Overviews
- Memory Systems & Cognitive Architecture
- Memory for Manipulation
- Memory for Navigation
- Memory for Locomotion
- Spatial & Scene Memory
- World Models & Memory
- Lifelong Learning & Continual Learning
- Benchmarks & Evaluation
- Datasets
- Contributing
Taxonomy
Memory in robotics often mixes multiple axes:
- Timescale
- Contextual memory (within-episode, short-term working memory)
- Episodic memory (experience replay / trajectories / videos)
- Semantic memory (facts, object affordances, task graphs)
- Long-term memory (stable knowledge across tasks)
- Representation
- key-value / slot memory, RNN / LSTM / Transformer state
- retrieval over embeddings (RAG / vector DB)
- 3D maps / NeRF / Gaussian splats / voxel grids
- symbolic graphs (scene graphs / task graphs)
- Usage
- policy conditioning (retrieve then act)
- planning (search over remembered states)
- perception (temporal integration / object permanence)
- safety & failure recovery (remember mistakes)
Read more: docs/taxonomy.md
Surveys & Overviews
There hasn't been a comprehensive survey on memory for robotics, we hope this list can help.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MemoryArena: Benchmarking Agent Memory in Interdependent Multi-Session Agentic Tasks | arXiv | 2026 | [Paper] |
| World Model for Robot Learning: A Comprehensive Survey | arXiv | 2026 | [Paper] |
| From Human Memory to AI Memory: A Survey on Memory Mechanisms in the Era of LLMs | arXiv | 2025 | [Paper] |
| Foundation Models in Robotics: Applications, Challenges, and the Future | IJRR | 2025 | [Paper] |
| Foundation Model Driven Robotics: A Comprehensive Review | arXiv | 2025 | [Paper] |
| Partially Observable Markov Decision Processes in Robotics: A Survey | IEEE T-RO | 2022 | [Paper] |
| Skill Transfer Learning for Autonomous Robots and Human-Robot Cooperation: A Survey | RAS | 2020 | [Paper] |
Memory Systems & Cognitive Architecture
Memory systems for robots draw on cognitive architectures to organize information for perception, planning, and action.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MEMORA: Embodied Action Memory from Egocentric Videos for Reasoning and Planning | EMNLP | 2026 | [Paper] [Code] |
| HiMe: Hierarchical Embodied Memory for Long-Horizon Vision-Language-Action Control | ICML | 2026 | [Paper] [Project] |
| RoboHarness: A Memory-Augmented Policy Harness for Vision-Language-Action Model Robustness via In-Context Adaptation | IROS | 2026 | [Paper] [Code] |
| RoboMemory: A Brain-inspired Multi-memory Agentic Framework for Interactive Environmental Learning in Physical Embodied Systems | arXiv | 2025 | [Paper] |
| A Memory System of a Robot Cognitive Architecture and its Implementation in ArmarX | RAS | 2023 | [Paper] |
| A Memory System for a Conscious Robot | Frontiers | 2018 | [Paper] |
| Memory as the Substrate of Cognition: A Developmental Cognitive Robotics Perspective | ResearchGate | 2015 | [Paper] |
| Dynamic Learning in Cognitive Robotics through a Procedural Long Term Memory | EAAI | 2013 | [Paper] |
| The Development of Embodied Cognition: Six Lessons from Babies | Artificial Life | 2005 | [Paper] |
MEMORA primarily evaluates memory from egocentric videos and high-level planning.
Further, I divide memory into four categories: Contextual memory, episodic memory, semantic memory, and long-horizon memory.
Contextual Memory
Working memory maintains task-relevant information during execution. It enables robots to track object states, maintain spatial awareness, and hold intermediate computation results. It is usually implemented by keyframe, history and context-window.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Memory before Goal: Role of Pre-History Memory for Humanoid Loco-Manipulation | arXiv | 2026 | [Paper] |
| Plan First, Act Later: Streaming Reasoning for Executable Memory in Robot Control | arXiv | 2026 | [Paper] |
| Mem4Act: Learning Effective Latent Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| LTM: Latent Transition Based In-Context Memory for Vision-Language-Action Models | arXiv | 2026 | [Paper] |
| Can a Frontier VLM Serve as a Robot Policy for Memory-Dependent Manipulation? | arXiv | 2026 | [Paper] |
| Divide-and-Remember: Recursive Action-Relevant Memory for Long-Horizon VLA Policies | arXiv | 2026 | [Paper] [Project] |
| Benchmarking and Enhancing Skill-Level Memory for Partially Observable Robotic Manipulation | arXiv | 2026 | [Paper] [Project] |
| Remember What You Did: Action-History Memory with Dual-Expert Denoising for Long-Horizon Vision-Language-Action Policies | arXiv | 2026 | [Paper] |
| T²Mem: Learning Test-Time Memory for Robotics | arXiv | 2026 | [Paper] [Project] |
| Where Memory Belongs: Ledger, an Object Ledger for Memory-Augmented VLAs | arXiv | 2026 | [Paper] |
| DRAM: Delta-rule Recurrent Associative Memory for Robot Manipulation Policies | arXiv | 2026 | [Paper] |
| Echo in the Steps: Learning Perceptive Humanoid Parkour with Gated Memory | arXiv | 2026 | [Paper] |
| Workspace Models: Lightweight Robotic Memory via Saliency-Driven Supervision | CoRL | 2026 | [Paper] |
| GLAM: Training a latent world model over global spatiotemporal memory for active exploration and navigation | arXiv | 2026 | [Paper] |
| Embodied-Navigator: Point, Think, Memorize, and Align for Efficient Navigation | arXiv | 2026 | [Paper] [Project] [Code] |
| OnEvoMemory: Evolving Memory through Online Robot Rollouts for Pretrained Robot Policies | ECCV Workshop | 2026 | [Paper] |
| BridgeVLA++: A Data-Efficient, Generalizable, and Memory-Augmented Vision-Language-Action Framework for 3D Manipulation | arXiv | 2026 | [Paper] [Project] |
| NativeMEM: Native Memory Compression for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HiMe: Hierarchical Embodied Memory for Long-Horizon Vision-Language-Action Control | ICML | 2026 | [Paper] [Project] |
| BIT-Nav: Brain-Inspired Trajectory Memory for Embodied Navigation | CVPR Workshop | 2026 | [Paper] |
| MemoryWAM: Efficient World Action Modeling with Persistent Memory | arXiv | 2026 | [Paper] [Project] |
| VL-MemKnG: Hybrid Memory with a Spatio-Temporal Knowledge Graph for Question Answering over Long Egocentric Navigation Trajectories | arXiv | 2026 | [Paper] |
| Scaling Short-Term Memory of Visuomotor Policies for Long-Horizon Tasks (PRISM) | arXiv | 2026 | [Paper] [Project] [Code] |
| HiMem-WAM: Hierarchical Memory-Gated World Action Models for Robotic Manipulation | arXiv | 2026 | [Paper] [Code] |
| Spatial Memory for Out-of-Vision Manipulation in Vision-Language-Action | ICML | 2026 | [Paper] |
| MemoAct: Atkinson-Shiffrin-Inspired Hierarchical Memory-Augmented Policy for Robotic Manipulation | RA-L | 2026 | [Paper] [Project] |
| VPWEM: Non-Markovian Visuomotor Policy with Working and Episodic Memory | RA-L | 2026 | [Paper] [Code] |
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| MemER: Scaling Up Memory for Robot Control via Experience Retrieval | arXiv | 2025 | [Paper] [Project] |
| Beyond Sliding Windows: Learning to Manage Memory in Non-Markovian Environments | arXiv | 2025 | [Paper] |
| Learning Long-Context Diffusion Policies via Past-Token Prediction | CoRL | 2025 | [Paper] [Project] |
| SAM2Act: Integrating Visual Foundation Model with A Memory Architecture for Robotic Manipulation | ICML | 2025 | [Paper] |
| A Working Memory Model Improves Cognitive Control in Agents and Robots | COGSYS | 2018 | [Paper] |
| Short-term Memory Mechanisms in Neural Network Learning of Robot Navigation Tasks | IEEE | 2010 | [Paper] |
Episodic Memory
Episodic memory stores specific events and experiences from the robot's past, enabling recall of particular situations, trajectories, and outcomes. It is usually implemented by memory banks, replay buffers, or latent tokens.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MemVLN: Streaming Episodic Memory for Vision-Language Navigation | arXiv | 2026 | [Paper] |
| MemBodied: Recurrent Associative Memory for Vision-Language-Action Models | arXiv | 2026 | [Paper] [Project] [Code] |
| Memory as Plans: World-Action Modeling with Memory-Grounded Planning | arXiv | 2026 | [Paper] [Project] |
| OnEvoMemory: Evolving Memory through Online Robot Rollouts for Pretrained Robot Policies | ECCV Workshop | 2026 | [Paper] |
| MEMORA: Embodied Action Memory from Egocentric Videos for Reasoning and Planning | EMNLP | 2026 | [Paper] [Code] |
| HiMe: Hierarchical Embodied Memory for Long-Horizon Vision-Language-Action Control | ICML | 2026 | [Paper] [Project] |
| DIM-WAM: World-Action Modeling with Diverse Historical Event Memory | arXiv | 2026 | [Paper] [Project] |
| RAVEN: Long-Horizon Reasoning & Navigation with a Visuo-Spatio-Temporal Memory | arXiv | 2026 | [Paper] [Project] [Code] |
| Mem-World: Memory-Augmented Action-Conditioned World Models for Persistent Robot Manipulation | CoRL | 2026 | [Paper] |
| VL-MemKnG: Hybrid Memory with a Spatio-Temporal Knowledge Graph for Question Answering over Long Egocentric Navigation Trajectories | arXiv | 2026 | [Paper] |
| MemoryVAM: Integrating Memory into Video Action Model for Robot Manipulation | arXiv | 2026 | [Paper] [Project] |
| MemoryVLA++: Temporal Modeling via Memory and Imagination in Vision-Language-Action Models | arXiv | 2026 | [Paper] [Project] |
| RoboHarness: A Memory-Augmented Policy Harness for Vision-Language-Action Model Robustness via In-Context Adaptation | IROS | 2026 | [Paper] [Code] |
| VPWEM: Non-Markovian Visuomotor Policy with Working and Episodic Memory | RA-L | 2026 | [Paper] [Code] |
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| MemoryVLA: Perceptual-Cognitive Memory in Vision-Language-Action Models for Robotic Manipulation | arXiv | 2025 | [Paper] |
| Forgetting in Robotic Episodic Long-Term Memory | ECAI | 2024 | [Paper] |
| Long Horizon Episodic Decision Making for Cognitively Inspired Robots | COGSYS | 2024 | [Paper] |
| Episodic Memory Model for Learning Robotic Manipulation | arXiv | 2021 | [Paper] |
| ART Neural Network-based Integration of Episodic Memory and Semantic Memory for Task Planning | AURO | 2019 | [Paper] |
| Deep Episodic Memory: Encoding, Recalling, and Predicting Episodic Experiences for Robot Action Execution | IEEE RAL | 2018 | [Paper] |
| Storing and Retrieving Perceptual Episodic Memories for Long-term Manipulation Tasks | ICAR | 2017 | [Paper] |
| Towards an Episodic Memory for Cognitive Robots | ECAI Workshop | 2008 | [Paper] |
Semantic Memory
Language provides robots with structured knowledge about concepts, objects, and their relationships. It is usually implemented by Neural Symbolic Model, Chain of Thought Reasoning, or Scene Graphs.
| Paper | Venue | Year | Links |
|---|---|---|---|
| ECoMEM: Explicit Concept Memory for Memory-Dependent Robot Control | arXiv | 2026 | [Paper] [Project] |
| Inline Memory Meets Reusable Skills: Memory-centric Framework for Vision-Language-Action Model | arXiv | 2026 | [Paper] |
| Where Memory Belongs: Ledger, an Object Ledger for Memory-Augmented VLAs | arXiv | 2026 | [Paper] |
| MessyMem: Learning-from-Doing Memory for Mobile Manipulation | CoRL | 2026 | [Paper] [Project] |
| Skills in Weights, Memory in Code: Hybrid Learning for Memory-Dependent Robot Manipulation | arXiv | 2026 | [Paper] |
| MEMORA: Embodied Action Memory from Egocentric Videos for Reasoning and Planning | EMNLP | 2026 | [Paper] [Code] |
| VL-MemKnG: Hybrid Memory with a Spatio-Temporal Knowledge Graph for Question Answering over Long Egocentric Navigation Trajectories | arXiv | 2026 | [Paper] |
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| GraSP-VLA: Graph-based Symbolic Action Representation for Long-Horizon Planning with VLA Policies | arXiv | 2025 | [Paper] |
| Enter the Mind Palace: Reasoning and Planning for Long-term Active Embodied Question Answering | arXiv | 2025 | [Paper] |
| Memory-Centric Embodied Question Answering | arXiv | 2025 | [Paper] |
| CRESTA: A Cognitivist Framework for Semantic-driven Task Awareness | RAS | 2025 | [Paper] |
| A Semantic Memory System for Task Planning under Uncertainties | IROS | 2010 | [Paper] |
| KnowRob: Knowledge processing for autonomous robots | IROS | 2009 | [Paper] |
| Robot Task Planning using Semantic Maps | RAS | 2008 | [Paper] |
Long-term Memory
Long-term memory enables continuous accumulation of knowledge across tasks and sessions, supporting lifelong learning and adaptation without catastrophic forgetting. It is usually implemented by experience replay, skill transfer, or continual learning.
| Paper | Venue | Year | Links |
|---|---|---|---|
| RoboArchitect: Automating the Design of Robotic Agents with Persistent Memory | arXiv | 2026 | [Paper] |
| EmbodiedRSI: Active Continual Robot Learning Through Hypothesis-Guided Co-Evolution | arXiv | 2026 | [Paper] |
| Inline Memory Meets Reusable Skills: Memory-centric Framework for Vision-Language-Action Model | arXiv | 2026 | [Paper] |
| MessyMem: Learning-from-Doing Memory for Mobile Manipulation | CoRL | 2026 | [Paper] [Project] |
| Memory Anchors for Continual Robot Learning | CoRL | 2026 | [Paper] [Project] |
| MEMORA: Embodied Action Memory from Egocentric Videos for Reasoning and Planning | EMNLP | 2026 | [Paper] [Code] |
| World Action Models Enable Continual Imitation Learning with Recurrent Generative Replays | arXiv | 2026 | [Paper] [Project] [Code] |
| RAVEN: Long-Horizon Reasoning & Navigation with a Visuo-Spatio-Temporal Memory | arXiv | 2026 | [Paper] [Project] [Code] |
| RoboHarness: A Memory-Augmented Policy Harness for Vision-Language-Action Model Robustness via In-Context Adaptation | IROS | 2026 | [Paper] [Code] |
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| RoboMemory: A Brain-inspired Multi-memory Agentic Framework for Interactive Environmental Learning in Physical Embodied Systems | arXiv | 2025 | [Paper] |
| Preserving and Combining Knowledge in Robotic Lifelong Reinforcement Learning | Nature Machine Intelligence | 2025 | [Paper] |
| LIBERO: Benchmarking Knowledge Transfer for Lifelong Robot Learning | NeurIPS | 2023 | [Paper] |
| Online Active Continual Learning for Robotic Lifelong Object Recognition | IEEE T-NNLS | 2023 | [Paper] |
| Lifelong Robotic Reinforcement Learning by Retaining Experiences | CoLLAs | 2022 | [Paper] |
| A lifelong learning approach to mobile robot navigation | ICRA | 2021 | [Paper] |
| Learning an Embedding Space for Transferable Robot Skills | ICLR | 2018 | [Paper] |
| RoboEarth: A World Wide Web for Robots | IEEE RA Mag | 2011 | [Paper] |
| RatSLAM: A hippocampal model for simultaneous localization and mapping | ICRA | 2004 | [Paper] |
| Lifelong robot learning | RAS | 1995 | [Paper] [Project] |
Memory for Manipulation
Robotics Foundation Models (RFMs)
Because non-markovian property makes RFMs like VLAs prone to overfit, it's a huge challenge for RFMs to learn memory. We need to design spatial-temporal memory mechanisms carefully.
| Paper | Venue | Year | Links |
|---|---|---|---|
| RoboArchitect: Automating the Design of Robotic Agents with Persistent Memory | arXiv | 2026 | [Paper] |
| Memory before Goal: Role of Pre-History Memory for Humanoid Loco-Manipulation | arXiv | 2026 | [Paper] |
| Plan First, Act Later: Streaming Reasoning for Executable Memory in Robot Control | arXiv | 2026 | [Paper] |
| Mem4Act: Learning Effective Latent Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| LTM: Latent Transition Based In-Context Memory for Vision-Language-Action Models | arXiv | 2026 | [Paper] |
| Can a Frontier VLM Serve as a Robot Policy for Memory-Dependent Manipulation? | arXiv | 2026 | [Paper] |
| EmbodiedRSI: Active Continual Robot Learning Through Hypothesis-Guided Co-Evolution | arXiv | 2026 | [Paper] |
| Divide-and-Remember: Recursive Action-Relevant Memory for Long-Horizon VLA Policies | arXiv | 2026 | [Paper] [Project] |
| ECoMEM: Explicit Concept Memory for Memory-Dependent Robot Control | arXiv | 2026 | [Paper] [Project] |
| Inline Memory Meets Reusable Skills: Memory-centric Framework for Vision-Language-Action Model | arXiv | 2026 | [Paper] |
| Remember What You Did: Action-History Memory with Dual-Expert Denoising for Long-Horizon Vision-Language-Action Policies | arXiv | 2026 | [Paper] |
| T²Mem: Learning Test-Time Memory for Robotics | arXiv | 2026 | [Paper] [Project] |
| Where Memory Belongs: Ledger, an Object Ledger for Memory-Augmented VLAs | arXiv | 2026 | [Paper] |
| DRAM: Delta-rule Recurrent Associative Memory for Robot Manipulation Policies | arXiv | 2026 | [Paper] |
| MemBodied: Recurrent Associative Memory for Vision-Language-Action Models | arXiv | 2026 | [Paper] [Project] [Code] |
| Memory as Plans: World-Action Modeling with Memory-Grounded Planning | arXiv | 2026 | [Paper] [Project] |
| Skills in Weights, Memory in Code: Hybrid Learning for Memory-Dependent Robot Manipulation | arXiv | 2026 | [Paper] |
| OnEvoMemory: Evolving Memory through Online Robot Rollouts for Pretrained Robot Policies | ECCV Workshop | 2026 | [Paper] |
| BridgeVLA++: A Data-Efficient, Generalizable, and Memory-Augmented Vision-Language-Action Framework for 3D Manipulation | arXiv | 2026 | [Paper] [Project] |
| NativeMEM: Native Memory Compression for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HiMe: Hierarchical Embodied Memory for Long-Horizon Vision-Language-Action Control | ICML | 2026 | [Paper] [Project] |
| DIM-WAM: World-Action Modeling with Diverse Historical Event Memory | arXiv | 2026 | [Paper] [Project] |
| World Action Models Enable Continual Imitation Learning with Recurrent Generative Replays | arXiv | 2026 | [Paper] [Project] [Code] |
| MemoryWAM: Efficient World Action Modeling with Persistent Memory | arXiv | 2026 | [Paper] [Project] |
| Mem-World: Memory-Augmented Action-Conditioned World Models for Persistent Robot Manipulation | CoRL | 2026 | [Paper] |
| MemoryVAM: Integrating Memory into Video Action Model for Robot Manipulation | arXiv | 2026 | [Paper] [Project] |
| HiMem-WAM: Hierarchical Memory-Gated World Action Models for Robotic Manipulation | arXiv | 2026 | [Paper] [Code] |
| MemoryVLA++: Temporal Modeling via Memory and Imagination in Vision-Language-Action Models | arXiv | 2026 | [Paper] [Project] |
| Spatial Memory for Out-of-Vision Manipulation in Vision-Language-Action | ICML | 2026 | [Paper] |
| RoboHarness: A Memory-Augmented Policy Harness for Vision-Language-Action Model Robustness via In-Context Adaptation | IROS | 2026 | [Paper] [Code] |
| π0.7: A Steerable Model with Emergent Capabilities | Physical Intelligence | 2026 | [Paper] [Project] |
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| OptimusVLA: Global Prior Meets Local Consistency: Dual-Memory Augmented Vision-Language-Action Model for Efficient Robotic Manipulation | CVPR | 2026 | [Paper] |
| MemER: Scaling Up Memory for Robot Control via Experience Retrieval | arXiv | 2025 | [Paper] [Project] |
| HAMLET: Switch your Vision-Language-Action Model into a History-Aware Policy | arXiv | 2025 | [Paper] [Project] |
| HiF-VLA: Hindsight, Insight and Foresight through Motion Representation for Vision-Language-Action Models | arXiv | 2025 | [Paper] |
| CronusVLA: Towards Efficient and Robust Manipulation via Multi-Frame Vision-Language-Action Modeling | ArKiv | 2025 | [Paper] [Project] |
| GraSP-VLA: Graph-based Symbolic Action Representation for Long-Horizon Planning with VLA Policies | arXiv | 2025 | [Paper] |
| MemoryVLA: Perceptual-Cognitive Memory in Vision-Language-Action Models for Robotic Manipulation | arXiv | 2025 | [Paper] |
Mobile Manipulation
| Paper | Venue | Year | Links |
|---|---|---|---|
| MessyMem: Learning-from-Doing Memory for Mobile Manipulation | CoRL | 2026 | [Paper] [Project] |
| VPWEM: Non-Markovian Visuomotor Policy with Working and Episodic Memory | RA-L | 2026 | [Paper] [Code] |
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| Searching in Space and Time: Unified Memory-Action Loops for Open-World Object Retrieval | arXiv | 2025 | [Paper] [Project] |
| DynaMem: Online Dynamic Spatio-Semantic Memory for Open World Mobile Manipulation | arXiv | 2024 | [Paper] |
| CLIP-Fields: Weakly Supervised Semantic Fields for Robotic Memory | RSS | 2023 | [Paper] [Project] |
General Manipulation
| Paper | Venue | Year | Links |
|---|---|---|---|
| Divide-and-Remember: Recursive Action-Relevant Memory for Long-Horizon VLA Policies | arXiv | 2026 | [Paper] [Project] |
| ECoMEM: Explicit Concept Memory for Memory-Dependent Robot Control | arXiv | 2026 | [Paper] [Project] |
| Inline Memory Meets Reusable Skills: Memory-centric Framework for Vision-Language-Action Model | arXiv | 2026 | [Paper] |
| Benchmarking and Enhancing Skill-Level Memory for Partially Observable Robotic Manipulation | arXiv | 2026 | [Paper] [Project] |
| Remember What You Did: Action-History Memory with Dual-Expert Denoising for Long-Horizon Vision-Language-Action Policies | arXiv | 2026 | [Paper] |
| T²Mem: Learning Test-Time Memory for Robotics | arXiv | 2026 | [Paper] [Project] |
| Where Memory Belongs: Ledger, an Object Ledger for Memory-Augmented VLAs | arXiv | 2026 | [Paper] |
| DRAM: Delta-rule Recurrent Associative Memory for Robot Manipulation Policies | arXiv | 2026 | [Paper] |
| MemBodied: Recurrent Associative Memory for Vision-Language-Action Models | arXiv | 2026 | [Paper] [Project] [Code] |
| Workspace Models: Lightweight Robotic Memory via Saliency-Driven Supervision | CoRL | 2026 | [Paper] |
| Memory as Plans: World-Action Modeling with Memory-Grounded Planning | arXiv | 2026 | [Paper] [Project] |
| Skills in Weights, Memory in Code: Hybrid Learning for Memory-Dependent Robot Manipulation | arXiv | 2026 | [Paper] |
| OnEvoMemory: Evolving Memory through Online Robot Rollouts for Pretrained Robot Policies | ECCV Workshop | 2026 | [Paper] |
| BridgeVLA++: A Data-Efficient, Generalizable, and Memory-Augmented Vision-Language-Action Framework for 3D Manipulation | arXiv | 2026 | [Paper] [Project] |
| NativeMEM: Native Memory Compression for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HiMe: Hierarchical Embodied Memory for Long-Horizon Vision-Language-Action Control | ICML | 2026 | [Paper] [Project] |
| DIM-WAM: World-Action Modeling with Diverse Historical Event Memory | arXiv | 2026 | [Paper] [Project] |
| MemoryWAM: Efficient World Action Modeling with Persistent Memory | arXiv | 2026 | [Paper] [Project] |
| Mem-World: Memory-Augmented Action-Conditioned World Models for Persistent Robot Manipulation | CoRL | 2026 | [Paper] |
| Scaling Short-Term Memory of Visuomotor Policies for Long-Horizon Tasks (PRISM) | arXiv | 2026 | [Paper] [Project] [Code] |
| MemoryVAM: Integrating Memory into Video Action Model for Robot Manipulation | arXiv | 2026 | [Paper] [Project] |
| HiMem-WAM: Hierarchical Memory-Gated World Action Models for Robotic Manipulation | arXiv | 2026 | [Paper] [Code] |
| MemoryVLA++: Temporal Modeling via Memory and Imagination in Vision-Language-Action Models | arXiv | 2026 | [Paper] [Project] |
| Spatial Memory for Out-of-Vision Manipulation in Vision-Language-Action | ICML | 2026 | [Paper] |
| RoboHarness: A Memory-Augmented Policy Harness for Vision-Language-Action Model Robustness via In-Context Adaptation | IROS | 2026 | [Paper] [Code] |
| MemoAct: Atkinson-Shiffrin-Inspired Hierarchical Memory-Augmented Policy for Robotic Manipulation | RA-L | 2026 | [Paper] [Project] |
| VPWEM: Non-Markovian Visuomotor Policy with Working and Episodic Memory | RA-L | 2026 | [Paper] [Code] |
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| RMBench: Memory-Dependent Robotic Manipulation Benchmark with Insights into Policy Design | arXiv | 2026 | [Paper] [Project] [Code] |
| Rethinking Progression of Memory State in Robotic Manipulation: An Object-Centric Perspective | AAAI | 2026 | [Paper] |
| Gated Memory Policy | arXiv | 2026 | [Paper] [Project] |
| OptimusVLA: Global Prior Meets Local Consistency: Dual-Memory Augmented Vision-Language-Action Model for Efficient Robotic Manipulation | CVPR | 2026 | [Paper] |
| Learning Long-Context Diffusion Policies via Past-Token Prediction | CoRL | 2025 | [Paper] [Project] |
| SAM2Act: Integrating Visual Foundation Model with A Memory Architecture for Robotic Manipulation | ICML | 2025 | [Paper] |
| Out of Sight, Still in Mind: Reasoning and Planning about Unobserved Objects with Video Tracking Enabled Memory Models | ICRA | 2024 | [Paper] |
| RoboEXP: Action-Conditioned Scene Graph via Interactive Exploration for Robotic Manipulation | CoRL | 2024 | [Paper] [Project] |
Memory for Navigation
Memory is of great importance for navigation, there has been rich research on it.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MemVLN: Streaming Episodic Memory for Vision-Language Navigation | arXiv | 2026 | [Paper] |
| AVALON: Zero-Shot Indoor Navigation with Human-Seeded Topological Memory | arXiv | 2026 | [Paper] |
| MemTransfer: Benchmarking Memory Beyond Matched Experience in Embodied Decision-Making | arXiv | 2026 | [Paper] |
| GLAM: Training a latent world model over global spatiotemporal memory for active exploration and navigation | arXiv | 2026 | [Paper] |
| EvoNav-Bench: Benchmarking Lifelong Navigation in Evolving Environments | arXiv | 2026 | [Paper] |
| Embodied-Navigator: Point, Think, Memorize, and Align for Efficient Navigation | arXiv | 2026 | [Paper] [Project] [Code] |
| RAVEN: Long-Horizon Reasoning & Navigation with a Visuo-Spatio-Temporal Memory | arXiv | 2026 | [Paper] [Project] [Code] |
| BIT-Nav: Brain-Inspired Trajectory Memory for Embodied Navigation | CVPR Workshop | 2026 | [Paper] |
| VL-MemKnG: Hybrid Memory with a Spatio-Temporal Knowledge Graph for Question Answering over Long Egocentric Navigation Trajectories | arXiv | 2026 | [Paper] |
| Remember to be Curious: Episodic Context and Persistent Worlds for 3D Exploration | arXiv | 2026 | [Paper] [Project] [Code] |
| Spatially-Enhanced Recurrent Memory for Long-Range Mapless Navigation via End-to-End Reinforcement Learning | arXiv | 2025 | [Paper] |
| MemoNav: Working Memory Model for Visual Navigation | CVPR | 2024 | [Paper] |
| Memory-Maze: Scenario Driven Benchmark and Visual Language Navigation Model for Guiding Blind People | arXiv | 2024 | [Paper] |
| Visual Language Maps for Robot Navigation (VLMaps) | ICRA | 2023 | [Paper] [Project] |
| Emergence of Maps in the Memories of Blind Navigation Agents | ICLR | 2023 | [Paper] [Project] |
| Memory-Augmented Reinforcement Learning for Image-Goal Navigation | IROS | 2022 | [Paper] |
| Structured Scene Memory for Vision-Language Navigation | CVPR | 2021 | [Paper] |
| Visual Graph Memory with Unsupervised Representation for Visual Navigation | ICCV | 2021 | [Paper] |
| Deep Visual Odometry With Adaptive Memory | TPAMI | 2020 | [Paper] |
| MultiON: Benchmarking Semantic Map Memory using Multi-Object Navigation | NeurIPS | 2020 | [Paper] |
| Scene Memory Transformer for Embodied Agents in Long-Horizon Tasks | CVPR | 2019 | [Paper] |
| Visual Memory for Robust Path Following | NeurIPS | 2018 | [Paper] |
| Cognitive Memory and Mapping in a Brain-like System for Robotic Navigation | Neural Networks | 2017 | [Paper] |
| Learning Indoor Robot Navigation using Visual and Sensorimotor Map | PMC | 2013 | [Paper] |
| Image-based Robot Navigation from an Image Memory | RAS | 2007 | [Paper] |
| 3D Navigation based on a Visual Memory | ICRA | 2006 | [Paper] |
Memory for Locomotion
| Paper | Venue | Year | Links |
|---|---|---|---|
| Memory before Goal: Role of Pre-History Memory for Humanoid Loco-Manipulation | arXiv | 2026 | [Paper] |
| Echo in the Steps: Learning Perceptive Humanoid Parkour with Gated Memory | arXiv | 2026 | [Paper] |
| LocoFormer: Generalist Locomotion via Long-context Adaptation | CoRL | 2025 | [Paper] [Project] |
| Sim-to-Real Transfer for Quadrupedal Locomotion via Terrain Transformer (TERT) | RA-L | 2023 | [Paper] |
| Learning Vision-Guided Quadrupedal Locomotion End-to-End with Cross-Modal Transformers (LocoTransformer) | ICLR | 2022 | [Paper] [Project] |
| RMA: Rapid Motor Adaptation for Legged Robots | RSS | 2021 | [Paper] [Project] |
| Rapidly Adaptable Legged Robots via Evolutionary Meta-Learning | IROS | 2020 | [Paper] [Blog] |
Spatial & Scene Memory
3D Scene Memory
Representing and reasoning about 3D environments.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MessyMem: Learning-from-Doing Memory for Mobile Manipulation | CoRL | 2026 | [Paper] [Project] |
| GLAM: Training a latent world model over global spatiotemporal memory for active exploration and navigation | arXiv | 2026 | [Paper] |
| Beyond Episodic Evaluation: Memory Architectural Bottlenecks in Sequential Embodied Question Answering | IROS | 2026 | [Paper] [Code] |
| RAVEN: Long-Horizon Reasoning & Navigation with a Visuo-Spatio-Temporal Memory | arXiv | 2026 | [Paper] [Project] [Code] |
| Mem-World: Memory-Augmented Action-Conditioned World Models for Persistent Robot Manipulation | CoRL | 2026 | [Paper] |
| Spatial Memory for Out-of-Vision Manipulation in Vision-Language-Action | ICML | 2026 | [Paper] |
| Remember to be Curious: Episodic Context and Persistent Worlds for 3D Exploration | arXiv | 2026 | [Paper] [Project] [Code] |
| 3D-Mem: 3D Scene Memory for Embodied Exploration and Reasoning | CVPR | 2025 | [Paper] [Project] [Code] |
| What Is The Best 3D Scene Representation for Robotics? | arXiv | 2025 | [Paper] |
| SnapMem: 3D Scene Memory for Embodied Exploration | OpenReview | 2024 | [Paper] |
| Embodied-RAG: General Non-parametric Embodied Memory for Retrieval and Generation | arXiv | 2024 | [Paper] |
| Searching in Space and Time: Unified Memory-Action Loops for Open-World Object Retrieval | arXiv | 2025 | [Paper] [Project] |
| ConceptFusion: Open-set Multimodal 3D Mapping | RSS | 2023 | [Paper] [Project] |
| Hierarchical Representations and Explicit Memory: Learning Effective Navigation Policies on 3D Scene Graphs | ICRA | 2022 | [Paper] |
Spatial Memory & SLAM
Simultaneous Localization and Mapping(SLAM) is the most fundamental explicit type of memory.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Unsupervised Online Learning for Robotic Interestingness with Visual Memory | IEEE T-RO | 2021 | [Paper] [Code] |
| Probabilistic Data Association for Semantic SLAM | ICRA | 2017 | [Paper] |
| SLAM-Based Spatial Memory for Behavior-Based Robots | IFAC | 2015 | [Paper] |
| RGB-D Mapping: Using Kinect-Style Depth Cameras for Dense 3D Modeling of Indoor Environments | IJRR | 2012 | [Paper] |
World Models & Memory
World models that incorporate memory for prediction and planning.
| Paper | Venue | Year | Links |
|---|---|---|---|
| GLAM: Training a latent world model over global spatiotemporal memory for active exploration and navigation | arXiv | 2026 | [Paper] |
| Memory as Plans: World-Action Modeling with Memory-Grounded Planning | arXiv | 2026 | [Paper] [Project] |
| DIM-WAM: World-Action Modeling with Diverse Historical Event Memory | arXiv | 2026 | [Paper] [Project] |
| World Action Models Enable Continual Imitation Learning with Recurrent Generative Replays | arXiv | 2026 | [Paper] [Project] [Code] |
| MemoryWAM: Efficient World Action Modeling with Persistent Memory | arXiv | 2026 | [Paper] [Project] |
| Mem-World: Memory-Augmented Action-Conditioned World Models for Persistent Robot Manipulation | CoRL | 2026 | [Paper] |
| MemoryVAM: Integrating Memory into Video Action Model for Robot Manipulation | arXiv | 2026 | [Paper] [Project] |
| HiMem-WAM: Hierarchical Memory-Gated World Action Models for Robotic Manipulation | arXiv | 2026 | [Paper] [Code] |
| MemoryVLA++: Temporal Modeling via Memory and Imagination in Vision-Language-Action Models | arXiv | 2026 | [Paper] [Project] |
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| MosaicMem: Persistent Geometry + Dynamic Content for Long-Horizon World Models | arXiv | 2026 | [Paper] [Project] |
| World Model for Robot Learning: A Comprehensive Survey | arXiv | 2026 | [Paper] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| Mastering Diverse Control Tasks through World Models | Nature | 2025 | [Paper] |
| Ctrl-World: A Controllable Generative World Model for Robot Manipulation | arXiv | 2025 | [Paper] |
| Genie 3: A New Frontier for World Models | Google DeepMind | 2025 | [Blog] |
| ManiGaussian: Dynamic Gaussian Splatting for Multi-task Robotic Manipulation | ECCV | 2024 | [Paper] [Project] |
| Mastering Memory Tasks with World Models (R2I) | ICLR | 2024 | [Paper] |
GLAM reports experiments on a controlled HM3D ObjectNav subset.
Lifelong Learning & Continual Learning
Experience Replay
| Paper | Venue | Year | Links |
|---|---|---|---|
| Memory Anchors for Continual Robot Learning | CoRL | 2026 | [Paper] [Project] |
| World Action Models Enable Continual Imitation Learning with Recurrent Generative Replays | arXiv | 2026 | [Paper] [Project] [Code] |
| Lifelong Robotic Reinforcement Learning by Retaining Experiences | CoLLAs | 2022 | [Paper] |
| Selective Experience Replay for Lifelong Learning | AAAI | 2018 | [Paper] |
Lifelong Learning Frameworks
| Paper | Venue | Year | Links |
|---|---|---|---|
| RoboArchitect: Automating the Design of Robotic Agents with Persistent Memory | arXiv | 2026 | [Paper] |
| EmbodiedRSI: Active Continual Robot Learning Through Hypothesis-Guided Co-Evolution | arXiv | 2026 | [Paper] |
| Inline Memory Meets Reusable Skills: Memory-centric Framework for Vision-Language-Action Model | arXiv | 2026 | [Paper] |
| Memory Anchors for Continual Robot Learning | CoRL | 2026 | [Paper] [Project] |
| World Action Models Enable Continual Imitation Learning with Recurrent Generative Replays | arXiv | 2026 | [Paper] [Project] [Code] |
| Preserving and Combining Knowledge in Robotic Lifelong Learning | Nature MI | 2025 | [Paper] |
| Towards General Purpose Robots at Scale: Memory and Lifelong Learning | arXiv | 2024 | [Paper] |
| A Lifelong Learning Approach to Mobile Robot Navigation | IEEE RAL | 2021 | [Paper] |
Skill Transfer & Memory
| Paper | Venue | Year | Links |
|---|---|---|---|
| Inline Memory Meets Reusable Skills: Memory-centric Framework for Vision-Language-Action Model | arXiv | 2026 | [Paper] |
| Skills in Weights, Memory in Code: Hybrid Learning for Memory-Dependent Robot Manipulation | arXiv | 2026 | [Paper] |
| Efficient Policy Learning by Extracting Transferable Robot Skills | CoRL | 2024 | [Paper] |
| Unsupervised Skill Transfer Learning for Autonomous Robots | RAS | 2021 | [Paper] |
| Skill Transfer Learning for Autonomous Robots and Human-Robot Cooperation: A Survey | RAS | 2020 | [Paper] |
| Learning an Embedding Space for Transferable Robot Skills | ICLR | 2018 | [Paper] |
Benchmarks & Evaluation
We treasure these features that actually pose challenges to memory:
- Partial observability: occlusions, hidden states, deferred rewards
- Long-horizon: requires recalling earlier observations/instructions
- Distribution shift: new scenes, objects, layouts
- Recovery: can the robots use memory to diagnose and retry?
| Benchmark / Evaluation | Year | Focus | Links |
|---|---|---|---|
| HuMeGo | 2026 | Goal-preceding object-event memory for humanoid loco-manipulation; six simulated and six real-world Unitree G1 tasks | [Paper] |
| HIDE | 2026 | 15 partially observable manipulation tasks testing skill-level recall, repetition, and execution progress | [Paper] [Project] |
| MemTransfer | 2026 | 100 warehouse navigation cases testing memory transfer under changed starts, routes, and history relevance | [Paper] |
| Counterfactual Memory Audit (CMA) | 2026 | Swaps histories under identical current inputs to test whether memory supports the correct physical decision | [Paper] |
| EvoNav-Bench | 2026 | Lifelong navigation with environmental changes that invalidate persistent scene memories | [Paper] |
| MEMOBench | 2026 | 30 history-dependent manipulation tasks with process-level diagnostics for memory storage, update, and compression | [Paper] [Code] |
| Sequential-EQA | 2026 | Memory accumulation and spatial alignment across sequential embodied questions, including real-robot evaluation | [Paper] [Code] |
| RoboMME-Interference | 2026 | Cross-session memory robustness under distracting robot experiences | [Paper] [Project] [Code] |
| ReMemBench | 2026 | 8 household manipulation tasks spanning spatial, prospective, object-associative, and object-set memory | [Paper] [Project] [Code] |
| LIBERO-RoboHarness | 2026 | VLA robustness and long-horizon task chaining with memory-based in-context adaptation | [Paper] [Code] |
| MemoryRTBench | 2026 | 6 RoboTwin-based manipulation tasks testing sequential, spatial, and episodic memory | [Paper] [Project] |
| RoboMemArena | 2026 | 26 long-horizon memory tasks with multimodal memory annotations and paired real-world tasks | [Paper] [Project] |
| MIKASA-Robo-VLA | 2026 | 90 memory tasks across 10 memory types for VLA evaluation on tabletop manipulation | [Paper] [Project] [Code] |
| RoboMME | 2026 | 16 manipulation tasks for temporal, spatial, object, and procedural memory in robotic generalist policies | [Paper] [Project] |
| RMBench | 2026 | 9 memory-dependent manipulation tasks over multiple memory-complexity levels | [Paper] [Project] [Code] |
| LIBERO-Mem | 2026 | Object-centric non-Markovian manipulation under object-level partial observability | [Paper] |
| MemMimic | 2026 | Non-Markovian imitation tasks with in-trial and cross-trial memory regimes | [Paper] [Project] |
| AbstainEQA | 2025 | Benchmarks abstention in embodied QA — when agents should say "I don't know" — across 5 categories with 1,636 ambiguous question variants; frontier models reach only 42.79% abstention recall vs. 91.17% for humans | [Paper] [Project] [Code] |
| EmbodiedMemory-Bench | 2026 | 2,554 interactive episodes testing visual recall, dynamic state tracking, interaction outcomes, and experience generalization | [Paper] [Code] [Project] |
CMA is an evaluation protocol rather than a standalone task dataset.
Read more: docs/evaluation.md
Datasets
See: docs/datasets.md
Citation
If you find this repository useful, please consider citing:
@misc{awesome-memory-for-robotics,
  author = {Jie Wang},
  title = {Awesome Memory for Robotics},
  year = {2025},
  publisher = {GitHub},
  howpublished = {\url{https://github.com/Everloom-129/Awesome-Memory-for-Robotics}}
}
Contributing
PRs welcome! Please read the contribution guidelines.
To add a new paper or resource:
- Fork this repository
- Add your entry in the appropriate section
- Submit a pull request
Please ensure your PR follows the existing format and includes:
- Paper title
- Venue and year
- Links to paper, code, and project page (if available)
Related Awesome Lists
License

This work is licensed under CC0 1.0 Universal.
⭐ Star this repository if you find it useful! ⭐