
Acmece/rl-collision-avoidance
Acmece/rl-collision-avoidance has 452 GitHub stars and 96 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-22 13:15 UTC. Last push 2021-01-21.
측정된 스타 증가
- in 24h
- 0
- in 7 days
- 기록 수집 중
- in 15 days
- 기록 수집 중
- in 1 month
- 기록 수집 중
서로 겹치는 기간의 순증가량이며 일별 합계가 아닙니다. 측정값이 없으면 비워 둡니다. 스타는 관심도를 나타내며 품질을 보장하지 않습니다.
소개
Implementation of the paper "Towards Optimally Decentralized Multi-Robot Collision Avoidance via Deep Reinforcement Learning"
학습README.md
Originalrl-collision-avoidance
This is a Pytorch implementation of the paper Towards Optimally Decentralized Multi-Robot Collision Avoidance via Deep Reinforcement Learning
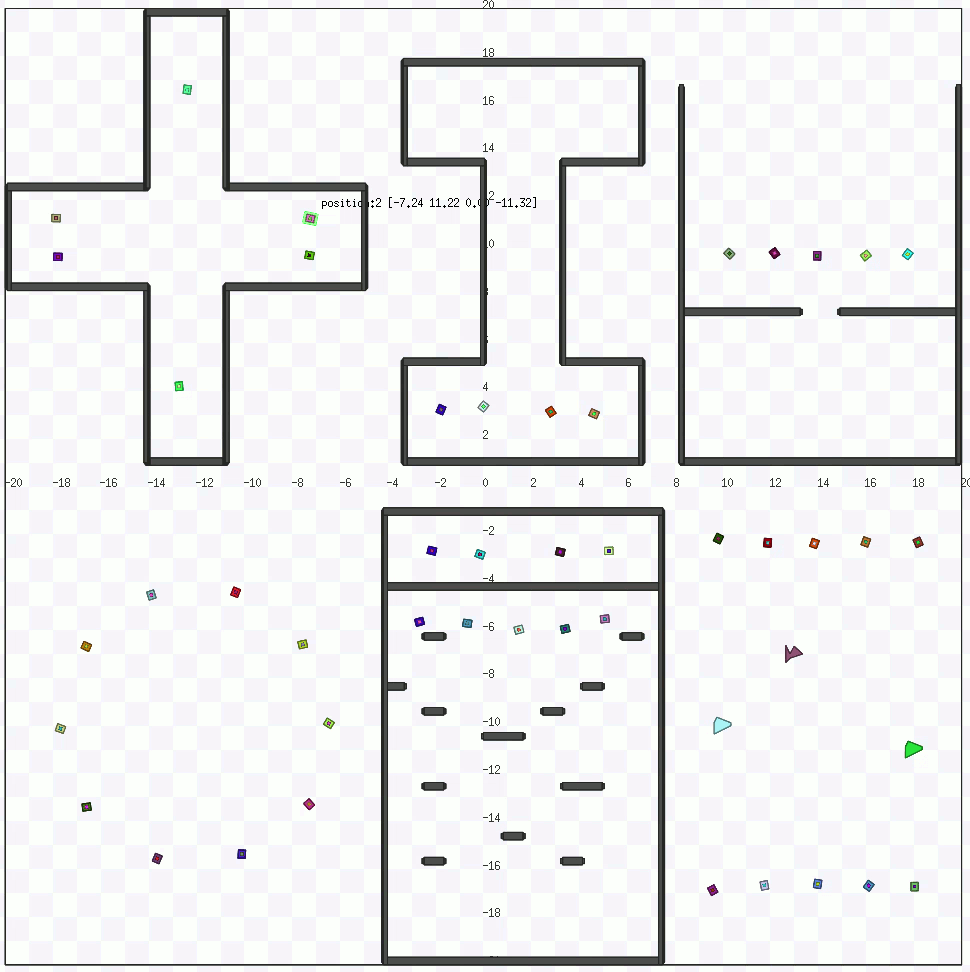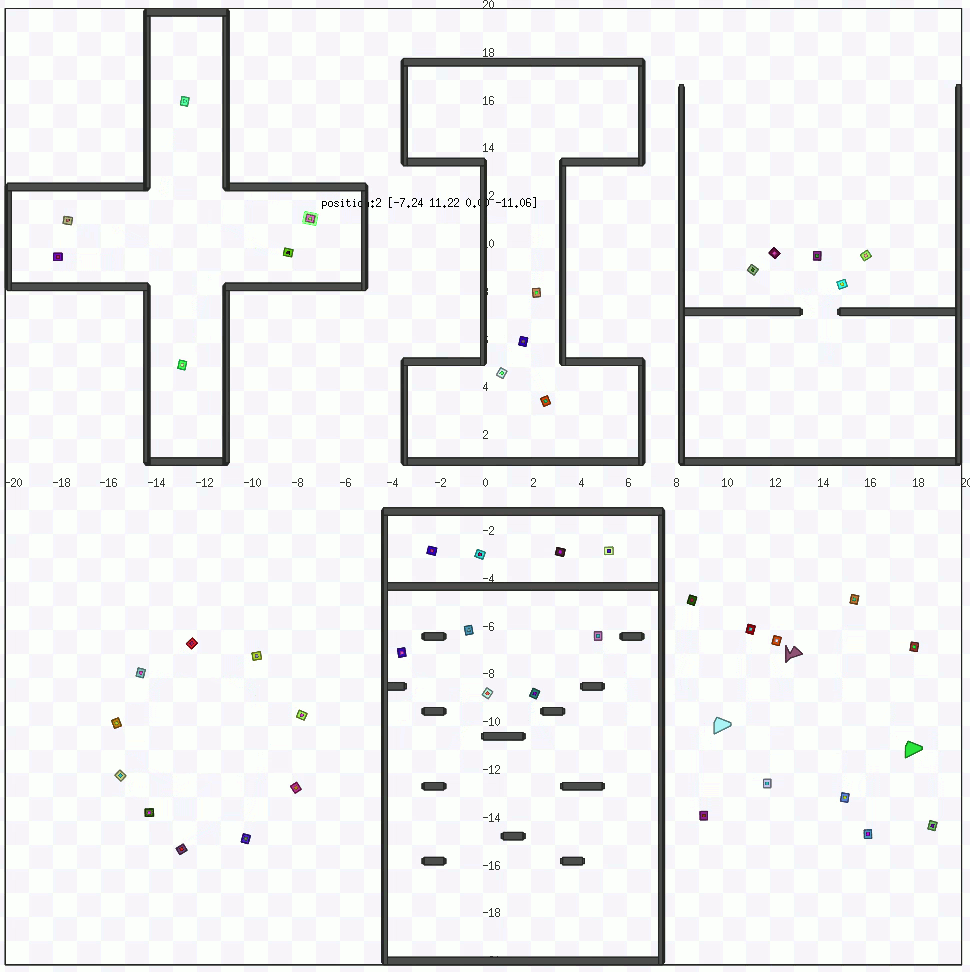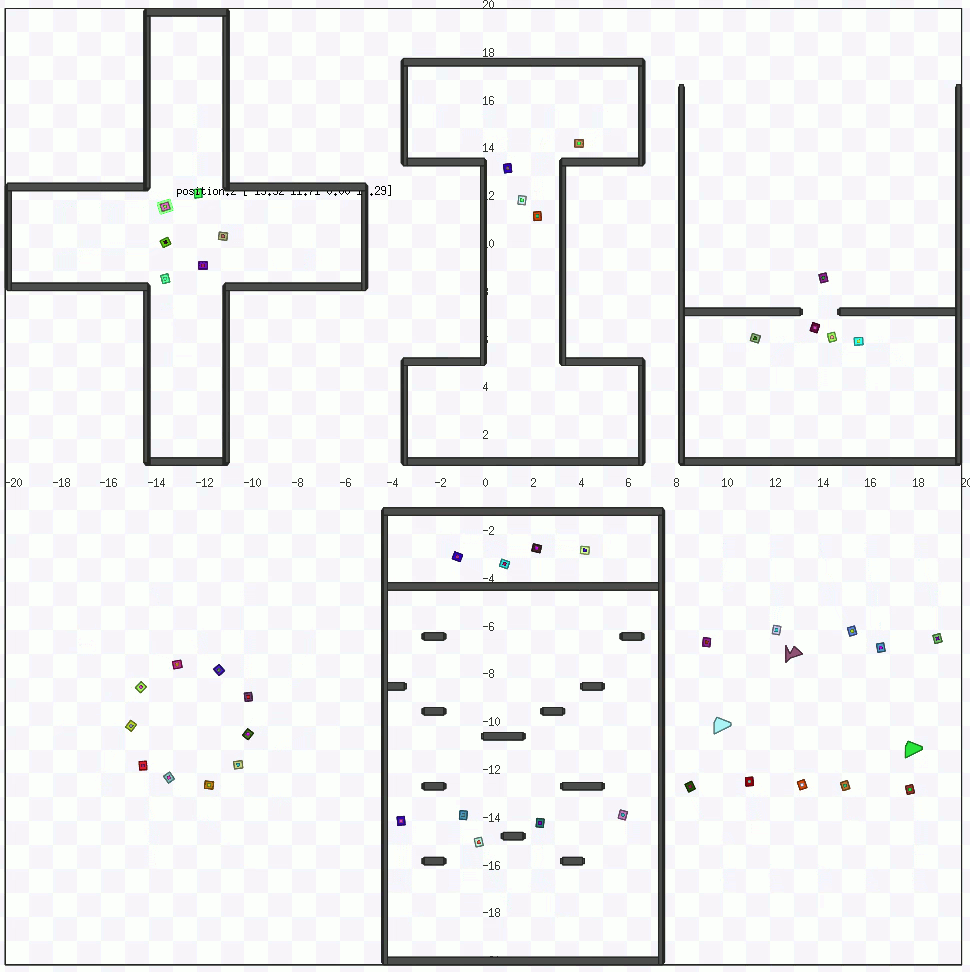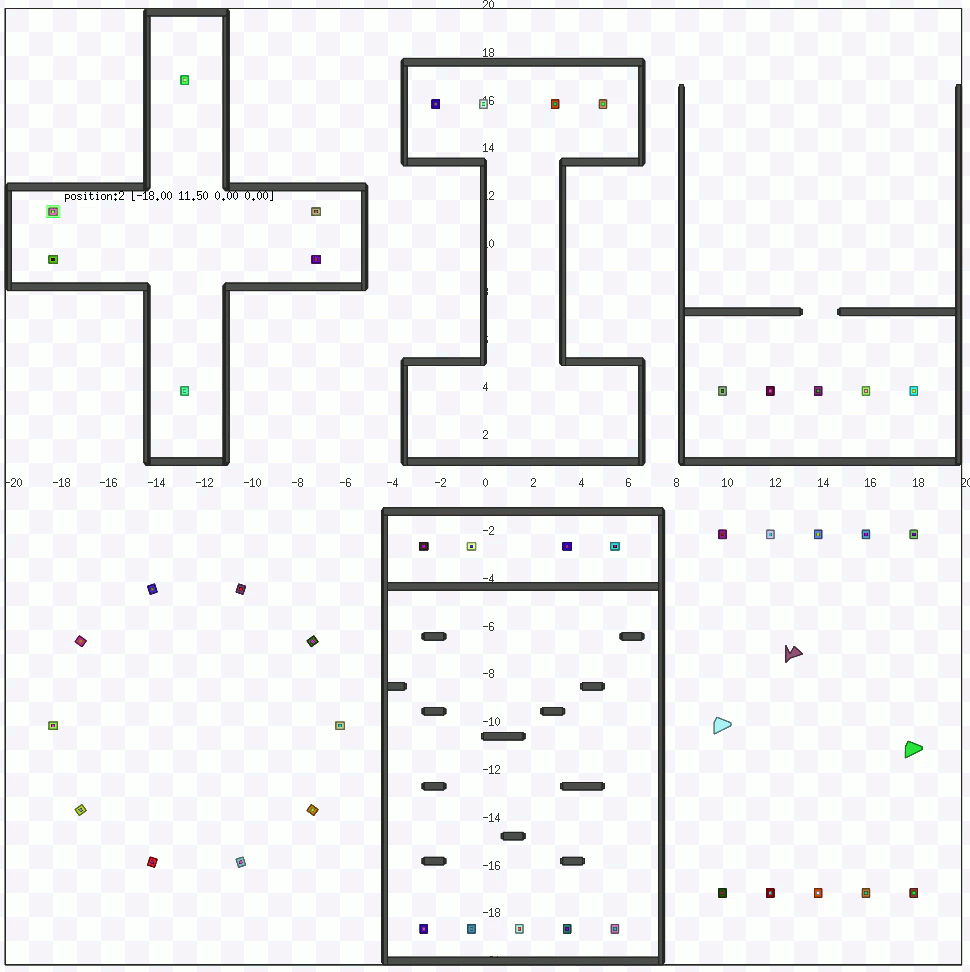 |
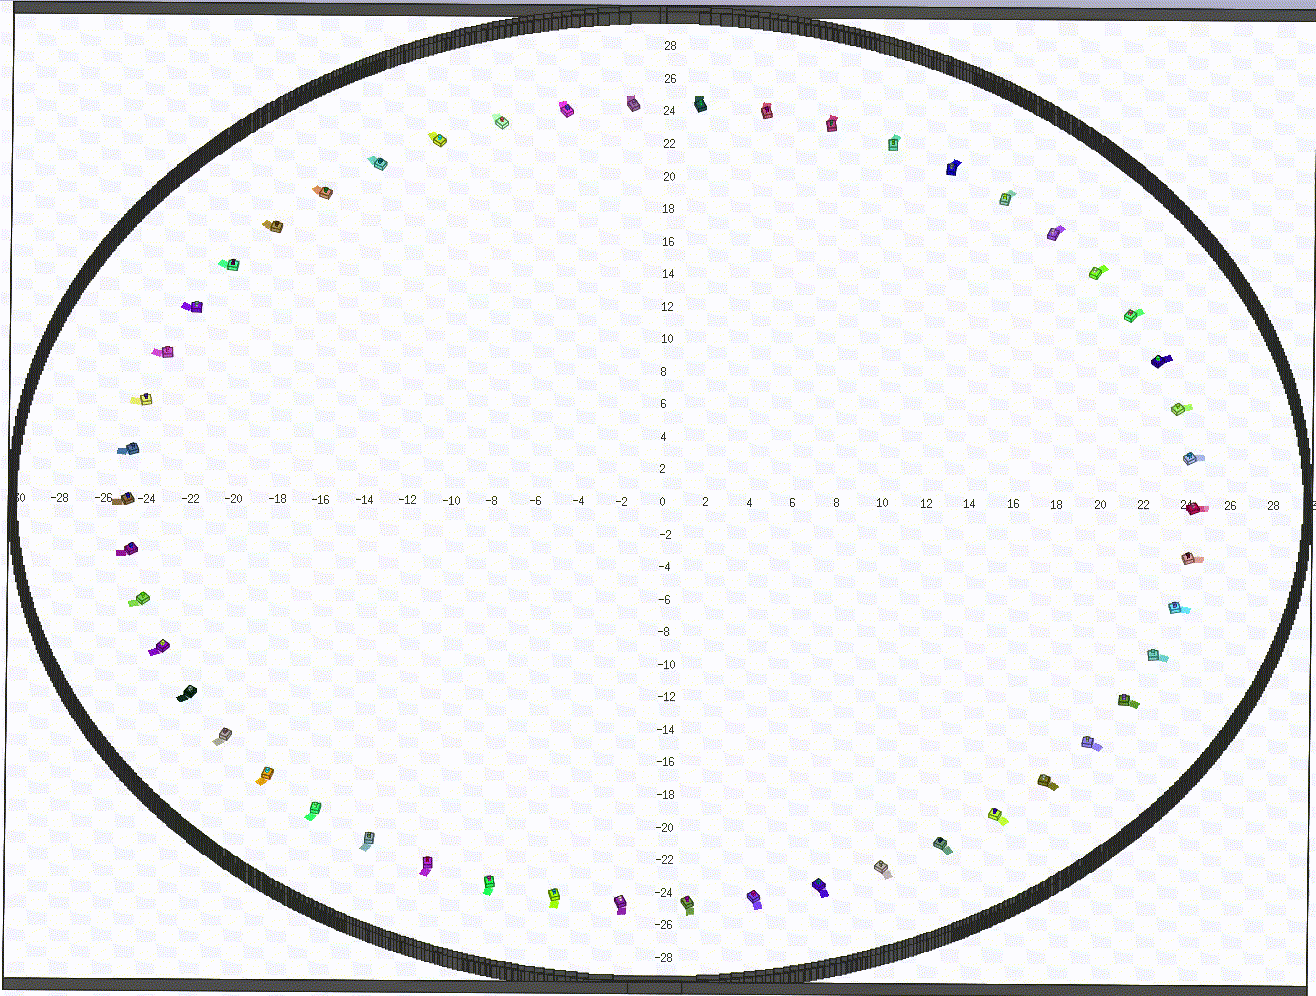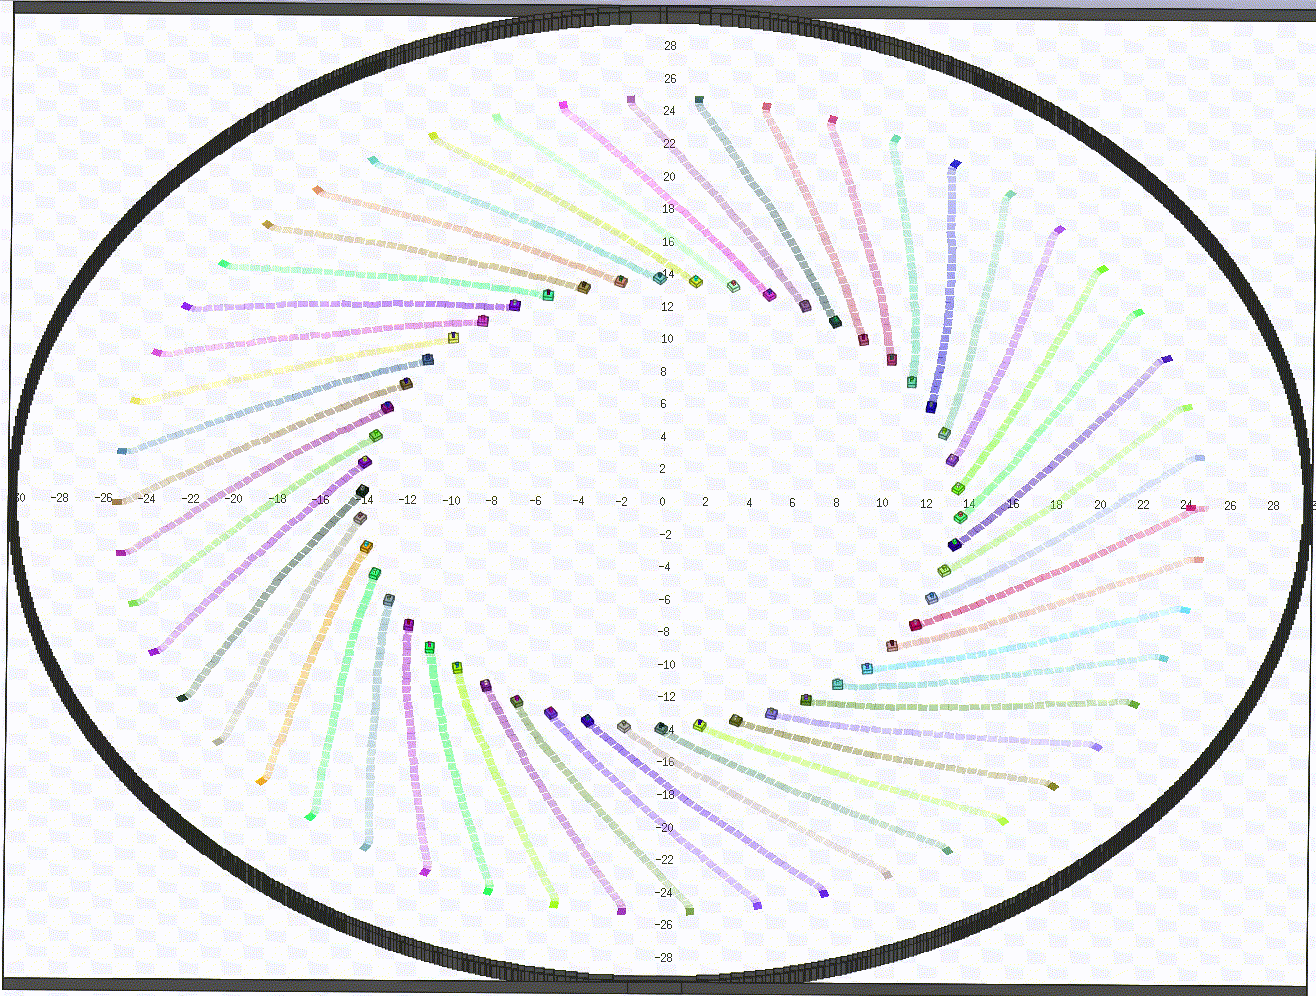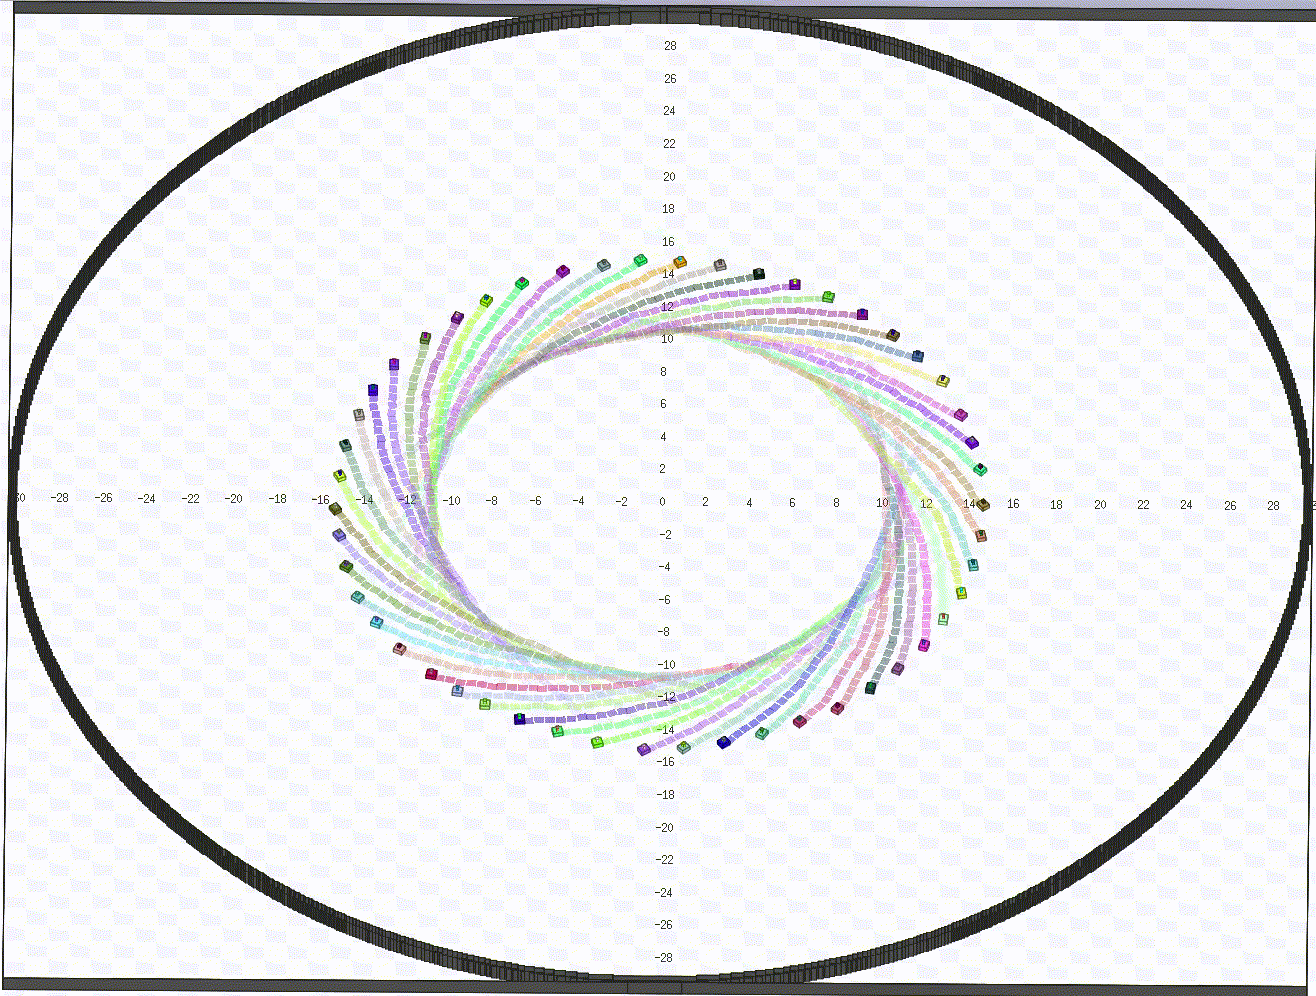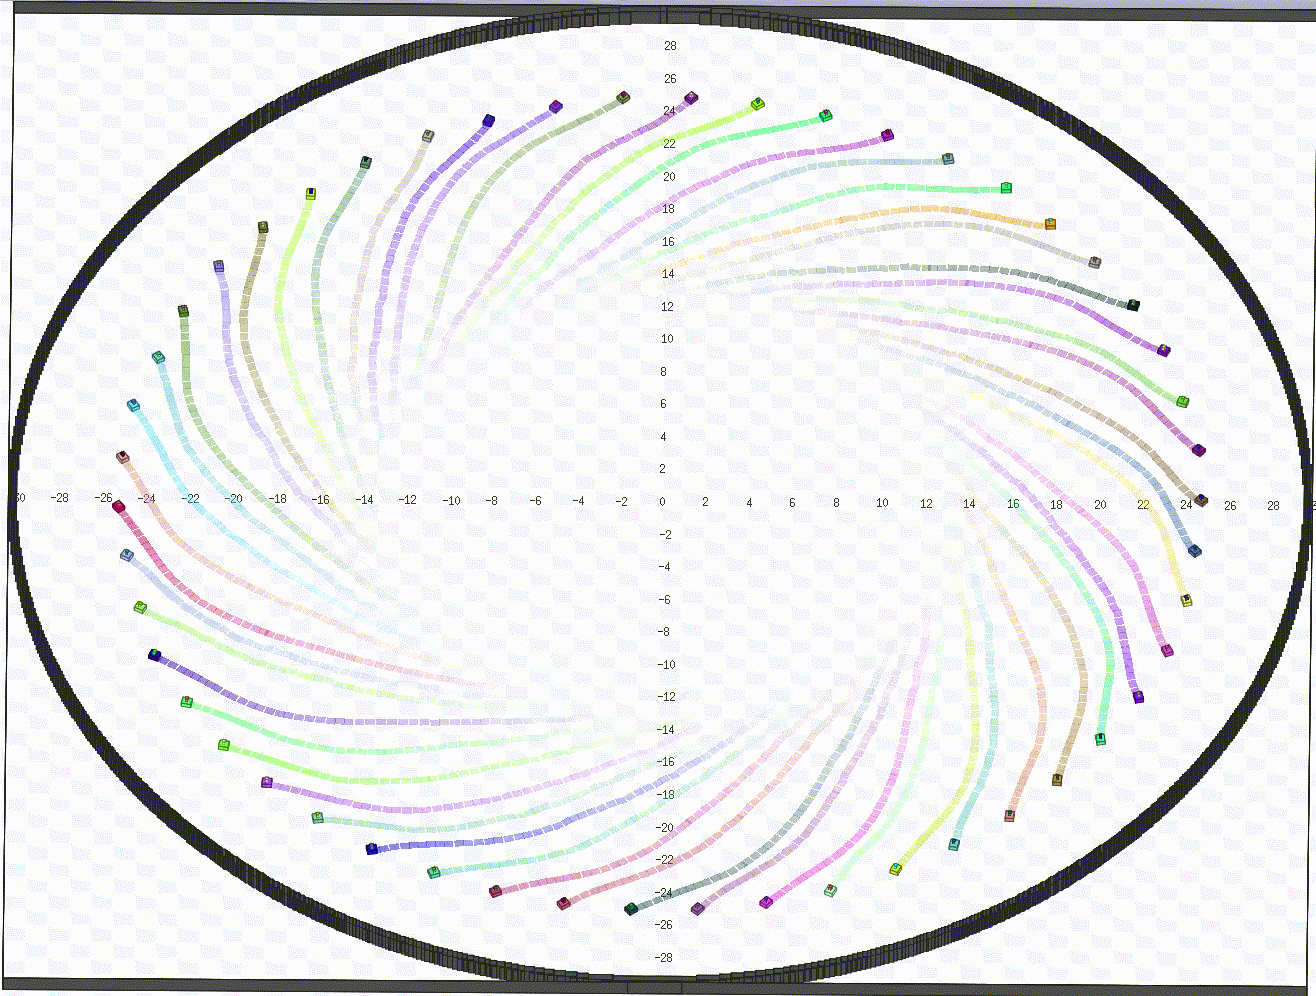 |
|---|
Requirement
- python2.7
- ROS Kinetic
- mpi4py
- Stage
- PyTorch
How to train
You may start with training in Stage1 and when it is well-trained you can transfer to Stage2 base on the policy model of Stage1, this is exactly what Curriculum Learning means. Training Stage2 from scratch may converge at a lower performance or not even converge. Please note that the motivation of training in Stage2 is to generalize the model, which hopefully can work well in real environment.
Please use the stage_ros-add_pose_and_crash package instead of the default package provided by ROS.
mkdir -p catkin_ws/src
cp stage_ros-add_pose_and_crash catkin_ws/src
cd catkin_ws
catkin_make
source devel/setup.bash
To train Stage1, modify the hyper-parameters in ppo_stage1.py as you like, and running the following command:
(leave out the -g if you want to see the GUI while training)
rosrun stage_ros_add_pose_and_crash stageros -g worlds/stage1.world
mpiexec -np 24 python ppo_stage1.py
To train Stage2, modify the hyper-parameters in ppo_stage2.py as you like, and running the following command:
rosrun stage_ros_add_pose_and_crash stageros -g worlds/stage2.world
mpiexec -np 44 python ppo_stage2.py
How to test
rosrun stage_ros_add_pose_and_crash stageros worlds/circle.world
mpiexec -np 50 python circle_test.py
Notice
I am not the author of the paper and not in their group either. You may contact Jia Pan ([email protected]) for the paper related issues. If you find it useful and use it in your project, please consider citing:
@misc{Tianyu2018,
	author = {Tianyu Liu},
	title = {Robot Collision Avoidance via Deep Reinforcement Learning},
	year = {2018},
	publisher = {GitHub},
	journal = {GitHub repository},
	howpublished = {\url{https://github.com/Acmece/rl-collision-avoidance.git}},
	commit = {7bc682403cb9a327377481be1f110debc16babbd}
}
관련 프로젝트 살펴보기
불러오는 중…