gpl
UKPLab
エディター、ターミナル、CLI、Gitツールで開発環境を改善できます。
UKPLab
ultimatepp

U++ is a C++ cross-platform rapid application development framework focused on programmer's productivity. It includes a set of libraries (GUI, SQL, Network etc.), and integrated development environment (TheIDE).
ultralytics
CocoaPods specification for the Ultralytics pod, distributing the Ultralytics.xcframework client for computer vision models hosted on the Ultralytics Platform.
ultralytics
Docker container, inference pipeline, and submission tooling for deploying trained YOLOv3 object detection models in the xView satellite imagery challenge.
umap-project
uMap lets you create maps with OpenStreetMap layers in a minute and embed them in your site.
umodoc
umputun
un33k
Returns unicode slugs
unable12
your repository as generative art — npx codebase-posters
unchainedshop
High-Performance Headless Node.js ESM E-Commerce Framework
und3fined
undergroundwires
☁️ Azure summary in bullet points
undertheseanlp
undont
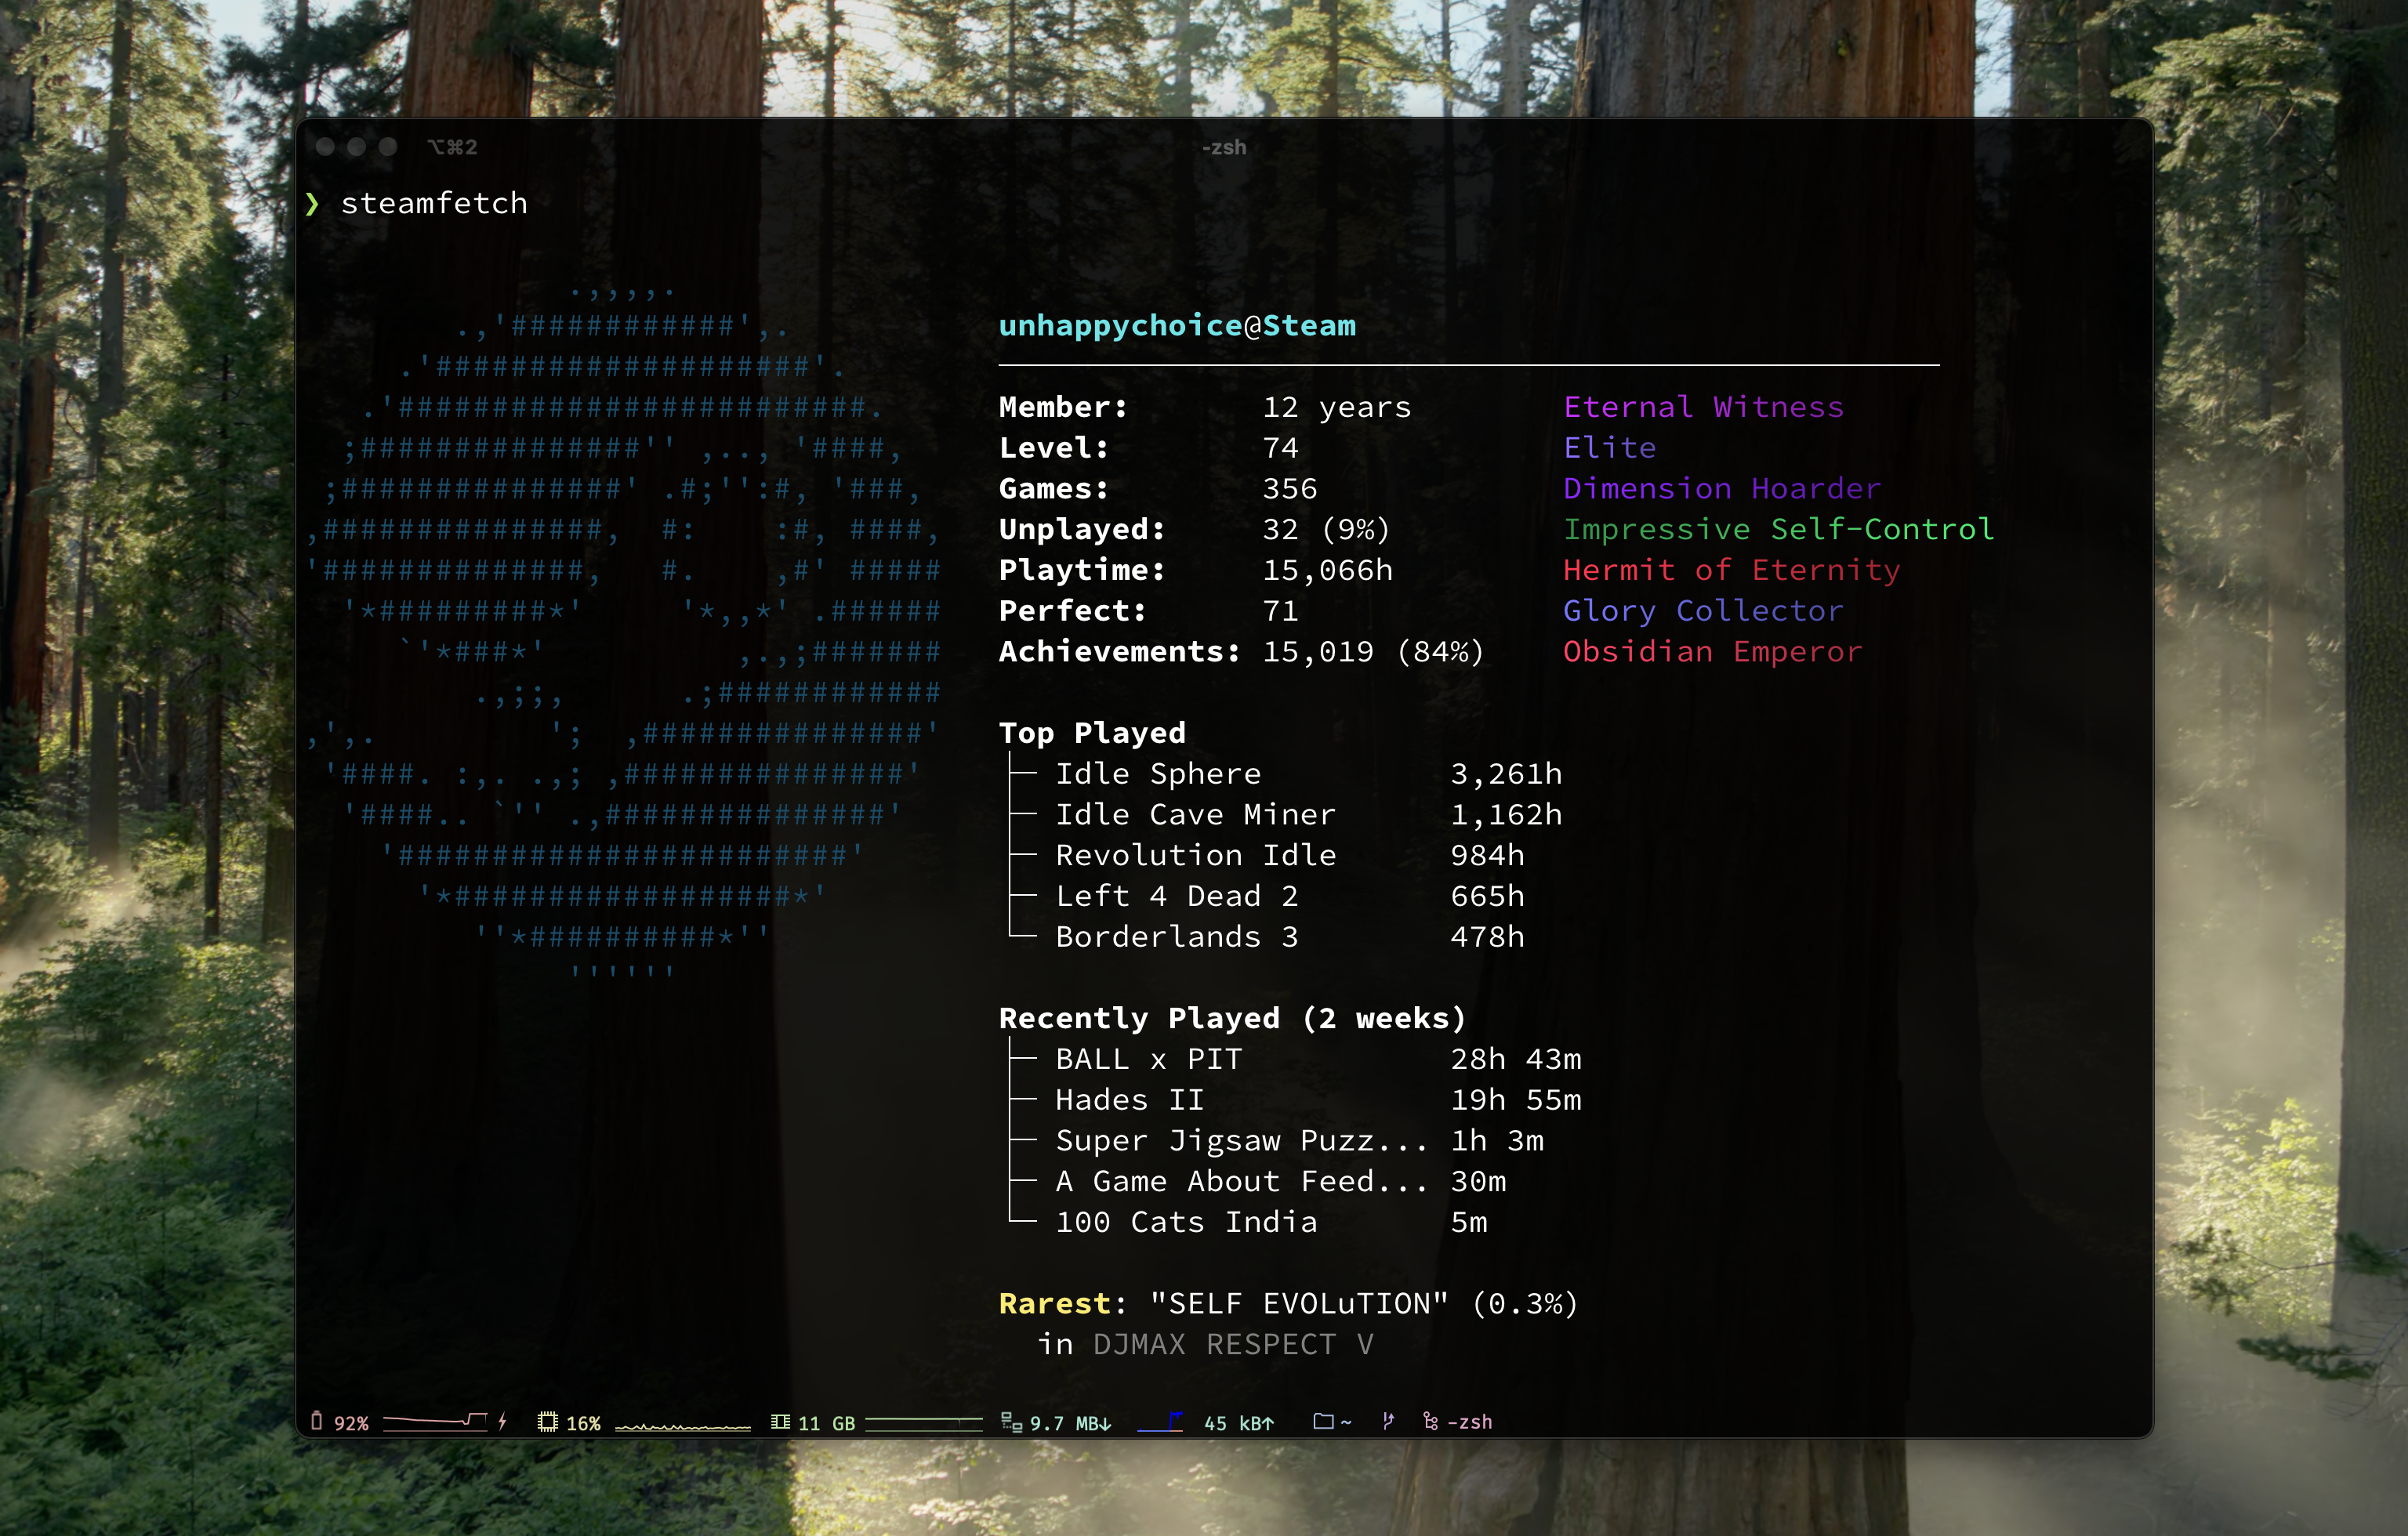
unhappychoice
unhappychoice
:desktop_computer: Show high resolution images on your terminal !
unikraft
unitreerobotics
Here are the ROS simulation packages for Unitree robots, You can load robots and joint controllers in Gazebo, so you can perform low-level control (control the torque, position and angular velocity) of the robot joints. Please be aware that the Gazebo simulation cannot do high-level control, namely walking. Aside from these simulation functions, you can also control your real robots in ROS with the unitree_ros_to_real packages. For real robots, you can do high-level and low-level control using our ROS packages.
Unity-Technologies
Unity-Technologies
Unity-Technologies
universal-tool-calling-protocol
unkeyed
unkn0wn-root

Terminal API client for HTTP, GraphQL, gRPC, WebSocket and SSE. Plain .http files you can diff and version, with scripted tests, workflows, mocks, recorder, and a CLI runner for CI.