
KumarRobotics/CoverageControl
KumarRobotics/CoverageControl has 28 GitHub stars and 6 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-15 16:18 UTC. Last push 2026-09-14.
計測したスター増加
- 24時間
- 0
- 7日間
- 履歴を収集中
- 15日間
- 履歴を収集中
- 1か月
- 履歴を収集中
期間ごとの純増数です。期間は重複しており、日別の値ではありません。未計測の値は空欄です。スター数は注目度の指標であり、品質の保証ではありません。
概要
Environment for coverage control and learning using GNN
機械学習README.md
オリジナルSee full documentation at https://KumarRobotics.github.io/CoverageControl/
Introduction
Coverage control is the problem of navigating a robot swarm to collaboratively monitor features or a phenomenon of interest not known a priori.
The library provides a simulation environment, algorithms, and GNN-based architectures for the coverage control problem.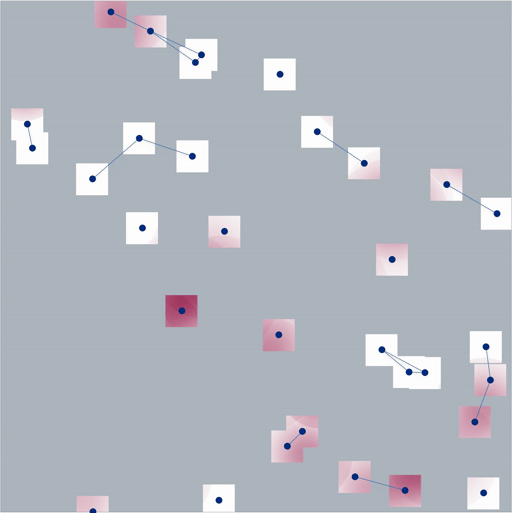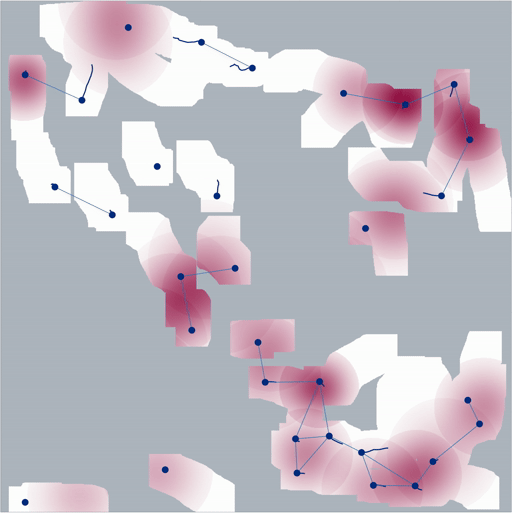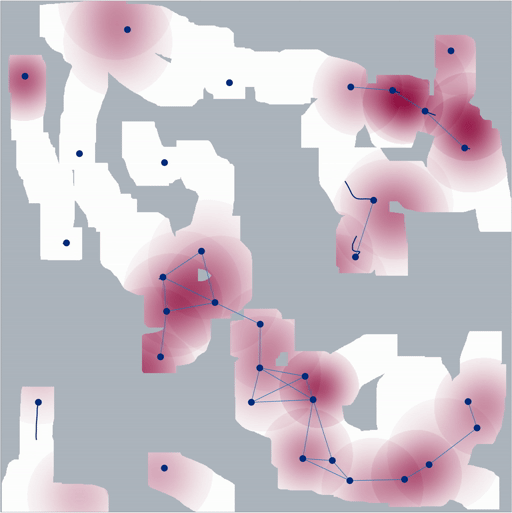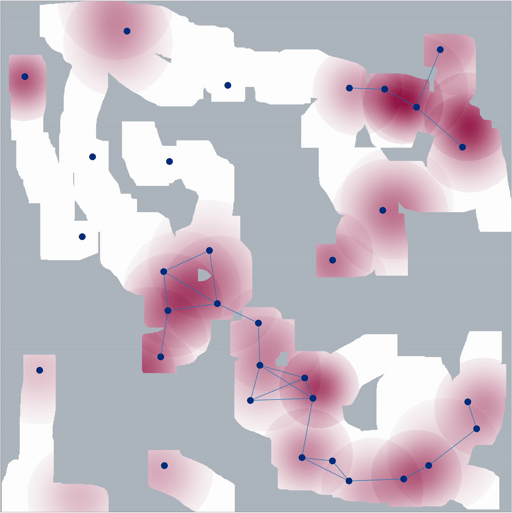
Key features:
- The core library is written in
C++andCUDAto handle large-scale simulations - There are
pythonbindings that interface with the core library - Several Centroidal Voronoi Tessellation (CVT)-based algorithms (aka Lloyd's algorithms)
- Learnable Perception-Action-Communication (LPAC) architecture for the coverage control problem is implemented in
PyTorchandPyTorch Geometric
Getting Started
The library is available as a pip package. To install the package, run the following command:
pip install coverage_control
See Installation for more details on installation.
See Quick Start guide for a quick introduction to the library.
Citation
@article{agarwal2024lpac,
      title         =   {LPAC: Learnable Perception-Action-Communication Loops with
                            Applications to Coverage Control},
      author        =   {Saurav Agarwal and Ramya Muthukrishnan and
                            Walker Gosrich and Vijay Kumar and Alejandro Ribeiro},
      year          =   {2024},
      eprint        =   {2401.04855},
      archivePrefix =   {arXiv},
      primaryClass  =   {cs.RO}
}
LPAC: Learnable Perception-Action-Communication Loops with Applications to Coverage Control.
Saurav Agarwal, Ramya Muthukrishnan, Walker Gosrich, Vijay Kumar, and Alejandro Ribeiro.
arXiv preprint arXiv:2401.04855 (2024).
Acknowledgements
- PyTorch
- PyTorch Geometric
- Eigen
- pybind11
- CGAL
- JSON for Modern C++
- CUDA Samples
- gnuplot-iostream
- hungarian-algorithm-cpp
- toml++
Support and Funding
The work was performed at the GRASP Laboratory and the Alelab, University of Pennsylvania, USA.
This work was supported in part by grants ARL DCIST CRA W911NF-17-2-0181 and ONR N00014-20-1-2822.
Contributors
- Saurav Agarwal
- Ramya Muthukrishnan
License
The library is licensed under the GPL-3.0 License. The documentation is not under the GPL-3.0 License and is licensed under the CC BY-NC-SA 4.0 License.