
visionpilot-project/VisionPilot
visionpilot-project/VisionPilot has 43 GitHub stars and 8 forks. Star changes are not measured yet. Last checked 2026-11-13 16:07 UTC. Last push 2026-10-27.
Progression mesurée des étoiles
- in 24h
- Historique en cours
- in 7 days
- Historique en cours
- in 15 days
- Historique en cours
- in 1 month
- Historique en cours
Variations nettes sur des périodes qui se chevauchent, pas des totaux quotidiens. Les mesures absentes restent vides. Les étoiles indiquent l’intérêt, pas la qualité.
À propos
Open-source modular autonomous driving simulation platform with computer vision, deep learning, and sensor fusion. Features lane detection, object recognition, various safety features, and adaptive control in BeamNG.tech, with real-time visualization via Foxglove.
Apprentissage automatiqueREADME.md
Original
VisionPilot: Autonomous Driving Simulation, Computer Vision & Real-Time Perception (BeamNG.tech)
Overview
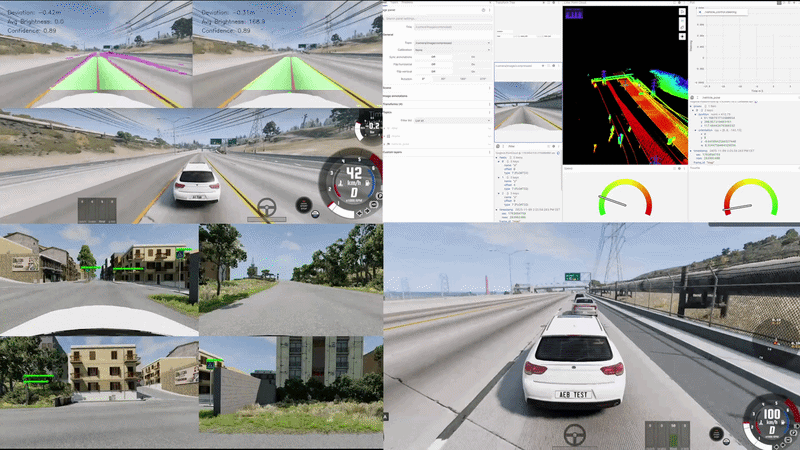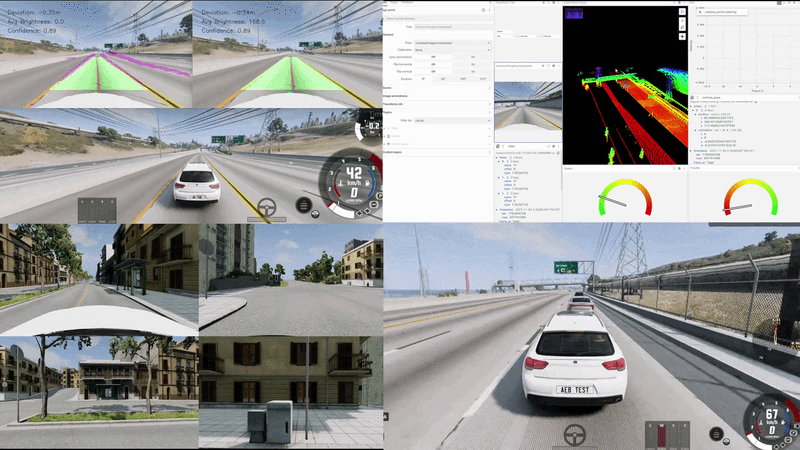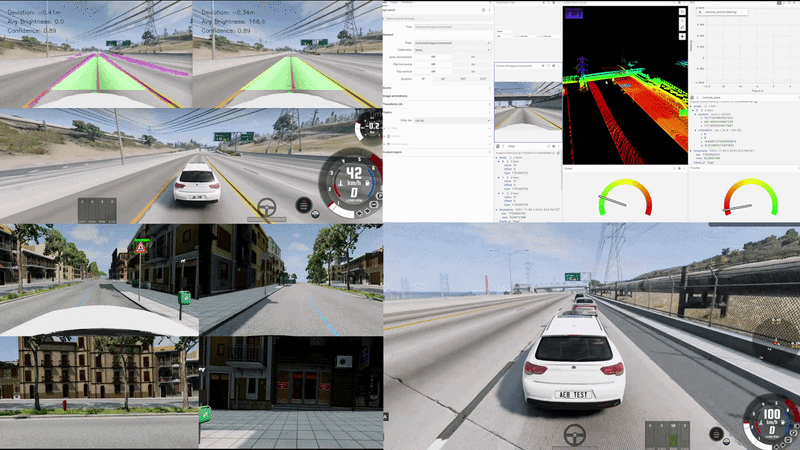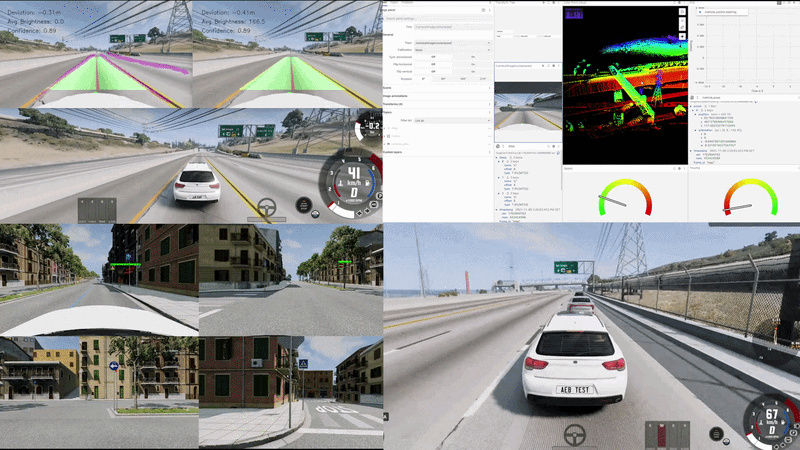
A modular Python project for autonomous driving research and prototyping, fully integrated with the BeamNG.tech simulator and Foxglove visualization. This system combines traditional computer vision algorithms and deep learning (CNN, UFLD) with real-time sensor fusion and autonomous vehicle control to tackle:
- Multi-Lane Detection: UFLD, Traditional CV
- Traffic Sign: Classification & Detection
- Traffic Lights: Classification & Detection
- Multi-Class Object Detection: Vehicles, pedestrians, cyclists and more
- Multi-Sensor Fusion: Camera, Lidar, Radar, GPS, IMU
- Real-Time Control: PID steering, cruise control (CC), automatic emergency braking (AEB)
- Visualization: Real-time monitoring with Foxglove WebSocket + multiple CV windows
- Configuration System: YAML-based modular settings
Looking Ahead: While VisionPilot currently runs on BeamNG.tech, integration with the CARLA Simulator is planned on our roadmap. If you are interested in helping build the CARLA bridge, PRs are welcome and much appreciated!
Table of Contents
- VisionPilot: Autonomous Driving Simulation, Computer Vision & Real-Time Perception (BeamNG.tech)
Usage
1. Download BeamNG.tech
First, download and install BeamNG.tech from the official website. This is required to run the simulation environment.
2. Configure BeamNG Path
Navigate to the config directory and update the path to your BeamNG.tech installation in the configuration files.
Configuration Files Overview:
| File | Purpose |
|---|---|
| beamng.yaml | Main configuration file containing the path to your BeamNG.tech installation. Required for basic setup |
| config.py | Python configuration module that loads and manages all YAML settings |
| control.yaml | Steering, throttle, and braking control parameters (PID tuning) |
| perception.yaml | Computer vision pipeline settings (lane detection, object detection thresholds) |
| scenarios.yaml | Simulation scenario definitions and test environments |
| sensors.yaml | Sensor configuration (camera, LiDAR, radar parameters) |
Update beamng.yaml with your BeamNG.tech installation path. For basic usage, this is the only essential configuration file you need to modify. Advanced users can also customize sensors.yaml to adjust sensor parameters.
3. Download Pretrained Models
Download the pretrained models for object detection, traffic light detection, traffic sign detection, and classification from the VisionPilot v0.1.0-alpha Release. Extract the downloaded model package into the models root folder with the following structure:
Note: Pretrained models are provided with the v0.1.0-alpha release. Download the
visionpilot-v0.1.0-models.zippackage from the release assets and extract its contents into themodelsfolder.
models/
├── object_detection/
│   └── object_detection.pt
├── traffic_light/
│   └── traffic_light_detection.pt
├── traffic_sign/
│   ├── traffic_sign_detection.pt
│   └── traffic_sign_classification.h5
└── ufld/
    └── ufld_culane_res18.pth
4. Specify Model Paths
Verify that the model loading section in your main script matches your model directory structure:
print("[Main] Loading local models...")
local_models = {}
local_models['vehicle'] = YOLO('models/object_detection/object_detection.pt')
local_models['traffic_light'] = YOLO('models/traffic_light/traffic_light_detection.pt')
local_models['sign_detect'] = YOLO('models/traffic_sign/traffic_sign_detection.pt')
local_models['sign_classify'] = load_model('models/traffic_sign/traffic_sign_classification.h5')
Update these paths if your model structure differs from the default.
UFLD Lane Detection Model
VisionPilot includes the required UFLDv2 code and configuration files. No separate UFLDv2 repository is required.
In src/perception/lane_detection/main.py, verify:
model_path = MODELS_DIR / "ufld" / "ufld_culane_res18.pth"
Ensure the ufld_culane_res18.pth model weights are available before running the simulation.
5. Start the Simulation
Navigate to the scripts directory and run the startup script:
Linux/macOS:
cd scripts
./start_simulation.sh
Windows Powershell:
cd scripts
start_simulation.bat
The simulation will initialize BeamNG.tech, load the perception models, and begin streaming sensor data and AI predictions in real-time.
Demos
Multi-Lane Detection Stress Testing
Evaluation of the multi-lane perception pipeline across various environmental edge cases, including high-glare transitions, low-light tunnels, and heavy atmospheric fog:
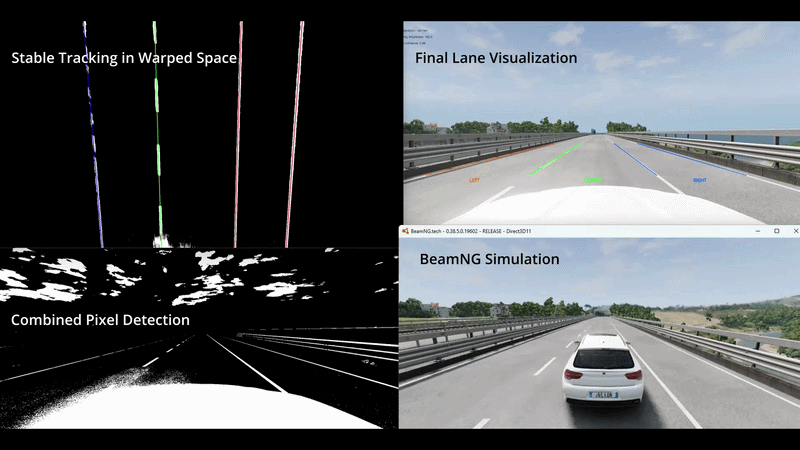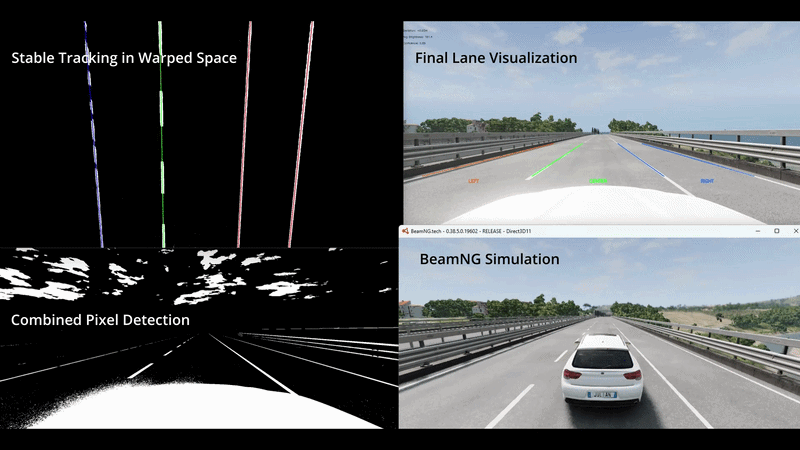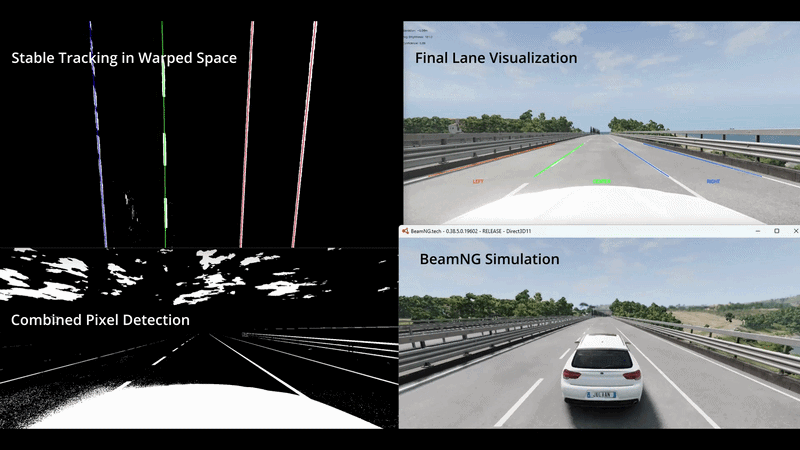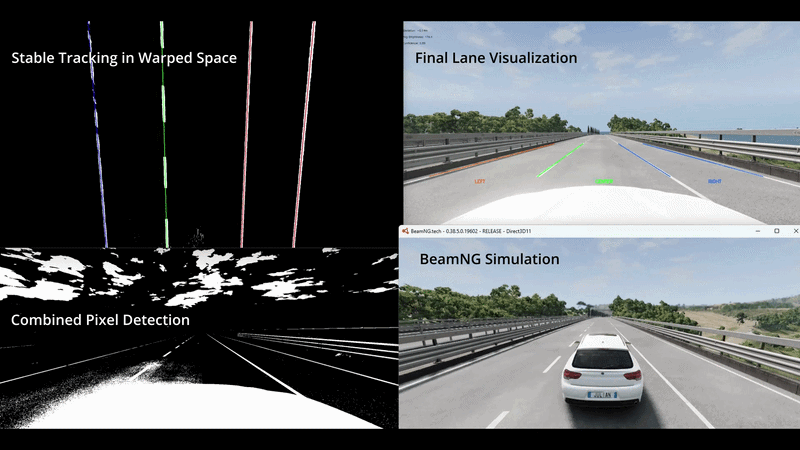
Extended Demo: Watch the full video here
Emergency Braking (AEB)
Watch the Emergency Braking System (AEB) in action with real-time radar filtering and collision avoidance:
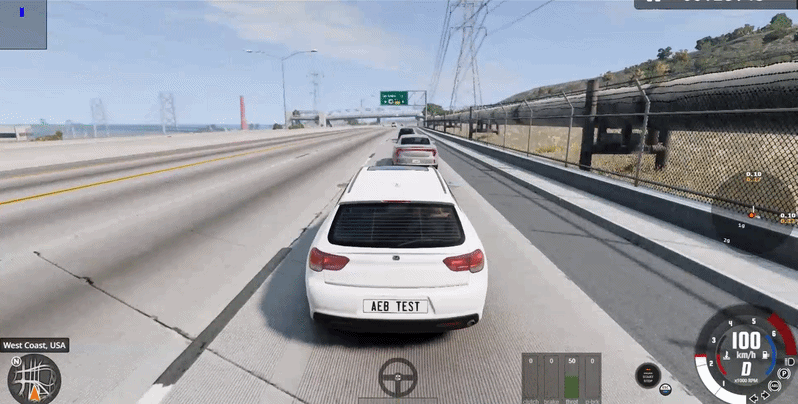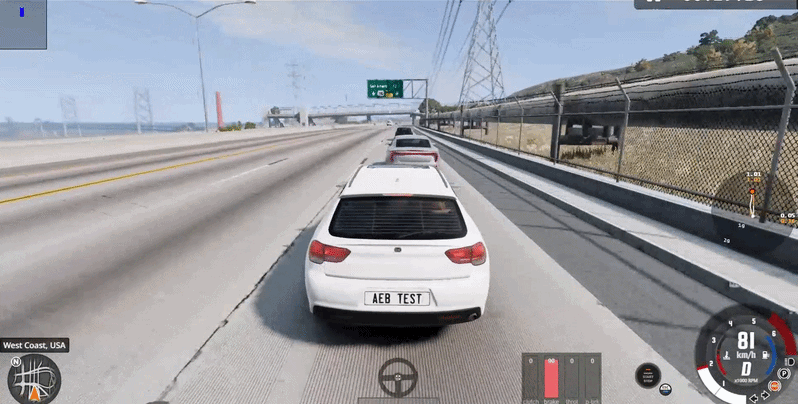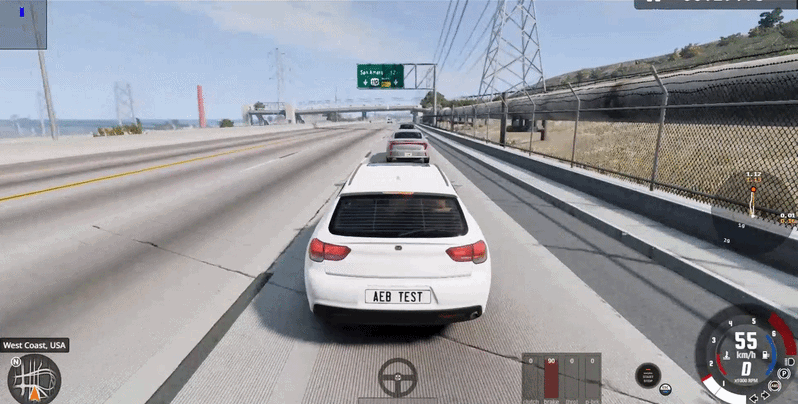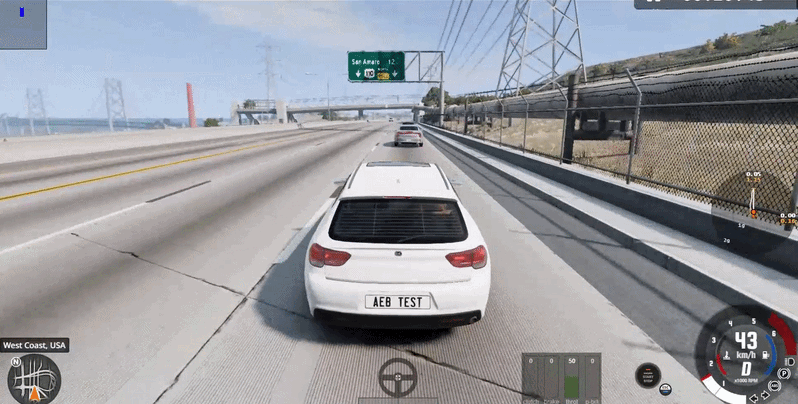
Extended Demo: Watch the full video here
Sign Detection & Classification
This demo shows real-time traffic sign detection and classification:
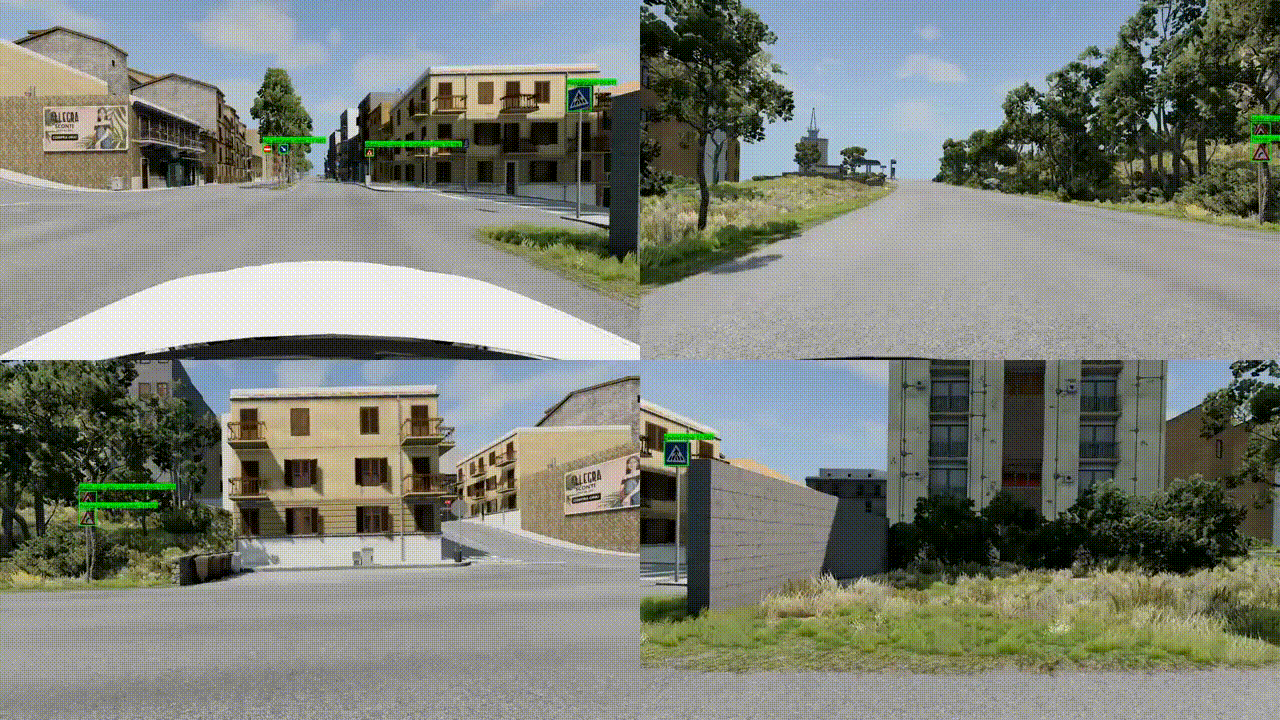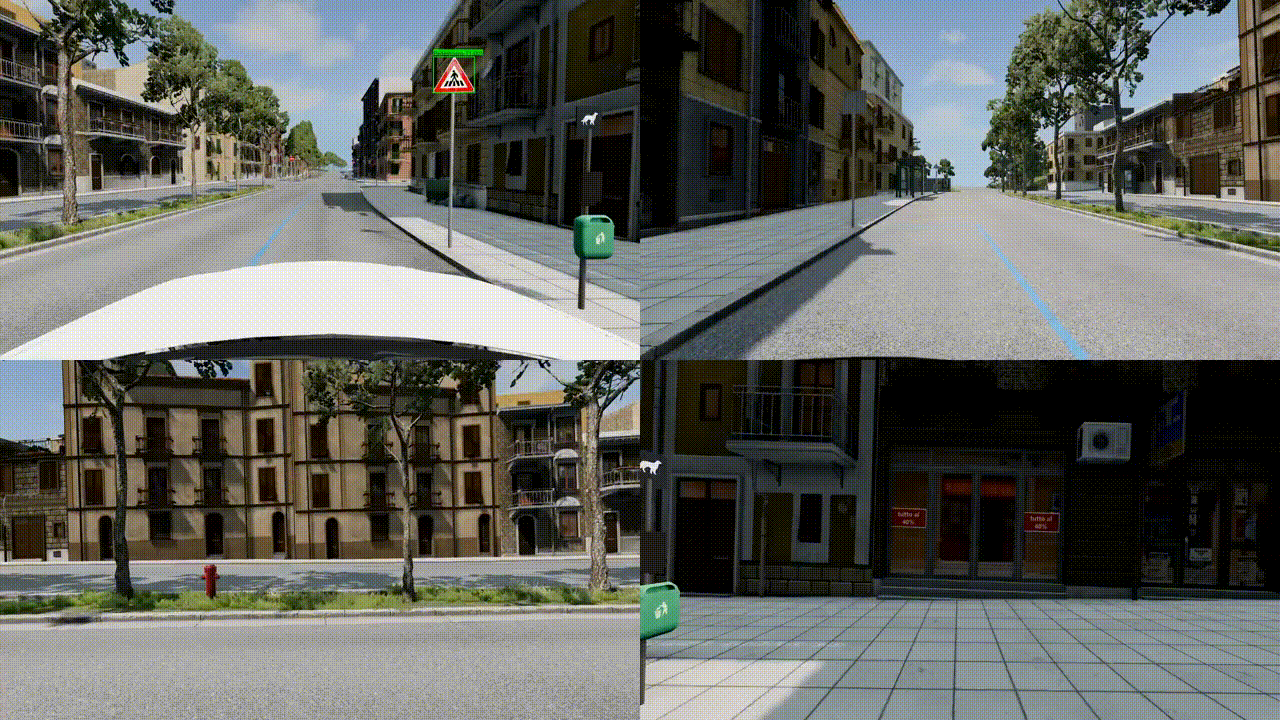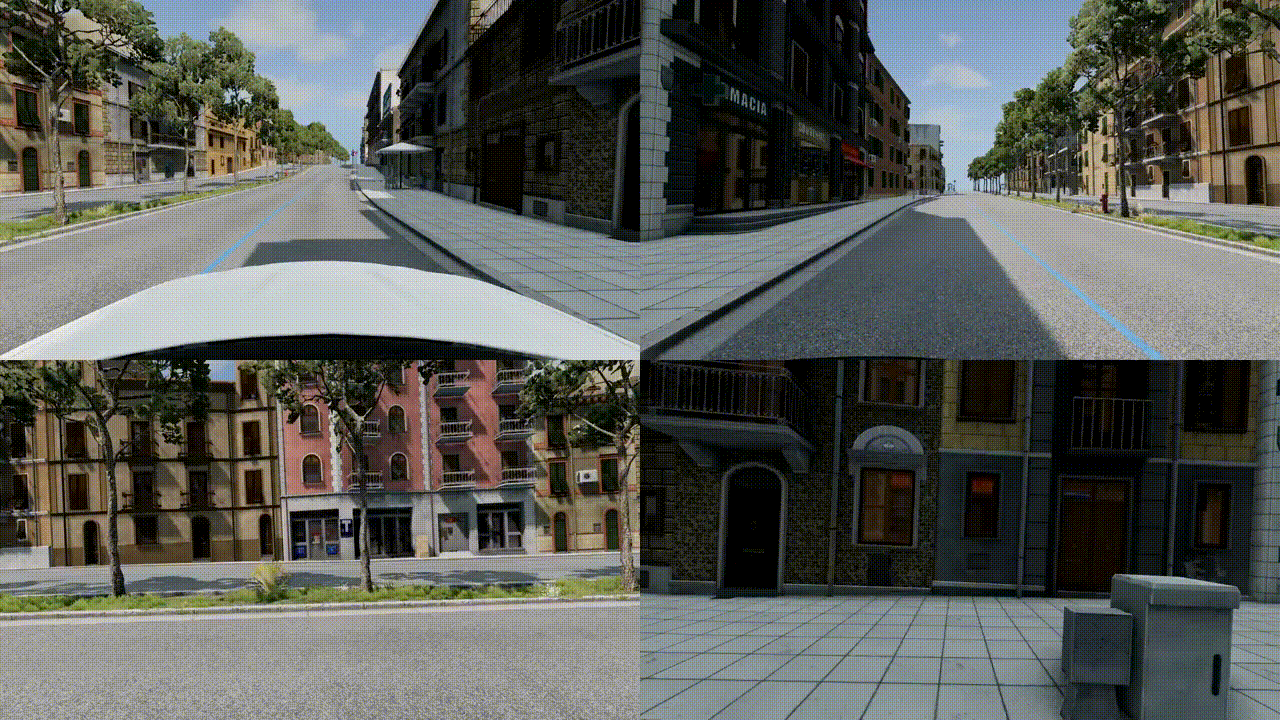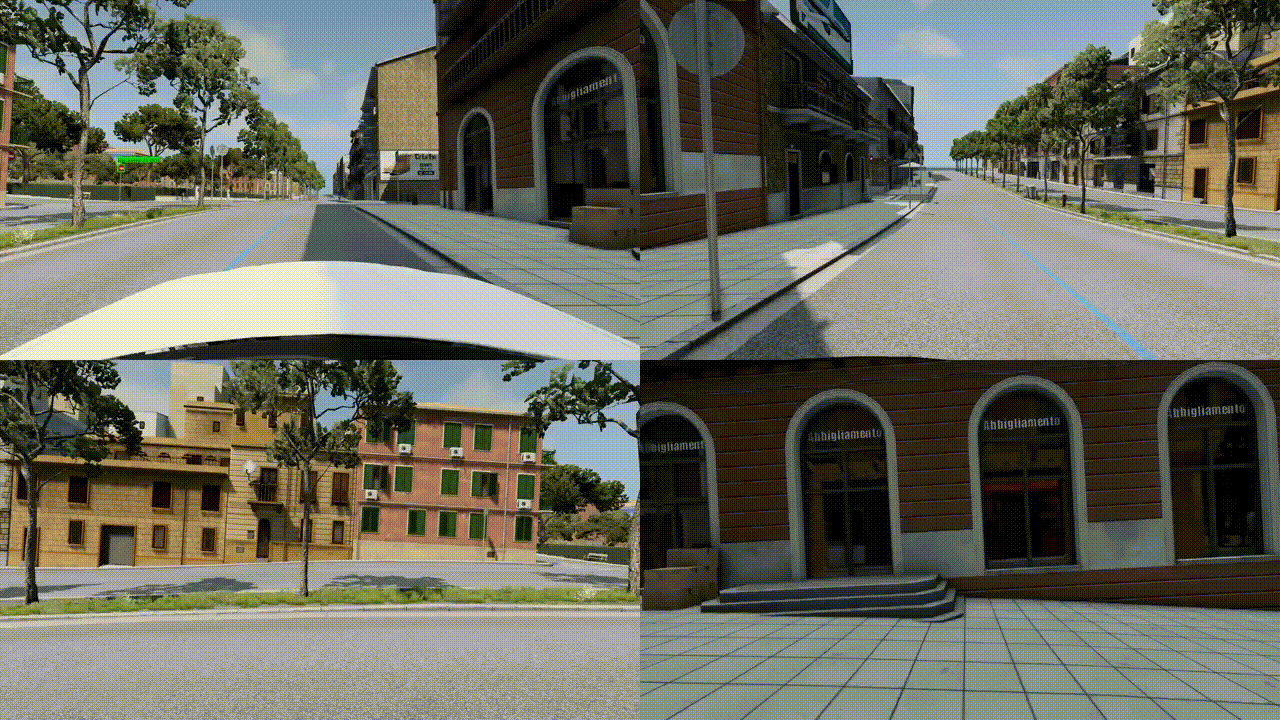
Extended Demo: Watch the full video here
VisionPilot does not yet support multi-camera. This is for demonstration purposes only.
Traffic Light Detection & Classification
This demo shows real-time traffic light detection and classification:
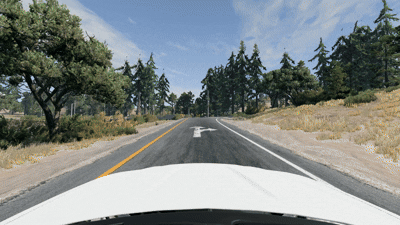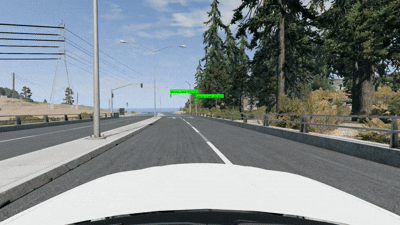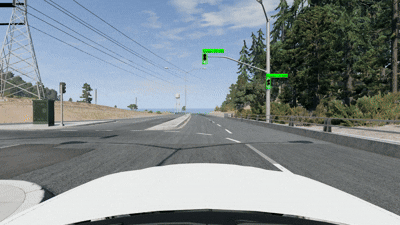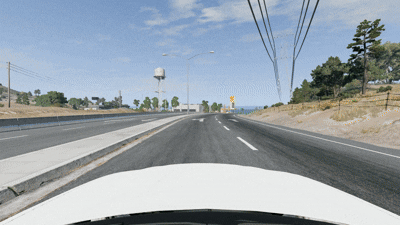
No extended Demo avaliable yet.
Lane Detection & Keeping (v2)
Watch the improved autonomous lane keeping demo (v2) in BeamNG.tech, featuring smoother fused CV+SCNN lane detection, stable PID steering, and robust cruise control:
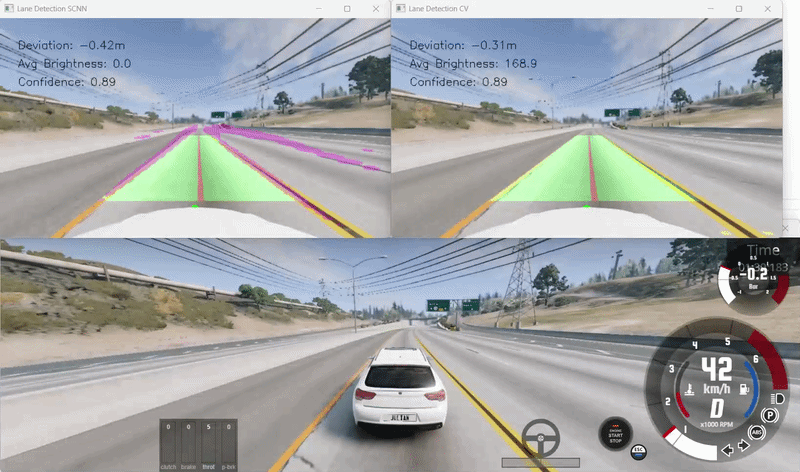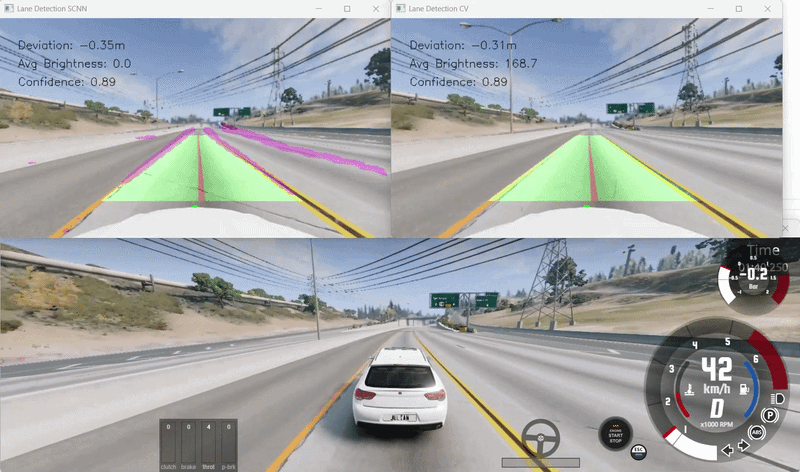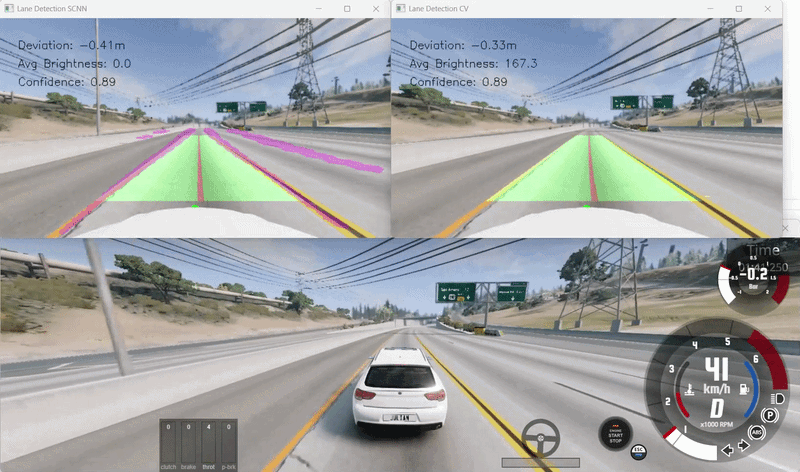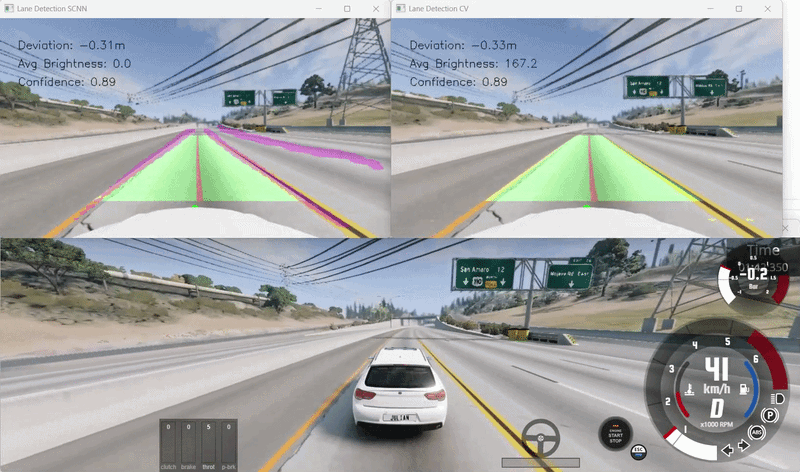
Extended Demo: Watch the full video here
Note: Very low-light (tunnel) scenarios are not yet supported.
Previous Lane Detection & Keeping (v1)
The original demo is still available for reference:
Lane Keeping & Multi-Model Detection Demo (v1)
Ultra-Fast Lane Detection (UFLD)
Watch the UFLD perform real-time lane detection with temporal spline smoothing on highway video.
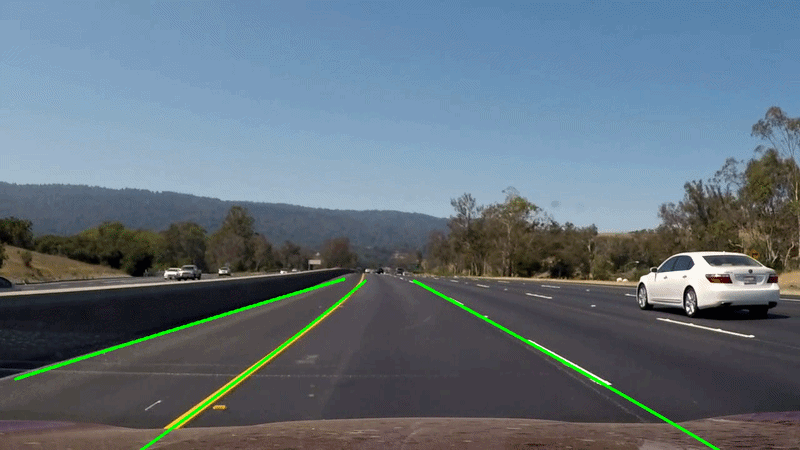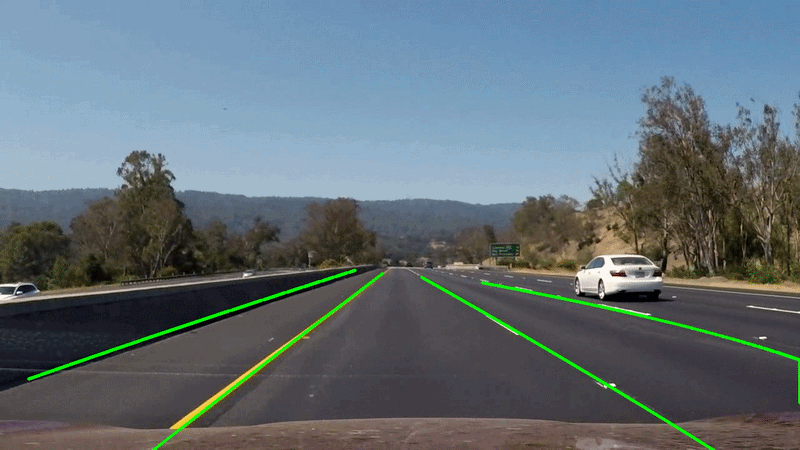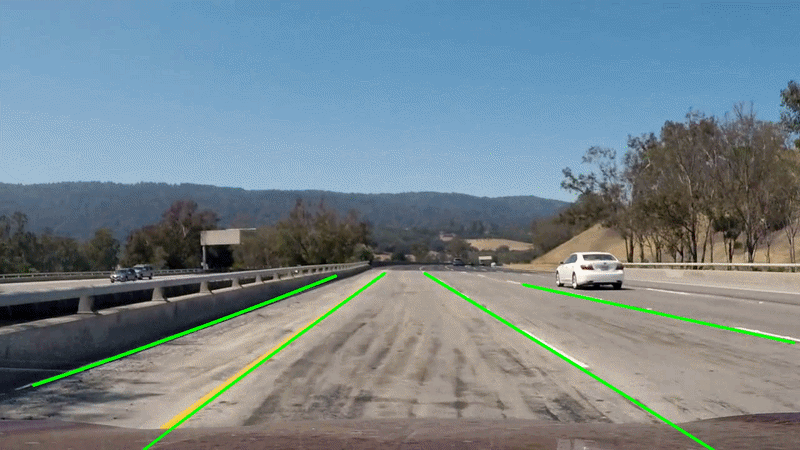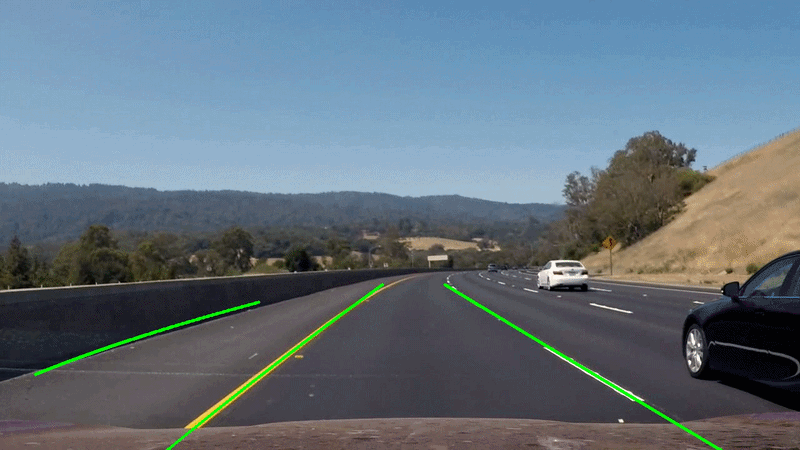
Extended Demo: Watch the full video here
Note: Because UFLDv2 operates as an internal feature module in VisionPilot's multi-feature voting pipeline, this standalone demo highlights the underlying model's perception capabilities before its output is merged into the final pixel voting matrix.
Foxglove Visualization
See real-time LiDAR point cloud streaming and autonomous vehicle telemetry in Foxglove Studio:
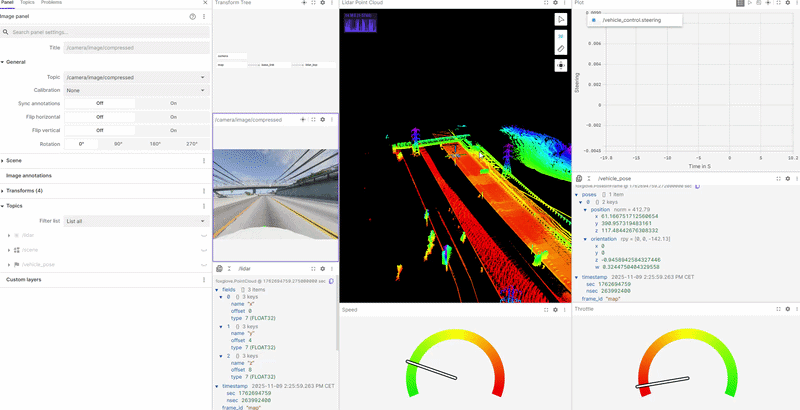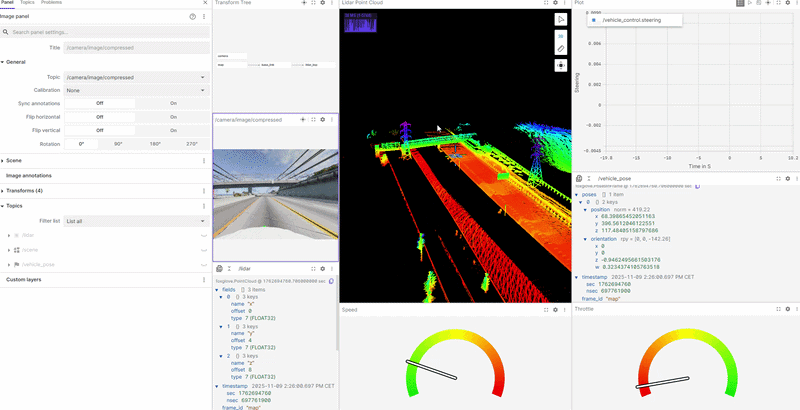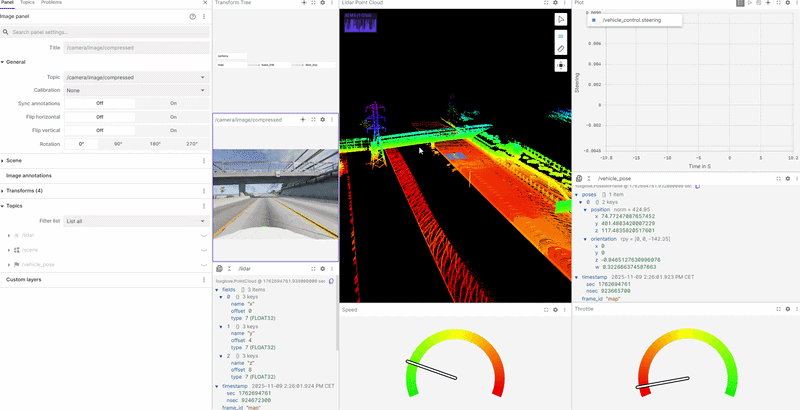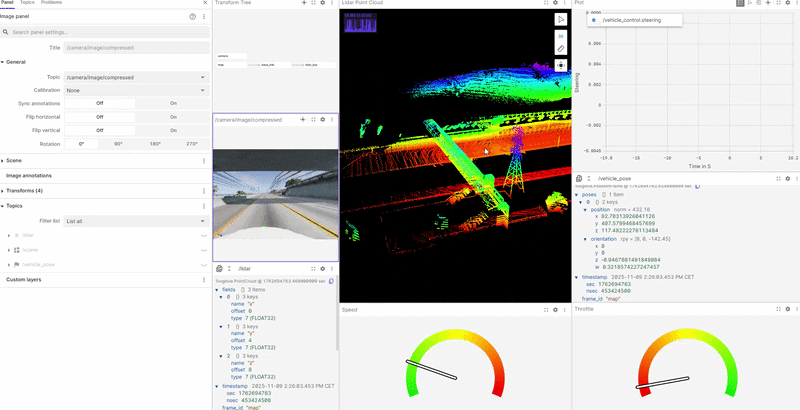
Extended Demo: Watch the full video here
More demo videos and visualizations will be added as features are completed.
Sensor Suite
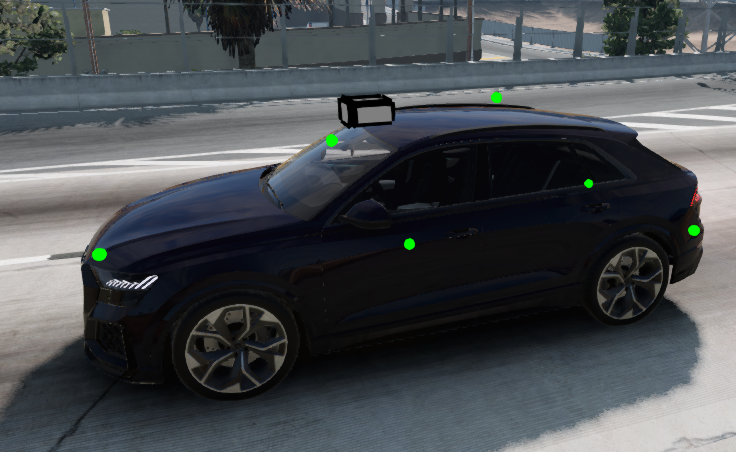
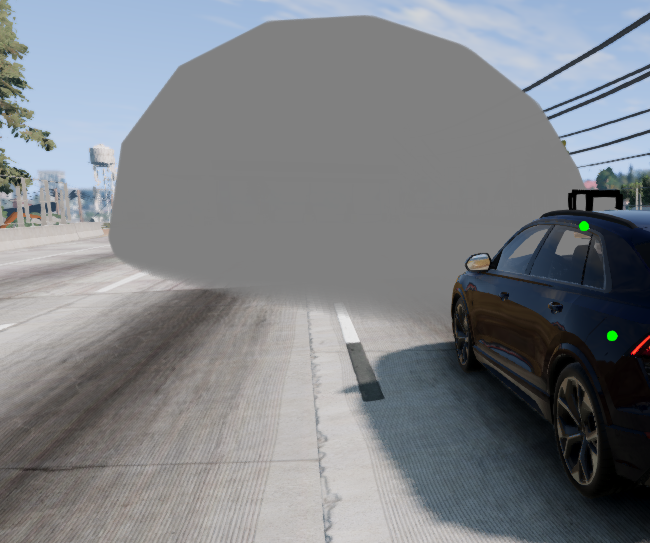
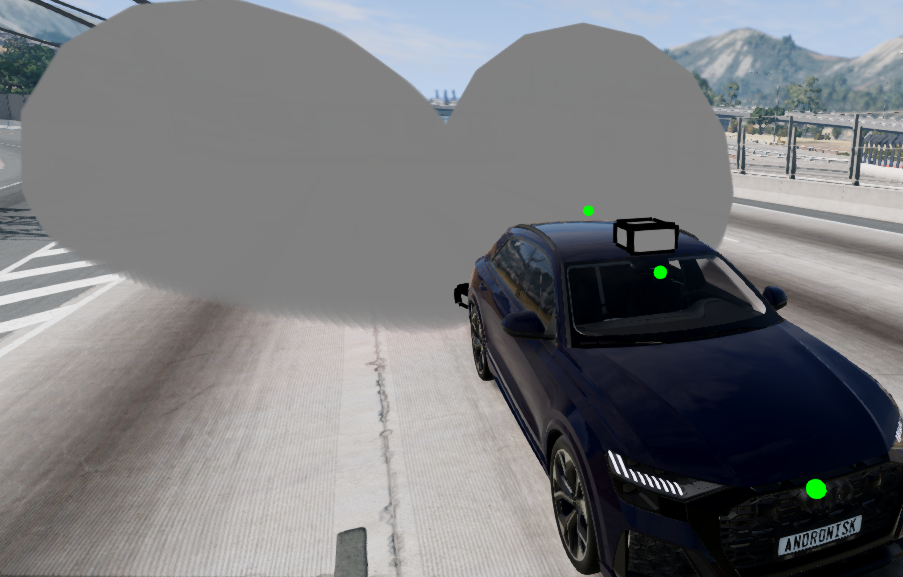
The vehicle is equipped with a comprehensive multi-sensor suite for autonomous perception and control:
| Sensor | Specification | Purpose |
|---|---|---|
| Front Camera | 1920x1080 @ 50Hz, 70° FOV, Depth enabled | Lane detection, traffic signs, traffic lights, object detection |
| LiDAR (Top) | 80 vertical lines, 360° horizontal, 120m range, 20Hz | Obstacle detection, 3D scene understanding |
| Front Radar | 200m range, 128×64 bins, 50Hz | Collision avoidance, adaptive cruise control |
| Rear Left & Right Radar | 30m range, 64×32 bins, 50Hz | Blindspot monitoring, rear object detection |
| Dual GPS | Front & rear positioning @ 50Hz | Localization |
| IMU | 100Hz update rate | Vehicle dynamics, pose estimation |
 |
 |
 |
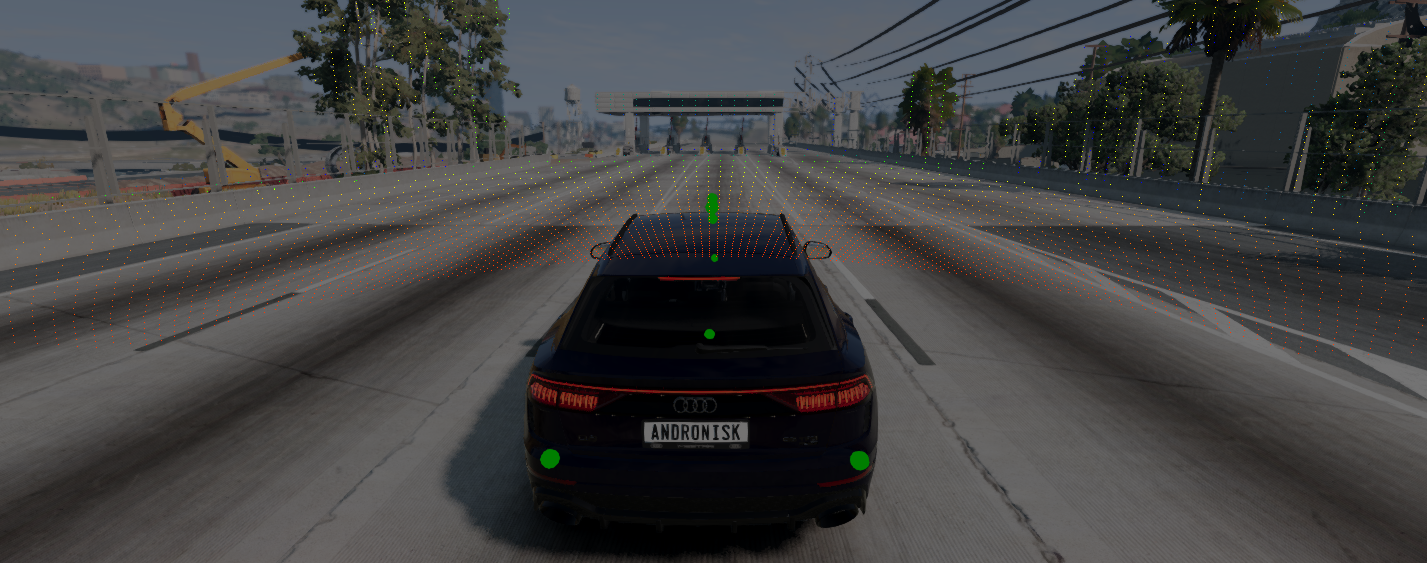 |
| Sensor Array | Front Radar | Rear Radars | Lidar Visualization |
Configuration files are located in the
/configdirectory:
Roadmap
Perception
2D Object & Scene Detection
- Sign classification & Detection (CNN / YOLO)
- Traffic light classification & Detection (CNN / YOLO)
- Multi-class object detection (Cars, Trucks, Buses, Pedestrians, Cyclists)
- Road Marking Detection (Arrows, Crosswalks, Stop Lines)
3D Perception & Spatial Estimation
- Speed Estimation using detection from camera and lidar
- Lidar Object Detection
- 💤 Multi Camera Setup (Will implement after all other camera-based features are finished)
- Multi-Object Tracking (MOT)
Lane & Drivable Area Segmentation
- Lane detection Fusion (UFLD / CV)
- 🔥 Ultra Fast Lane Detection (UFLD) integration
- Traditional CV Lane Detection (with Majority Voting & Lighting condition Detection)
- Improve voting system and add additional features
- Lighting Condition Detection
- Detect multiple lanes
- 🔥 Handle dashed lines better in lane detection
Sensor Fusion
Sensor Hardware Integration
- Integrate Radar
- Integrate Lidar
- Integrate GPS
- Integrate IMU
- 💤 Ultrasonic Sensor Integration
State Estimation & Mapping
- Kalman Filtering (Standard & Extended)
- 💤 SLAM (simultaneous localization and mapping)
- Build HD Map of the BeamNG.tech map
- Localize Vehicle on HD Map
Control & Planning
Low Level Motion Control
- Vehicle Control integration (Throttle, Steering, Braking)
- Integrate PIDF controller for steering and speed control
- 💤 Model Predictive Control (MPC) for more advanced control strategies
Safety & Driving Assist
- Adaptive Cruise Control (ACC)
- Cruise Control (CC)
- Automatic Emergency Braking (AEB)
- 🔥 Blind Spot Monitoring (BSD)
- Dynamic Target Speed
- Curve Speed Optimization
- Adaptive Cruise Control (ACC)
Tactical & Behavior Planning
- Behavior Tree Architecture (Stop, Yield, Lane Change, Overtake)
- Traffic Rule Enforcement (Stop at red lights, stop signs, yield signs)
- 🔥 Lane Change Logic (Check Blindspot, Signal, Execute)
- Obstacle Avoidance (Depends on Behavior Tree)
- Parking Logic (Parallel / Perpendicular Path Finding)
Trajectory & Path Planning
- Frenet Frame Transformation
- Global Path Planning
- Local Path Planning
- Trajectory Prediction (Surrounding Vehicle Intent)
Simulation & Scenarios
- Integrate and test in BeamNG.tech simulation
- Modularize and clean up BeamNG.tech pipeline
- CARLA Simulator Integration (Planned / Help Wanted)
Note: CARLA support is planned for multi-simulator testing, but active development hasn't started yet. PRs and community contributions are very welcome!
- Environmental Conditions (Fog, Night, Dawn/Dusk, Tunnels/Low-Light)
- Traffic scenarios (Light, Moderate, Heavy)
- 💤 Physical RC Deployment
Visualization & Logging
- ⭐ Full Foxglove visualization integration (Overhaul needed)
- Modular YAML configuration system
- Real-time drive logging and telemetry
Note: Considering moving away from Foxglove entirely to build a custom dashboard. Not a priority at this time.
- Spatial & Path Visualization
- 🔥 Birds-Eye View (BEV)
- Inverse Perspective Mapping (IPM)
- Map & Real Time Perception Overlay
- Trajectory & Path Plan Overlays in Foxglove
Deployment & Infrastructure
- 💤 Microservices Architecture
- Containerize models with Docker
- Aggregator service for concurrent inference orchestration
- Message Broker (Redis)
Meta & Documentation
- Vibe-Code a website for the project
- Redo project structure for better modularity
- README Demo Media
- Performance Benchmarks
- Documentation
- First release with pre-trained models
Legend
🔥 High Priority
⭐ Refining / In Progress (Working baseline, needs tuning and improvements)
💤 Backlog / Postponed (Nice to have, deferred)
Note on Installation
Status: This project is currently in active development. A stable, production-ready release with pre-trained models and complete documentation will be available eventually.
Known Limitations
- Simulator Support: Currently only validated in BeamNG.tech. CARLA simulator integration is planned, but not yet implemented.
- Tunnel/Low-Light Scenarios: Camera perception fails below certain lighting thresholds
- Multi-Camera Support: Single front-facing camera only (future roadmap)
- PID Controller Tuning: May oscillate on tight curves
- Real-World Testing: Only validated in simulation (BeamNG.tech), for now...
Credits
Datasets:
- CU Lane, LISA, GTSRB, Mapillary, BDD100K
Simulation & Tools:
- BeamNG.tech by BeamNG GmbH
- Foxglove Studio for visualization
- Docker & Docker Compose for containerization
Special Thanks:
- Kaggle for free GPU resources (Model Training)
- Mr. Pratt (Teacher/Supervisor) for guidance
Acknowledgements
Academic Papers & Research:
Ultra Fast Deep Lane Detection v2
@ARTICLE{qin2022ultrav2,
  author={Qin, Zequn and Zhang, Pengyi and Li, Xi},
  journal={IEEE Transactions on Pattern Analysis and Machine Intelligence},
  title={Ultra Fast Deep Lane Detection With Hybrid Anchor Driven Ordinal Classification},
  year={2022},
  doi={10.1109/TPAMI.2022.3182097}
}
Citation
If you use VisionPilot in your project, please cite:
@software{visionpilot2026,
  title={VisionPilot: Autonomous Driving Simulation, Computer Vision & Real-Time Perception},
  author={Julian Stamm},
  year={2026},
  url={https://github.com/visionpilot-project/VisionPilot}
}
BeamNG.tech Citation
Title: BeamNG.tech
Author: BeamNG GmbH
Address: Bremen, Germany
Year: 2025
Version: 0.35.0.0
URL: https://www.beamng.tech/
License
This project is licensed under the MIT License - see LICENSE file for details.
Explorer des projets similaires
tensorflow/tensorflow
Un framework open source d'apprentissage automatique pour tous
201,585 étoileshuggingface/transformers
🤗 Transformers : le framework de définition de modèles pour les modèles d'apprentissage automatique de pointe en texte, vision, audio et multimodal, pour l'inférence et l'entraînement.
168,948 étoilesAUTOMATIC1111/stable-diffusion-webui
Interface web de Stable Diffusion
165,302 étoilesComfy-Org/ComfyUI
La GUI, l'API et le backend les plus puissants et modulaires pour les modèles de diffusion, avec une interface de graphes et de nœuds. Le moteur d'inférence local le plus rapide au monde.
146,657 étoiles