
VjiaLi/V2U4Real
VjiaLi/V2U4Real has 74 GitHub stars and 2 forks. Star changes are not measured yet. Last checked 2026-11-13 22:20 UTC. Last push 2026-07-23.
Progression mesurée des étoiles
- in 24h
- Historique en cours
- in 7 days
- Historique en cours
- in 15 days
- Historique en cours
- in 1 month
- Historique en cours
Variations nettes sur des périodes qui se chevauchent, pas des totaux quotidiens. Les mesures absentes restent vides. Les étoiles indiquent l’intérêt, pas la qualité.
À propos
CVPR 2026 - V2U4Real: A Real-world Large-scale Dataset for Vehicle-to-UAV Cooperative Perception
Outils de développementREADME.md
Original
V2U4Real: A Real-world Large-scale Dataset for Vehicle-to-UAV Cooperative Perception
Weijia Li, Haoen Xiang, Tianxu Wang, Shuaibing Wu, Qiming Xia, Cheng Wang, Chenglu Wen
CVPR 2026
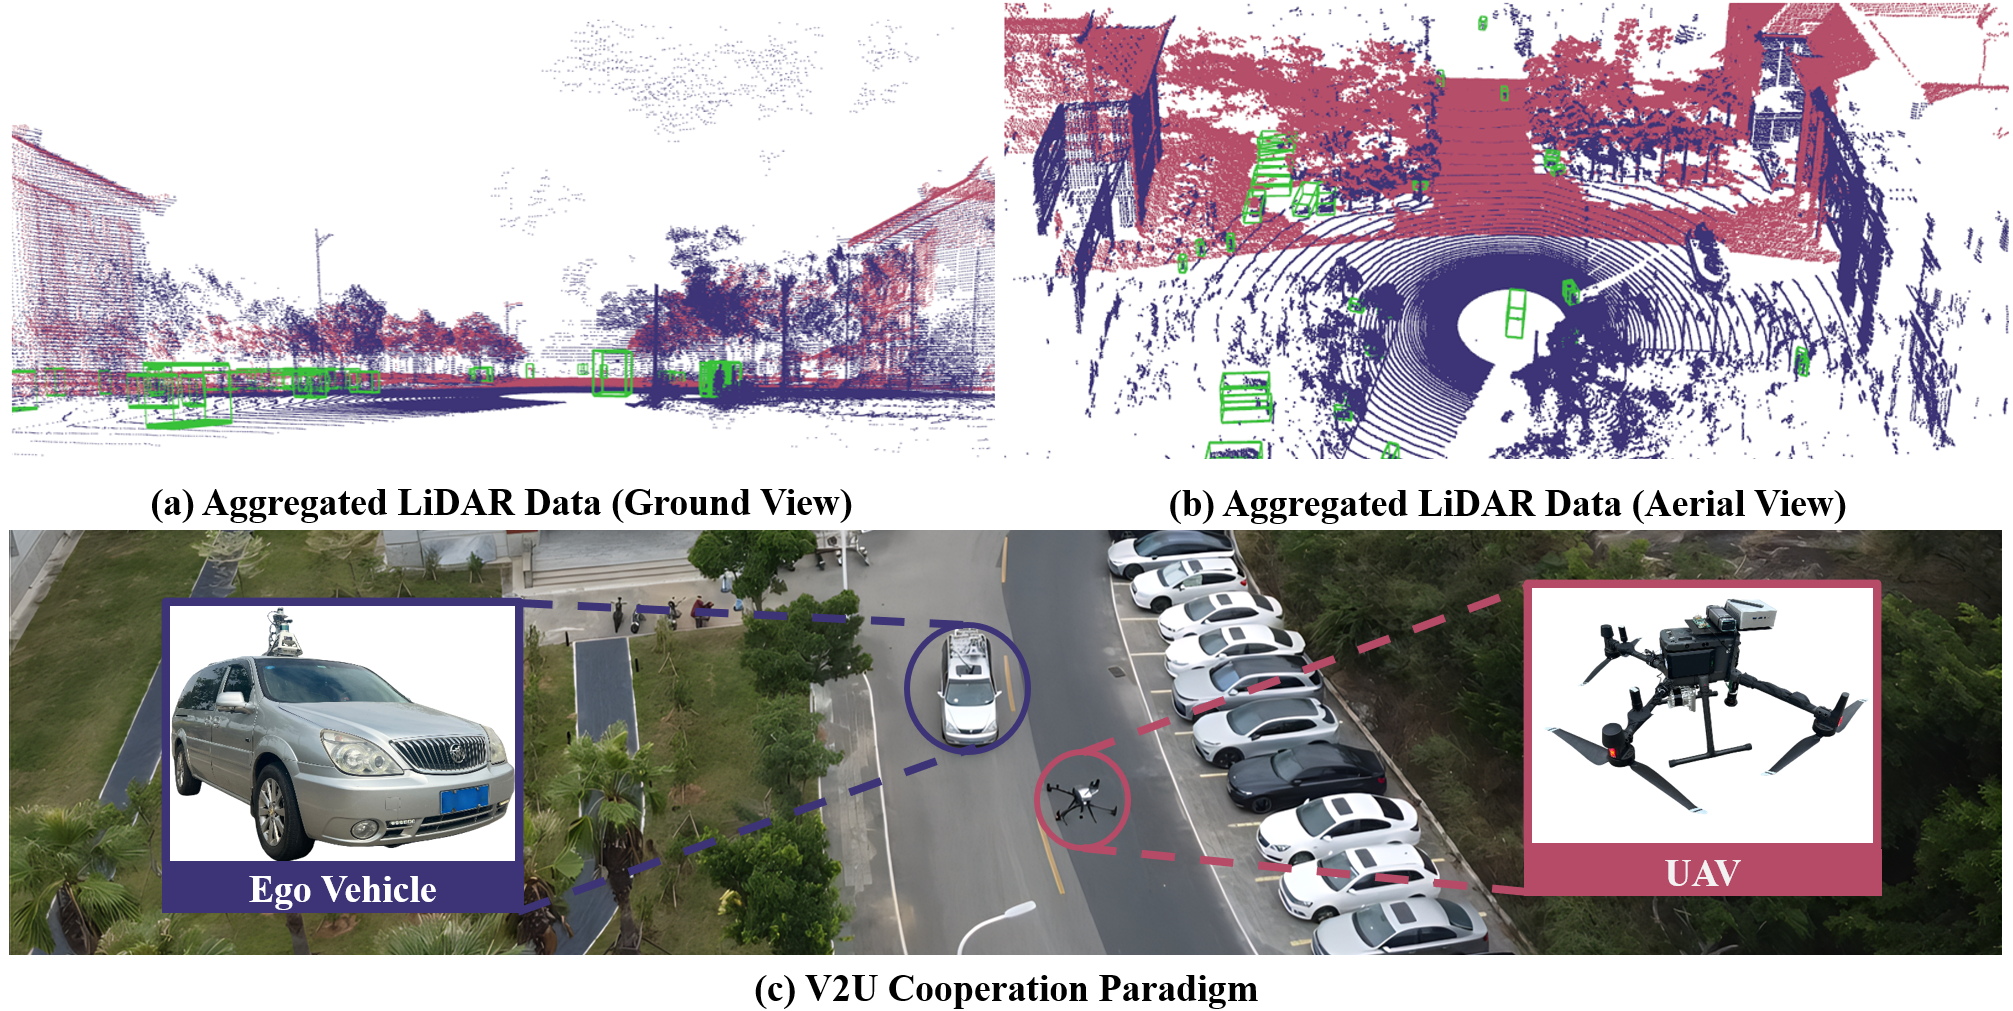



Dataset Demo
News
- [2026.02] V2U4Real is accepted to CVPR 2026:boom::boom::boom:.
- [2026.05] Codebase is released.
- [2026.07] Dataset download links were released.
TODO
- Release training and inference code
- Release pretrained models
- Release benchmark leaderboard
- Release dataset download links
Installation
1. Clone the repository
git clone https://github.com/VjiaLi/V2U4Real.git
cd V2U4Real
2. Create the environment
We recommend using Conda:
conda env create -f environment.yml
conda activate v2u4real
python setup.py develop
If Conda installation fails, you can install the dependencies with pip instead:
pip install -r requirements.txt
python setup.py develop
3. Pytorch Installation (>=1.8, tested on 1.8-1.12.0)
Go to https://pytorch.org/ to install pytorch cuda version.
4. Install Spconv
pip install spconv-cu113
Notes for installing spconv 1.2.1:
- Make sure your cmake version >= 3.13.2
- CUDNN and CUDA runtime library (use
nvcc --versionto check) needs to be installed on your machine.
4. Compile CUDA ops for 3D box IoU / NMS
python opencood/utils/setup.py build_ext --inplace
Data Download
Please check Hugging Face to download the data.
After downloading the data, please put the data in the following structure:
├── V2U4Real
│   ├── train
|       |── 2025-07-17-16-12_1
|       |   |──1  # Vehicle Side
|       |   |  |── camera
|       |   |  |   |── left     # left camera images
|       |   |  |   |   |── 000001.jpg
|       |   |  |   |── middle   # center camera images
|       |   |  |   |   |── 000001.jpg
|       |   |  |   |── right    # right camera images
|       |   |  |   |   |── 000001.jpg
|       |   |  |── ouster       # OS-128 LiDAR point clouds
|       |   |  |   |── 000001.pcd
|       |   |  |── ruby         # RS-128 LiDAR point clouds
|       |   |  |   |── 000001.pcd
|       |   |  |── m1           # M1-PLUS LiDAR point clouds
|       |   |  |   |── 000001.pcd
|       |   |  |── yaml         # metadata for each timestamp
|       |   |  |   |── ouster
|       |   |  |   |   |── 000001.yaml
|       |   |  |   |── ruby
|       |   |  |   |   |── 000001.yaml
|       |   |  |   |── m1
|       |   |  |   |   |── 000001.yaml
|       |   |──2  # UAV Side
|       |   |  |── camera       # downward camera images
|       |   |  |   |── 000001.jpg
|       |   |  |── ouster       # OS-128 LiDAR point clouds
|       |   |  |   |── 000001.pcd
|       |   |  |── yaml         # metadata for each timestamp
|       |   |  |   |── ouster
|       |   |  |   |   |── 000001.yaml
|       |── 2025-07-17-16-12_2
│   ├── val
│   ├── test
Quick Start
Data sequence visualization
To quickly visualize the LiDAR stream in the V2U4Real dataset, first modify the validate_dir
in your opencood/hypes_yaml/visualization.yaml to the v2u4real data path on your local machine, e.g. v2u4real/val,
and then run the following command:
cd ~/V2U4Real
python opencood/visualization/vis_data_sequence.py [--color_mode ${COLOR_RENDERING_MODE}]
Arguments Explanation:
color_mode: str type, indicating the lidar color rendering mode. You can choose from 'constant', 'intensity' or 'z-value'.
Train your model
V2U4Real uses yaml file to configure all the parameters for training. To train your own model from scratch or a continued checkpoint, run the following command:
python opencood/tools/train.py --hypes_yaml ${CONFIG_FILE} [--model_dir ${CHECKPOINT_FOLDER} --half]
Arguments Explanation:
hypes_yaml: the path of the training configuration file, e.g.opencood/hypes_yaml/pointpillar_early_fusion.yaml, meaning you want to train an early fusion model which utilizes Pointpillar as the backbone.model_dir(optional) : the path of the checkpoints. This is used to fine-tune the trained models. When themodel_diris given, the trainer will discard thehypes_yamland load theconfig.yamlin the checkpoint folder.half(optional): If set, the model will be trained with half precision. It cannot be set together with multi-gpu training.
To train on multiple gpus, run the following command:
CUDA_VISIBLE_DEVICES=0,1,2,3 python -m torch.distributed.launch --nproc_per_node=4 --use_env opencood/tools/train.py --hypes_yaml ${CONFIG_FILE} [--model_dir ${CHECKPOINT_FOLDER}]
Test the model
Before you run the following command, first make sure the validation_dir in config.yaml under your checkpoint folder
refers to the testing dataset path, e.g. v2u4real/test.
python opencood/tools/inference.py --model_dir ${CHECKPOINT_FOLDER} --fusion_method ${FUSION_STRATEGY} [--show_vis] [--show_sequence]
Arguments Explanation:
model_dir: the path to your saved model.fusion_method: indicate the fusion strategy, currently support 'early', 'late', and 'intermediate'.show_vis: whether to visualize the detection overlay with point cloud.show_sequence: the detection results will visualized in a video stream. It can NOT be set withshow_visat the same time.
The evaluation results will be dumped in the model directory.
Benchmark and Model Zoo
Results of Cooperative 3D object detection
| Method | Backbone | Sync [email protected] | Sync [email protected] | Async [email protected] | Async [email protected] | Bandwidth | Download Link |
|---|---|---|---|---|---|---|---|
| Late Fusion | PointPillar | 43.53 | 21.46 | 24.36 | 9.88 | 0.009 | url |
| Early Fusion | PointPillar | 51.31 | 27.74 | 30.94 | 13.99 | 3.18 | url |
| Where2Comm | PointPillar | 53.85 | 29.71 | 48.99 | 28.36 | 0.65 | url |
| AttFuse | PointPillar | 50.20 | 27.33 | 40.51 | 21.92 | 0.65 | url |
| V2X-ViT | PointPillar | 45.51 | 25.99 | 45.74 | 26.00 | 0.65 | url |
| CoBEVT | PointPillar | 41.99 | 22.38 | 31.47 | 16.05 | 0.65 | url |
| CoAlign | PointPillar | 56.67 | 36.61 | 50.81 | 33.33 | 0.65 | url |
| ERMVP | PointPillar | 45.56 | 22.64 | 28.06 | 14.22 | 0.65 | url |
| DSRC | PointPillar | 54.64 | 31.77 | 47.63 | 26.05 | 0.65 | url |
| No Fusion (Vehicle only) | PointPillar | 27.53 | 12.75 | 27.53 | 12.75 | 0.0 | |
| No Fusion (UAV only) | PointPillar | 32.44 | 14.31 | 32.44 | 14.31 | 0.0 |
Results of Cooperative 3D object tracking
| Method | AMOTA(↑) | AMOTP(↑) | sAMOTA(↑) | MOTA(↑) | MOTP(↑) | MT(↑) | ML(↓) |
|---|---|---|---|---|---|---|---|
| Early Fusion | 19.22 | 39.41 | 56.79 | 59.26 | 64.67 | 67.94 | 23.81 |
| Late Fusion | 14.82 | 34.39 | 51.12 | 50.64 | 64.90 | 48.41 | 37.30 |
| AttFuse | 20.98 | 41.31 | 61.55 | 60.40 | 64.89 | 57.94 | 23.81 |
| Where2comm | 20.07 | 41.49 | 58.52 | 62.07 | 63.04 | 65.08 | 15.87 |
| V2X-ViT | 14.74 | 35.25 | 50.38 | 50.76 | 64.76 | 57.94 | 30.16 |
| CoBEVT | 15.96 | 36.53 | 52.62 | 53.60 | 64.54 | 51.59 | 35.71 |
| CoAlign | 22.08 | 43.11 | 59.03 | 63.49 | 65.43 | 69.05 | 14.29 |
| ERMVP | 19.02 | 37.42 | 56.82 | 58.27 | 63.31 | 35.71 | 49.21 |
| DSRC | 18.67 | 39.72 | 53.20 | 59.74 | 65.03 | 73.02 | 13.49 |
| No Fusion (Vehicle only) | 11.73 | 25.84 | 46.56 | 45.33 | 44.59 | 34.13 | 52.38 |
| No Fusion (UAV only) | 7.00 | 21.58 | 33.56 | 35.72 | 55.40 | 3.17 | 81.75 |
Citation
If you find this dataset or code useful in your research, please consider citing our paper.
@inproceedings{li2026v2u4real,
  title={V2U4Real: A Real-world Large-scale Dataset for Vehicle-to-UAV Cooperative Perception},
  author={Li, Weijia and Xiang, Haoen and Wang, Tianxu and Wu, Shuaibing and Xia, Qiming and Wang, Cheng and Wen, Chenglu},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  pages={4728--4737},
  year={2026}
}
Acknowledgements
Thanks for the excellent cooperative perception datasets OPV2V and V2V4Real.
Thanks for the dataset and code support from DerrickXu.
Explorer des projets similaires
codecrafters-io/build-your-own-x
Maîtrisez la programmation en recréant de zéro vos technologies préférées.
562,335 étoilespublic-apis/public-apis
Une liste collective d'API gratuites
498,773 étoilesmorluto/rea
Rétro-ingénierie de n'importe quoi avec des agents, du comportement des applications jusqu'aux binaires natifs.
457,506 étoilesopenclaw/openclaw
L'IA qui fait vraiment les choses. Tout système d'exploitation, toute plateforme. À la manière du homard. 🦞
394,396 étoiles