
stmorgenstern/diff-soup
stmorgenstern/diff-soup has 55 GitHub stars and 4 forks. GitHot measured 0 stars in 24 hours and +2 in 7 days. Last checked 2026-11-20 19:27 UTC. Last push 2026-11-17.
Crecimiento de estrellas medido
- in 24h
- 0
- in 7 days
- +2
- in 15 days
- Recopilando historial
- in 1 month
- Recopilando historial
Cambios netos en períodos que se solapan, no totales diarios. Los datos no disponibles se dejan en blanco. Las estrellas indican interés, no calidad.
Acerca de
Multiphysics modeling, differentiable simulation, and physically-constrained machine learning in JAX using GPU-accelerated stiff solvers with sparse numerical methods
Aprendizaje automáticoREADME.md
Originaldiff-soup: differentiable, sparse-oriented unified PDE suite

diff-soup is a software package written in JAX for modeling, simulation, and inference of (stiff) dynamical systems governed by ODEs, DAEs, and PDEs.
For modeling:
- a Recipe API that states equations in math-like notation on structured and unstructured domains;
- finite difference, finite volume and finite element discretizations;
- sparse Jacobians assembled by automatic differentiation with graph coloring.
For simulation:
- three variable-step, variable-order stiff integrators written in JAX,
JNDF,JBDFandJIDA, for ODEs and DAEs up to index one; - sparse direct solves with NVIDIA cuDSS on the GPU, and KLU or dense solves on the CPU;
- forward and reverse mode differentiation of every solve, to second order;
- batched solves, with data and model parallelism across GPUs and cluster nodes.
For inference:
- parameter estimation using least squares estimation, maximum likelihood estimation (MLE), and maximum a posteriori (MAP) estimation;
- physically-constrained deep learning using differentiable simulation, with neural networks embedded inside the physical model.
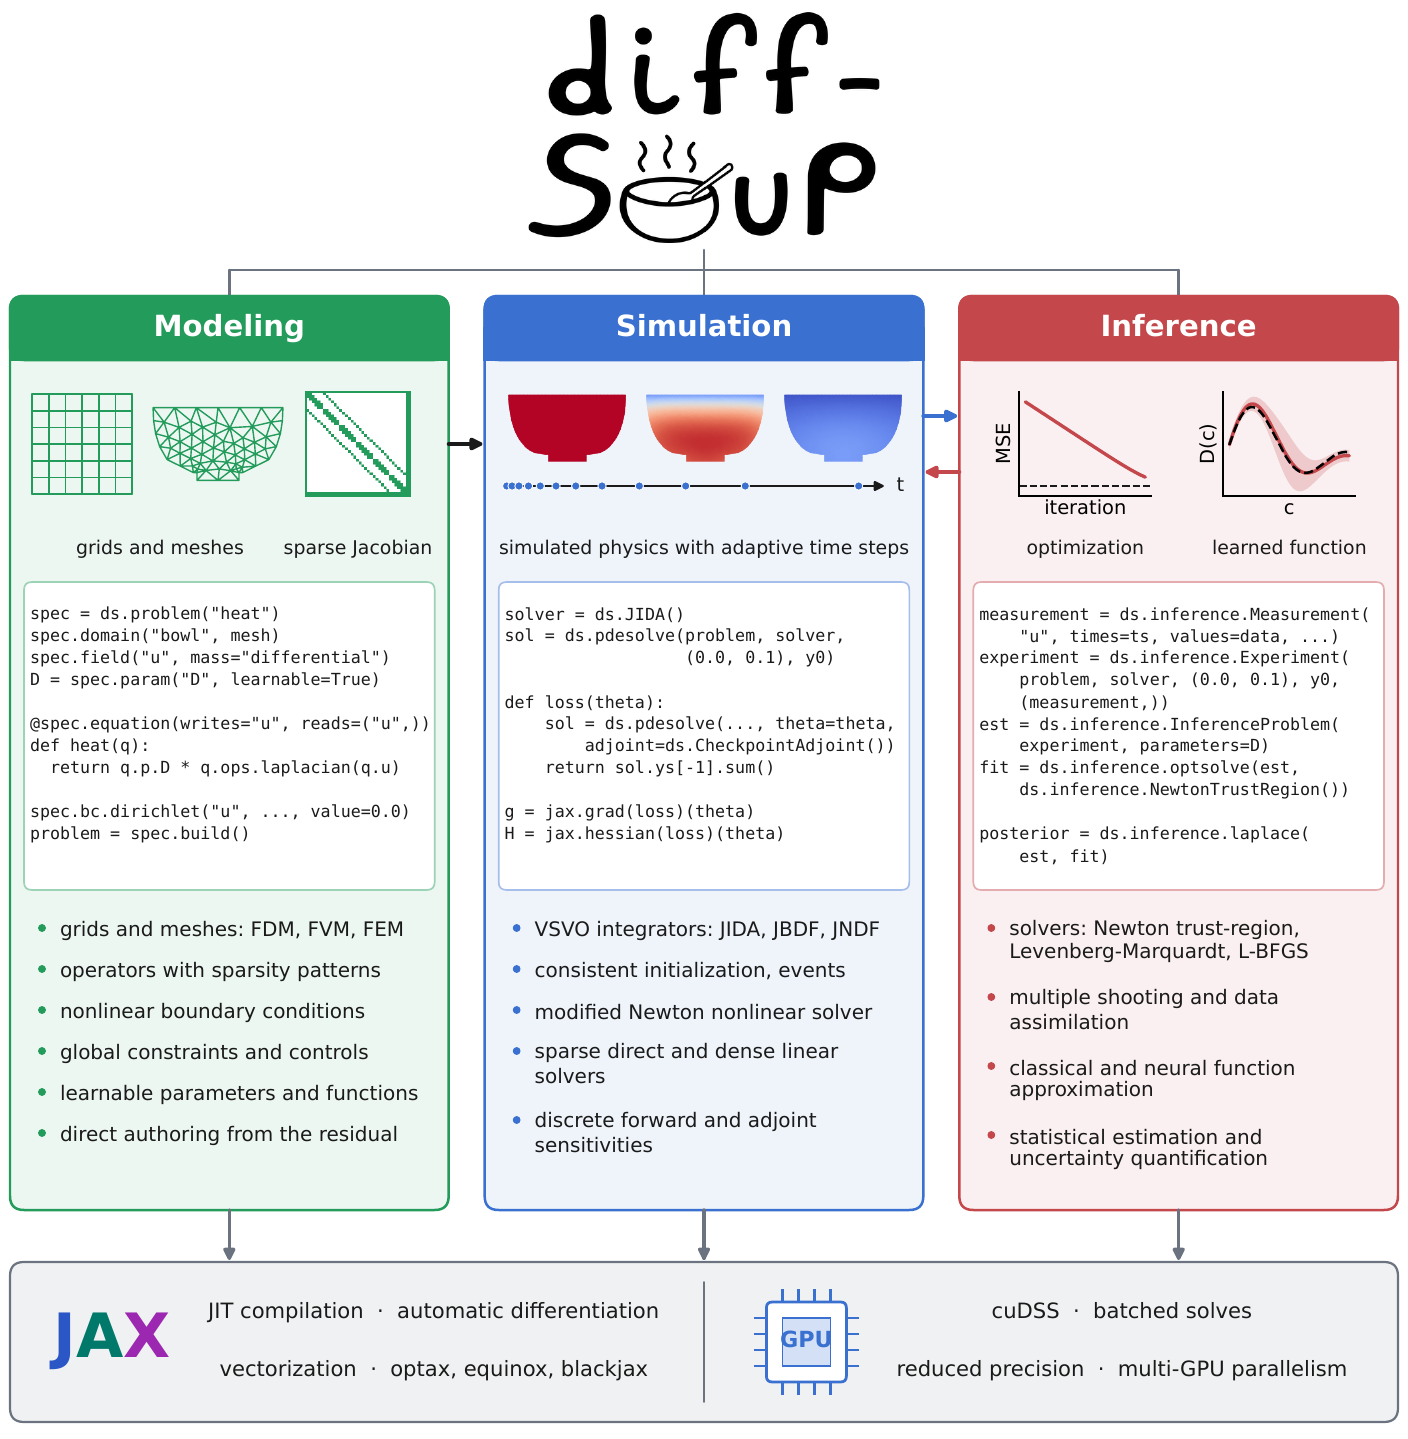
The modeling, simulation and inference modules of diff-soup, and the JAX and GPU features they are built on.
Installation
pip install "diff-soup[cu13]"   # CUDA 13, driver 580 or newer
pip install "diff-soup[cu12]"   # CUDA 12, driver 525 or newer
pip install diff-soup           # CPU only
Requires Linux x86_64 and Python 3.12 or 3.13. The GPU backend needs an NVIDIA GPU of compute capability 8.0 or newer.
Turn on JAX's 64-bit mode with jax.config.update("jax_enable_x64", True) before building a problem.
Building from source is covered on the installation page.
Documentation
Available at https://stmorgenstern.github.io/diff-soup/.
Quick example
The two-dimensional Brusselator, a stiff reaction-diffusion system, on a 32 by 32 finite-volume grid with its walls held at the reaction steady state:
import diff_soup as ds
import jax
import jax.numpy as jnp

jax.config.update("jax_enable_x64", True)

n = 32
A, B, alpha = 1.0, 3.0, 1.0 / 50.0

spec = ds.problem("brusselator")
spec.domain("square", ds.domains.cartesian_grid_2d(n, n, 1.0, 1.0, method="fvm"))
spec.field("u", mass="differential",
           init=lambda x, y: A + jnp.sin(2 * jnp.pi * x) * jnp.sin(2 * jnp.pi * y))
spec.field("v", mass="differential", init=lambda x, y: jnp.full_like(x, B / A))

@spec.equations(writes=("u", "v"), reads=("u", "v"))
def brusselator(q):
    uuv = q.u**2 * q.v
    du = A + uuv - (B + 1.0) * q.u + alpha * q.ops.laplacian(q.u)
    dv = B * q.u - uuv + alpha * q.ops.laplacian(q.v)
    return {"u": du, "v": dv}

i, j = jnp.indices((n, n))
wall = ((i == 0) | (i == n - 1) | (j == 0) | (j == n - 1)).ravel()
spec.bc.dirichlet("u", on=wall, value=A)
spec.bc.dirichlet("v", on=wall, value=B / A)

problem = spec.build()
y0 = spec.assemble_state({})

sol = ds.pdesolve(problem, ds.JIDA(), (0.0, 10.0), y0)
u_end = sol.ys[-1][: n * n]
print(float(u_end.mean()))   # the average of u over the square at t = 10
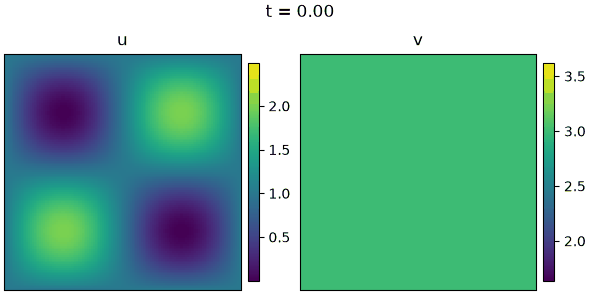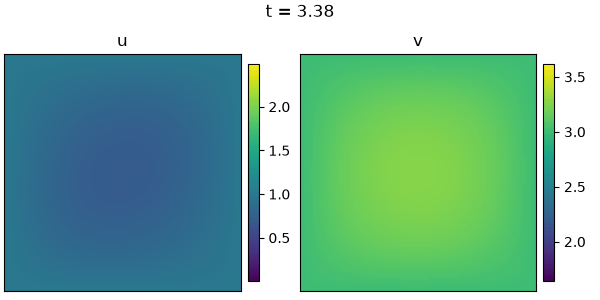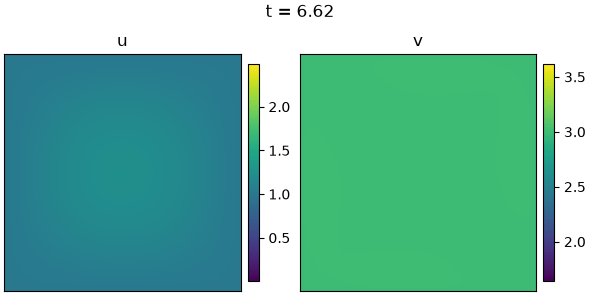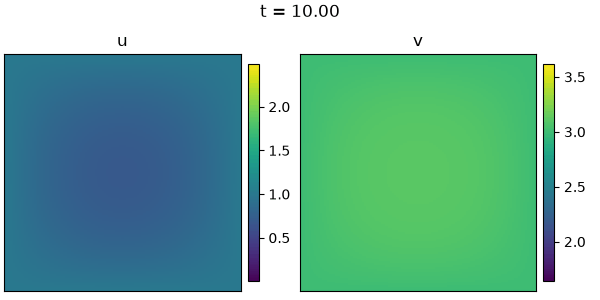
u and v of the same model on a 128 by 128 grid, from t = 0 to t = 10.
Acknowledgments
diff-soup builds on the following projects.
Time stepping
SUNDIALS: IDA and CVODE, whose step-size, error-weight and solver-reuse rules the integrators follow (Hindmarsh et al. 2005).
OrdinaryDiffEq.jl: the QNDF method the NDF integrator follows (Rackauckas and Nie 2017).
SciPy: BDF dense output and the bounded least-squares trust region.
Sparse direct solvers
SuiteSparse KLU: the CPU sparse LU (Davis and Palamadai Natarajan 2010).
SuperLU_MT: the threaded CPU sparse LU for source builds (Li 2005).
NVIDIA cuDSS: the GPU sparse direct solver.
JAX ecosystem
JAX: the array library and compiler diff-soup is written in.
Equinox: modules and PyTree tools.
Diffrax: the interfaces for saving output and events, which diff-soup mirrors.
jaxtyping: shape and dtype annotations.
Optax: first-order optimisers for the embedded neural networks.
BlackJAX: posterior sampling.
diff-soup is released under the BSD 3-Clause License, see LICENSE. Third-party licences and notices are listed in THIRD_PARTY_NOTICES.md.
Citation
If you use diff-soup, please cite the paper, arXiv:2610.37333.
@article{degnanmorgenstern2026diffsoup,
    title={diff-soup: {GPU}-native Differentiable Simulation and Inference for Large-scale Stiff Dynamical Systems},
    author={Samuel Degnan-Morgenstern and Martin Z. Bazant},
    journal={arXiv preprint arXiv:2610.37333},
    year={2026},
}