
but0n/Avem
but0n/Avem has 2,945 GitHub stars and 584 forks. GitHot measured 0 stars in 24 hours, +6 in 7 days, and +6 in 15 days. Last checked 2026-11-22 02:51 UTC. Last push 2023-10-03.
Crecimiento de estrellas medido
- in 24h
- 0
- in 7 days
- +6
- in 15 days
- +6
- in 1 month
- Recopilando historial
Cambios netos en períodos que se solapan, no totales diarios. Los datos no disponibles se dejan en blanco. Las estrellas indican interés, no calidad.
Acerca de
🚁 Controlador de vuelo ligero para drones-[Drone]-[STM32]-[PID]-[BLDC]
Herramientas de desarrolloREADME.md
Original


Avem :bird:
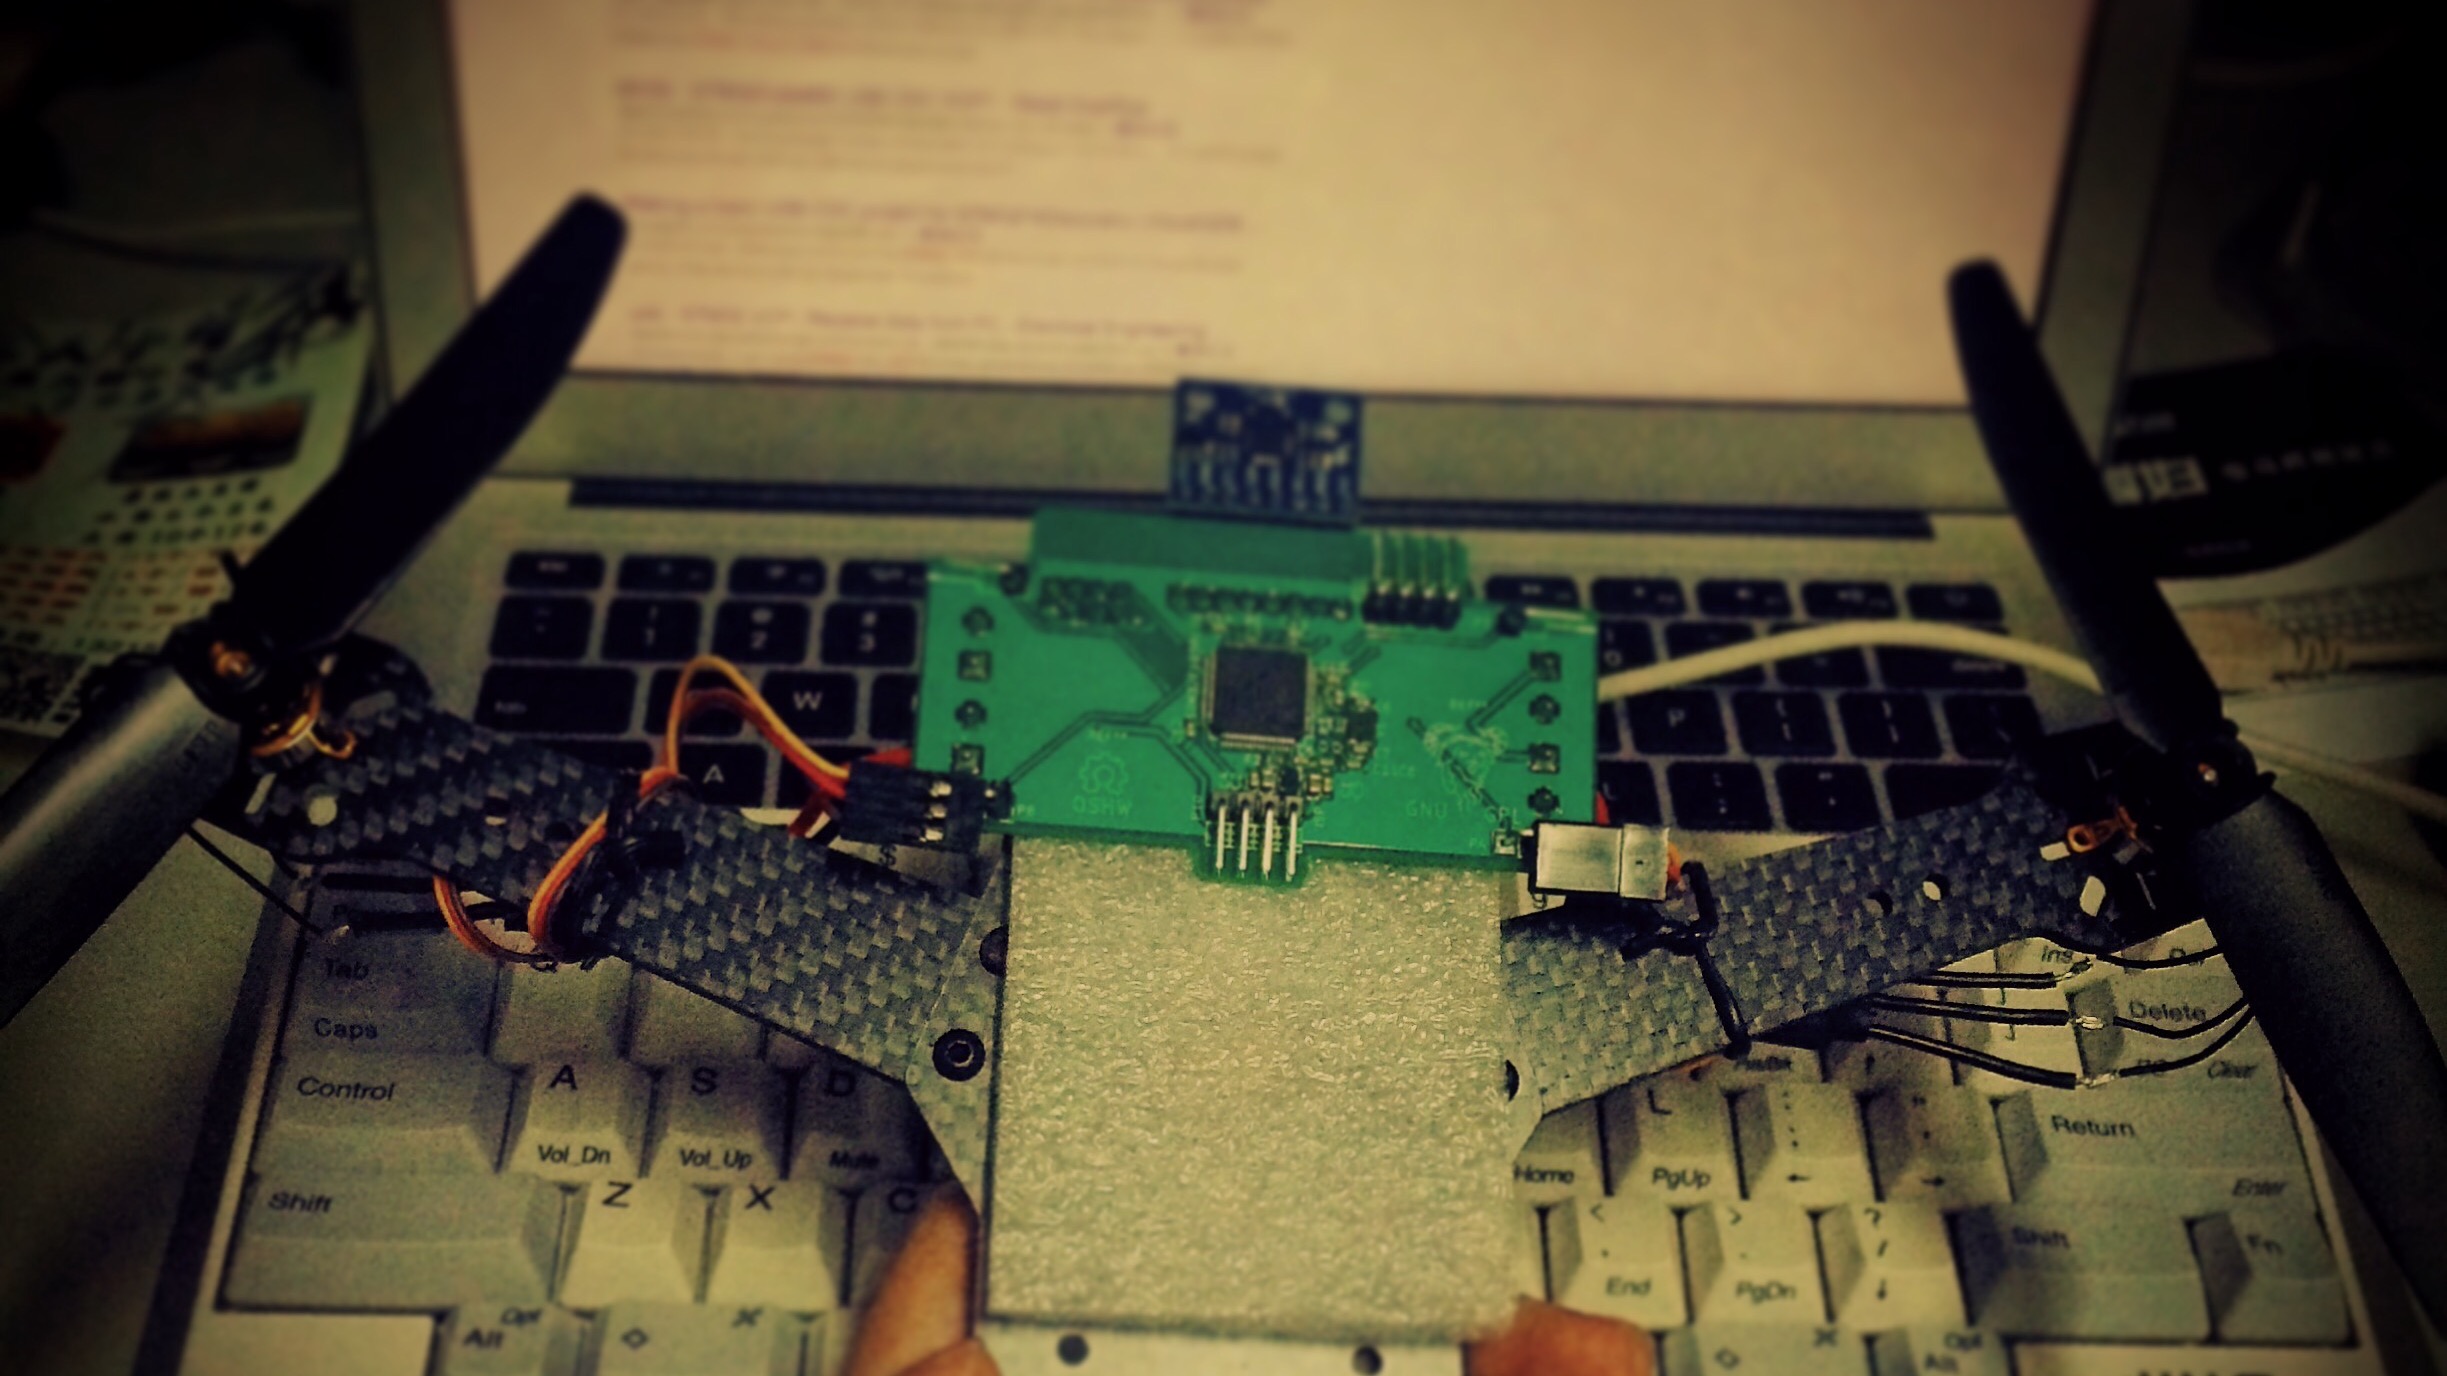
[UAV] - [STM32F103] - 6 Axes sensor MPU6050 - Quaternion & Euler Angles Compute - PID Controller
Terminal demo
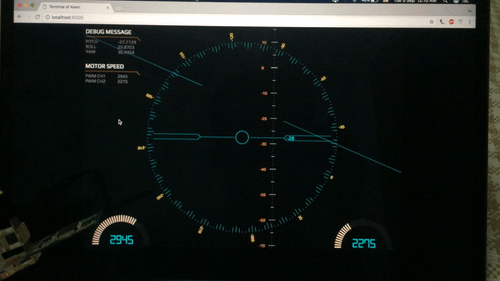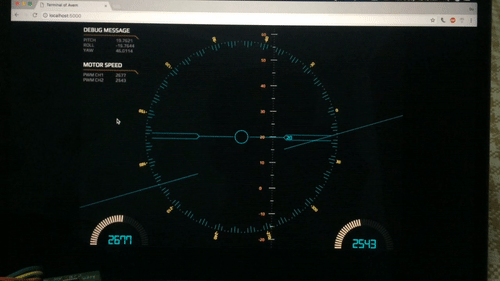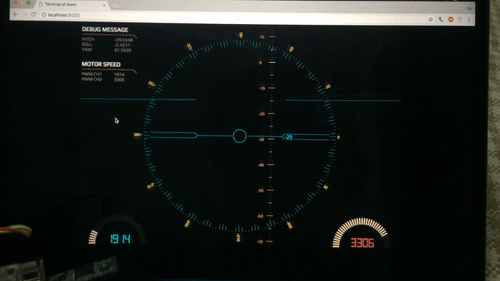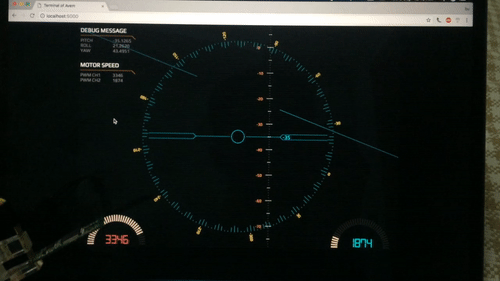

https://github.com/but0n/Avem_HUD
I/O List
MPU6050 | BLDC | Wi-Fi | GPS
:----: |:----: |:----: |:---:
SCL PB15 |Channel 1 PA6|USART3_TX PB10 |TBD
SDA PB14 |Channel 2 PA7|USART3_RX PB11 |TBD
||Channel 3 PB0| | |
||Channel 4 PB1| | |
To-do list
- Software I2C
- Init MPU6050
- Get 3 axes
Gryoand 3 axesAcceldata from MPU6050 - Cumpute Quaternion and Euler Angles
- PWM output
- Driving motors with L9110S
- PID Control
- Schematic
- PCB Layout
- Brushless DC motor-Video via YouTube
- Wi-Fi(
ESP8266) - Cascade PID control
- FreeRTOS
- Host: Flask + pyserial
- PID debug
- GPS
Hardware

Schematic

PCB Layout
Version 3.0

Made with ♥ by but0n
Explorar proyectos relacionados
Cargando…