
arthurdjn/pytorch-pointcloud
arthurdjn/pytorch-pointcloud has 36 GitHub stars and 3 forks. GitHot measured 0 stars in 24 hours, +3 in 7 days, and +3 in 15 days. Last checked 2026-11-20 21:03 UTC. Last push 2026-11-18.
Crecimiento de estrellas medido
- in 24h
- 0
- in 7 days
- +3
- in 15 days
- +3
- in 1 month
- Recopilando historial
Cambios netos en períodos que se solapan, no totales diarios. Los datos no disponibles se dejan en blanco. Las estrellas indican interés, no calidad.
Acerca de
PyTorch Point Cloud models, scripts, pretrained weights -- PointNet++, KPConv, RandLA-Net, VoteNet, SPVCNN, 3DETR, PointTransformer, OctFormer, PointMamba and more
Aprendizaje automáticoREADME.md
Original
Deep learning on point clouds, with PyTorch.
Models, pretrained weights, datasets, transforms and inferers, in the style of
timm and
PyG.



Documentation · Model zoo · Tutorials · Changelog
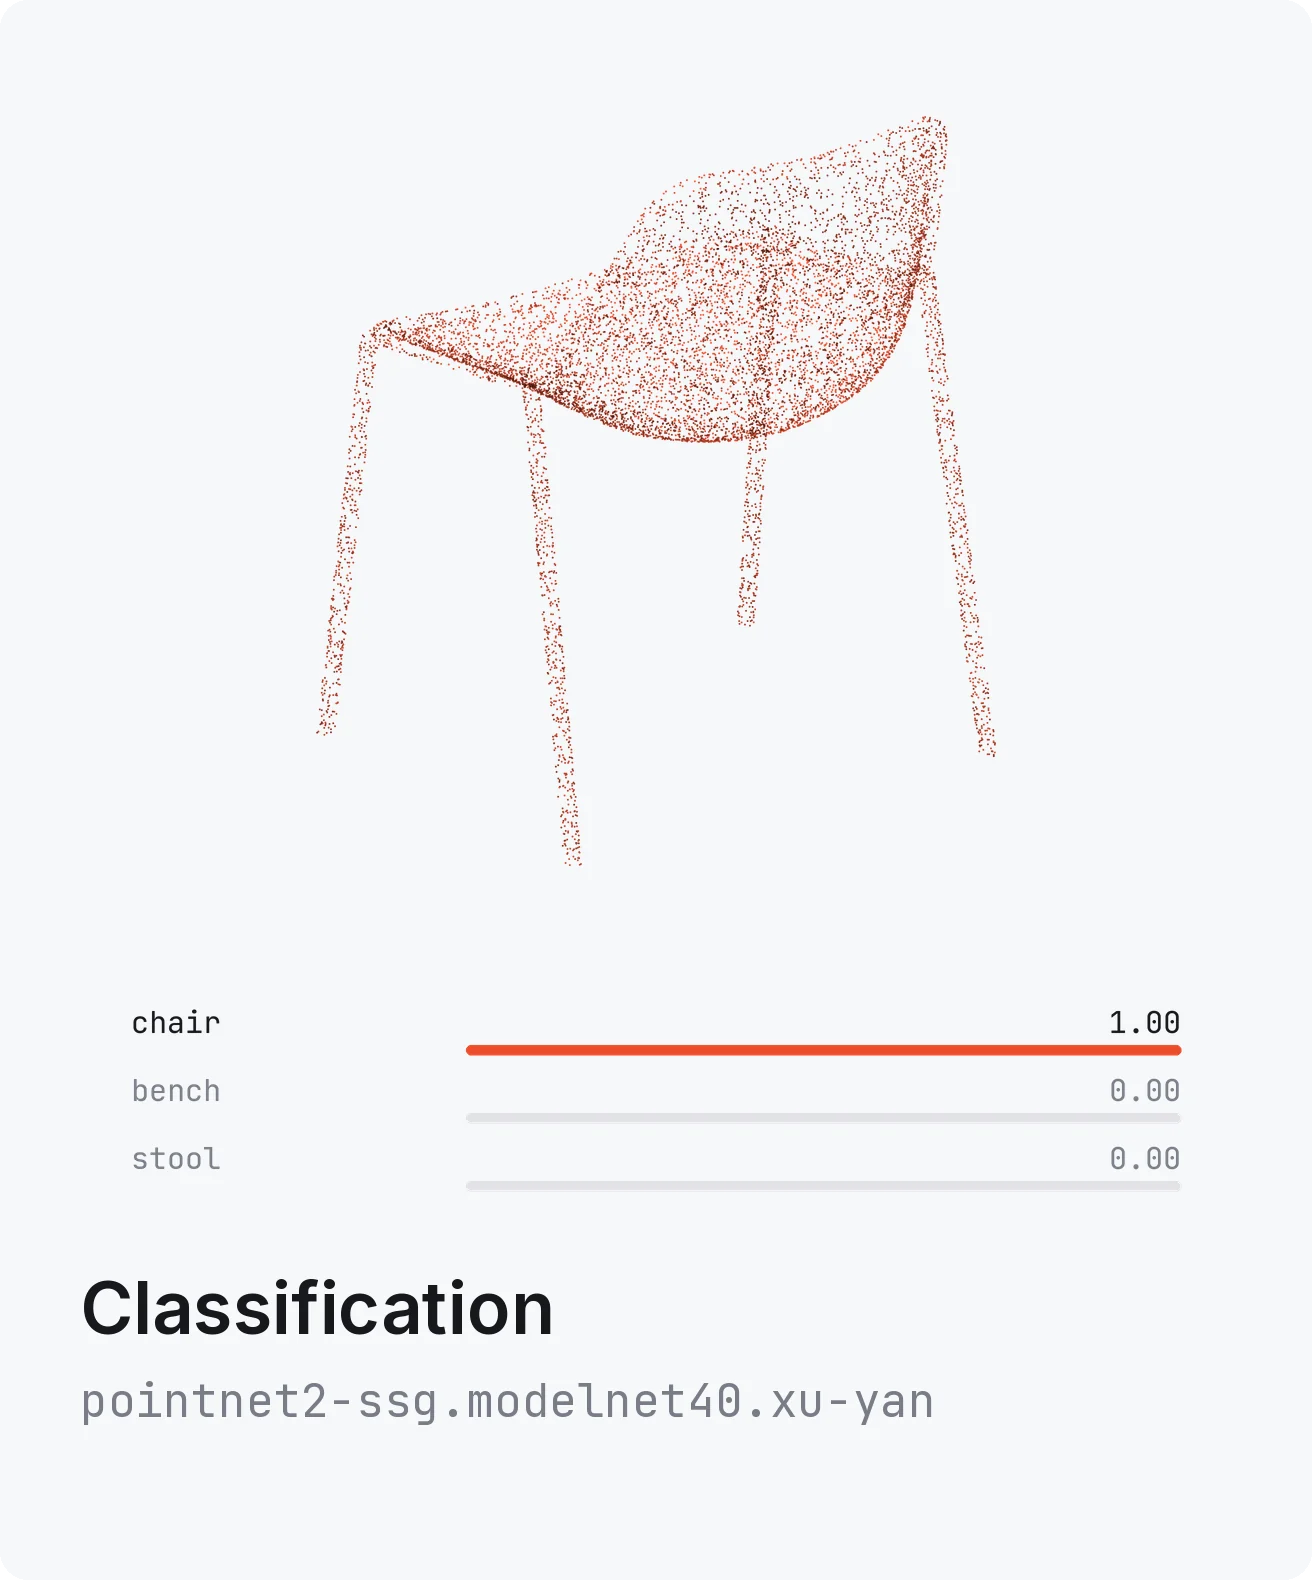
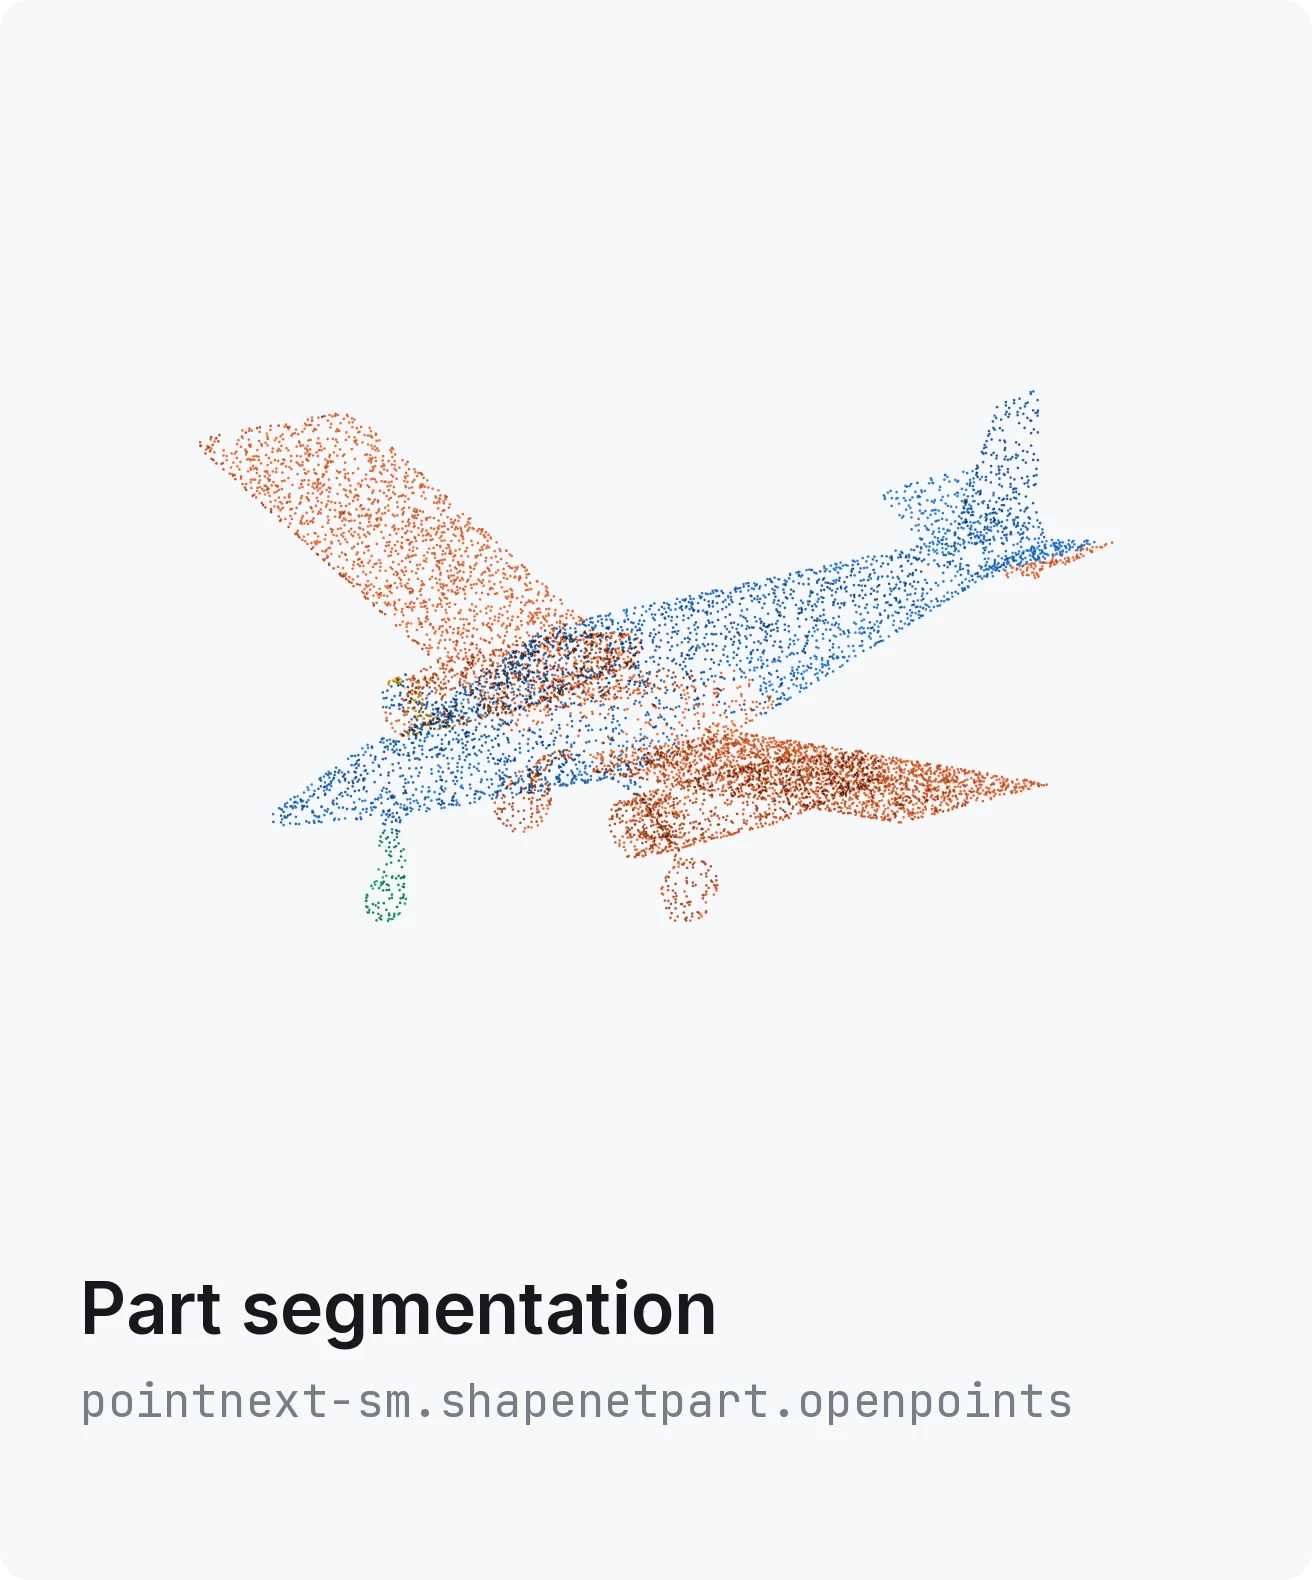
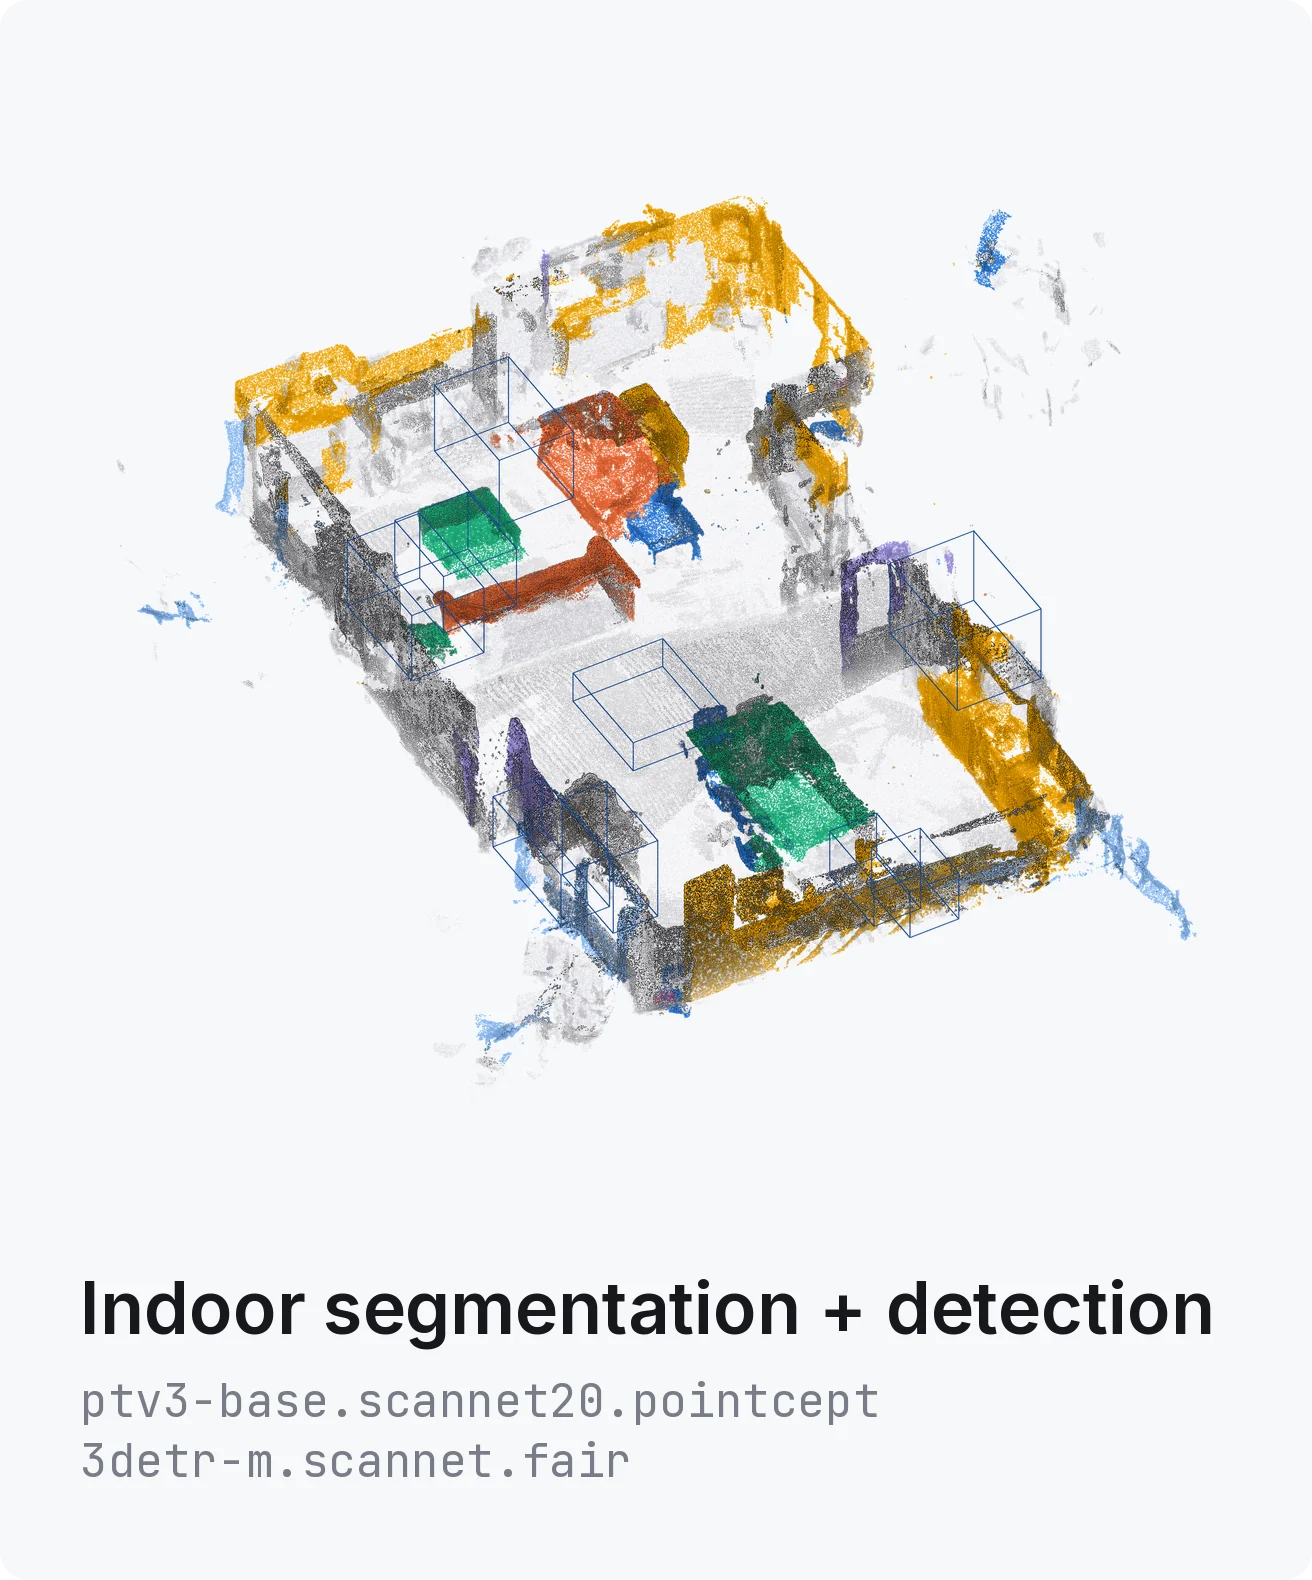
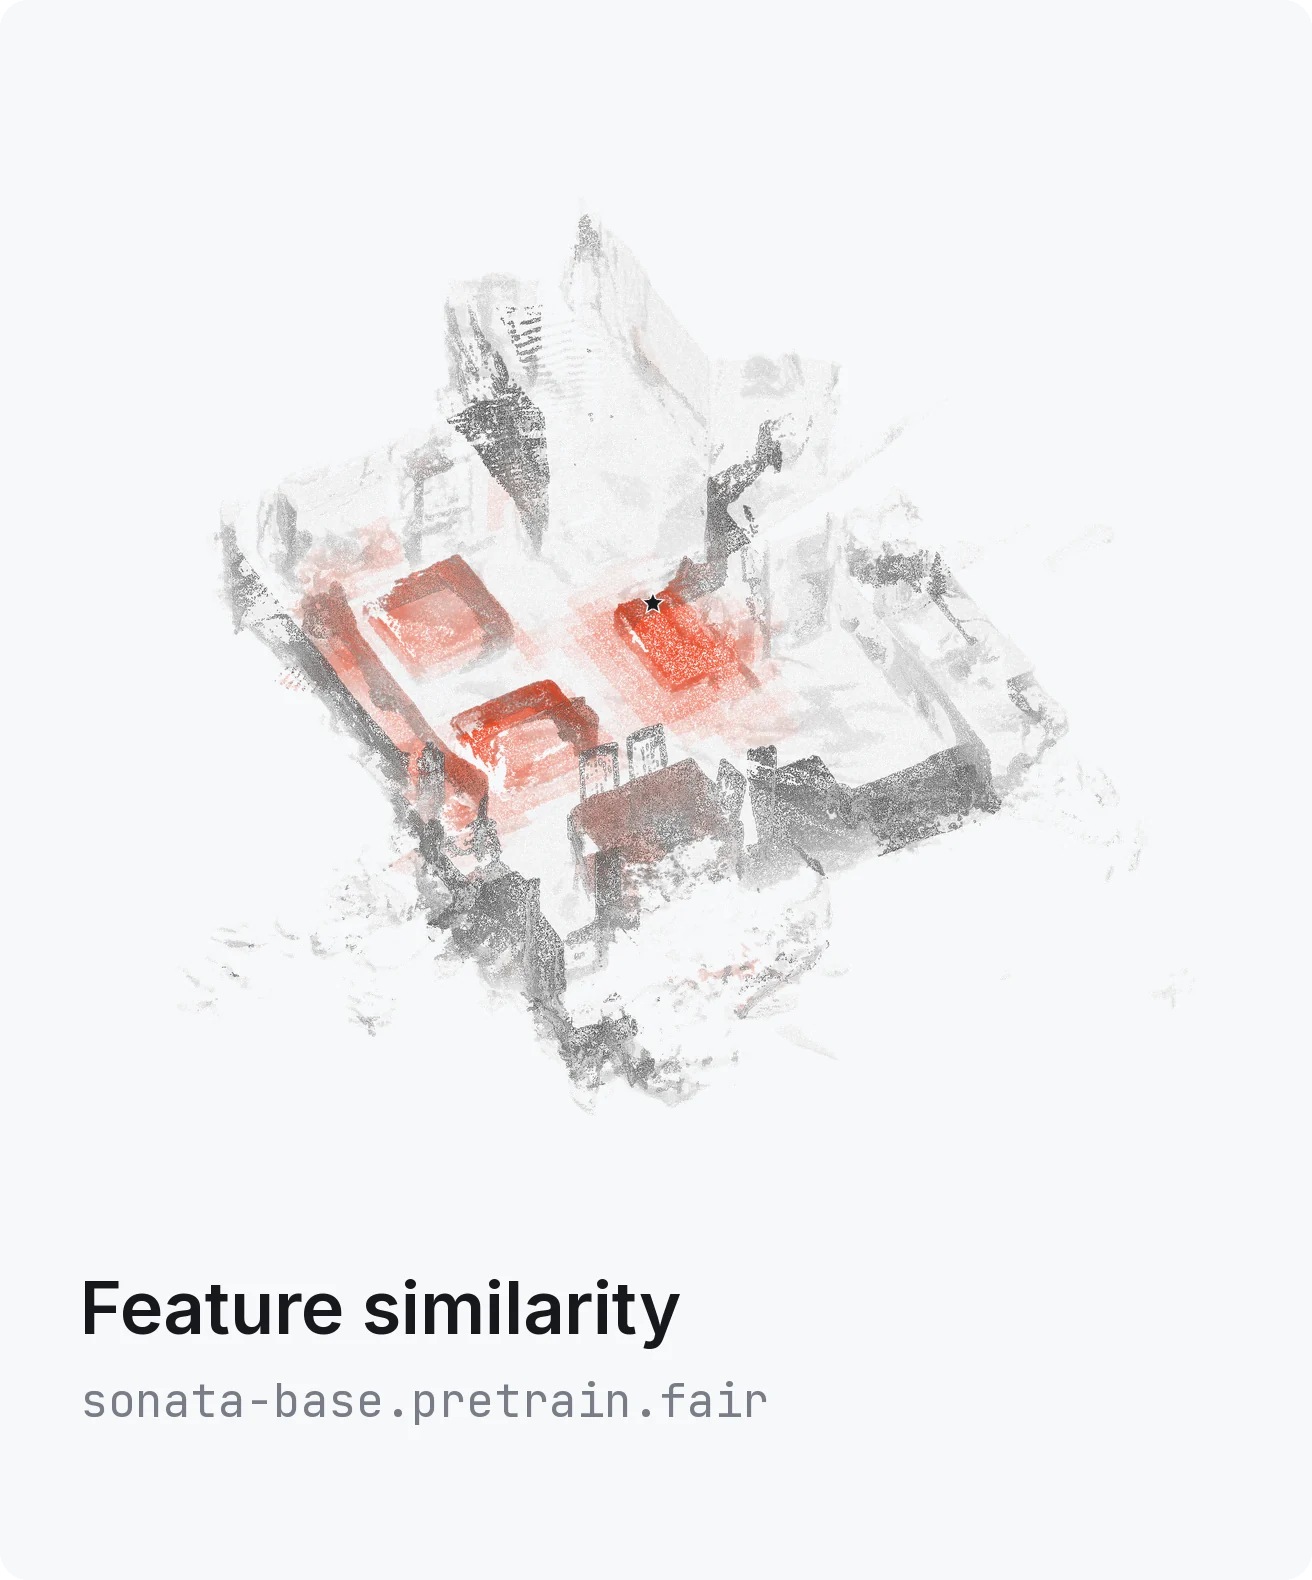
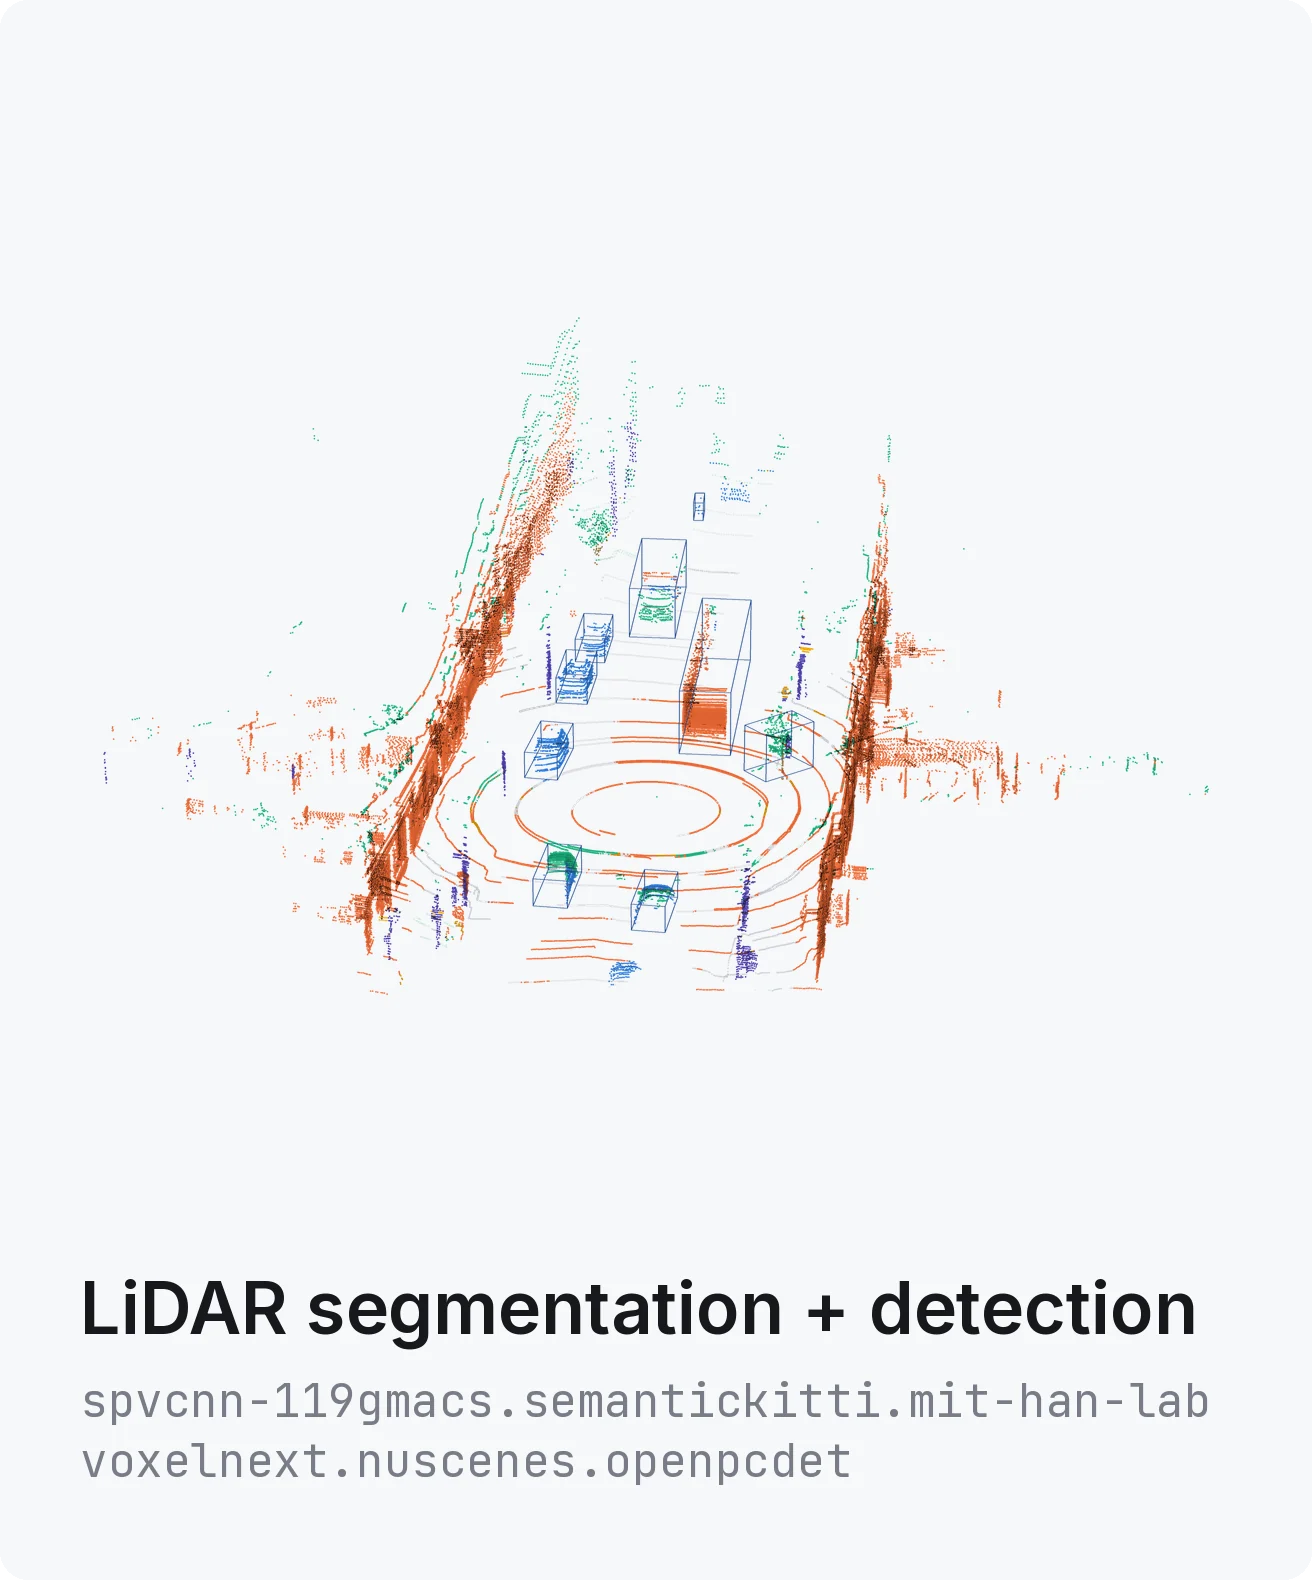
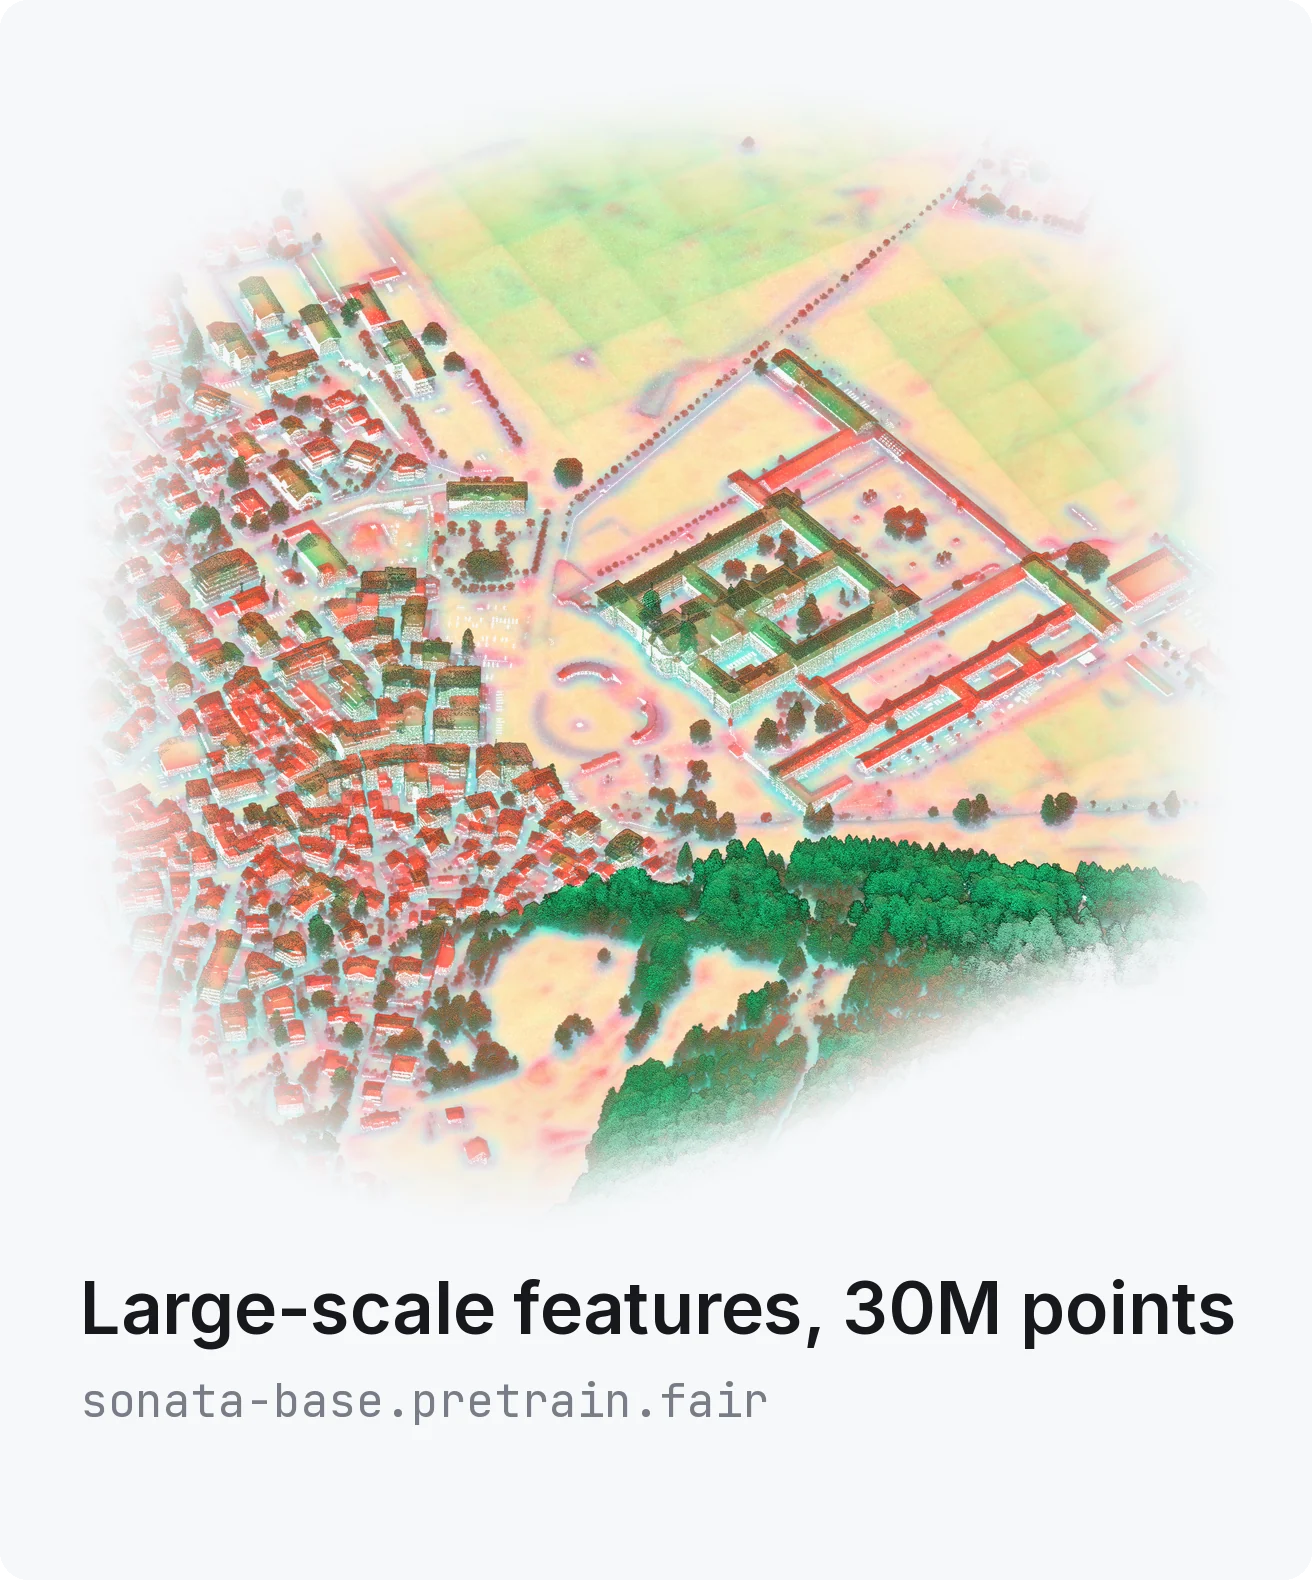
[!WARNING]
torch-pointcloudis in alpha and active development. Expect breaking changes.
Installation
pip install torch==2.10.0 --index-url https://download.pytorch.org/whl/cpu
pip install torch-pointcloud
pip install pyg-lib -f https://data.pyg.org/whl/torch-2.10.0+cpu.html
Most models also need pyg-lib, and some a CUDA extension (spconv, flash-attn, ...), built for your torch and
CUDA versions. Read the installation documentation for further details.
Quickstart
import torch
import torch_pointcloud as tp

# Requires pyg-lib
model = tp.create_model(
    "pointnext-sm.scanobjectnn-hardest.openpoints",
    task="classification",
    pretrained=True,
).eval()

pos = torch.randn(2048, 3)  # (N, 3) coordinates
x = torch.cat([pos, pos[:, 1:2] - pos[:, 1].min()], dim=1)  # (N, 4) features: xyz + height
batch = torch.zeros(2048, dtype=torch.long)  # (N,) batch index

with torch.no_grad():
    logits = model(x, pos, batch)  # (1, 15)
Each checkpoint ships information about the model, such as the transform used to preprocess the input, metrics, license and more.
import torch_pointcloud as tp

model, info = tp.create_model("randlanet.semantickitti.tsung-han-wu", task="semantic-segmentation", pretrained=True, return_info=True)
info["transform"]  # the preprocessing pipeline of that checkpoint
info["weights"]["metrics"]  # {"mIoU": 55.39, "OA": 90.05}

tp.list_models("pointnext*")  # every registered PointNeXt config
tp.list_models(task="detection", pretrained=True)  # all detection checkpoints
See the examples directory for benchmarks and training recipes.
Why torch-pointcloud?
torch-pointcloud is a library of pretrained models that makes common layers and backbones easy to reuse. It does
not replace research-first codebases such as
Pointcept, OpenPCDet and
MMDetection3D or OpenPoints
but it complements them with a common interface that makes benchmarking and interoperability across architectures easier.
Contributing
Contributions are welcome. See CONTRIBUTING.md for the development setup and the pull request checks.
Citation
If you find this project useful, please consider citing:
@software{dujardin2026pytorchpointcloud,
  author = {Dujardin, Arthur},
  title = {PyTorch PointCloud},
  year = {2026},
  url = {https://github.com/arthurdjn/pytorch-pointcloud},
  doi = {10.5281/zenodo.22159632},
  license = {Apache-2.0}
}
License
Apache 2.0. See LICENSE.
Pretrained weights and adapted code keep the license of their source, and some checkpoints are restricted to
non-commercial use (create_model warns when loading them). Most were trained on research-only datasets, whose terms
also apply to the weights.
See THIRD_PARTY_NOTICES.md.