
PetoiCamp/OpenCat-Old
PetoiCamp/OpenCat-Old has 1,382 GitHub stars and 360 forks. GitHot measured +1 stars in 24 hours and +1 in 7 days. Last checked 2026-11-13 00:43 UTC. Last push 2026-09-08.
Crecimiento de estrellas medido
- in 24h
- +1
- in 7 days
- +1
- in 15 days
- Actualización retrasada
- in 1 month
- Actualización retrasada
Cambios netos en períodos que se solapan, no totales diarios. Los datos no disponibles se dejan en blanco. Las estrellas indican interés, no calidad.
Acerca de
A programmable and highly maneuverable robotic cat for STEM education and AI-enhanced services.
AprendizajeREADME.md
OriginalOpenCat
This repository for Nybble is too redundent with large image files and is now obsolete. Please visit our new repository for OpenCat that works for both Nybble and Bittle! For the latest OpenCat robots (Bittle X, Nybble Q), see OpenCatESP32, or buy Bittle X on Petoi.com.
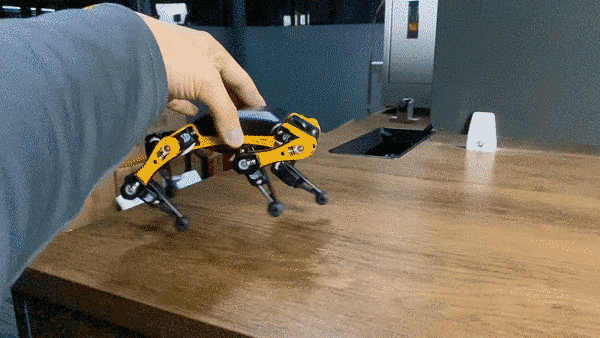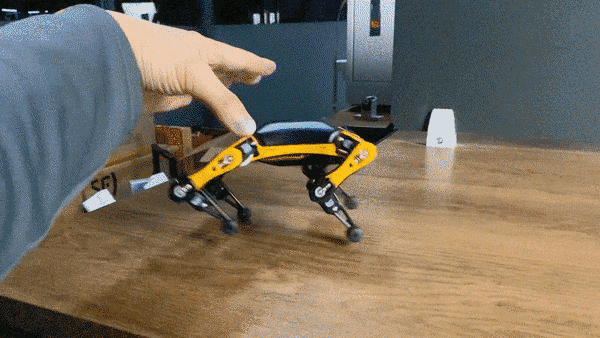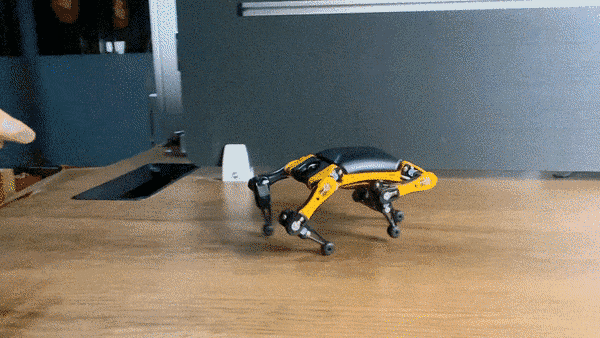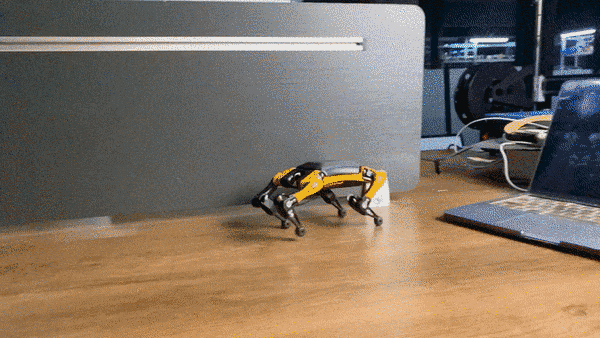
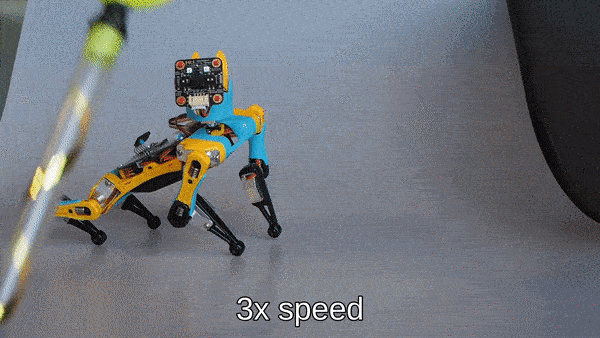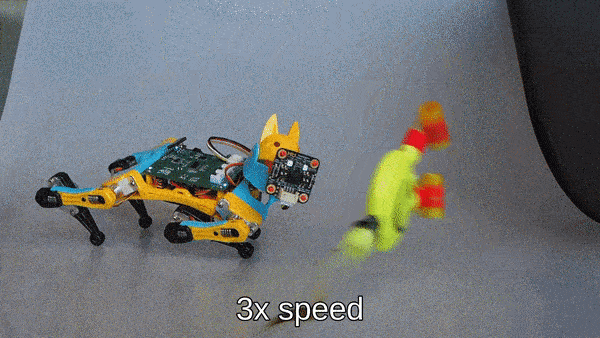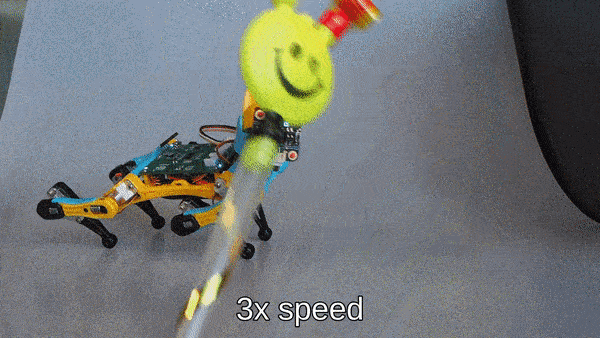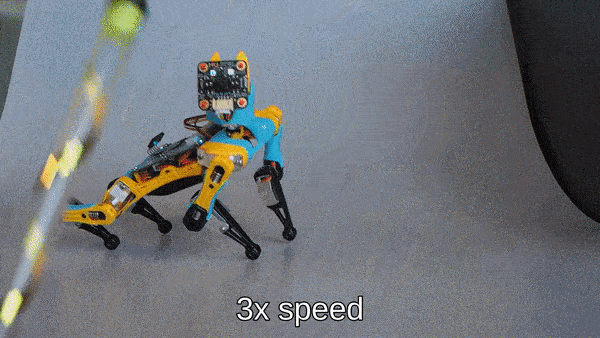
--
This is the repository for OpenCat project.
The goal is to collaborate talents for this cute quadruped mini robot kit. It's still a complex system only for skilled makers, yet we want to share it with the public by mass production and bringing down the cost.
OpenCat robots are used for hands-on physical AI education and real-world physical AI applications — from K-12 robotics classrooms to university research labs — not just screen-based coding exercises.
Quaddle mini robot dog — launching on Kickstarter Sept 2, 2026
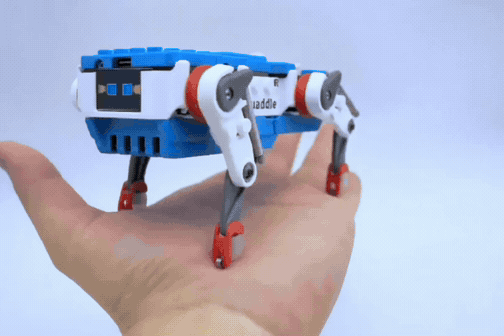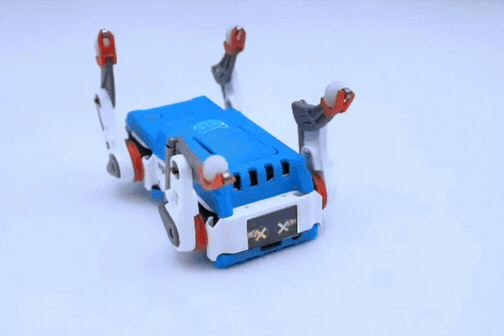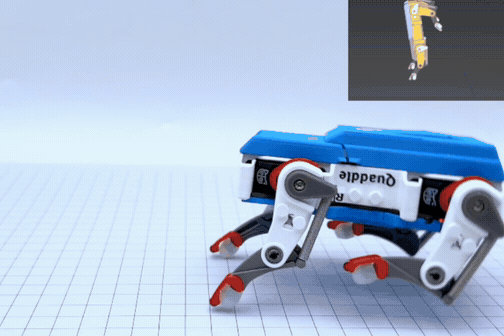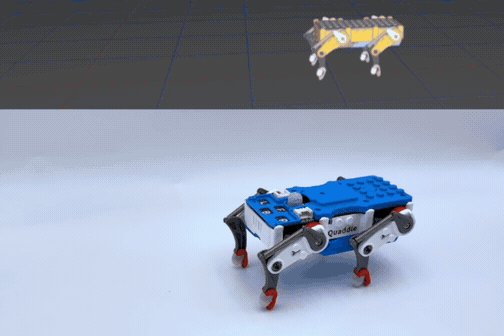
Quaddle is Petoi's newest quadruped, going live on Kickstarter Sept 2, 2026 — a mini desk robot built on the same OpenCat lineage as Bittle and Nybble.
- Full quadruped running on just 4 servos instead of the usual 8–12, which forces genuinely different gait-design and leg-coordination solutions to still get all four legs walking, running, and balancing
- Position-feedback servos — readable, not just drivable — which is what makes Puppet Mode possible: hand-guide the legs and record a motion directly, no code required
- 3D-printable shells and mounts for customization
- Same open platform this codebase's lineage already supports for gait research, reinforcement learning (RL), and sim2real work — a hands-on physical AI platform, not a toy version of the idea
- Try it in the online simulator before it ships
Source code is not yet public. It's an upgraded version of the OpenCat project. Its ESP32-S3 code structure is closer to OpenCatESP32, which already powers thousands of Bittle X and Nybble Q robots in the field, than to this legacy repo. We plan to open source it before Quaddle delivery.
- Watch r/petoi for the open-source announcement
- Get notified on Kickstarter when it goes live
- Check out the Quaddle Hugging Face page
About the Founder & Track Record
Inspired by Boston Dynamics' Spot, Dr. Rongzhong Li started OpenCat in his dorm at Wake Forest University in 2016. The goal was straightforward: make agile quadruped robots affordable and hackable enough for researchers, educators, and makers — not just well-funded labs.
Since then:
- 30,000+ robots shipped, cumulative across all channels
- 60+ countries
- $1M+ raised across two prior Kickstarter and Indiegogo campaigns
- 20+ academic papers cite the platform — see Research Spotlight
- One of the most-starred open-source quadruped robot projects on GitHub
Follow the project:
Explorar proyectos relacionados
sindresorhus/awesome
😎 Listas Awesome sobre todo tipo de temas interesantes [NOTA: Las pull requests están temporalmente desactivadas hasta que tenga ocasión de ponerme al día con las existentes]
536,325 estrellasEbookFoundation/free-programming-books
:books: Libros de programación disponibles de forma gratuita
401,540 estrellasnilbuild/developer-roadmap
Hojas de ruta interactivas, guías y otros contenidos educativos para ayudar a los desarrolladores a crecer en su carrera.
371,949 estrellasvinta/awesome-python
La lista definitiva que responde a «Quiero hacer X en Python, ¿qué herramienta debería usar?».
334,494 estrellas