
xyzzzh/Jag has 41 GitHub stars and 0 forks. Star changes are not measured yet. Last checked 2026-11-11 16:08 UTC. Last push 2026-10-24.
So werden diese Zahlen gemessen
Jag: Direct Box Prediction for Efficient Visual Grounding
Gemessener Sternzuwachs
- in 24h
- Verlauf wird gesammelt
- in 7 days
- Verlauf wird gesammelt
- in 15 days
- Verlauf wird gesammelt
- in 1 month
- Verlauf wird gesammelt
Nettoänderungen in überlappenden Zeiträumen, keine Tagessummen. Fehlende Messwerte bleiben leer. Sterne zeigen Interesse, nicht Qualität.
README.md
Original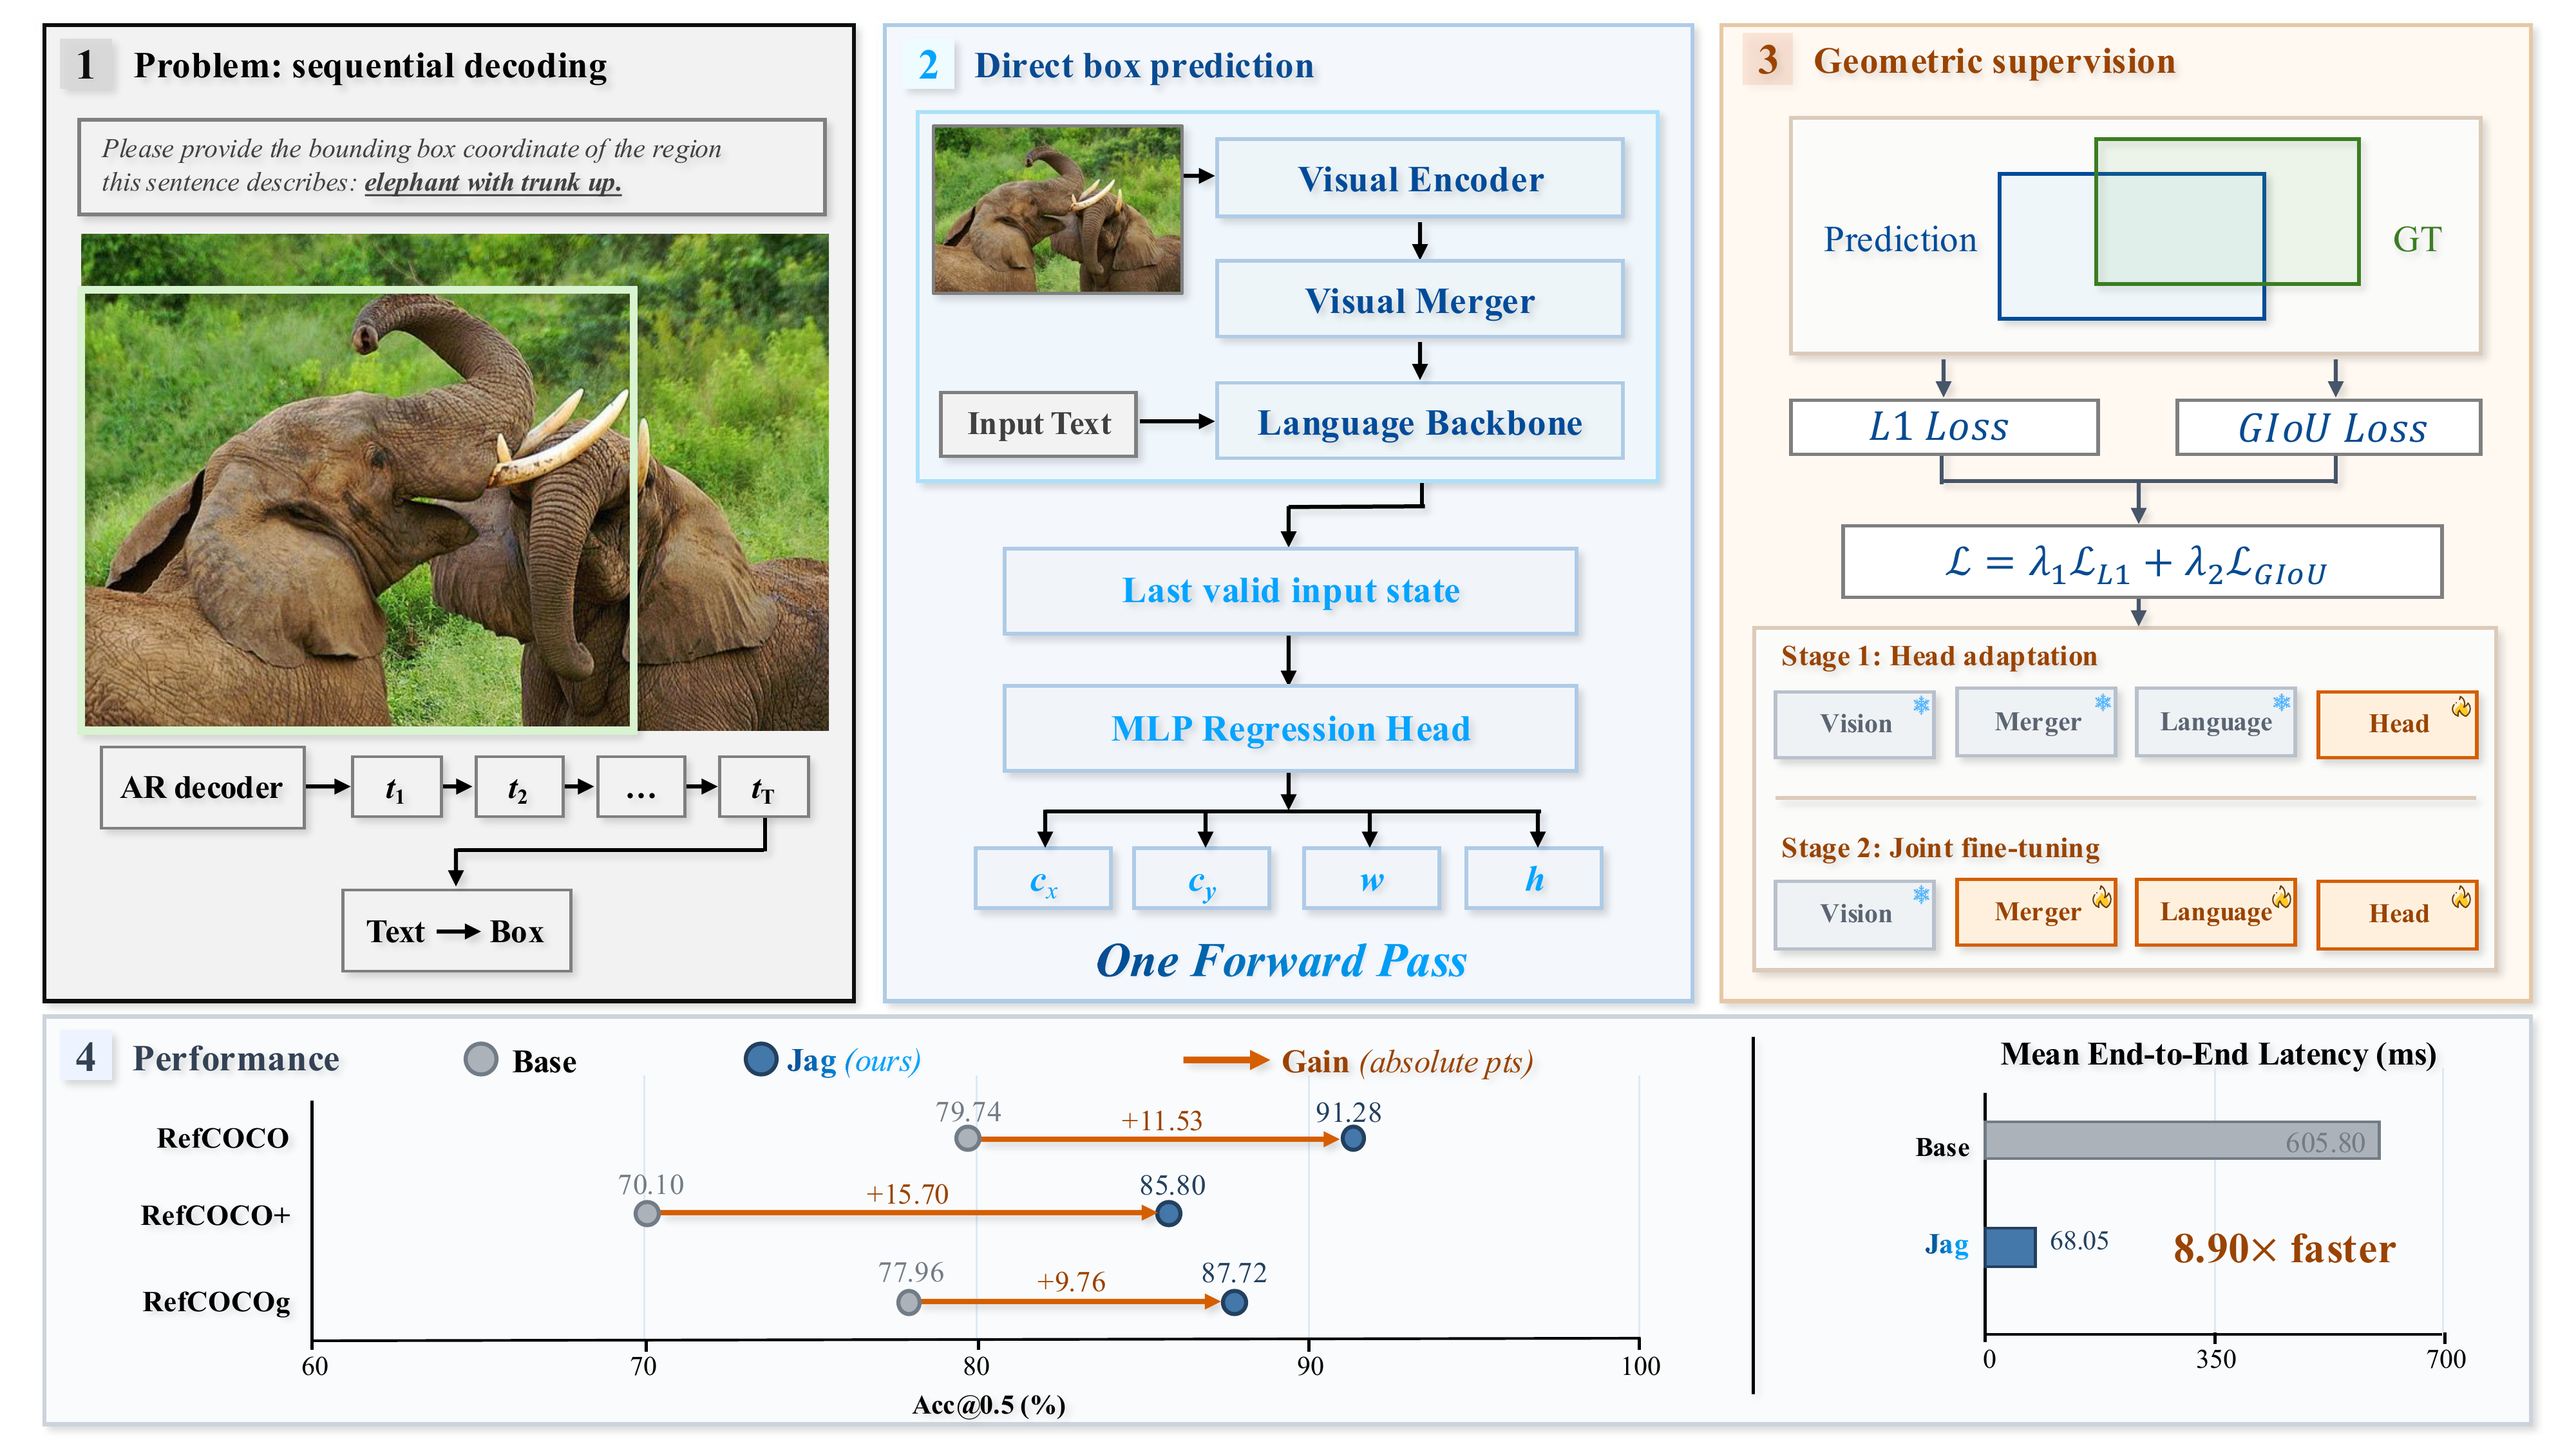
Introduction
Jag adapts a compact multimodal model for continuous bounding-box prediction. It returns the geometric answer directly, retaining the image–language processing of Qwen3.5-0.8B while removing autoregressive coordinate generation.
A lightweight MLP reads the last valid input-token representation and predicts normalized cxcywh coordinates in one forward pass. L1 and GIoU losses supervise head adaptation followed by joint training of the language backbone, visual merger, and regression head. The remaining vision encoder stays frozen.
Training uses ModelScope ms-swift, evaluation uses EvalScope, and Docker provides the environment. Optional SwanLab logging tracks training progress.
Results
Accuracy at IoU ≥ 0.5 (%). RefCOCO and RefCOCO+ pool testA and testB by sample count; RefCOCOg uses test.
| Model | RefCOCO | RefCOCO+ | RefCOCOg |
|---|---|---|---|
| Base (Qwen3.5-0.8B) | 79.74 | 70.10 | 77.96 |
| NExT-Chat | 83.68 | 75.67 | 79.28 |
| LocateAnything | 91.35 | 84.12 | 88.54 |
| Jag | 91.28 | 85.80 | 87.72 |
Jag improves over Base across all five test splits and leads the compared models on three splits. See the per-split results.
Single-request end-to-end inference:
| Model | Latency ↓ (ms) | Throughput ↑ (samples/s) | GPU memory ↓ (GiB) |
|---|---|---|---|
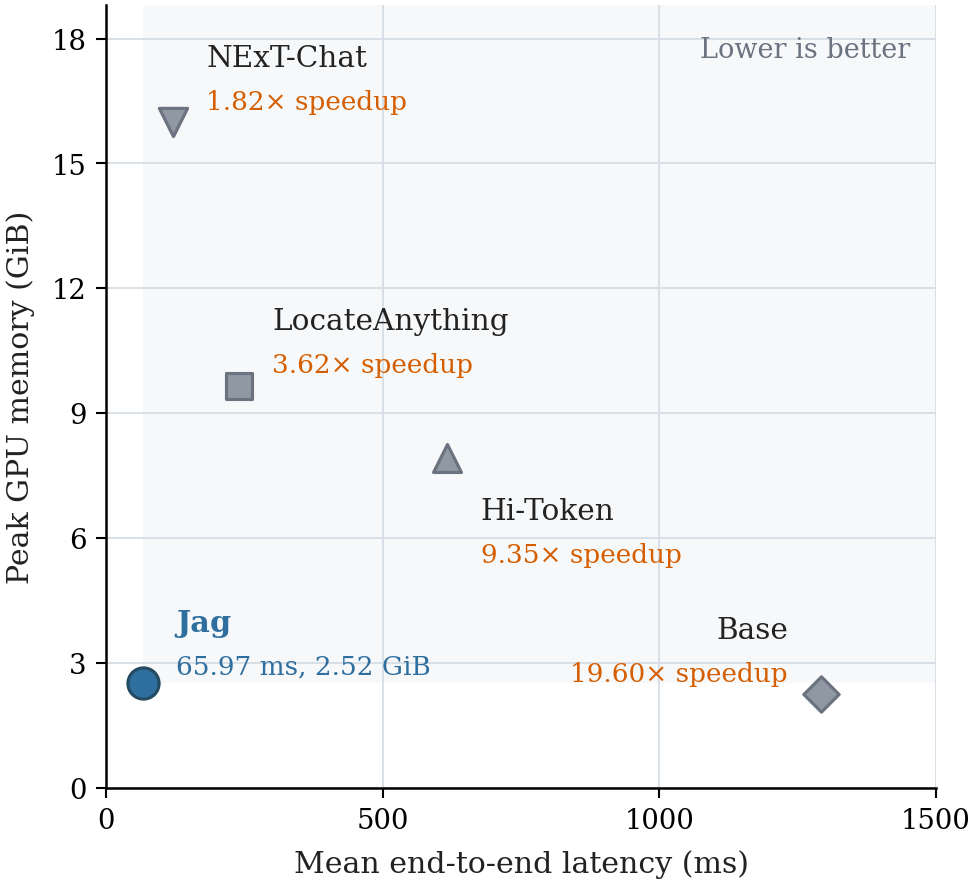
| Base | 1293.01 | 0.77 | 2.25 |
| NExT-Chat | 120.01 | 8.33 | 15.99 |
| LocateAnything | 239.05 | 4.18 | 9.66 |
| Hi-Token | 616.90 | 1.62 | 7.91 |
| Jag | 65.97 | 15.16 | 2.52 |
Jag is 1.82× faster than NExT-Chat, 3.62× faster than LocateAnything, and 9.35× faster than Hi-Token in the measured setting. Model loading and warmup are excluded. GPU memory is the sampled peak process memory.
See the evaluation protocol and model card.
Quick start
Try the online demo, or run Jag on your own image with Python 3.12:
git clone https://github.com/xyzzzh/Jag.git
cd Jag
python3.12 -m venv .venv
source .venv/bin/activate
python -m pip install -r requirements-inference.txt
python -m jag.predict \
  --checkpoint xyzzzh/Jag \
  --image /path/to/image.jpg \
  --expression 'the person wearing a red shirt' \
  --device cuda --weight-dtype bf16
The published model downloads automatically on first use. No training data or separate base-model download is needed. The JSON field bbox_xyxy contains [x1, y1, x2, y2] in original-image pixels; add --output prediction.json to save it. A local model directory is also accepted by --checkpoint. See inference.
Training and evaluation
1. Prepare data and the environment
Install Docker Compose and NVIDIA Container Toolkit, then copy the environment template:
cp .env.example .env
Download and extract train2014.zip. Set REFCOCO_IMAGES_DIR in .env to the extracted train2014 folder, then prepare the RefCOCO annotation archive and download the base model:
python3 scripts/prepare_data.py --archive /path/to/refcoco.zip --output data/refcoco
bash scripts/docker.sh build
bash scripts/docker.sh run --rm jag python scripts/download_model.py
Training uses refcoco_train.jsonl; evaluation uses the five test splits listed in the data guide.
2. Train
bash scripts/train.sh
The training recipe trains on the combined RefCOCO-family training data and exports the completed model to models/Jag. If that directory already exists, use --export-output /models/Jag-trained. For SwanLab, set SWANLAB_API_KEY and add --swanlab. See training.
3. Evaluate
To evaluate the published model without training, download it into models/Jag:
bash scripts/docker.sh --eval run --rm jag \
  hf download xyzzzh/Jag --local-dir /models/Jag
bash scripts/evaluate.sh jag
bash scripts/evaluate.sh base
bash scripts/benchmark.sh
See evaluation for quality and inference measurements.
Contributions
Contributions are welcome. See CONTRIBUTING.md.
Citation
@misc{zhu2026jag,
  title={Jag: Direct Box Prediction for Efficient Visual Grounding},
  author={Xiuyuan Zhu and Ke Lu and Hao Wu and Zijin Du and Dongming Zhang and Jian Xue},
  year={2026},
  eprint={2610.13239},
  archivePrefix={arXiv},
  primaryClass={cs.CV},
  url={https://arxiv.org/abs/2610.13239}
}
License and acknowledgments
Code uses Apache 2.0. Model weights and datasets retain their respective licenses. We thank Qwen, ms-swift, EvalScope, SwanLab, and the COCO/RefCOCO authors.
Ähnliche Projekte entdecken
tensorflow/tensorflow
Ein Open-Source-Framework für maschinelles Lernen für alle
201,505 Sternehuggingface/transformers
🤗 Transformers: das Framework zur Modelldefinition für State-of-the-Art-Modelle des maschinellen Lernens in Text, Vision, Audio und multimodal, für Inferenz und Training.
168,815 SterneAUTOMATIC1111/stable-diffusion-webui
Web-UI für Stable Diffusion
165,289 SterneComfy-Org/ComfyUI
Die leistungsstärkste und modularste GUI, API und das Backend für Diffusionsmodelle mit einer Oberfläche aus Graphen und Knoten. Die schnellste lokale Inferenz-Engine der Welt.
146,271 Sterne