
sea-bass/pyroboplan
sea-bass/pyroboplan has 462 GitHub stars and 51 forks. GitHot measured 0 stars in 24 hours. Last checked 2026-11-18 21:57 UTC. Last push 2026-11-03.
Gemessener Sternzuwachs
- in 24h
- 0
- in 7 days
- Verlauf wird gesammelt
- in 15 days
- Verlauf wird gesammelt
- in 1 month
- Verlauf wird gesammelt
Nettoänderungen in überlappenden Zeiträumen, keine Tagessummen. Fehlende Messwerte bleiben leer. Sterne zeigen Interesse, nicht Qualität.
Über uns
Educational Python library for manipulator motion planning
LernenREADME.md
OriginalPyRoboPlan


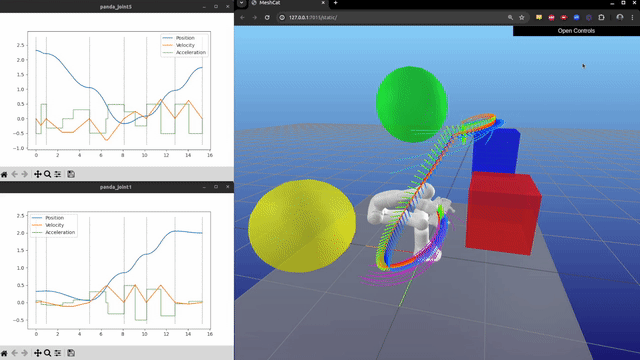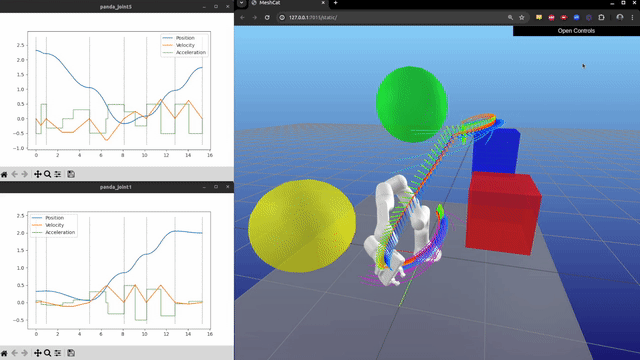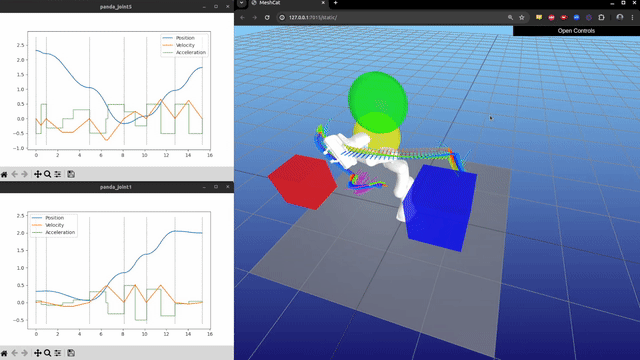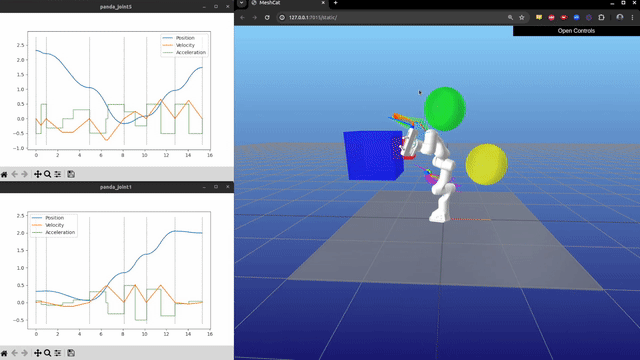
Educational Python library for manipulator motion planning.
This library extensively uses the Pinocchio Python bindings for modeling robot kinematics and dynamics.
For more information, refer to the full documentation, this blog post on motion planning, or this YouTube presentation.
By Sebastian Castro, 2024-2026
[!WARNING] This library should be used for educational purposes only. If you are doing more serious motion planning and control work, check out RoboPlan.
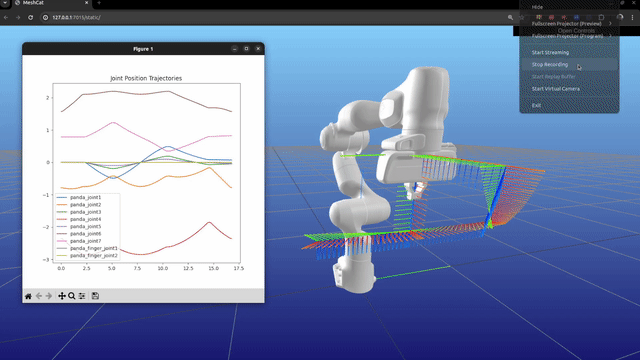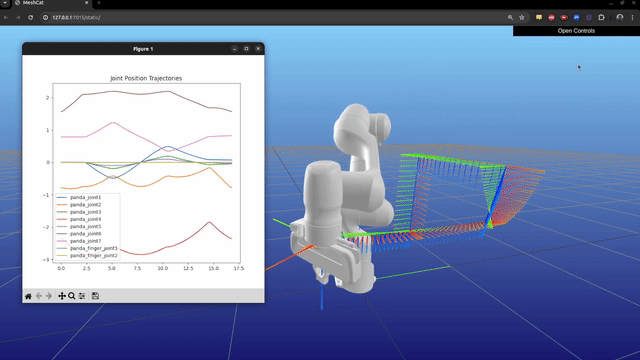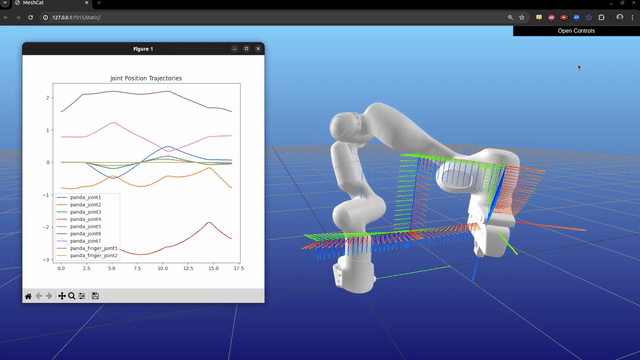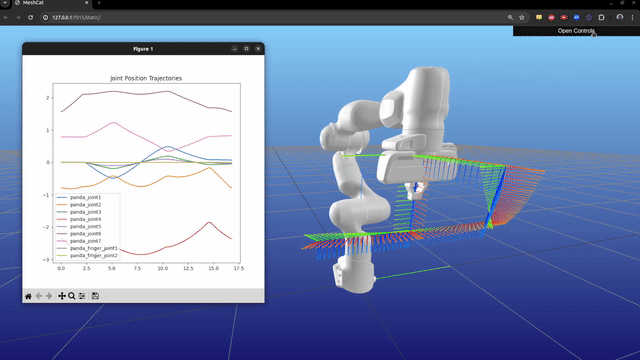
Setup
From PyPi
pip3 install pyroboplan
From Source
Clone this repository.
git clone https://github.com/sea-bass/pyroboplan.git
(Optional) Set up a virtual environment and install dependencies.
source scripts/setup_virtual_env.bash
Install this package and its dependencies.
pip3 install -e .