
menloresearch/asimov-1
menloresearch/asimov-1 has 1,571 GitHub stars and 257 forks. GitHot measured +9 stars in 24 hours and +180 in 7 days. Last checked 2026-11-11 21:34 UTC. Last push 2026-10-30.
So werden diese Zahlen gemessen
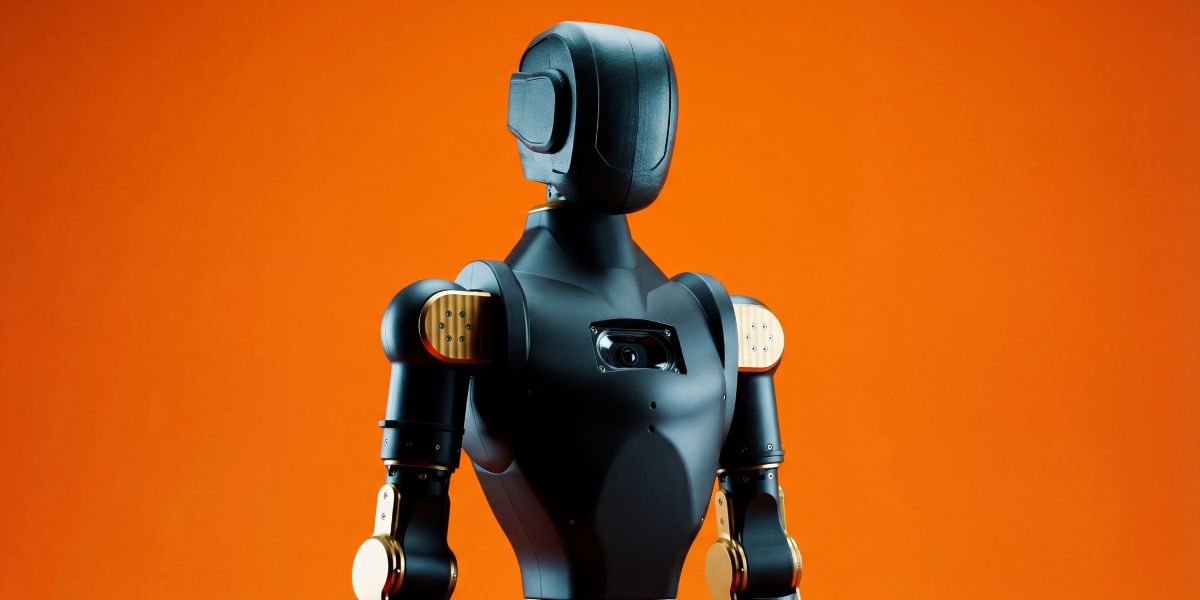
v1 of Asimov, an open-source humanoid robot
Gemessener Sternzuwachs
- in 24h
- +9
- in 7 days
- +180
- in 15 days
- Verlauf wird gesammelt
- in 1 month
- Verlauf wird gesammelt
Nettoänderungen in überlappenden Zeiträumen, keine Tagessummen. Fehlende Messwerte bleiben leer. Sterne zeigen Interesse, nicht Qualität.
README.md
OriginalAsimov 1: Open-Source Humanoid Robot


Asimov is an open-source humanoid robot that you can build, train and customize.
Website · Manual · DIY Kit · 3D Model · Discord · X · Forum
Asimov 1 is a 1.2 m, 35 kg biped with 25 actuated degrees of freedom. This repository contains the mechanical CAD, electrical CAD, simulation model, and onboard software to build, simulate, and customize Asimov 1.
Specifications
| Spec | Value |
|---|---|
| Height | 1.2 m |
| Weight | 35 kg |
| Degrees of Freedom | 25 actuated |
| Legs | 6 DOF x 2 |
| Arms | 5 DOF x 2 (shoulder pitch/roll/yaw, elbow, wrist yaw) |
| Torso | 1 DOF waist yaw, 10 W 4 ohm speaker, 6 DOF IMU |
| Head | 2 DOF neck (neck yaw, neck pitch), stereo microphone array, 2MP monocular camera |
| CAN Bus | 5 @ 1Mbps + 1 @ 500kbps |
| Onboard Compute | Raspberry Pi 5 (media + network) + Radxa CM5 (motion control) |
| Structural Materials | 7075 aluminium, MJF PA12 nylon |
| Activity | Rated Load | Peak Load |
|---|---|---|
| Squat | 5 kg | - |
| Bicep curl | 5 kg each arm | 15 kg each arm |
| Front raise | 5 kg each arm | 15 kg each arm |
| Lateral raise | 6 kg each arm | 18 kg each arm |
Build your own Asimov
[!TIP] Option 1: DIY Kit: Everything you need to build Asimov 1, unassembled. Shipping now for $20,000. Order now →
[!NOTE] Option 2: Self-source: Pull the BOM and fabricate everything yourself. Assembly Manual →
DIY Kit
| Category | Included | Not Included |
|---|---|---|
| Hardware | All BOM components (unassembled), power supply & cabling, spare parts | Tools, hands |
| Compute | RPi edge board, motion control board, network board, power distribution board | 4G/5G modules |
| Sensors | Monocular camera, IMUs, mic, speaker, motor joint states | Lidar, 360 cam |
| Docs | Quick start guide, manual, DIY build videos | — |
Pre-order the Asimov 1 DIY Kit →
Self-source
Start with the repo-local fabrication manifest for the CAD-derived part inventory, then cross-reference the BOM and assembly manual for procurement details, sourcing, and fabrication notes.
The shoe accessory is supplied as a single ASV1_Shoes.STL. The shoes are symmetric and the same geometry fits either foot: print two identical copies in TPU 95A using FDM, one per foot.
The dummy hands are supplied as ASV1_DUMMY_HANDS.3mf, a Bambu Studio project with embedded printing settings. See the mechanical fabrication guide for the part-naming chart and material/process classes, and the stool accessory for its CAD, BOM, and fabrication specifications.
Fabrication manifest
The fabrication manifest inventories STEP and STL files under mechanical/ASV1/*/FABRICATION. Accessories have their own documentation under mechanical/accessories. Regenerate the manifest after changing the robot fabrication files, then verify it:
python3 scripts/generate_fabrication_manifest.py
python3 scripts/generate_fabrication_manifest.py --check
Roadmap
| Status | Item |
|---|---|
| ✅ | Mechanical CAD — 7 subassemblies |
| ✅ | MuJoCo simulation model |
| ✅ | Electrical wiring harness |
| ✅ | Electrical schematics & PCB files |
| 🔜 | Asimov Edge |
| 🔜 | Locomotion policy |
Work with us
- Build questions?: Ask in the forum or open a GitHub Issue for bugs and contributions.
- Deploying Asimov?: Talk to us →
- Supply chain partner?: If you manufacture actuators, structural components, or electronics and want to be part of the Asimov supply chain, reach out. [email protected]
Ähnliche Projekte entdecken
codecrafters-io/build-your-own-x
Meistere das Programmieren, indem du deine Lieblingstechnologien von Grund auf neu erschaffst.
561,936 Sternepublic-apis/public-apis
Eine gemeinschaftliche Liste kostenloser APIs
498,325 Sternemorluto/rea
Mit Agenten alles per Reverse Engineering untersuchen, vom Verhalten der Anwendung bis hin zu nativen Binärdateien.
453,356 Sterneopenclaw/openclaw
Die KI, die wirklich Dinge erledigt. Jedes Betriebssystem, jede Plattform. Auf die Hummer-Art. 🦞
394,375 Sterne