
KumarRobotics/CoverageControl
KumarRobotics/CoverageControl has 29 GitHub stars and 6 forks. GitHot measured 0 stars in 24 hours and +1 in 7 days. Last checked 2026-11-20 04:31 UTC. Last push 2026-09-14.
Gemessener Sternzuwachs
- in 24h
- 0
- in 7 days
- +1
- in 15 days
- Verlauf wird gesammelt
- in 1 month
- Verlauf wird gesammelt
Nettoänderungen in überlappenden Zeiträumen, keine Tagessummen. Fehlende Messwerte bleiben leer. Sterne zeigen Interesse, nicht Qualität.
Über uns
Environment for coverage control and learning using GNN
Maschinelles LernenREADME.md
OriginalSee full documentation at https://KumarRobotics.github.io/CoverageControl/
Introduction
Coverage control is the problem of navigating a robot swarm to collaboratively monitor features or a phenomenon of interest not known a priori.
The library provides a simulation environment, algorithms, and GNN-based architectures for the coverage control problem.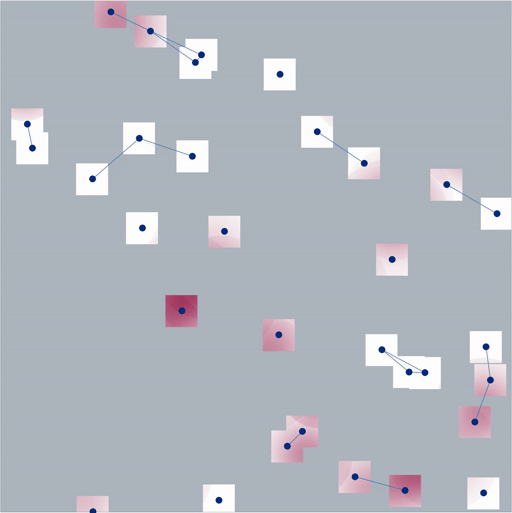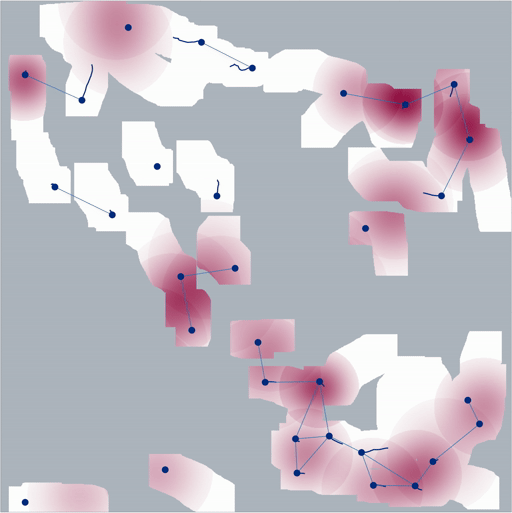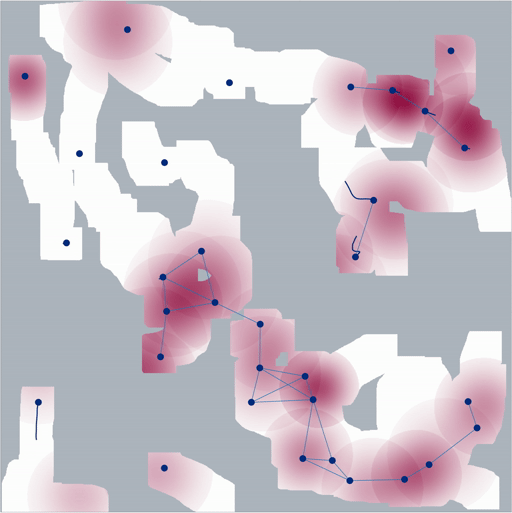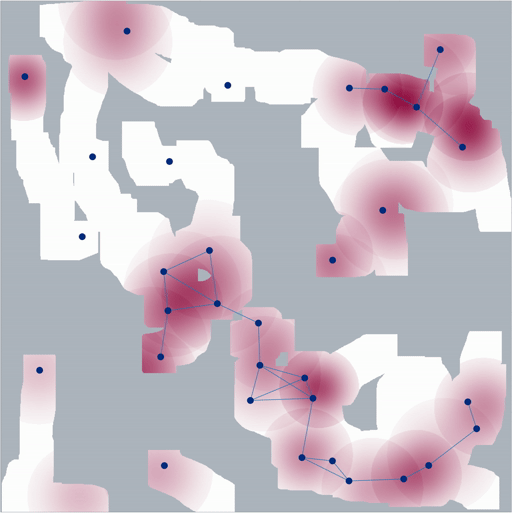
Key features:
- The core library is written in
C++andCUDAto handle large-scale simulations - There are
pythonbindings that interface with the core library - Several Centroidal Voronoi Tessellation (CVT)-based algorithms (aka Lloyd's algorithms)
- Learnable Perception-Action-Communication (LPAC) architecture for the coverage control problem is implemented in
PyTorchandPyTorch Geometric
Getting Started
The library is available as a pip package. To install the package, run the following command:
pip install coverage_control
See Installation for more details on installation.
See Quick Start guide for a quick introduction to the library.
Citation
@article{agarwal2024lpac,
      title         =   {LPAC: Learnable Perception-Action-Communication Loops with
                            Applications to Coverage Control},
      author        =   {Saurav Agarwal and Ramya Muthukrishnan and
                            Walker Gosrich and Vijay Kumar and Alejandro Ribeiro},
      year          =   {2024},
      eprint        =   {2401.04855},
      archivePrefix =   {arXiv},
      primaryClass  =   {cs.RO}
}
LPAC: Learnable Perception-Action-Communication Loops with Applications to Coverage Control.
Saurav Agarwal, Ramya Muthukrishnan, Walker Gosrich, Vijay Kumar, and Alejandro Ribeiro.
arXiv preprint arXiv:2401.04855 (2024).
Acknowledgements
- PyTorch
- PyTorch Geometric
- Eigen
- pybind11
- CGAL
- JSON for Modern C++
- CUDA Samples
- gnuplot-iostream
- hungarian-algorithm-cpp
- toml++
Support and Funding
The work was performed at the GRASP Laboratory and the Alelab, University of Pennsylvania, USA.
This work was supported in part by grants ARL DCIST CRA W911NF-17-2-0181 and ONR N00014-20-1-2822.
Contributors
- Saurav Agarwal
- Ramya Muthukrishnan
License
The library is licensed under the GPL-3.0 License. The documentation is not under the GPL-3.0 License and is licensed under the CC BY-NC-SA 4.0 License.